The Dijkstra algorithm solves the single-source shortest path problem in a finite graph with nonnegative edge weights, finding distances to all reachable vertices. Start with tentative distance and elsewhere. Repeatedly choose the unfinalized vertex with least tentative distance, declare that label permanent, and perform edge relaxation on its outgoing edges. For an undirected graph, inspect both directions. A finite tentative distance always records the cost of a discovered graph path, but can improve before finalization.
In our example, finalizing discovers at , at , and at . Choose next: edge relaxation through lowers to and to . Choose : edge relaxation through lowers to . Finally choose . The permanent distances are therefore , , , ; the evolving tentative distances were and .
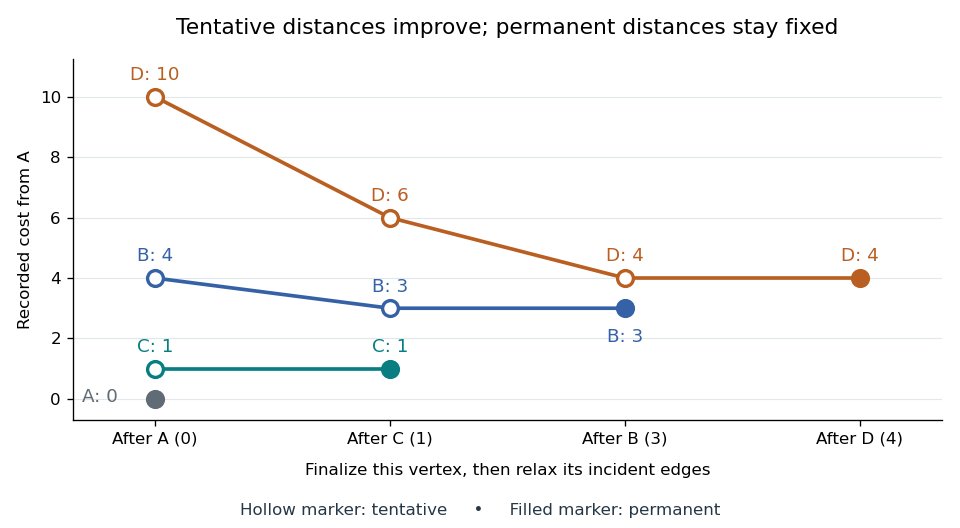
Tentative distances fall until the Dijkstra algorithm makes each label permanent
. Details. Store a shortest-path predecessor whenever edge relaxation improves a label. The final table contains enough information to reconstruct routes, rather than merely their costs:
| Vertex | Distance from | Shortest-path predecessor | Finalization order |
|---|---|---|---|
| None: source | |||
Following shortest-path predecessors backwards gives ; reversing the order gives . If only this destination matters, stop when is finalized. Stopping when is first discovered would incorrectly return . If the smallest remaining tentative distance is , all remaining vertices are unreachable.
Why is the permanent choice safe? Suppose the selected vertex had a cheaper graph path. Let be the first unfinalized vertex on that graph path. Its preceding vertex was finalized, so edge relaxation has already offered a label no larger than that prefix's cost. Nonnegative remaining edge weights make the whole cost at least this prefix's cost; selection gives . A cheaper graph path would contradict these comparisons. Zero weights are allowed; ties can be resolved arbitrarily. This is the reason the label-setting shortest-path algorithm works, rather than a lucky feature of the drawing.
Negative weights break that reasoning. In a directed graph with costing , costing , and costing , the Dijkstra algorithm would finalize at before discovering the cheaper cost . The Bellman-Ford algorithm handles negative edge weights when no relevant negative directed cycle exists.
With an adjacency list and an indexed binary heap implementing a priority queue, the time complexity is for , using Big O notation. Each vertex is extracted at most once, each edge is inspected once per direction, and each successful edge relaxation decreases a heap key in time. This assumes constant-cost arithmetic and comparisons; exact computation with very large weights adds their representation cost. The queue uses space beyond the graph. Simply scanning all remaining vertices gives instead.[ref]
https://algs4.cs.princeton.edu/44sp/DijkstraSP.java.html. Princeton, DijkstraSP implementation
[ref]https://algs4.cs.princeton.edu/code/javadoc/edu/princeton/cs/algs4/IndexMinPQ.html. Princeton, indexed binary heap operations
The 1959 paper presents the shortest path problem as its second problem, after the minimum spanning tree problem, and grows known shortest routes in increasing distance order.[ref]
https://www.cs.yale.edu/homes/lans/readings/routing/dijkstra-routing-1959.pdf. Dijkstra, A note on two problems in connexion with graphs, pp. 269–271
In his later recollection, Dijkstra dated the shortest-route discovery to 1956: a demonstration for the ARMAC computer used a simplified Dutch railway map and printed the route between towns. A practical request became an enduring algorithm because the same distance rule applies to any suitable graph.[ref]https://garfield.library.upenn.edu/classics1983/A1983QA19900001.pdf. Dijkstra's recollection, published in 1983
Among paths of minimum total weight, choose the fewest edges. Store a lexicographic order pair and extend it across weight as . For positive edge weights, every extension strictly increases its first component, so Dijkstra's algorithm settles these pairs correctly when its priority queue and relaxation both compare the full pair. Equal total weight then selects the smaller hop count; arbitrary vertex-name tie-breaking does not express this objective.
A tentative distance is the cheapest cost so far recorded by a shortest path problem algorithm. For the single-source convention, initialize and elsewhere. Every finite label is the cost of a discovered route from to , soIt is an upper bound supplied by an actual route, not a guess that might be too low. The loop invariant follows directly from edge relaxation: extending a discovered route to by supplies another discovered route. The usual label initialization and this safety property are stated and proved in the authored MIT notes.[ref]
https://ocw.mit.edu/courses/6-006-introduction-to-algorithms-fall-2011/6277a1f06100c26a7ff21031af6757b5_MIT6_006F11_lec16.pdf. MIT 6.006, Lecture 16, p. 1: relaxation safety
In the trace under edge relaxation, first records the direct directed path . Later records , and finally records . Each label is a usable route cost, but the first two are not shortest. An infinite tentative distance means no route has yet been discovered; only a completed search establishes unreachability. The isolated vertex in that example remains at .
In a directed graph, the discovered route is formally a directed walk, which may repeat vertices; in the pictured acyclic graph it is always a directed path. Negative-cost directed cycles can keep supplying cheaper directed walks without a finite optimum. In the all-to-one convention, the same meaning applies to discovered routes from to . Do not confuse either version with the lower bounds supplied by feasible potentials in the Bellman inequalities: one records something achievable, the other rules out anything cheaper.
Edge relaxation tests whether extending a recorded route by one directed edge improves a tentative distance. For a single source and an original directed edge of weight , form the candidate . If is finite and , replace by and record the shortest-path predecessor . Otherwise leave both unchanged. The minimum formula in the header gives the resulting label in either case. The authored implementation uses this strict comparison and records the incoming directed edge.[ref]
https://raw.githubusercontent.com/kevin-wayne/algs4/master/src/main/java/edu/princeton/cs/algs4/DijkstraSP.java. Sedgewick and Wayne, DijkstraSP.java, relax method
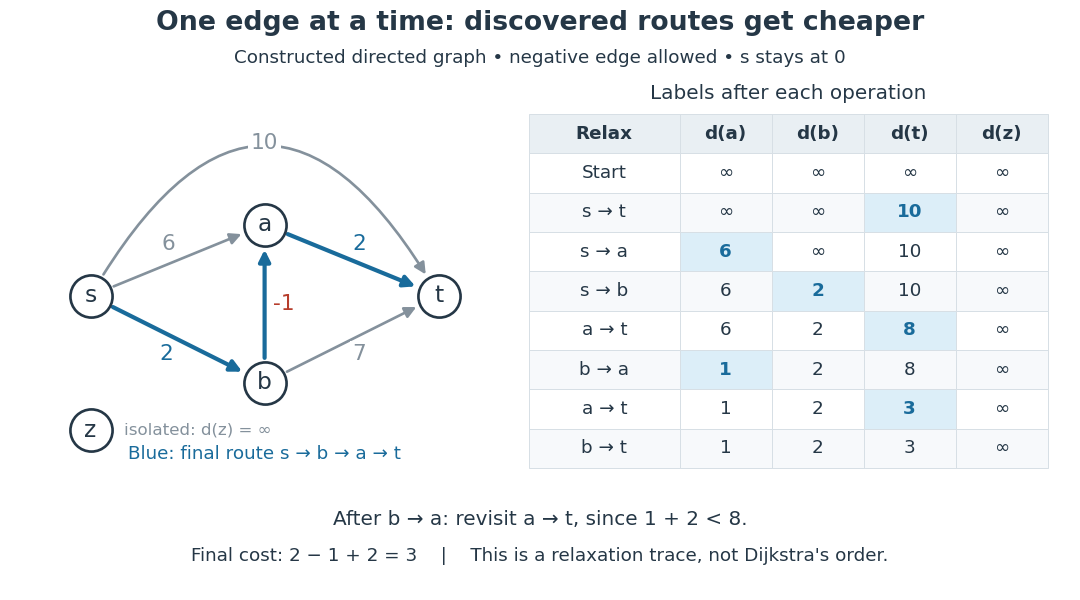


The table lists labels after each specified operation, keeping throughout this constructed acyclic graph. Relaxing first offers . Relaxing then offers , lowering from to ; revisiting now offers . Finally offers , so the label stays. Changing a label can make a previously checked outgoing directed edge worth checking again. This trace illustrates the operation itself, with a deliberately specified order, rather than a run of the Dijkstra algorithm.
A single edge relaxation does not require nonnegative weights: its candidate is the cost of a real extended directed walk, even when the last directed edge has negative weight. Nonnegative weights are needed by the Dijkstra algorithm to make its selected minimum tentative distance permanent. The Bellman-Ford algorithm permits negative weights and revisits labels; its authored implementation also checks for reachable negative-cost directed cycles.[ref]
https://raw.githubusercontent.com/kevin-wayne/algs4/master/src/main/java/edu/princeton/cs/algs4/DijkstraSP.java. Sedgewick and Wayne, DijkstraSP.java, nonnegative-weight precondition
[ref]BellmanFordSP.java. Algorithms, 4th edition by Robert Sedgewick and others; Sedgewick and Wayne, BellmanFordSP.java, signed weights and cycle detection
For the all-to-one convention of the Bellman inequalities, relax the same original directed edge by . This prepends to a discovered route from to , and improves the tail label , not the head label . Skip the operation when . In exact arithmetic, a full pass over all relevant directed edges with no improvement establishes all their Bellman inequalities; combined with the discovered-route upper bounds, this certifies finite distances. One unsuccessful operation establishes only that this particular candidate did not improve its label at that moment.
A shortest-path predecessor records the previous vertex on a chosen route from source to . When edge relaxation strictly improves through , set . For a multigraph, store the actual directed edge, since two edges with the same endpoints can have different weights. Initialize all vertices, including the source, without a shortest-path predecessor. The authored implementation reconstructs a route by following these incoming edges backwards, then reversing their order.[ref]
https://raw.githubusercontent.com/kevin-wayne/algs4/master/src/main/java/edu/princeton/cs/algs4/DijkstraSP.java. Sedgewick and Wayne, DijkstraSP.java, edgeTo and pathTo
At the end of the edge relaxation trace, , , and . Following them gives , so the forward directed path is , of cost . This makes the distance useful: a number tells us the best cost, whereas the shortest-path predecessors tell us which connections to take. In the Dijkstra algorithm, reconstruct a destination's shortest route after its label becomes permanent. In a label-correcting shortest-path algorithm, wait for convergence and the appropriate negative-cost directed cycle check. During correction, a predecessor's label may have changed since its child's last update: immediately after in the trace, the current chain to costs although still records the earlier discovered route of cost .
Strict improvement is a useful guard against directed cycles in the recorded pointers. Consider and of cost zero, followed by and , also of cost zero. After the first two edge relaxations, both labels are zero and both shortest-path predecessors are . If equality also allows pointer replacement, the last two operations can set and : following pointers loops forever despite correct distance labels. Keeping the old pointer on ties prevents this example; choosing among equal-cost routes requires a separate rule that preserves a route to the source. Strict improvement alone does not protect against reachable negative-cost directed cycles, which can force endless decreases. Equality on recorded edges plus the Bellman inequalities certifies route costs only when the pointer chains actually terminate at the source.
For all-to-one distances to , record a next vertex whenever relaxing improves . Follow these successors forward in the original directed graph to reach . They are shortest-path predecessors when viewed in the reversed directed graph; keeping the direction convention explicit prevents returning a route whose arrows point the wrong way.
Articles by others on the same topic
There are currently no matching articles.