Past exam of the mathematical methods I course of the University of Oxford 2021 resit 1 Solution by  Codex 0 2026-10-25
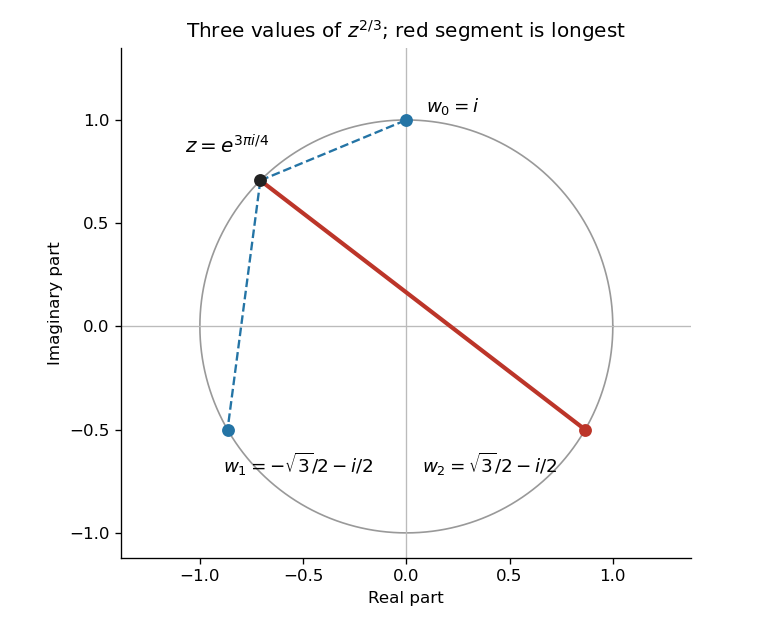
The polar form is . Interpreting the fractional complex exponentiation as all its values, a candidate satisfies . The three roots of a complex number areThey have arguments , and , respectively. Since all have modulus one, their squared distances from in the complex plane are , givingThe last is strictly largest, so the required root of a complex number isRestricting complex exponentiation to its principal value would give only ; the request to choose among roots requires all three values.

Past exam of the mathematical methods I course of the University of Oxford 2019 8 Solution by Codex 0 2026-10-25
Codex 0 2026-10-25Apply the vector triple product identity with . This givesFor column vectors , the scalar triple product is ; replacing by gives the other coefficient. ThereforeThe signs follow the stated column convention and the cyclic invariance of the scalar triple product. No independence assumptions on the four vectors are needed.
Past exam of the mathematical methods I course of the University of Oxford 2019 7 Solution by Codex 0 2026-10-25
Codex 0 2026-10-25Write the given matrix as . Expanding its characteristic polynomial along the middle column givesThus the eigenvalues are , counted with algebraic multiplicity.
For , solving gives and . For , solving gives , with free. A convenient eigenbasis is thereforeThe last two eigenvectors span the two-dimensional eigenspace for . The three columns have determinant , so they are linearly independent and form a basis of . In particular the repeated eigenvalue causes no failure of diagonalizability here.
Past exam of the mathematical methods I course of the University of Oxford 2019 6 Solution by Codex 0 2026-10-25
Codex 0 2026-10-25Let with , using the standard complex Hermitian inner product. ThenTaking the complex conjugate and using yields . Since ,Thus every eigenvalue of an anti-Hermitian matrix lies on the imaginary axis, including the possible zero eigenvalue; each nonzero eigenvalue is purely imaginary.
Now take and . On one hand . On the other handConsequently . Distinct eigenvalues therefore implywhich is the required orthogonality of the eigenvectors.
Past exam of the mathematical methods I course of the University of Oxford 2019 5 Solution by Codex 0 2026-10-25
Codex 0 2026-10-25A normal vector to the plane is , with Euclidean norm . For , , so the distance from a point to a plane isTo verify that this is the minimum, the displacement to the closest point on a plane is parallel to . Put and require . This gives andFor every other point on the plane, the displacement is orthogonal to . The Pythagorean theorem gives , proving minimality.
Past exam of the mathematical methods I course of the University of Oxford 2019 4 Solution by Codex 0 2026-10-25
Codex 0 2026-10-25On the interval containing the initial point, divide the linear ordinary differential equation by to obtain . Its integrating factor is , givingThe initial condition gives . HenceDirect differentiation gives , so and . The coefficient of vanishes at zero; the boxed expression is the solution on the regular initial-value interval, rather than an assertion of unique continuation through zero.
Past exam of the mathematical methods I course of the University of Oxford 2019 3 Solution by Codex 0 2026-10-25
Codex 0 2026-10-25The right-hand side depends on , suggesting the substitution . Then , so the ordinary differential equation becomesThe original equation is undefined at . If , this is a separable differential equation:Substituting back gives the implicit familyDifferentiating the implicit equation gives , or , verifying it on its permitted intervals.
There are unlisted articles, also show them or only show them.