Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Isocline
Direction field 2026-10-14
A direction field for places a short segment with slope at each sampled point where is defined. A function graph of a solution of a differential equation follows these segments: its tangent line has exactly the prescribed slope. Segment length is a drawing choice, rather than a speed; arrows, if used, point toward increasing . An isocline collects points with one common slope.
For Newton's law of cooling, with time in minutes and temperature in degrees Celsius, the slopes at are respectively degrees Celsius per minute. Each horizontal row is an isocline, because this autonomous differential equation has no explicit time dependence. Above the solutions of a differential equation descend, below they rise, and is an equilibrium point.
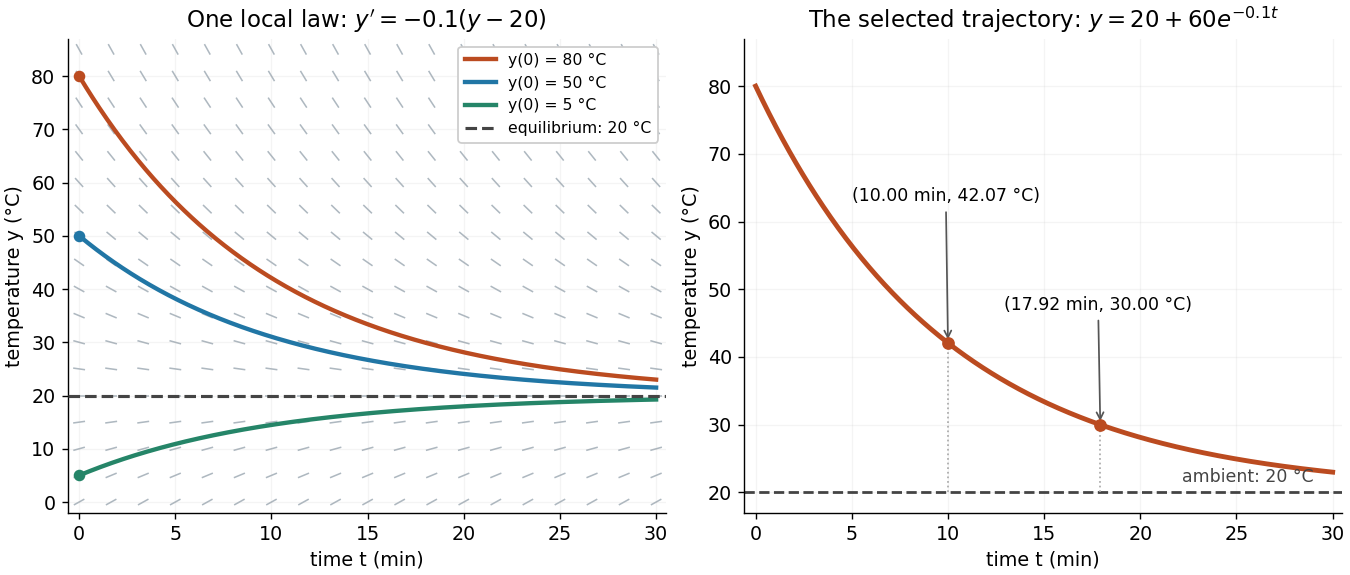
The highlighted initial condition selects one curve from the family. The picture reveals approach to the equilibrium point before any algebra is done. Under the hypotheses of the Picard-Lindelöf theorem, distinct function graphs of solutions cannot cross or even meet in the time-state plane. A direction field alone does not guarantee uniqueness: several curves can share a tangent line at the same point when those hypotheses fail. See the delayed-start example under initial value problem.
This geometric interpretation is developed in Direction Fields, Isoclines, Integral Curves.
Isocline 2026-10-14
For the first-order ordinary differential equation defined on an open subset of the plane, an isocline of slope is the level setHere is a constant. At every point of this isocline, the direction field prescribes a tangent vector proportional to for a solution of a differential equation. It does not generally prescribe the tangent line of the isocline itself. The level set can have several components or fail to be a smooth curve, and points outside are excluded.
For example, take on the whole plane. Its isoclines are the parallel straight linesEach line has slope , while the direction field along it has slope . Thus the isocline carries horizontal segments even though the line itself rises. A function graph of a solution of a differential equation follows the segments, rather than following this line. Only the isocline with , namely , is also a solution of a differential equation.[ref]
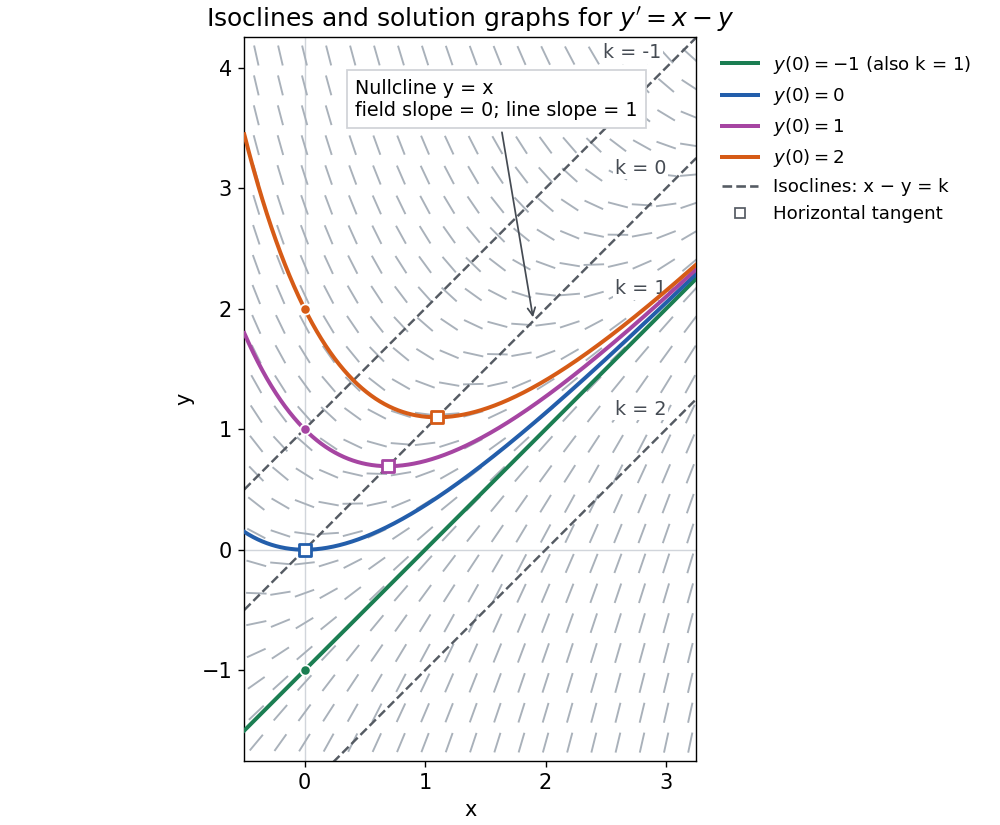
The first-order linear differential equation has the exact familyThe initial condition selects and hence a unique solution of a differential equation for every real . The picture shows . For the solution of a differential equation stays on the isocline; for other it moves through different isoclines. These formulas check the pictured trajectories by direct differentiation, independently of how the direction field was sampled.
The zero-slope isocline is called a nullcline. Below the nullcline in this example, ; above it, . For , the solution of a differential equation meets it at , where and , a strict local minimum. The nullcline is therefore a useful guide to turning points, although it is not itself a solution of a differential equation. In the equivalent planar autonomous differential equation , , it is the nullcline for the second component; there is no equilibrium point, because the first component never vanishes.
This makes isoclines useful even when no explicit solution of a differential equation is available: organize a direction field by common slopes, read where function graphs rise or fall, and identify possible turning points on nullclines.
Past exam of the mathematics course of the University of Cambridge 2004 ia Paper 2 1B Solution Created 2026-09-24 Updated 2026-10-14
For a straight-line solution , substitution into the differential equation gives . Thus , and the two possible slopes areThese straight lines solve the differential equation on either side of the origin. At the origin itself the right-hand side is undefined.
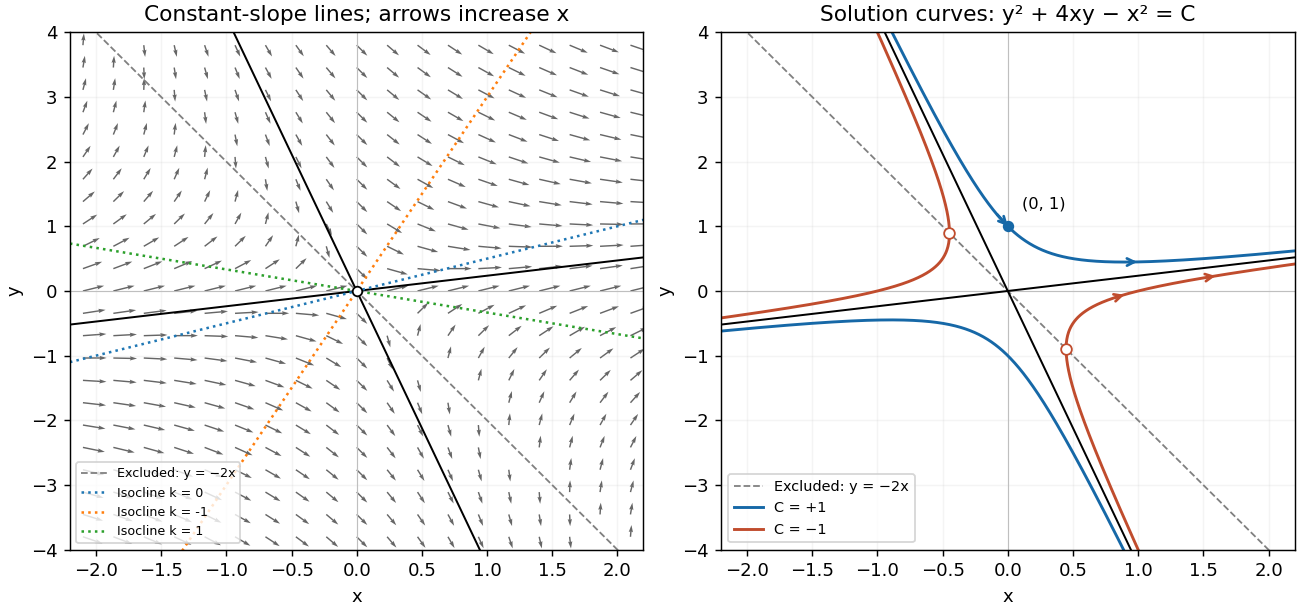
An isocline of slope has equation . For it is the straight line ; for it is , excluding the origin. In particular, is the zero-slope isocline. The line is excluded from the domain of the differential equation; slopes tend to infinity on approaching it. Draw the flow vectors proportional to , with positive horizontal component. This specifies orientation by increasing , rather than by an auxiliary time variable.
To integrate, put where . ThenThe left-hand integral is , so the nonconstant- solutions have the first integralThe constant- solutions omitted by separation are exactly the two straight lines already found, corresponding to . Alternatively, differentiating this first integral gives , which recovers the original differential equation wherever and also verifies continuation through when .
The first integral describes hyperbolas with the two straight-line solutions as asymptotes. For , the upper branch crosses the vertical axis at and exists for every real . For , each branch is confined to and reaches a vertical tangent on the excluded line ; the corresponding classical solution intervals exclude those endpoints. These give the two distinct types of curves requested in the sketch.
The initial condition selects and the upper branch, henceHere , so this really is a global solution of the initial value problem, and agrees with the right-hand side.