Let be an open set and a continuous function. Suppose is locally Lipschitz in the state , with a Lipschitz constant uniform on a sufficiently small time-state neighborhood of each point. Then each determines a unique local solution of a differential equation to the displayed initial value problem, on an interval around . This is the local theorem in Ordinary Differential Equations and Dynamical Systems by Gerald Teschl.
For example, , , has the solution of a differential equation : its derivative is itself and its starting value is . The Lipschitz constant is , since . Thus uniqueness follows even before computing . Picard iteration below constructs this exponential function one polynomial at a time.
The Lipschitz condition has real content. For the continuous function involving a square root,each waiting time gives a different forward solution of a differential equation:The constant solution of a differential equation is another choice. At , delays give respectively. Before the join, both sides of the ordinary differential equation are zero; afterwards, . Both one-sided derivatives at are zero, so the join is valid. All these trajectories can also be extended by zero to . The failed Lipschitz condition is visible in the quotientFor this quotient is . Continuity still allows local existence by the Peano existence theorem; it cannot choose a waiting time. MIT's 18.034 Lecture 2, Example 2.3 develops the same waiting-time mechanism for a different ordinary differential equation, .
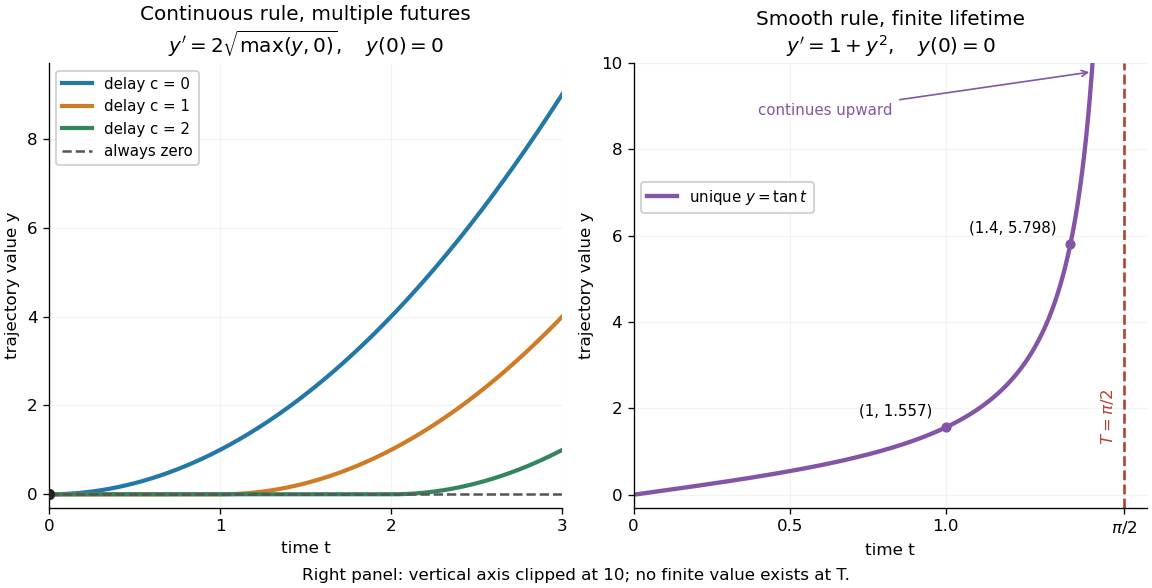
Failure of uniqueness and finite-time blowup are different obstructions
. Left: several delayed solutions of a differential equation of share . Right: the unique solution of a differential equation of , , has finite-time blowup at . The right vertical axis ends at ; the curve continues upward beyond the plot, and there is no finite endpoint value. Details.The useful promise is that an initial condition and a sufficiently regular local rule select one trajectory. It justifies comparing models and following trajectories without an arbitrary choice at each instant. A locally Lipschitz continuous rule need not keep that trajectory bounded: meets the theorem's hypotheses everywhere but has finite-time blowup. Longer existence is governed by the finite-dimensional continuation criterion.
For the ordinary differential equation through , consider a symmetric existence rectangle , . Its maximum slope bound is . The condition becomes . Differentiating shows its maximum occurs at , givingThis is the largest interval guaranteed by this particular centered-rectangle criterion. Direct separation of variables instead gives on the maximal real interval . The comparison shows the difference between a sufficient local existence theorem and the actual continuation interval. The endpoint obstruction is the zero of the denominator at .
A coefficient that vanishes at the initial time can hide failure of the uniform Lipschitz condition required for an initial value problem. For , the map is identically zero. But every rectangle of positive widths around contains some , andNo Lipschitz constant works uniformly on the rectangle. Actual uniqueness also fails: and are distinct differentiable solutions with initial value zero. Substitution gives for the second solution. A condition at the single initial time cannot replace control on a neighbourhood.
Suppose is continuous and Lipschitz in its state variable on a closed cylinder , , with bounds and Lipschitz constant . On a smaller interval of radius , the displayed Picard operator maps continuous curves in that closed ball into itself when , and it is a contraction mapping in the supremum norm when . This function space is complete because it is a closed subset of a Banach space of continuous vector-valued functions. The contraction mapping theorem gives a unique fixed point, and the fundamental theorem of calculus makes it a solution of the ordinary differential equation. Choosing also prevents any solution with the same initial data from first exiting the cylinder during that interval.
For the autonomous differential equation , the displayed family stays at until time and then decreases below it. Here . Direct differentiation verifies the equation on each side; since , the derivative tends to zero at departure, making the joined function continuously differentiable. Distinct departure times give different solutions from the same equilibrium initial condition. The ratio is unbounded, so the local Lipschitz continuity hypothesis of the Picard-Lindelöf theorem fails.
A solution starting above reaches it in finite time. It can then use any of these continuations. For , , and initial value , arrival occurs at time two; departure at gives afterwards. Waiting-time solutions of a sublinear Bernoulli equation give a related mechanism for departures in the opposite direction.
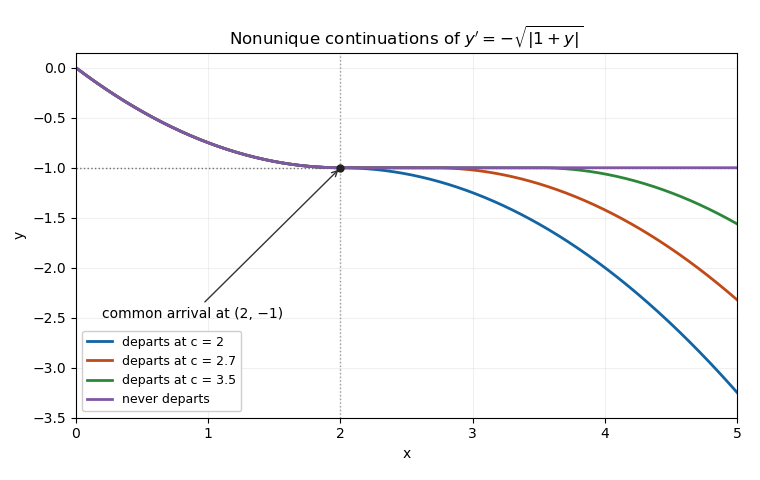
Different waiting-time continuations at a non-Lipschitz equilibrium share the same earlier trajectory
. Details. Picard iteration replaces a tentative trajectory by the accumulated integral of its proposed rate. For an initial value problem , , define the Picard map and its starting function byHere is the constant starting trajectory; the same symbol without its argument denotes the initial state. A fixed point of solves this integral equation, and the fundamental theorem of calculus gives the original ordinary differential equation.
For , , successive integrals giveAt , the first five values are , while . The fourth polynomial misses by about . On , every omitted term of the exponential series is nonnegative and increasing, so the largest error occurs at . The tail tends to zero, giving uniform convergence to the exponential function on this interval.
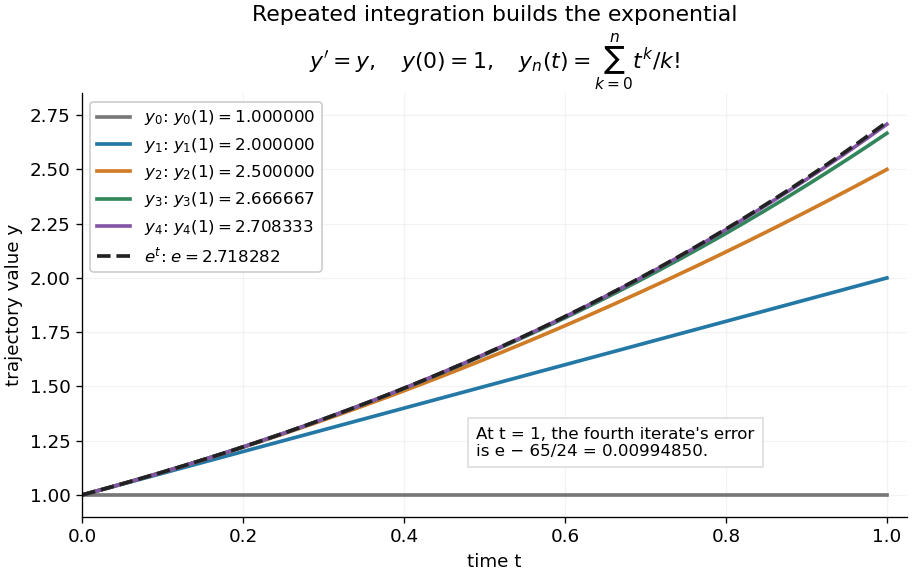
Picard iteration builds the exponential solution by repeated integration
. The first five polynomials approach the exponential function on . Endpoint values are listed in the legend; the last error is approximately . Details.The beauty of Picard iteration is that each proposed trajectory supplies a better rate history for the next one. For this example, one integration adds exactly the next term of the exponential series. In general, the integrals may be difficult to compute, but the construction still explains local existence and uniqueness.
The short contraction mapping argument needs two independent controls. Choose a time-state cylinder on whichThe second bound is the uniform local Lipschitz condition. Set with , and . In the function space of continuous functions , use the supremum norm . On its closed ball , direct integral estimates giveThus the map preserves the closed ball and is a contraction mapping there. This closed ball is a complete metric space, so the contraction mapping theorem gives convergence to exactly one fixed point. Any other local solution of a differential equation stays in the same ball after shortening its interval, and hence agrees there.
For , take , so in the state ball and , . Choosing gives and , with the actual solution satisfying . The plotted interval is longer than this simple guarantee: the explicitly computed exponential series converges there anyway. The condition is sufficient for this one-step contraction mapping argument, rather than a necessary lifespan bound.
For real constants , apply Picard iteration to the initial value problem , , starting with . The recurrence isSince , mathematical induction gives the displayed partial sums. The exponential series converges at every finite argument, so for every real , uniformly on each compact interval in that range. This is not a Taylor series in , so its convergence is not restricted to . The differential equation's coefficient is singular at even when a special solution has a removable singularity there.
For Picard iteration , , assume and a Lipschitz constant on a rectangle containing every iterate. The first difference is at most . Integrating the preceding bound multiplied by proves the displayed estimate by mathematical induction. Its uniform bounds sum to a convergent exponential series for every finite , so the Weierstrass M-test gives uniform convergence without requiring .
For two arbitrary initial functions in a function set preserved by the Picard iteration operator , the same induction givesThus some iterate is a contraction mapping on any fixed finite interval for which every iterate stays in that set. The iterated contraction argument gives a unique fixed point of on a nonempty complete metric space, without requiring . For a rectangle with field bound and vertical radius , supplies the required self-mapping property.
Consider the Volterra integral equationwhere is continuous, , , and the continuous kernel satisfies for , with . If , there is exactly one continuous solution on the whole half-line. It is bounded, and Picard iteration beginning at converges in supremum norm with contraction ratio at most .
For a proof, the integral of the kernel is at most . Thus maps the closed ball of radius in the Banach space of bounded continuous functions into itself, since . Factoring gives on this ball. The contraction mapping theorem gives its unique fixed point. A first-exit argument shows that every continuous solution, even one not initially assumed bounded, stays strictly inside the same ball: a first time with would contradict . Reapplying the estimate gives the strict global bound , so uniqueness is unrestricted within the continuous solution class. If , zero is the only solution by the Gronwall inequality on each finite interval.
A Picard iterate is one of the successive approximate solutions of a differential equation obtained by repeatedly applying its integral solution operator. If and , the usual operator is . An integrating factor can produce a different, equivalent operator with better estimates, as in Global Picard iteration with a decaying kernel. The word iterate denotes an approximate function; Picard iteration denotes the procedure.
Under the Picard-Lindelöf theorem's hypotheses on , extend a solution of a differential equation as far as possible, to a maximal interval . If , the time-state trajectory must eventually leave every compact subset of . Equivalently, confinement near to one compact subset of permits continuation past . See Teschl, Section 2.6, Lemma 2.14 and Corollaries 2.15–2.16, pp. 52–53.
The domain restriction matters even for a bounded trajectory. Restrict , , to . Then exists in this domain only for ; at its values are . As , it approaches the excluded boundary point while remaining bounded. Its trajectory cannot fit into any compact subset of near that endpoint. This is escape from a finite domain, without finite-time blowup in norm. Enlarging the domain to gives the same formula for every real .
Conversely, , , stays in the compact set for every fixed . Its growing exponential function is unbounded over the entire future, but has no finite-time blowup. At , its largest value on is only . The relevant question is boundedness before each finite endpoint, rather than one bound valid forever. The tangent function in the diagram under the Picard-Lindelöf theorem illustrates the other possibility: its norm escapes every bound before .
This criterion is useful because an estimate can secure continuation without an explicit formula. In a finite-dimensional vector space, a bounded closed ball is compact; a bounded state trajectory therefore supplies the needed compact set when its time-state closure is inside the domain. That final proviso prevents mistaking a domain boundary for finite-time blowup.
A common sufficient estimate comes from global Lipschitz continuity in the state. Assume for an open time interval , with continuous and a Lipschitz constant valid for all states on each compact time interval under consideration. For , let , finite by continuity. Then , and the Gronwall inequality gives, for wherever the solution already exists,For instance, , , has and the exact solution , attaining this estimate; at the value is . Finite bounds of this kind give continuation throughout , with the analogous estimate backwards in time. When , this gives existence for all real times. If has a finite endpoint, it gives no continuation beyond that prescribed domain. The underlying linear-growth criterion is [ref].
A brief explanation of the continuation mechanism suffices: within the protecting compact set, the continuous function is bounded, say by . The integral equation yields near the finite endpoint, so has a limit . The protecting compact set puts inside . Restarting the initial value problem there and using local uniqueness joins the trajectories.
The Bielecki norm method changes the norm used for an integral contraction mapping, allowing a larger time interval without changing the underlying continuous functions. On for a Banach space , useFor with a uniformly -Lipschitz continuous right-hand side,Thus makes a contraction mapping. On a fixed finite interval this weighted supremum norm is equivalent to the usual one. The Banach fixed-point theorem applies when maps the chosen complete function space into itself.
For integration from to , the weight gives the alternative bound for . Both versions reduce the integral operator bound by choosing a weight, rather than by claiming that a local existence theorem automatically gives a global solution for an arbitrary nonlinear vector field.
Articles by others on the same topic

The Picard–Lindelöf theorem, also known as the Picard existence theorem or the Picard-Lindelöf theorem, is a fundamental result in the theory of ordinary differential equations (ODEs). It provides conditions under which a first-order ordinary differential equation has a unique solution in a specified interval.



