A critical point of a dynamical system is a point where both components of the vector field vanish. For a continuously differentiable vector field, strictly negative real parts of both eigenvalues of its Jacobian matrix imply asymptotic stability of the equilibrium. If an isolated critical point is a center of a planar dynamical system and the eigenvalues are distinct, they must be a nonzero purely imaginary conjugate pair. Purely imaginary eigenvalues alone do not in general prove nonlinear stability; the nonlinear ordinary differential equation system must still be examined.
Here the critical points are and , with Jacobian . At zero its eigenvalues are , giving an unstable saddle equilibrium. The unstable direction is and the stable direction is . Thus trajectories leaving the origin are tangent to , and those returning are tangent to , with both opposite rays included.
An exact first integral isThe two homoclinic loops belong to :They confirm the incoming and outgoing tangent directions. For example the right loop is , ; changing both signs gives the left loop.
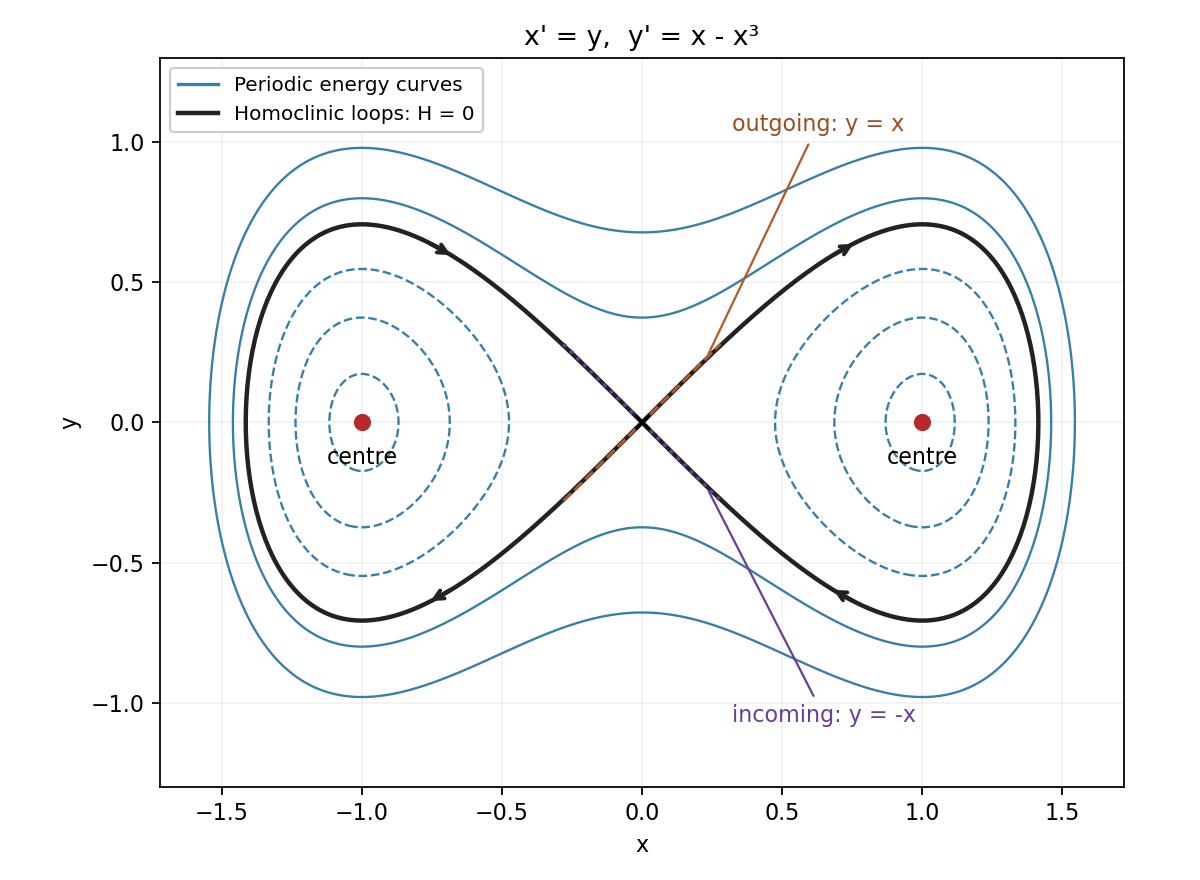

At put , . The exact equations are , , so the linearization of a dynamical system gives . Its nonconstant solutions haveThe same linear classification holds at . For the nonlinear ordinary differential equation system, has strict local minima at both points. Levels are two families of smooth closed ovals, proving that both are stable centers, rather than asymptotically stable equilibria. These give actual periodic orbits of the nonlinear ordinary differential equation system, with small-amplitude periods tending to .
Articles by others on the same topic
There are currently no matching articles.