Put and . The lens space is the quotientThe cyclic group has order . Its action is free: if fixes a point with , then ; if , then and , which again implies by coprimality. A finite free smooth action gives a closed orientable three-manifold, and the quotient projection is a covering space.
Since is simply connected, this is the universal covering and its deck group is the cyclic group of order . HenceFor the quotient is and the group is trivial. With this unoriented quotient convention, replacing by reverses the chosen generator and leaves the quotient unchanged; oriented surgery conventions may record the signs differently.
Take two solid tori , each with a meridian-longitude basis on its boundary. Use opposite boundary-basis orientations on the two sides, so that a determinant-one coefficient matrix describes an orientation-reversing gluing map. For choose a torus homeomorphism inducingand define . The linear map on realizes the matrix. Torus homeomorphisms with the same action on first homology are isotopic, and an isotopy extends over a boundary collar, so the resulting three-manifold depends only on . Specifying opposite boundary conventions is necessary: gluing two identically oriented boundary bases by a determinant-one map would not describe the usual oriented gluing.
We now identify this gluing directly in the quotient from part (a). Split into the two invariant solid tori and . On write , . The quotient coordinatesidentify with . They are invariant under ; choosing a th root of reconstructs , and different choices are exactly the same cyclic orbit. Thus this is a genuine solid-torus coordinate model.
On the common boundary, measure arguments in turns as . Its quotient lattice isThe meridian and longitude of the first quotient torus can be chosen as and . They form a lattice basis, since . The meridian of the second torus is precisely that loop. Consequently
The determinant condition is . Put , so . On , the analogous quotient coordinates use and , and a longitude is . Choose its negative for the second boundary-basis convention. Thensince . Thus the two quotient tori are glued by exactly . This proves the genus-one gluing model of a lens space andDifferent choices of satisfying the determinant condition differ by . This changes by a meridional Dehn twist on , which extends over : in solid-torus coordinates it is . Therefore there is no hidden dependence on that choice of longitude.
Use the quotient lens spaces and set . Let . The mapis a homeomorphism and satisfiesbecause . Since is invertible modulo , generates the entire target deck group. Hence maps cyclic orbits bijectively to cyclic orbits, as does its inverse, and descends to a homeomorphism:This is an explicit map, so no classification theorem for lens spaces is required. It reverses orientation: complex conjugation in one coordinate reverses the ambient real orientation, while swapping the two complex coordinates preserves it.
Work in the smooth or piecewise-linear category; embedded spheres and disks are locally flat. A closed connected orientable three-manifold is an irreducible three-manifold when every embedded bounds an embedded three-ball. It is a prime three-manifold when forces or . A separating sphere gives such a connected sum after capping its two sides with balls. Irreducibility therefore implies primeness, but a prime manifold can still have a nonseparating sphere.
A geometrizable three-manifold is one whose prime summands, after sphere splitting and capping, can be cut along disjoint essential tori into pieces whose interiors admit complete geometric structures modeled on the eight Thurston geometries:Here a geometric structure is a locally homogeneous quotient structure modeled on the stated simply connected space. The original manifold need not itself carry one geometry before decomposition.
A Heegaard splitting is , where are handlebodies with their boundaries identified. Its genus is the common boundary genus. The Heegaard genus is the least possible genus of such a splitting. Thus “genus ” as a minimum requires both a genus- splitting and the nonexistence of one of smaller genus; an arbitrary genus- splitting only proves .
The sphere in is nonseparating: its complement is , which is connected. A sphere bounding a ball separates, so this product is not an irreducible three-manifold.
To show it is prime, suppose a separating sphere cuts it into compact pieces with one spherical boundary each. The Seifert-van Kampen theorem givesA free product of two nontrivial groups is nonabelian: choose nonidentity elements in the two factors; their products in the two orders are distinct reduced words. Hence one factor, say , is trivial. The inclusion of this simply connected compact piece lifts to the universal cover . The lift is an embedding: equality of lifted points would imply equality of their projections in . Its image is compact with boundary the lifted sphere.
Use the three-dimensional Schoenflies theorem: a locally flat embedded sphere in bounds a ball, and its compact side is that ball. The interior of is both open and closed in the corresponding complement component, and compactness rules out the unbounded component. Thus is the bounded ball, and itself is a ball. Capping gives , so every connected-sum decomposition is trivial. Therefore is prime but not irreducible.
Now let a prime closed connected orientable fail irreducibility. A sphere not bounding a ball cannot separate: if it did, primeness would make one capped side , and the three-dimensional Schoenflies theorem would make its uncapped side a ball. Thus there is a nonseparating sphere . Its two-sided neighborhood is . Since the complement is connected, join its two boundary spheres by an embedded arc in that complement and thicken the arc. The union is a punctured : the thickened arc joins the two ends of the sphere-cylinder, and the remaining boundary is one sphere. This is the nonseparating sphere gives a sphere-circle summand construction and yieldsThe product is not , since its fundamental group is . Primeness forces , soThe background results used are van Kampen, the explicit universal cover of the product, and the locally flat three-dimensional Schoenflies theorem; no Poincaré-conjecture argument is needed.
Let be the disjoint complete meridian-disk system of , and let be that of . The identification joins and into an embedded sphere in . Each disk is nonseparating in its handlebody: cutting along it leaves a genus-one handlebody, and cutting along the other then gives a ball. After cutting along , the two cut handlebodies are connected and are still joined along the complement of the common boundary circle. Hence is nonseparating.
Cap the two new sphere boundaries with balls. The resulting closed manifold inherits a genus-one Heegaard splitting: its two sides are the solid tori obtained by cutting the original handlebodies along their common disks. Their meridians are the surviving curves and . The hypothesis that avoids makes it descend to the compressed torus, and its single intersection with remains a single intersection there.
A genus-one splitting whose two meridians intersect once is . To see this directly, choose the target torus basis with its meridian. The other meridian is . A meridional Dehn twist, extending across the target solid torus, removes the integer , leaving the longitude. Gluing a second solid torus with meridian equal to that longitude is the standard splitting of into the neighborhoods of its two coordinate circles. Therefore .
By the common nonseparating disks in a Heegaard splitting construction and part (b), reversing the cut and caps givesThe product metric on is homogeneous, and quotienting by an integer translation in the second factor gives . Thus carries this Thurston geometry and is a geometrizable three-manifold.
There is a wording qualification: if “Heegaard genus two” means the minimum defined in part (a), the disk data contradict it. The product splits as on each hemisphere of , giving a genus-one splitting, while genus zero gives only , so . The genuine construction is a genus-two splitting of a genus-one manifold; the geometrizability conclusion remains valid. The proof used the complete disk systems, the common-sphere cut-and-cap construction, and the explicitly justified genus-one meridian-intersection criterion.
For tame or smooth embeddings , ambient isotopy means there is a continuous family , , of homeomorphisms, with and . Equivalently the map is a homeomorphism of preserving the time coordinate. In the smooth category one uses diffeomorphisms and a smooth isotopy. If only unparametrized images are compared, the last condition is ; for oriented knots it must also preserve the strand orientation.
A link is an embedding of a finite disjoint union of circles. Choose a point of outside it and identify the complement of that point with . A generic planar projection gives an immersion with only finitely many transverse double points, no triple points and no singularities of the projected strands. A link diagram is this planar immersed union together with the over/under information at each double point, recording which strand has the larger height. An oriented link diagram also records each component's orientation. The crossing data are indispensable: the planar immersion alone does not specify the link.
Write . Normalize the reduced Kauffman bracket by and . At a positive braid crossing choose the smoothing rule , where is the two parallel strands and joins the adjacent top endpoints and adjacent bottom endpoints. At its mirror crossing the coefficients are interchanged. This convention fixes the two smoothing labels. Equivalently, for a nonempty diagram,where each bracket smoothing state chooses one smoothing at each crossing, count the choices, and counts the resulting circles. It is a Laurent polynomial in and is independent of the order in which crossings are resolved.
We prove the local invariance needed for the Jones polynomial. In the Temperley-Lieb diagram algebra, stacking the smoothing tangles gives , and its reflected version. These identities follow just by following the planar strands; only the first removes an extra circle. The inverse crossing is , andThus the second Reidemeister move preserves the bracket. Expanding three crossings givesso the third Reidemeister move does too; inverse versions follow by multiplying by inverse crossings. A positive curl resolves to times the straight strand, and a negative curl gives . Thus the first move changes the bracket by the indicated factor.
Orient the diagram and let be its writhe, the sum of the signed crossings. DefineThe first move changes by or , exactly cancelling the bracket's curl factor. The other two moves leave writhe unchanged. Planar isotopy leaves both quantities unchanged. The Reidemeister theorem states that diagrams of ambient-isotopic tame oriented links are related by planar isotopy and these three local moves; therefore depends only on the oriented link.
This substitution really lies in . If there are crossings, each state exponent has parity , and also has parity . Expanding each power of adds only even exponents, so every exponent of the normalized bracket has parity . Every even power of is an integral power of . The normalization gives .
Use the standard closed three-strand braid , a four-crossing diagram of the figure-eight knot. The diagram has two positive and two negative crossings, so .
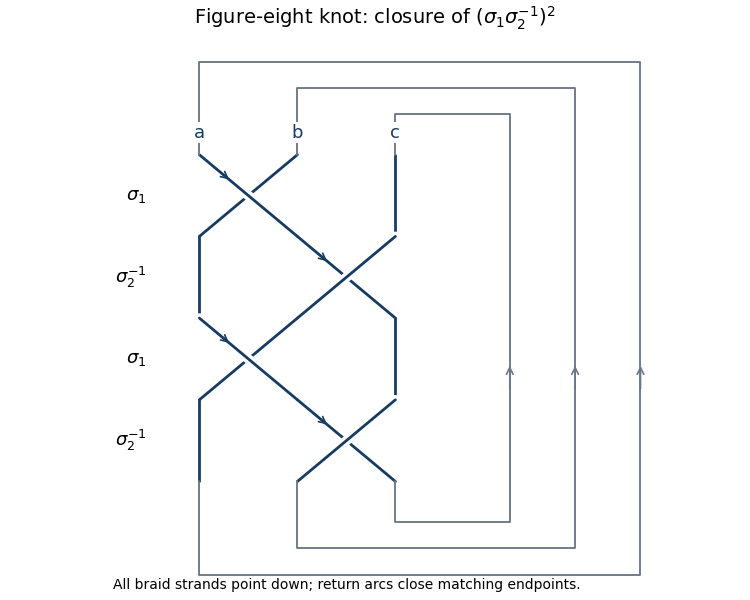
Four-crossing closed braid for the figure-eight knot, with three starting meridians
. Details. 
In the Temperley-Lieb diagram algebra on three strands put , . The relations are , , , . The bracket image of one two-crossing block isClosing planar diagrams gives the bracket trace on the three-strand Temperley-Lieb algebra:These values follow because the closures have respectively three, two and one circles. Expanding and reducing givesTaking its trace and substituting yieldsThere is no writhe correction, soThe equality is immediate from the five displayed coefficients. The same braid model supplies the meridians used in part (d).
Use the braid from part (c). Put meridians around its three strands at one end. At a positive crossing, the Wirtinger presentation relations induce the Artin automorphism of a braidFor the inverse crossing on strands two and three, they giveThe first formula is the usual crossing conjugation, and the second is its inverse on the relevant pair. Following one block gives :The four-crossing braid induces . Closing it identifies each ending meridian with its starting meridian. Applying the Seifert-van Kampen theorem to the crossing regions and the closing arcs therefore giveswhereBoth elementary crossing automorphisms preserve . Hence , and the first two closure relations imply the third: after substitution , so cancellation gives .
The first remaining relation can be solved without adding any relation:Substitute this expression into . Free cancellation and multiplying the two sides by inverse words giveThese are Tietze transformations, eliminating a generator defined by one relation and retaining the other. Thus the figure-eight knot group has the requested one-relator presentation
Choose an essential simple closed curve in the oriented topological surface and an annular neighborhood . A positive Dehn twist about is represented on this annulus bywhere is zero near , one near , and increases between them. Since a full turn is the identity on the boundary circle, this map is the identity near both boundary components of the annulus and extends by the identity outside it. It preserves orientation and turns one end relative to the other by one full turn. An inverse twist uses .
More intrinsically, is a Dehn twist if its mapping class is that of this annulus-supported homeomorphism, for some curve and the chosen handedness. Choices of annular coordinates and interpolation give isotopic maps. The genus hypothesis permits essential curves, but the definition also makes sense for boundary-parallel curves on surfaces with boundary.
The Lickorish-Dehn theorem says that every orientation-preserving homeomorphism of a compact connected orientable surface, fixing its boundary pointwise, is isotopic relative to the boundary to a finite product of Dehn twists and their inverses about simple closed curves. Boundary-parallel curves are permitted. For a closed surface of genus , a finite collection of curves suffices to generate its mapping class group. If boundary components are allowed to be permuted, twists alone do not express those permutations; the boundary condition is part of the precise statement.
The fundamental theorem of Dehn surgery asserts that every closed connected orientable three-manifold is integer surgery on a finite framed link in . To prove it, first choose a Heegaard splitting of of genus . Existence of such splittings is a standard background result: a triangulation, with spanning trees collapsed in its primal and dual one-skeletons, gives complementary regular neighborhoods of finite graphs, hence two handlebodies. Choose a standard genus- splitting of , formed by stabilizing its genus-zero splitting. Identify the two pairs of handlebodies. If is the sphere's gluing map and is the gluing map for , then is an orientation-preserving self-homeomorphism of the common surface. The Lickorish-Dehn theorem writes it, up to isotopy, as a product , .
Here is the local surgery mechanism. Place on an intermediate level of a product collar of the surface. Its tubular neighborhood has longitude given by that surface and meridian around the normal disk. Remove the neighborhood and fill with meridian slope . Cut the remaining annular neighborhood of along a transverse arc. Going around the new meridian now makes one extra positive or negative turn in the longitude direction. On gluing the cut annulus back, the two collar levels are therefore identified by , precisely the Dehn twist from part (a). Outside this annulus the identification is unchanged. This proves unit surface-framed surgery realizes a Dehn twist; its surgery coefficient is or relative to the surface framing, with sign fixed by the chosen normal convention.
Put the curves on distinct collar levels and order those levels to realize the indicated composition. They are disjoint as curves in the three-manifold even if their surface projections intersect. Performing the prescribed surgeries replaces by , up to isotopy. An isotopy of a gluing map extends across a collar, so the filled manifold is homeomorphic to .
Finally each surface framing differs from the preferred longitude framing in by an integer number of twists. Thus its coefficient becomes an integer coefficient in the usual knot longitude convention. These finitely many disjoint curves form the required framed link :The ingredients used were Heegaard-splitting existence, the stated twist-generation theorem, and the explicit local unit-surgery construction.
Each component is an unknot, so its closed exterior is a solid torus. Choose the usual boundary basis , where is a meridian of the component and its Seifert longitude. In the exterior's fundamental group, generates and is trivial, since it bounds a meridian disk of that exterior.
Every essential embedded circle on a torus represents a primitive homology class with . If it bounds a disk in the exterior, it is null-homotopic there, so . Primitivity then forces . Essential simple curves of the same primitive unoriented slope on a torus are isotopic: lift them to the plane and straighten their parallel primitive lines, or cut the torus along one curve to obtain an annulus. ConsequentlyThis is the preferred longitude of an unknot. The disk is only required to lie in the complement of its own solid torus; it may meet the other link component, so no additional disjoint-disk assertion is being used.
For the intended standard Hopf link, identify with the unit sphere in and its two components with the coordinate circles and . Outside small neighborhoods of those circles, both coordinates are nonzero, and their arguments together with giveOn this product the longitude of either component is the meridian of the other. Therefore the two attaching meridians become the two coordinate curves of , intersecting exactly once. Adding the product collar does not change a gluing of solid tori. The meridian-intersection-one argument in Question 2(c) identifies the result with the standard genus-one splitting of the sphere. Thus zero surgery on the Hopf link gives
There is a genuine link-type qualification in the wording: merely specifying two linked but individually unknotted components does not determine the Hopf link. For example the two components of the torus link are unknotted but have linking number . Filling their preferred longitudes is zero surgery with linking matrixso the resulting first homology is its cokernel, , rather than the zero group of . The cokernel formula follows because zero longitudes impose twice the other meridian as the homology relations. Thus the sphere answer applies to the standard once-linked Hopf interpretation; the literal unspecified link description alone is insufficient to force a single manifold.
A Kleinian group is a discrete subgroup of the orientation-preserving isometry group of , identified with . For an abstract finitely generated group this means a faithful representation into whose image is discrete; the chosen image is the geometric realization. Its boundary action is by Möbius transformations on .
Discreteness means the identity is isolated in the group topology, and for a subgroup it also excludes an infinite sequence of distinct elements converging anywhere in the isometry group. Torsion-freeness is not part of this definition: elliptic Möbius transformations of finite order are allowed. Therefore a Kleinian quotient need not be a smooth hyperbolic manifold.
Fix an interior point . The limit set of a Kleinian group is the set of boundary accumulation points of its orbit, orThe boundary compactification may be realized as the closed unit ball. A discrete isometry group has only finitely many orbit points in each compact interior region: isometries moving into a compact set form a compact family after accounting for the compact rotation stabilizer, and infinitely many distinct group elements there would contradict discreteness. The stabilizer of is finite for the same reason. Thus an infinite group has an infinite orbit escaping every compact interior set and a nonempty boundary accumulation set. A finite group has empty limit set. This also shows the displayed intersection does not introduce ordinary interior accumulation points.
For another point , the corresponding points satisfy . In the Poincaré ball model the distance identity isIf , bounded distance impliesSo as well. Exchanging proves equality of the two accumulation sets. Hence the definition is independent of the interior base point.
It is closed as an intersection of the compact orbit closure with the closed boundary, and it is -invariant because multiplying an orbit by an element of permutes that orbit. Changing ball coordinates or conjugating the geometric realization transports the set by the induced boundary homeomorphism. Different nonconjugate representations of an abstract group are not asserted to have the same subset of one fixed sphere. None of these arguments requires finite generation.
Let be nonempty, closed and -invariant. We first show it cannot be a singleton when is a non-elementary Kleinian group.
Suppose every element fixes one boundary point, conjugated to . Each boundary map then has the affine form . If all elements have , their action in upper half-space keeps the height of fixed. An orbit sequence escaping compact interior sets must have its horizontal coordinate tending to infinity along any convergent boundary subsequence, so its only possible boundary limit is . If some element has , move its second fixed point to , making it . For any , its conjugates are . Choose or so . If , these are distinct group elements converging to , contradicting discreteness. Thus for every group element: all fix both and , and their only possible interior-orbit boundary limits are these two points. In both cases the Kleinian limit set has at most two points. This contradicts non-elementarity. Therefore has at least two distinct points.
Use the Klein ball model, in which hyperbolic geodesics are straight chords, and take the closed Euclidean convex hull of in the closed ball. It contains an interior point , since the open chord between two distinct points of lies in the open ball. The interior part of this hull is hyperbolically convex and invariant under : isometries preserve geodesic segments, so they preserve the hyperbolic convex hull of the invariant set. Thus .
The only points of on the boundary sphere are the points of . Indeed, if , compactness of gives for every , because on the unit sphere only when . The same linear inequality holds throughout , excluding from it. Conversely , so .
Every boundary accumulation point of consequently lies in . Base-point independence from part (b) identifies that accumulation set with , proving minimality of the Kleinian limit set:This proves the stated containment for every nonempty closed invariant set, not merely for sets containing an arbitrarily chosen orbit on the boundary.
Write . As a subgroup of a discrete group, it is a Kleinian group, even if it is not finitely generated. Since it is infinite, part (b) gives a nonempty closed Kleinian limit set . For , conjugation and base-point independence giveOne can see this directly by applying to : the image is the orbit of under the conjugate subgroup, and the choice of interior point does not affect its limit set. Normality makes the conjugate subgroup equal to , so is -invariant. Applying part (c) yields .
Conversely , so every boundary accumulation point of the smaller orbit is one of the larger orbit: . Therefore the limit set of an infinite normal Kleinian subgroup satisfiesInfinitude supplies nonemptiness, normality supplies invariance, and non-elementarity supplies minimality. Properness of the subgroup is not needed, and no finite-generation assumption on it has been inserted.
Take as a subgroup of . It is discrete because representatives have integer entries, so a bounded set of matrices contains only finitely many such representatives, modulo the two choices of sign. It is finitely generated byThe Euclidean algorithm on the first column of an integer determinant-one matrix reduces it using these two transformations, proving the generation statement.
It is non-elementary. The powers of move an interior upper-half-space point towards , so . Conjugating by gives a parabolic with fixed point , and conjugating that parabolic by gives one with fixed point . Their interior orbits approach those respective points. Thus are three distinct points in the Kleinian limit set.
However in the projective group, and is a nonidentity elliptic Möbius transformation fixing the hyperbolic geodesic with boundary endpoints . It is a half-turn around that axis. Near an ordinary point of the axis, quotienting identifies the transverse angle modulo , giving cone angle instead of . The elliptic stabilizer obstruction to a hyperbolic manifold quotient therefore givesThe obstruction is the nonfree action, not finite generation or elementary behavior. An underlying topological quotient can still be a manifold; the conical quotient metric is what prevents this example from being a hyperbolic manifold quotient.
Articles by others on the same topic
There are currently no matching articles.