Let be the centre displacement and the small disk rotation. Put . The moment of inertia of a uniform disc is , obtained from and . Thus the kinetic energy is .
For one spring, let point radially towards its fixed anchor and let be the perpendicular unit vector. The moving attachment is , while the anchor is . Expanding their separation to second order gives the spring extension beyond natural length:Insert this in the elastic potential energy . For the three symmetric directions, and . Dropping the constant equilibrium energy givesTherefore the quadratic Lagrangian isThe prestretch terms cannot be omitted: they supply transverse spring stiffness and the entire rotational restoring torque, as derived generally in small oscillations of a disk attached to prestretched radial springs.
The quadratic Lagrangian is diagonal in , so the Euler-Lagrange equations give two pure translations and one pure rotation. Their angular frequencies areA horizontal translation has ; a vertical translation has ; and the rotational mode has . Any fixed-direction translation is another choice in the same two-dimensional degenerate normal mode space. The rotation keeps the centre fixed.
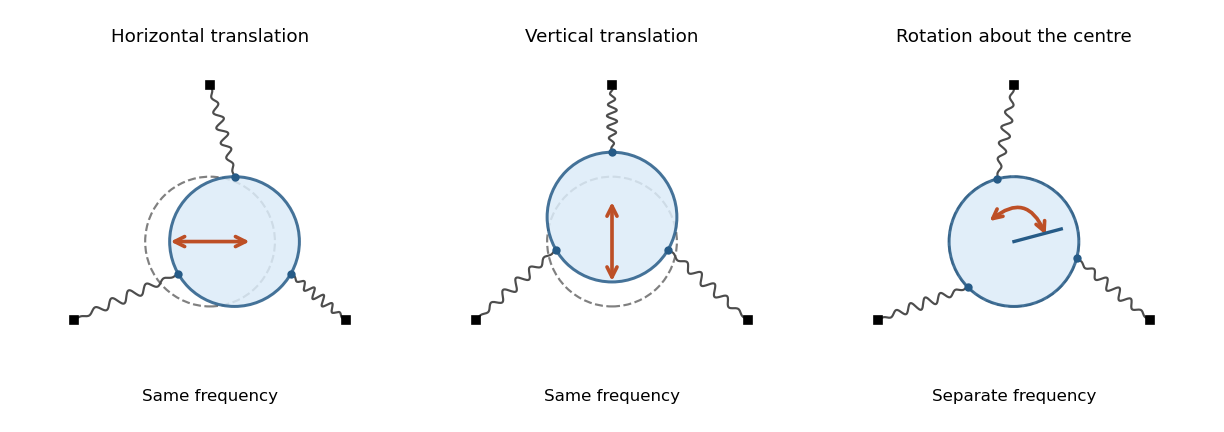

The disk still has only three degrees of freedom and hence three normal modes: two centre coordinates and one in-plane rotation. Five springs alter the restoring quadratic form but add no disk coordinates. The fivefold rotational symmetry makes the translational stiffness proportional to the two-dimensional identity matrix, and makes translation-rotation coupling vanish. Therefore the two translation modes are always degenerate; the rotational mode is separate, with possible accidental equality of its frequency for particular parameters. The general formulas in small oscillations of a disk attached to prestretched radial springs apply with .
Articles by others on the same topic
There are currently no matching articles.