Kinetic energy is the energy associated with motion. For a nonrelativistic point mass of mass m>0, measured in a specified inertial frame,Here v is velocity and v is speed; T is another common symbol for kinetic energy. The dot product makes K nonnegative regardless of the direction of velocity. At fixed mass, doubling speed quadruples kinetic energy: a 2kg point mass at 2m/s has 4J, whereas at 4m/s it has 16J. The SI units are kgm2/s2=J. Different reference frames can assign different velocities and therefore different kinetic energies. [ref]
K=21mv⋅v=21mv2,v=∣v∣.
A short outline explains why kinetic energy has this formula. In a nonrelativistic inertial frame, constant mass and Newton's second law give, using the chain rule,Integrating over time proves the work-energy theorem, Wnet=Kf−Ki. The net force is the sum of all forces, and Wnet is their total work, not merely the work of a chosen driving force. This route to final speed is useful when the forces as functions of position are known but the full motion as a function of time would be harder to find. [ref]
dtdK=mv⋅dtdv=Fnet⋅v.
In the running example, a 2kg point mass starts at rest and receives a constant net 3N force through 4m. Its net work is 12J, soAt any intermediate distance x≥0, K(x)=(3N)x and v(x)=2Fx/m: kinetic energy is a linear function of distance, while speed is proportional to the square root of distance. If a net opposing 3N braking force subsequently acts for 4m, it does −12J of work and brings this point mass to rest. Negative net work decreases kinetic energy; it does not make kinetic energy negative. Beyond the stopping point the motion must be reconsidered, since the point mass cannot keep moving forward with a negative K.
Kf=12J,vf=m2Kf=12m/s≈3.4641m/s.
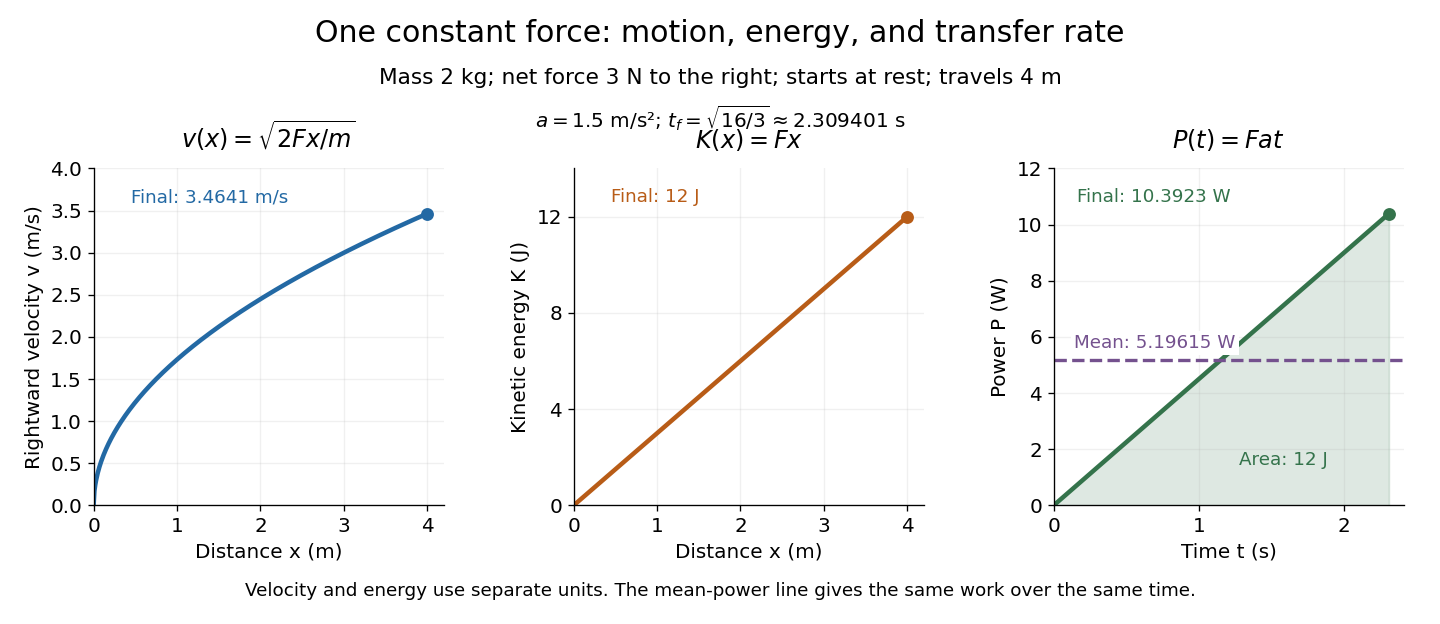
Kinetic energy also makes the exchange with potential energy intuitive: a falling body's loss of gravitational potential energy can appear as increased kinetic energy. The formula above applies when speed is small compared with the speed of light; at higher speeds, special relativity changes the expression. [ref]
Kinetic energy per unit mass. For an acceleration field a, its change along an actual trajectory is Δ(∣v∣2/2)=∫a⋅dr, by the chain rule. This differs by a mass factor from the work integral of a physical force.
For unidirectional flow through area A with mean speed u, the outgoing kinetic-energy flux is 21ρAαu3, where α=(Au3)−1∫Au3dA. Cubing the mean speed generally differs from averaging the cube. A uniform profile has α=1; circular laminar Hagen-Poiseuille flow has α=2.
For a free particle of rest mass m, subtract its rest energy mc2 from its total energy γmc2, where γ is the Lorentz factor. The low-speed binomial series gives K=mv2/2+3mv4/(8c2)+O(mv6/c4), recovering classical kinetic energy.
For rotational motion about a fixed axis, let r be cylindrical radius, v the signed tangential velocity, and dm the mass measure. Define the kinetic energy, axial angular momentum, and moment of inertia byThe Cauchy-Schwarz inequality gives L2≤(∫v2dm)(∫r2dm)=2KI. More precisely, direct expansion gives the nonnegative energy gapThus the minimum at fixed L and fixed mass distribution occurs exactly when v=(L/I)r almost everywhere with respect to dm. This means constant angular velocity Ω=L/I, or solid-body rotation. If the profile is continuous, the equality holds at every point in the mass support.
K=21∫v2dm,L=∫rvdm,I=∫r2dm>0.
K−2IL2=21∫(v−ILr)2dm.
For a uniform unit-density cylinder of radius a, height h, and volume V=πa2h, the moment of inertia is I=Va2/2. Therefore K≥L2/(Va2), with equality for ω(r)=2L/(Va2). Multiplying by a uniform nonunit density changes the mass measure and I consistently.
Writing particle positions relative to the center of mass as ρi=ri−R makes ∑imiρi=0, so the cross term in the squared velocities vanishes. The total kinetic energy splits into center-of-mass translation and relative motion as displayed. For a rigid body, the latter is 21Iω2, where I is the moment of inertia about the instantaneous rotation axis through the center of mass.
For a twice differentiable position away from the origin, write r=ru with radial unit vector u. Its unit-length constraint gives u⋅u˙=0 and u⋅u¨=−∣u˙∣2, separating radial and directional contributions to speed and kinetic energy. The identity is kinematic and does not require a particular force law.
The kinetic energy density of a continuum with mass density ρ and velocity v is ρ∣v∣2/2. For a displacement field, the material velocity is its time derivative.
Rotational kinetic energy is the kinetic energy of a rigid body's rotation. For pure rotation about an axis fixed in an inertial frame,Here r⊥ is the perpendicular distance of a mass element dm from that axis, I is the moment of inertia about that same axis, and ω is the common angular speed, measured in radians per second. The rigid body assumption fixes the relative positions of the mass elements; they share angular velocity but have different speeds v=ωr⊥. Summing their kinetic energies dmv2/2 gives the formula. This is a nonrelativistic model; deformation or internal motion can contribute additional kinetic energy.[ref]
Krot=21Iω2,I=∫r⊥2dm,ω=∣ω∣.
For a computed example, take a uniform disc and an ideal thin ring, each of mass M=2kg and radius R=0.30m, rotating about its central perpendicular axis at angular speed 10rad/s. The moment of inertia of a uniform disc is MR2/2=0.090kgm2, while the ring has moment of inertia MR2=0.180kgm2. Their rotational kinetic energies are therefore 4.5J and 9.0J. The ring stores twice the energy at the same angular speed, because more mass lies farther from the axis. At the same nonzero rotational kinetic energy, its angular speed would instead be 1/2 times the disc's. This makes radial placement useful for storing energy in a rotating wheel, although a real design must also withstand the stresses of rotation.
For fixed-axis rotation with constant moment of inertia, write the signed rotation rate as Ω=θ˙, with angle θ in radians. The axial component of net external torque obeys τaxis=IΩ˙, so the work-energy theorem becomesAn opposing torque removes rotational kinetic energy; bearing friction must be included in the net torque. The signed Ω matters when the direction reverses. Rotation about a fixed axis need not be about a principal axis: the scalar energy formula still holds, but transverse bearing torques can be needed to maintain that axis.
dtdKrot=τaxisΩ,ΔKrot=∫τaxisdθ.
For general rigid body motion, use the inertia tensor IG about the centre of mass G:This is the kinetic-energy decomposition about the centre of mass. In a principal body frame, the rotational term is 21(I1ω12+I2ω22+I3ω32), using the principal moments of inertia. Away from a principal axis, angular momentum and angular velocity need not be parallel. A freely rotating asymmetric rigid body can change the direction of angular velocity relative to the body even while rotational kinetic energy remains constant; Euler equations for a torque-free rigid body govern that motion. One constant axial moment of inertia is then insufficient.[ref]
Ktotal=21M∣VG∣2+21ωTIGω,LG=IGω.
Ancestors (5)
Incoming links (959)
- Accretion-disk boundary layer
- Accretion-disk stream-impact hot spot
- Activation energy
- Adhesive collision of two equal discs
- Adiabatic process
- Adiabatic vertical modes of a Gaussian atmosphere
- Alfvén wave energy transport
- Anderson positron track experiment
- Angular momentum and the escape energy threshold
- Astrophysical jet
- Astrophysical S factor
- Atomic and nuclear beta-decay energy conventions
- Attosecond streaking
- Auger electron
- Baroclinic energy ratio and deformation scale
- Beam cooling
- Bernoulli's principle
- BGK model
- Bond-dissociation enthalpy
- Bothe-Geiger coincidence experiment
- Boundary integral for kinetic energy of planar potential flow
- Boundary-pressure correction to the virial theorem
- Boundary work and mean-flow energy of an internal wave
- Boyle's law
- Bubble-chamber track readout
- Buoyancy exchange time of a cold-air enclosure
- Burger number
- Calorimetry
- Cathode-ray attenuation with finite detector acceptance
- Center-of-mass coordinates
- Chadwick neutron discovery experiment
- Chain sliding over a table edge
- Characteristic X-ray
- Charged sheet between grounded parallel plates
- Charge-sign ambiguity of a curved track
- Cherenkov mass inference
- Circular-orbit derivation of the Bohr model
- Classically allowed region
- Classically forbidden region
- Classical mechanics
- Cluster velocity-dispersion mass estimate
- Cockcroft-Walton lithium disintegration experiment
- Cockcroft-Walton multiplier model
- Collisional de-excitation
- Collision contact geometry is not determined by incoming velocities
- Collision stopping power
- Compound Atwood machine
- Compton scattering
- Compton wavelength
- Conservation of angular momentum
- Conservative energy flux of a polytropic ideal gas
- Constant-area capture of stationary dust
- Coriolis force does no work
- Coulomb head-on closest approach with target recoil
- Coulomb potential energy
- Coulomb radial origin condition
- Critical-layer regularity of a neutral Hazel mode
- Cumulative mixing efficiency
- Cyclotron dee
- Cyclotron energy and orbit radius
- Cyclotron gap energy gain
- Damping
- Diatomic bond stretch
- Dissipation range
- Doppler cooling limit
- Double-exchange mechanism
- Double pendulum Lagrangian
- Dulong-Petit law
- Dynamic pressure
- Eccentric circular-hole disk inertia
- Eccentric wheel with missing-mass kinetic energy neglected
- Effective mass of a rolling rigid body
- Effusive cooling
- Effusive molecular energy flux
- Einstein photoelectric equation
- Elastic collision
- Elastic eccentric impact of a thin disc
- Elastic rough-sphere bounce
- Electric potential
- Electric potential difference
- Electron accelerating-voltage wavelength
- Electron analyser pass energy
- Electron analyser retard ratio
- Electron energy analyzer
- Electron-induced pair-production threshold
- Electron microscope resolution
- Electron optics
- Electron spectrometer
- Electron stopping power
- Electrostatic acceleration energy gain
- Electrostatic accelerator
- Elsässer energy invariant
- Emulsion range measurement
- Energy balance of the incompressible vertical-shear model
- Energy cascade
- Energy decay of a viscously damped harmonic oscillator
- Energy dissipation of a damped pendulum
- Energy fluxes of a strong adiabatic shock
- Energy in a rectangular membrane mode
- Energy of a deep-water standing gravity wave
- Energy-preserving change of rolling radius
- Energy transfer after an impulse in two weakly coupled oscillators
- Enthalpy
- Equal-angle relativistic elastic scattering
- Equal-speed elastic impact on a free rod
- Equal string-mode energies with inverse-mode-number amplitudes
- Escape-energy balance diagram
- Escape speed, circular speed, and propulsion
- Escape velocity
- Exciton optical transition
- Fermi energy
- Fermi energy of a model electron gas
- Fermi sea
- Finite-energy condition for planar exterior potential flow
- Finite-time collision in an inverse-cube central force
- First law of thermodynamics
- Fixed-angular-momentum energy test for principal-axis rotation
- Fixed-energy initial-condition optimality
- Fixed-energy turbulent mixed layer
- Fixed-target antiproton production threshold
- Franck-Hertz energy-loss model
- Franck-Hertz experiment
- Franck-Hertz repeated-loss collection model
- Franck-Hertz retarding collector transfer
- Franck-Hertz spacing fit and contact offset
- Free expansion
- Free particle in rotating coordinates
- Frictional conversion of spin to rolling
- Frictional heating
- Galilean boost energy of an interacting gas
- Galilean invariance of collision elasticity
- Gaussian variational energy for the harmonic oscillator
- Generalized coordinate
- Geostrophic adjustment of a surface-height jump
- Grain photoelectric heating
- Ground state
- Ground-state energy
- Harmonic-oscillator number-state second moments
- Healing length
- Heat
- Heat capacity
- Heat capacity ratio
- Heat engine
- Heating and Cooling of HII regions by Ian Czekala
- Heisenberg uncertainty relation
- Hess's law calorimetry experiment
- High harmonic generation
- High-speed charge and isotope scaling of electronic stopping
- Horizontal-coordinate mass matrix of an unequal-mass double pendulum
- Hydrogen ground-state probability beyond the classical turning point
- Ideal gas
- Impulsive disruption by stellar mass loss
- Inelastic collision
- Inelastic scattering
- Inertia tensor
- Infinite square well
- Instantaneous power
- Internal energy
- Internal energy and system boundaries
- Internal energy of an ideal gas
- Invariant-mass selection of bubble-chamber events
- Inverse photoemission spectroscopy
- Inverse-square potential
- Isolated system
- Isothermal-galaxy momentum-balance shell threshold
- Isothermal process
- Isothermal shearing-sheet energy conservation
- Jacobi coordinates
- Joule's paddle-wheel experiment
- Joule-Thomson effect
- Kinetic energy
- Kinetic energy conservation
- Kinetic energy decomposition about the center of mass
- Kinetic-energy decomposition about the centre of mass
- Kinetic-energy estimate from wavefunction nodes
- Kinetic-energy inner product
- Kinetic energy released by relativistic decay
- Kinetic friction
- Kolmogorov four-fifths law
- Laboratory evidence for the Hoyle state
- Lagrangian internal energy balance
- Laser cooling
- Latent heat of fusion
- Lawrence-Livingston cyclotron experiment
- Leaking bucket under constant tension
- Lenard cathode-ray window experiment
- Linear drag
- Linearized free-surface boundary conditions
- Linear particle accelerator
- Liquefaction enthalpy budget
- Liquefaction yield with separate warm-gas and liquid outlets
- Lithium proton reaction energy
- Lithium reaction laboratory recoil
- Lorentz force
- Lossless two-channel thickness scattering model
- Lowest Landau level
- Magnetic forces do no work
- Magnetic relaxation
- Magnetic rigidity
- Maser microwave energy budget
- Mass and range of a nuclear exchange field
- Mass-loading power at fixed velocity
- Mass-radius scaling of confinement energy
- Mass spectrometry
- Mass threshold after photon absorption
- Matter
- Maximum elastic recoil energy fraction
- Maxwell-Boltzmann distribution
- Maxwell molecule collision operator
- Maxwell speed distribution
- Mean-field alignment equation
- Mechanical energy
- Mechanical mass matrix
- Midpoint-plucked fixed-end string
- Modal energy of a string
- Moment of inertia of a uniform solid sphere
- Momentum
- Momentum-bin Kurie ordinate
- Momentum conservation
- Most probable speed in the Maxwell distribution
- Muon-neutrino electron recoil spectrum
- Neutrino-electron elastic scattering
- Neutron
- Neutron detection by proton recoil
- Neutron moderation
- Neutron scattering
- Neutron scattering kinematics
- Newtonian gravitational potential
- Newtonian potential of a point mass
- Nonlinear Boltzmann collision operator
- Nonrelativistic particle
- Normal mode
- Normal-mode energy exchange
- Normal-mode impulse projection
- Normal modes of an equilateral spring triangle
- Normal modes of a rigid beam on two end springs
- Normal modes of three beads connected by springs on a circular hoop
- Normal modes of three masses connected by two equal springs
- Nuclear radius bound from a Coulomb turning point
- Nuclear reaction Q-value
- Nuclear recoil
- Nuclear-recoil kinematics of WIMP scattering
- One-body coherence of a Hartree condensate
- Ornstein-Uhlenbeck moment equations
- Orthogonality of trigonometric functions
- Oscillator energy dissipation
- Oscillator ground-state density in a comparison wavelength
- Outgoing analytic branch of Klein-Gordon step momentum
- Paddle-wheel calorimetry energy balance
- Parabolic variational trial for a particle in a box
- Parallel current sheets with a resistive termination
- Particle accelerator
- Particle on a cone coupled to a hanging mass
- Particle range
- Past exam of the advanced fluid dynamics course of the University of Oxford / 2024 / 2 / a / Solution
- Past exam of the advanced Quantum Condensed Matter Physics course of the University of Cambridge / 2015 / Paper 1 / 1 / a / Solution
- Past exam of the advanced Quantum Condensed Matter Physics course of the University of Cambridge / 2015 / Paper 1 / 1 / b / Solution
- Past exam of the advanced Quantum Condensed Matter Physics course of the University of Cambridge / 2015 / Paper 1 / 1 / c / Solution
- Past exam of the advanced Quantum Condensed Matter Physics course of the University of Cambridge / 2015 / Paper 1 / 1 / Solution
- Past exam of the advanced quantum physics course of the University of Cambridge / 2015 / Paper 1 / 1 / b / Solution
- Past exam of the advanced quantum physics course of the University of Cambridge / 2016 / Paper 1 / 3 / Solution
- Past exam of the advanced quantum physics course of the University of Cambridge / 2019 / Section B / 4 / Solution
- Past exam of the advanced quantum physics course of the University of Cambridge / 2019 / Section B / 6 / Solution
- Past exam of the advanced quantum theory: path integrals and many-particle physics course of the University of Oxford / 2024 / 1 / a / Solution
- Past exam of the advanced quantum theory: path integrals and many-particle physics course of the University of Oxford / 2024 / 2 / e / Solution
- Past exam of the astrophysical fluid dynamics course of the University of Cambridge / 2012 / Paper 1 / 2 / c / Solution
- Past exam of the astrophysical fluid dynamics course of the University of Cambridge / 2012 / Paper 1 / 3 / Solution
- Past exam of the astrophysical fluid dynamics course of the University of Cambridge / 2013 / Paper 1 / 2 / a / Solution
- Past exam of the astrophysical fluid dynamics course of the University of Cambridge / 2013 / Paper 1 / 2 / c / Solution
- Past exam of the astrophysical fluid dynamics course of the University of Cambridge / 2014 / Paper 1 / 1 / b / Solution
- Past exam of the astrophysical fluid dynamics course of the University of Cambridge / 2015 / Paper 1 / 4 / a / Solution
- Past exam of the astrophysical fluid dynamics course of the University of Cambridge / 2016 / Paper 1 / 1 / c / Solution
- Past exam of the astrophysical fluid dynamics course of the University of Cambridge / 2016 / Paper 1 / 2 / a / Solution
- Past exam of the astrophysical fluid dynamics course of the University of Cambridge / 2016 / Paper 1 / 3 / c / Solution
- Past exam of the astrophysical fluid dynamics course of the University of Cambridge / 2016 / Paper 1 / 4 / b / Solution
- Past exam of the astrophysical fluid dynamics course of the University of Cambridge / 2017 / 3 / b / Solution
- Past exam of the astrophysical fluid dynamics course of the University of Cambridge / 2022 / Section B / 5 / a / Solution
- Past exam of the astrophysics course of the University of Oxford / 2018 / 1 / a / Solution
- Past exam of the astrophysics course of the University of Oxford / 2018 / 6 / b / Solution
- Past exam of the astrophysics course of the University of Oxford / 2022 / 2 / b / Solution
- Past exam of the astrophysics course of the University of Oxford / 2022 / 4 / a / Solution
- Past exam of the atomic and laser physics course of the University of Oxford / 2021 / 1 / c / Solution
- Past exam of the atomic and Optical Physics course of the University of Cambridge / 2012 / Paper 1 / 1 / Solution
- Past exam of the atomic and Optical Physics course of the University of Cambridge / 2012 / Paper 1 / 3 / a / Solution
- Past exam of the atomic and Optical Physics course of the University of Cambridge / 2013 / Paper 1 / 1 / Solution
- Past exam of the atomic and Optical Physics course of the University of Cambridge / 2014 / Paper 1 / 3 / b / Solution
- Past exam of the atomic and Optical Physics course of the University of Cambridge / 2016 / Paper 1 / 2 / b / Solution
- Past exam of the atomic and Optical Physics course of the University of Cambridge / 2016 / Paper 1 / 3 / Solution
- Past exam of the chemistry A course of the University of Cambridge / 2021 / Paper 1 / A2 / c / iv / Solution
- Past exam of the chemistry A course of the University of Cambridge / 2023 / Paper 1 / A2 / b / iii / Solution
- Past exam of the chemistry A course of the University of Cambridge / 2023 / Paper 1 / A2 / b / i / Solution
- Past exam of the chemistry A course of the University of Cambridge / 2025 / Paper 1 / A1 / a / i / Solution
- Past exam of the chemistry course of the year 3 of the natural sciences course of the University of Cambridge / 2022 / Paper 2B / Section A / 25 / a / Solution
- Past exam of the chemistry course of the year 3 of the natural sciences course of the University of Cambridge / 2022 / Paper 2B / Section A / 26 / a / Solution
- Past exam of the chemistry course of the year 3 of the natural sciences course of the University of Cambridge / 2022 / Paper 3 / 49 / c / ii / Solution
- Past exam of the chemistry course of the year 4 of the natural sciences course of the University of Cambridge / 2022 / Paper 3 / Section B / 38 / c / Solution
- Past exam of the chemistry course of the year 4 of the natural sciences course of the University of Cambridge / 2022 / Paper 3 / Section B / 38 / d / Solution
- Past exam of the classical mechanics course of Part B of the physics course of the University of Oxford / 2016 / 1 / c / Solution
- Past exam of the classical mechanics course of Part B of the physics course of the University of Oxford / 2016 / 1 / d / Solution
- Past exam of the classical mechanics course of Part B of the physics course of the University of Oxford / 2016 / 3 / d / Solution
- Past exam of the classical mechanics course of the University of Oxford / 2023 / 1 / c / Solution
- Past exam of the condensed matter physics course of the University of Oxford / 2012 / 3 / b / Solution
- Past exam of the condensed matter physics course of the University of Oxford / 2013 / 2 / c / Solution
- Past exam of the condensed matter physics course of the University of Oxford / 2016 / 2 / a / Solution
- Past exam of the condensed matter physics course of the University of Oxford / 2021 / 1 / b / Solution
- Past exam of the condensed matter physics course of the University of Oxford / 2021 / 3 / a / Solution
- Past exam of the condensed matter physics course of the University of Oxford / 2022 / 2 / a / i / Solution
- Past exam of the condensed matter physics major option course of the University of Oxford / 2015 / 2 / a / Solution
- Past exam of the condensed matter physics major option course of the University of Oxford / 2018 / 2 / d / Solution
- Past exam of the field theories and collective phenomena in condensed matter course of the University of Oxford / 2025 / 1 / a / Solution
- Past exam of the flows, fluctuations and complexity and symmetry and relativity paper of Part B of the physics course of the University of Oxford / 2011 / 1 / 1 / Solution
- Past exam of the fluids and waves course of the University of Oxford / 2014 / 1 / c / Solution
- Past exam of the fluids and waves course of the University of Oxford / 2014 / 1 / d / Solution
- Past exam of the formation of Structure in the Universe course of the University of Cambridge / 2012 / Paper 1 / 3 / Solution
- Past exam of the formation of Structure in the Universe course of the University of Cambridge / 2014 / Paper 1 / 3 / a / Solution
- Past exam of the formation of Structure in the Universe course of the University of Cambridge / 2016 / Paper 1 / 1 / c / Solution
- Past exam of the frontiers of experimental condensed matter physics course of the University of Cambridge / 2013 / Paper 1 / 2 / b / Solution
- Past exam of the general relativity and cosmology course of the University of Oxford / 2013 / 4 / a / Solution
- Past exam of the general relativity course of the University of Oxford / 2021 / 4 / c / Solution
- Past exam of the geophysical fluid dynamics course of the University of Oxford / 2023 / 1 / a / Solution
- Past exam of the kinetic theory course of the University of Oxford / 2023 / 1 / a / Solution
- Past exam of the kinetic theory course of the University of Oxford / 2023 / 1 / d / Solution
- Past exam of the kinetic theory course of the University of Oxford / 2024 / 2 / c / Solution
- Past exam of the kinetic theory course of the University of Oxford / 2024 / 2 / e / Solution
- Past exam of the kinetic theory course of the University of Oxford / 2025 / 1 / a / Solution
- Past exam of the kinetic theory course of the University of Oxford / 2025 / 1 / b / Solution
- Past exam of the kinetic theory course of the University of Oxford / 2025 / 1 / d / Solution
- Past exam of the mathematical methods I course of the University of Oxford / 2017 resit / 7 / a / Solution
- Past exam of the mathematical methods II course of the University of Oxford / 2013 / 8 / b / Solution
- Past exam of the mathematical methods II course of the University of Oxford / 2013 resit / 10 / c / Solution
- Past exam of the mathematical methods II course of the University of Oxford / 2013 resit / 3 / b / Solution
- Past exam of the mathematical methods II course of the University of Oxford / 2014 / 12 / d / Solution
- Past exam of the mathematical methods II course of the University of Oxford / 2014 resit / 10 / a / Solution
- Past exam of the mathematical methods II course of the University of Oxford / 2014 resit / 8 / b / Solution
- Past exam of the mathematical methods II course of the University of Oxford / 2014 resit / 8 / c / Solution
- Past exam of the mathematical methods II course of the University of Oxford / 2015 resit / 11 / d / Solution
- Past exam of the mathematical methods II course of the University of Oxford / 2016 / 11 / e / Solution
- Past exam of the mathematical methods II course of the University of Oxford / 2017 / 10 / Solution
- Past exam of the mathematical methods II course of the University of Oxford / 2018 / 10 / a / Solution
- Past exam of the mathematical methods II course of the University of Oxford / 2021 / 7 / iv / b / Solution
- Past exam of the mathematical methods II course of the University of Oxford / 2021 resit / 10 / b / Solution
- Past exam of the mathematical methods II course of the University of Oxford / 2021 resit / 10 / c / Solution
- Past exam of the mathematical methods II course of the University of Oxford / 2021 resit / 11 / a / Solution
- Past exam of the mathematical physics course of the University of Oxford / 2007 / A / 1 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2001 / ia / Paper 4 / 12A / Solution
- Past exam of the mathematics course of the University of Cambridge / 2001 / ia / Paper 4 / 4A / Solution
- Past exam of the mathematics course of the University of Cambridge / 2001 / iii / Paper 35 / 2 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2001 / iii / Paper 35 / 4 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2001 / iii / Paper 36 / 3 / b / Solution
- Past exam of the mathematics course of the University of Cambridge / 2001 / iii / Paper 36 / 3 / c / Solution
- Past exam of the mathematics course of the University of Cambridge / 2001 / iii / Paper 45 / 1 / i / Solution
- Past exam of the mathematics course of the University of Cambridge / 2002 / ia / Paper 4 / 12E / Solution
- Past exam of the mathematics course of the University of Cambridge / 2002 / ib / Paper 1 / 15C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2002 / iii / Paper 71 / 4 / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2003 / ia / Paper 4 / 10E / Solution
- Past exam of the mathematics course of the University of Cambridge / 2003 / ia / Paper 4 / 9E / Solution
- Past exam of the mathematics course of the University of Cambridge / 2003 / iii / Paper 55 / 4 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2004 / ia / Paper 4 / 11A / Solution
- Past exam of the mathematics course of the University of Cambridge / 2004 / ia / Paper 4 / 12A / Solution
- Past exam of the mathematics course of the University of Cambridge / 2004 / ib / Paper 3 / 21C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2004 / ib / Paper 3 / 9D / Solution
- Past exam of the mathematics course of the University of Cambridge / 2004 / iii / Paper 64 / 2 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2004 / iii / Paper 64 / 3 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2004 / iii / Paper 67 / 2 / c / Solution
- Past exam of the mathematics course of the University of Cambridge / 2004 / iii / Paper 73 / 1 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2005 / ia / Paper 4 / 10C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2005 / ia / Paper 4 / 11C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2005 / ia / Paper 4 / 12C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2005 / ib / Paper 1 / 17E / Solution
- Past exam of the mathematics course of the University of Cambridge / 2005 / ib / Paper 1 / 4G / Solution
- Past exam of the mathematics course of the University of Cambridge / 2005 / iii / Paper 61 / 3 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2005 / iii / Paper 70 / 2 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2005 / iii / Paper 73 / 2 / v / Solution
- Past exam of the mathematics course of the University of Cambridge / 2005 / iii / Paper 78 / 3 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2005 / ii / Paper 2 / 33B / Solution
- Past exam of the mathematics course of the University of Cambridge / 2005 / ii / Paper 2 / 9C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2005 / ii / Paper 4 / 34D / Solution
- Past exam of the mathematics course of the University of Cambridge / 2005 / ii / Paper 4 / 37E / Solution
- Past exam of the mathematics course of the University of Cambridge / 2006 / ia / Paper 4 / 11C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2006 / ib / Paper 1 / 4B / Solution
- Past exam of the mathematics course of the University of Cambridge / 2006 / iii / Paper 62 / 2 / b / Solution
- Past exam of the mathematics course of the University of Cambridge / 2006 / iii / Paper 62 / 2 / d / Solution
- Past exam of the mathematics course of the University of Cambridge / 2006 / iii / Paper 73 / 2 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2006 / iii / Paper 73 / 3 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2006 / iii / Paper 76 / 2 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2006 / iii / Paper 79 / 3 / i / Solution
- Past exam of the mathematics course of the University of Cambridge / 2006 / ii / Paper 2 / 9C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2007 / ia / Paper 4 / 10C / i / Solution
- Past exam of the mathematics course of the University of Cambridge / 2007 / ia / Paper 4 / 12C / iv / Solution
- Past exam of the mathematics course of the University of Cambridge / 2007 / ib / Paper 3 / 18D / Solution
- Past exam of the mathematics course of the University of Cambridge / 2007 / ib / Paper 4 / 18D / Solution
- Past exam of the mathematics course of the University of Cambridge / 2007 / iii / Paper 65 / 1 / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2007 / iii / Paper 65 / 1 / d / Solution
- Past exam of the mathematics course of the University of Cambridge / 2007 / iii / Paper 65 / 3 / b / Solution
- Past exam of the mathematics course of the University of Cambridge / 2007 / iii / Paper 76 / 4 / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2007 / iii / Paper 81 / 1 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2007 / iii / Paper 84 / 3 / ii / Solution
- Past exam of the mathematics course of the University of Cambridge / 2007 / iii / Paper 84 / 3 / i / Solution
- Past exam of the mathematics course of the University of Cambridge / 2007 / ii / Paper 2 / 9C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2008 / ia / Paper 4 / 12B / Solution
- Past exam of the mathematics course of the University of Cambridge / 2008 / ib / Paper 2 / 17B / iv / Solution
- Past exam of the mathematics course of the University of Cambridge / 2008 / iii / Paper 59 / 3 / ii / Solution
- Past exam of the mathematics course of the University of Cambridge / 2008 / iii / Paper 81 / 1 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2008 / iii / Paper 84 / 5 / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2009 / ia / Paper 4 / 10A / b / Solution
- Past exam of the mathematics course of the University of Cambridge / 2009 / ia / Paper 4 / 11A / Solution
- Past exam of the mathematics course of the University of Cambridge / 2009 / ia / Paper 4 / 12A / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2009 / iii / Paper 62 / 3 / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2009 / iii / Paper 64 / 4 / b / Solution
- Past exam of the mathematics course of the University of Cambridge / 2009 / iii / Paper 64 / 4 / c / Solution
- Past exam of the mathematics course of the University of Cambridge / 2009 / iii / Paper 65 / 3 / v / Solution
- Past exam of the mathematics course of the University of Cambridge / 2009 / iii / Paper 68 / 1 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2009 / iii / Paper 79 / 4 / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2009 / ii / Paper 4 / 34D / ii / Solution
- Past exam of the mathematics course of the University of Cambridge / 2010 / ia / Paper 4 / 10B / Solution
- Past exam of the mathematics course of the University of Cambridge / 2010 / ia / Paper 4 / 9B / Solution
- Past exam of the mathematics course of the University of Cambridge / 2010 / iii / Paper 60 / 3 / iv / Solution
- Past exam of the mathematics course of the University of Cambridge / 2010 / iii / Paper 65 / 4 / c / Solution
- Past exam of the mathematics course of the University of Cambridge / 2010 / iii / Paper 65 / 4 / d / Solution
- Past exam of the mathematics course of the University of Cambridge / 2010 / ii / Paper 1 / 15D / Solution
- Past exam of the mathematics course of the University of Cambridge / 2010 / ii / Paper 1 / 34B / Solution
- Past exam of the mathematics course of the University of Cambridge / 2010 / ii / Paper 1 / 9D / Solution
- Past exam of the mathematics course of the University of Cambridge / 2010 / ii / Paper 2 / 15D / Solution
- Past exam of the mathematics course of the University of Cambridge / 2010 / ii / Paper 2 / 9D / Solution
- Past exam of the mathematics course of the University of Cambridge / 2011 / ia / Paper 4 / 12B / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2011 / ia / Paper 4 / 9B / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2012 / iii / Paper 59 / 2 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2012 / iii / Paper 60 / 1 / i / Solution
- Past exam of the mathematics course of the University of Cambridge / 2012 / iii / Paper 60 / 3 / ii / Solution
- Past exam of the mathematics course of the University of Cambridge / 2012 / iii / Paper 64 / 4 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2012 / iii / Paper 73 / 2 / v / Solution
- Past exam of the mathematics course of the University of Cambridge / 2012 / iii / Paper 73 / 3 / vi / Solution
- Past exam of the mathematics course of the University of Cambridge / 2012 / iii / Paper 73 / 3 / v / Solution
- Past exam of the mathematics course of the University of Cambridge / 2012 / iii / Paper 7 / 4 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2013 / ia / Paper 4 / 10B / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2013 / ia / Paper 4 / 12B / b / Solution
- Past exam of the mathematics course of the University of Cambridge / 2013 / ia / Paper 4 / 9B / a / i / Solution
- Past exam of the mathematics course of the University of Cambridge / 2013 / ib / Paper 4 / 18A / Solution
- Past exam of the mathematics course of the University of Cambridge / 2013 / iii / Paper 73 / 1 / iii / Solution
- Past exam of the mathematics course of the University of Cambridge / 2013 / iii / Paper 73 / 4 / iii / Solution
- Past exam of the mathematics course of the University of Cambridge / 2014 / ia / Paper 4 / 10C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2014 / ia / Paper 4 / 12C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2014 / iii / Paper 54 / 3 / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2014 / iii / Paper 70 / 4 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2015 / ia / Paper 4 / 10C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2015 / ia / Paper 4 / 11C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2015 / ia / Paper 4 / 3C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2015 / iii / Paper 62 / 1 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2015 / iii / Paper 63 / 2 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2015 / iii / Paper 64 / 1 / d / Solution
- Past exam of the mathematics course of the University of Cambridge / 2015 / iii / Paper 64 / 2 / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2015 / iii / Paper 65 / 2 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2015 / iii / Paper 65 / 3 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2015 / iii / Paper 79 / 1 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2015 / ii / Paper 1 / 32A / Solution
- Past exam of the mathematics course of the University of Cambridge / 2015 / ii / Paper 1 / 7D / b / i / Solution
- Past exam of the mathematics course of the University of Cambridge / 2016 / ia / Paper 4 / 9B / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2016 / ia / Paper 4 / 9B / c / Solution
- Past exam of the mathematics course of the University of Cambridge / 2016 / ib / Paper 3 / 17D / b / iv / Solution
- Past exam of the mathematics course of the University of Cambridge / 2016 / iii / Paper 314 / 2 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2016 / iii / Paper 322 / 3 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2017 / ia / Paper 4 / 10A / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2017 / ia / Paper 4 / 3A / Solution
- Past exam of the mathematics course of the University of Cambridge / 2017 / ia / Paper 4 / 9A / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2017 / ia / Paper 4 / 9A / b / Solution
- Past exam of the mathematics course of the University of Cambridge / 2017 / iii / Paper 314 / 1 / b / Solution
- Past exam of the mathematics course of the University of Cambridge / 2017 / iii / Paper 316 / 4 / i / Solution
- Past exam of the mathematics course of the University of Cambridge / 2017 / iii / Paper 321 / 2 / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2017 / iii / Paper 331 / 2 / b / ii / Solution
- Past exam of the mathematics course of the University of Cambridge / 2017 / iii / Paper 331 / 2 / b / i / Solution
- Past exam of the mathematics course of the University of Cambridge / 2017 / iii / Paper 331 / 4 / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2017 / iii / Paper 331 / 4 / b / Solution
- Past exam of the mathematics course of the University of Cambridge / 2017 / iii / Paper 343 / 2 / iii / Solution
- Past exam of the mathematics course of the University of Cambridge / 2017 / iii / Paper 343 / 2 / i / Solution
- Past exam of the mathematics course of the University of Cambridge / 2018 / ia / Paper 4 / 10A / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2018 / iii / Paper 314 / 2 / d / Solution
- Past exam of the mathematics course of the University of Cambridge / 2018 / iii / Paper 317 / 1 / ii / Solution
- Past exam of the mathematics course of the University of Cambridge / 2018 / iii / Paper 317 / 1 / i / Solution
- Past exam of the mathematics course of the University of Cambridge / 2018 / iii / Paper 321 / 1 / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2018 / iii / Paper 321 / 3 / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2018 / iii / Paper 333 / 1 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2018 / ii / Paper 2 / 14B / Solution
- Past exam of the mathematics course of the University of Cambridge / 2019 / iii / Paper 346 / 1 / b / Solution
- Past exam of the mathematics course of the University of Cambridge / 2019 / iii / Paper 346 / 2 / Solution
- Past exam of the mathematics course of the University of Cambridge / 2020 / ii / Paper 4 / 8B / Solution
- Past exam of the mathematics course of the University of Cambridge / 2021 / ia / Paper 4 / 4C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2021 / ia / Paper 4 / 9C / Solution
- Past exam of the mathematics course of the University of Cambridge / 2021 / ii / Paper 1 / 8D / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2023 / ii / Paper 2 / 14D / b / Solution
- Past exam of the mathematics course of the University of Cambridge / 2024 / ia / Paper 4 / 12C / b / Solution
- Past exam of the mathematics course of the University of Cambridge / 2024 / ib / Paper 3 / 16D / Solution
- Past exam of the mathematics course of the University of Cambridge / 2024 / iii / Paper 333 / 1 / b / Solution
- Past exam of the mathematics course of the University of Cambridge / 2024 / ii / Paper 4 / 15E / a / Solution
- Past exam of the mathematics course of the University of Cambridge / 2025 / ii / Paper 1 / 36C / b / i / Solution
- Past exam of the mathematics course of the University of Cambridge / 2026 / ia / Paper 4 / 10B / d / Solution
- Past exam of the mathematics course of the University of Cambridge / 2026 / ib / Paper 2 / 15B / Solution
- Past exam of the mathematics course of the University of Cambridge / 2026 / ii / Paper 1 / 35E / c / Solution
- Past exam of the mathematics course of the University of Cambridge / 2026 / ii / Paper 2 / 14A / c / Solution
- Past exam of the mathematics course of the University of Cambridge / 2026 / ii / Paper 2 / 8A / a / Solution
- Past exam of the mathematics course of the University of Oxford / 2015 / Prelims / Mathematics IV / 2 / a / Solution
- Past exam of the mathematics course of the University of Oxford / 2015 / Prelims / Mathematics IV / 4 / b / Solution
- Past exam of the mathematics course of the University of Oxford / 2017 / Prelims / Mathematics IV / 4 / b / Solution
- Past exam of the mathematics course of the University of Oxford / 2017 / Prelims / Mathematics IV resit / 5 / a / Solution
- Past exam of the mathematics course of the University of Oxford / 2021 / Prelims / Mathematics IV resit / 5 / d / Solution
- Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge / 2010 / Paper 2 / 12 / a / Solution
- Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge / 2023 / Paper 2 / 19 / b / i / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2001 / Paper 2 / 7 / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2002 / Paper 2 / 7 / i / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2003 / Paper 2 / 7 / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2004 / Paper 2 / 7 / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2005 / Paper 2 / 7 / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2007 / Paper 2 / 7 / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2009 / Paper 2 / 7 / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2012 / Paper 1 / 10 / ii / a / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2012 / Paper 2 / 7 / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2013 / Paper 2 / 7 / i / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2014 / Paper 2 / 7 / i / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2015 / Paper 2 / 7 / a / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2016 / Paper 1 / 2 / b / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2017 / Paper 2 / 7 / a / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2018 / Paper 2 / 7 / b / i / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2019 / Paper 2 / 7 / a / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2021 / Paper 2 / 7 / a / i / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2022 / Paper 2 / 7 / a / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2024 / Paper 2 / 7 / a / Solution
- Past exam of the mathematics course of the year 2 of the natural sciences course of the University of Cambridge / 2025 / Paper 2 / 7 / a / Solution
- Past exam of the medical physics course of the University of Cambridge / 2012 / Paper 1 / 1 / Solution
- Past exam of the medicine course of the University of Oxford / 1864 / First examination / Physics / 2 / Solution
- Past exam of the medicine course of the University of Oxford / 1867 / First examination / Physics / 2 / Solution
- Past exam of the MPhil in micro- and nanotechnology enterprise course of the University of Cambridge / 2018 / Paper 1 / Section A(i) / 1 / i / Solution
- Past exam of the MPhil in micro- and nanotechnology enterprise course of the University of Cambridge / 2018 / Paper 2 / Section A(ii) / 14 / i / Solution
- Past exam of the MPhil in nuclear energy course of the University of Cambridge / 2020 / Module NE4 / 2 / a / Solution
- Past exam of the MPhil in nuclear energy course of the University of Cambridge / 2020 / Module NE4 / 2 / c / Solution
- Past exam of the MPhil in nuclear energy course of the University of Cambridge / 2021 / Module NE1 / 1 / a / Solution
- Past exam of the MPhil in nuclear energy course of the University of Cambridge / 2021 / Module NE1 / 1 / e / Solution
- Past exam of the nuclear and particle physics course of the University of Oxford / 2021 / 2 / b / Solution
- Past exam of the nuclear and particle physics course of the University of Oxford / 2021 / 2 / d / Solution
- Past exam of the nuclear and particle physics course of the University of Oxford / 2021 / 2 / e / Solution
- Past exam of the nuclear and particle physics course of the University of Oxford / 2022 / 1 / b / Solution
- Past exam of the nuclear and particle physics course of the University of Oxford / 2022 / 1 / c / Solution
- Past exam of the optics and electrodynamics course of the University of Cambridge / 2014 / Paper 1 / 3 / Solution
- Past exam of the optics and electrodynamics course of the University of Cambridge / 2016 / Paper 1 / 1 / a / Solution
- Past exam of the options I course of the University of Oxford / 2005 / H / 1 / Solution
- Past exam of the options I course of the University of Oxford / 2006 / H / H1 / Solution
- Past exam of the options I course of the University of Oxford / 2012 / G / G1 / Solution
- Past exam of the options I course of the University of Oxford / 2013 / H / 1 / a / Solution
- Past exam of the options II course of the University of Oxford / 2006 / H / 2 / Solution
- Past exam of the options II course of the University of Oxford / 2009 / H / H2 / Solution
- Past exam of the particle and nuclear physics course of the University of Cambridge / 2012 / Paper 1 / 1 / b / Solution
- Past exam of the particle and nuclear physics course of the University of Cambridge / 2012 / Paper 1 / 4 / Solution
- Past exam of the particle and nuclear physics course of the University of Cambridge / 2013 / Paper 1 / 4 / Solution
- Past exam of the particle and nuclear physics course of the University of Cambridge / 2015 / Paper 1 / 2 / b / Solution
- Past exam of the particle and nuclear physics course of the University of Cambridge / 2016 / Paper 1 / 1 / c / Solution
- Past exam of the particle and nuclear physics course of the University of Cambridge / 2016 / Paper 1 / 2 / b / Solution
- Past exam of the particle and nuclear physics course of the University of Cambridge / 2016 / Paper 1 / 3 / b / Solution
- Past exam of the particle and nuclear physics course of the University of Cambridge / 2016 / Paper 1 / 4 / e / Solution
- Past exam of the particle and nuclear physics course of the University of Cambridge / 2018 / Section B / B3 / Solution
- Past exam of the particle and nuclear physics course of the University of Cambridge / 2021 / Section A / 1 / Solution
- Past exam of the philosophy of science supplementary subject of the University of Oxford / 2015 / 6 / Solution
- Past exam of the philosophy of science supplementary subject of the University of Oxford / 2019 / 1 / Solution
- Past exam of the philosophy of science supplementary subject of the University of Oxford / 2022 / 8 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2013 / 11 / e / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2013 / 2 / b / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2013 / 7 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2013 / 9 / d / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2013 resit / 11 / b / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2013 resit / 2 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2013 resit / 5 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2013 resit / 9 / c / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 / 10 / b / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 / 11 / a / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 / 11 / b / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 / 1 / a / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 / 1 / b / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 / 3 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 / 8 / a / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 / 8 / b / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 / 9 / b / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 / 9 / c / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 resit / 10 / c / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 resit / 11 / a / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 resit / 2 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 resit / 3 / a / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 resit / 5 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 resit / 8 / b / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2014 resit / 9 / a / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2015 / 10 / a / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2015 / 10 / d / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2015 / 8 / a / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2015 resit / 10 / a / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2015 resit / 11 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2015 resit / 4 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2015 resit / 5 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2015 resit / 9 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2016 / 11 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2016 / 2 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2016 resit / 10 / i / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2016 resit / 2 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2016 resit / 7 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2016 resit / 8 / iii / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2016 resit / 8 / ii / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2017 / 10 / a / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2017 / 10 / c / i / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2017 / 11 / a / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2017 / 11 / e / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2017 / 4 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2017 / 5 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2017 / 8 / d / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2017 / 9 / a / ii / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2017 resit / 1 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2017 resit / 2
- Past exam of the physics 1 paper of the University of Oxford / 2017 resit / 4 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2017 resit / 5 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2017 resit / 6 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2017 resit / 9 / b / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2018 / 1 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2018 / 4 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2018 / 6 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2018 / 8 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2018 / 9 / ii / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2018 / 9 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2019 / 10 / b / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2019 / 2 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2019 / 4 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2019 / 8 / b / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2019 / 9 / b / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2019 resit / 10 / a / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2019 resit / 10 / c / ii / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2019 resit / 5 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2019 resit / 6 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2019 resit / 8 / iii / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2019 resit / 8 / ii / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2019 resit / 8 / i / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2019 resit / 8 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2021 / 10 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2021 / 4 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2021 / 7 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2021 / 8 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2021 / 9 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2021 resit / 10 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2021 resit / 2 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2021 resit / 4 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2021 resit / 5 / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2021 resit / 9 / a / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2021 resit / 9 / b / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2022 / 10 / a / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2022 / 10 / b / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2022 / 5 / a / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2022 / 7 / c / Solution
- Past exam of the physics 1 paper of the University of Oxford / 2022 / 9 / a / Solution
- Past exam of the physics 2 paper of the University of Oxford / 2013 resit / 1 / ii / Solution
- Past exam of the physics 2 paper of the University of Oxford / 2014 resit / 7 / 1 / Solution
- Past exam of the physics 2 paper of the University of Oxford / 2014 resit / 7 / a / Solution
- Past exam of the physics 2 paper of the University of Oxford / 2016 / 2 / Solution
- Past exam of the physics 2 paper of the University of Oxford / 2017 / 1 / Solution
- Past exam of the physics 2 paper of the University of Oxford / 2017 resit / 3 / Solution
- Past exam of the physics 2 paper of the University of Oxford / 2019 / 8 / c / Solution
- Past exam of the physics 2 paper of the University of Oxford / 2019 / 9 / c / Solution
- Past exam of the physics 2 paper of the University of Oxford / 2019 resit / 8 / ii / Solution
- Past exam of the physics A course of the University of Cambridge / 2011 / Paper 2 / Section A / 1 / Solution
- Past exam of the physics A course of the University of Cambridge / 2012 / Paper 1 / Section B / B9 / Solution
- Past exam of the physics A course of the University of Cambridge / 2012 / Paper 1 / Section C / C11 / c / Solution
- Past exam of the physics A course of the University of Cambridge / 2013 / Paper 1 / Section B / B8 / Solution
- Past exam of the physics A course of the University of Cambridge / 2013 / Paper 1 / Section B / B9 / Solution
- Past exam of the physics A course of the University of Cambridge / 2013 / Paper 1 / Section C / C10 / Solution
- Past exam of the physics A course of the University of Cambridge / 2018 / Paper 1 / Section C / C10 / Solution
- Past exam of the physics A course of the University of Cambridge / 2018 / Paper 1 / Section C / C11 / c / Solution
- Past exam of the physics A course of the University of Cambridge / 2019 / Paper 1 / Section A / 1 / Solution
- Past exam of the physics A course of the University of Cambridge / 2019 / Paper 1 / Section A / 2 / Solution
- Past exam of the physics A course of the University of Cambridge / 2019 / Paper 1 / Section B / B7 / b / Solution
- Past exam of the physics A course of the University of Cambridge / 2021 / Paper 1 / Section A / 2 / Solution
- Past exam of the physics A course of the University of Cambridge / 2021 / Paper 1 / Section B / B7 / b / Solution
- Past exam of the physics A course of the University of Cambridge / 2021 / Paper 1 / Section D / D9 / Solution
- Past exam of the physics A course of the University of Cambridge / 2022 / Paper 1 / Section B / B7 / a / Solution
- Past exam of the physics B course of the University of Cambridge / 2010 / Paper 1 / Section B / B8 / b / Solution
- Past exam of the physics B course of the University of Cambridge / 2011 / Paper 1 / Section B / B8 / a / Solution
- Past exam of the physics B course of the University of Cambridge / 2011 / Paper 2 / Section C / C10 / Solution
- Past exam of the physics B course of the University of Cambridge / 2012 / Paper 1 / Section C / C10 / Solution
- Past exam of the physics B course of the University of Cambridge / 2012 / Paper 1 / Section C / C11 / Solution
- Past exam of the physics B course of the University of Cambridge / 2012 / Paper 1 / Section C / C12 / Solution
- Past exam of the physics B course of the University of Cambridge / 2012 / Paper 1 / Section C / C13 / Solution
- Past exam of the physics B course of the University of Cambridge / 2012 / Paper 2 / Section B / B8 / c / Solution
- Past exam of the physics B course of the University of Cambridge / 2012 / Paper 2 / Section B / B9 / Solution
- Past exam of the physics B course of the University of Cambridge / 2013 / Paper 1 / Section B / B8 / Solution
- Past exam of the physics B course of the University of Cambridge / 2013 / Paper 1 / Section C / C12 / Solution
- Past exam of the physics B course of the University of Cambridge / 2014 / Paper 1 / Section A / A4 / Solution
- Past exam of the physics B course of the University of Cambridge / 2014 / Paper 2 / Section B / B8 / c / Solution
- Past exam of the physics B course of the University of Cambridge / 2014 / Paper 2 / Section B / B9 / Solution
- Past exam of the physics B course of the University of Cambridge / 2015 / Paper 1 / Section C / C10 / Solution
- Past exam of the physics B course of the University of Cambridge / 2015 / Paper 1 / Section C / C11 / Solution
- Past exam of the physics B course of the University of Cambridge / 2015 / Paper 2 / Section A / A1 / Solution
- Past exam of the physics B course of the University of Cambridge / 2015 / Paper 2 / Section B / B8 / d / Solution
- Past exam of the physics B course of the University of Cambridge / 2015 / Paper 2 / Section C / C11 / Solution
- Past exam of the physics B course of the University of Cambridge / 2016 / Paper 1 / Section B / B8 / Solution
- Past exam of the physics B course of the University of Cambridge / 2016 / Paper 1 / Section C / C13 / Solution
- Past exam of the physics B course of the University of Cambridge / 2016 / Paper 2 / Section B / B8 / d / Solution
- Past exam of the physics B course of the University of Cambridge / 2016 / Paper 2 / Section C / C12 / c / Solution
- Past exam of the physics B course of the University of Cambridge / 2016 / Paper 2 / Section C / C12 / Solution
- Past exam of the physics B course of the University of Cambridge / 2017 / Paper 1 / Section A / A5 / Solution
- Past exam of the physics B course of the University of Cambridge / 2017 / Paper 1 / Section C / C11 / Solution
- Past exam of the physics B course of the University of Cambridge / 2017 / Paper 1 / Section C / C12 / Solution
- Past exam of the physics B course of the University of Cambridge / 2017 / Paper 2 / Section B / B9 / Solution
- Past exam of the physics B course of the University of Cambridge / 2017 / Paper 2 / Section C / C12 / Energy of incident particles / Solution
- Past exam of the physics B course of the University of Cambridge / 2017 / Paper 2 / Section C / C12 / Solution
- Past exam of the physics B course of the University of Cambridge / 2018 / Paper 1 / Section C / C10 / Physical interpretation / Solution
- Past exam of the physics B course of the University of Cambridge / 2018 / Paper 1 / Section C / C10 / Solution
- Past exam of the physics B course of the University of Cambridge / 2018 / Paper 1 / Section C / C12 / c / Solution
- Past exam of the physics B course of the University of Cambridge / 2018 / Paper 2 / Section A / A3 / Solution
- Past exam of the physics B course of the University of Cambridge / 2018 / Paper 2 / Section B / B8 / c / Solution
- Past exam of the physics B course of the University of Cambridge / 2019 / Paper 1 / Section A / A4 / Solution
- Past exam of the physics B course of the University of Cambridge / 2019 / Paper 2 / Section B / B9 / Solution
- Past exam of the physics B course of the University of Cambridge / 2019 / Paper 2 / Section C / C13 / Solution
- Past exam of the physics B course of the University of Cambridge / 2021 / Paper 1 / Section A / A1 / Solution
- Past exam of the physics B course of the University of Cambridge / 2021 / Paper 1 / Section B / B6 / d / Solution
- Past exam of the physics B course of the University of Cambridge / 2021 / Paper 2 / Section B / B6 / b / Solution
- Past exam of the physics B course of the University of Cambridge / 2022 / Paper 1 / Section A / A3 / Solution
- Past exam of the physics B course of the University of Cambridge / 2022 / Paper 2 / Section A / A3 / Solution
- Past exam of the physics B course of the University of Cambridge / 2022 / Paper 2 / Section B / B6 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2010 / Paper 1 / Section B / B9 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2011 / Paper 1 / Section A / A2 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2012 / Paper 1 / Section B / B7 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2012 / Paper 1 / Section E / E14 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2013 / Paper 1 / Section A / 1 / b / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2013 / Paper 1 / Section B / B7 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2013 / Paper 1 / Section D / D13 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2013 / Paper 1 / Section E / E15 / b / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2015 / Paper 1 / Section B / B9 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2015 / Paper 1 / Section D / D13 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2015 / Paper 1 / Section E / E14 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2016 / Paper 1 / Section A / A1 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2016 / Paper 1 / Section B / B8 / a / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2016 / Paper 1 / Section D / D12 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2017 / Section E / 15 / a / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2018 / Section A / 5 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2018 / Section B / 9 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2018 / Section D / 13 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2018 / Section E / 15 / b / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2021 / Section B / 10 / d / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2021 / Section B / 6 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2021 / Section B / 8 / c / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2021 / Section B / 8 / d / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2022 / Section A / 2 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2022 / Section A / 5 / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2022 / Section B / 6 / b / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2022 / Section B / 6 / e / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2022 / Section B / 9 / a / Solution
- Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge / 2024 / Paper 1 / Section B / 7 / c / Solution
- Past exam of the physics course of the year 4 of the natural sciences course of the University of Cambridge / 2013 / Paper 1 / Section A / A1 / a / Solution
- Past exam of the physics course of the year 4 of the natural sciences course of the University of Cambridge / 2015 / Paper 1 / Section B / B4 / Solution
- Past exam of the physics course of the year 4 of the natural sciences course of the University of Cambridge / 2016 / Paper 1 / Section A / A4 / Solution
- Past exam of the physics course of the year 4 of the natural sciences course of the University of Cambridge / 2016 / Paper 1 / Section B / B2 / d / Solution
- Past exam of the physics course of the year 4 of the natural sciences course of the University of Cambridge / 2016 / Paper 1 / Section B / B3 / Solution
- Past exam of the physics course of the year 4 of the natural sciences course of the University of Cambridge / 2016 / Paper 1 / Section B / B5 / Solution
- Past exam of the physics of atmospheres and oceans course of the University of Oxford / 2015 / 1 / c / Solution
- Past exam of the physics of atmospheres and oceans course of the University of Oxford / 2016 / 2 / Solution
- Past exam of the physics of atmospheres and oceans course of the University of Oxford / 2017 / 3 / c / Solution
- Past exam of the Probability, statistics and options II course of the University of Oxford / 2007 / H / 2 / Solution
- Past exam of the Probability, statistics and options II course of the University of Oxford / 2008 / H / 2 / b / i / Solution
- Past exam of the Probability, statistics and options II course of the University of Oxford / 2009 / H / H2 / Solution
- Past exam of the Probability, statistics and options II course of the University of Oxford / 2011 / H / H2 / Solution
- Past exam of the quantum condensed matter course of the University of Cambridge / 2004 / Section B / B10 / Solution
- Past exam of the quantum condensed matter course of the University of Cambridge / 2012 / 1 / c / Solution
- Past exam of the quantum condensed matter course of the University of Cambridge / 2012 / 2 / b / Solution
- Past exam of the quantum condensed matter course of the University of Cambridge / 2013 / 1 / b / Solution
- Past exam of the quantum condensed matter course of the University of Cambridge / 2014 / 1 / c / Solution
- Past exam of the quantum condensed matter course of the University of Cambridge / 2014 / 2 / a / Solution
- Past exam of the quantum condensed matter course of the University of Cambridge / 2014 / 4 / Solution
- Past exam of the quantum condensed matter course of the University of Cambridge / 2017 / 4 / Solution
- Past exam of the quantum Condensed Matter Field Theory course of the University of Cambridge / 2013 / Paper 1 / 1 / a / Solution
- Past exam of the quantum Condensed Matter Field Theory course of the University of Cambridge / 2016 / Paper 1 / 2 / c / Solution
- Past exam of the quantum matter course of the University of Oxford / 2023 / 1 / a / Solution
- Past exam of the quantum matter course of the University of Oxford / 2023 / 2 / a / Solution
- Past exam of the quantum matter course of the University of Oxford / 2025 / 1 / c / Solution
- Past exam of the quantum matter course of the University of Oxford / 2025 / 2 / d / Solution
- Past exam of the quantum matter course of the University of Oxford / 2025 / 2 / e / Solution
- Past exam of the quantum mechanics quantum theory and quantum computers course of the University of Oxford / 2007 / B / 5 / Solution
- Past exam of the quantum mechanics quantum theory and quantum computers course of the University of Oxford / 2009 / A / 2 / Solution
- Past exam of the quantum mechanics quantum theory and quantum computers course of the University of Oxford / 2010 / B / 4 / Solution
- Past exam of the quantum theory and quantum computers course of the University of Oxford / 2010 / 1 / Solution
- Past exam of the quantum theory course of the University of Oxford / 2015 / 2 / c / ii / Solution
- Past exam of the quantum theory course of the University of Oxford / 2015 / 3 / ii / Solution
- Past exam of the radiative processes and high energy astrophysics course of the University of Oxford / 2024 / 1 / a / Solution
- Past exam of the radiative processes and high energy astrophysics course of the University of Oxford / 2024 / 1 / f / Solution
- Past exam of the relativistic Astrophysics and Cosmology course of the University of Cambridge / 2013 / Paper 1 / 3 / c / Solution
- Past exam of the relativistic Astrophysics and Cosmology course of the University of Cambridge / 2015 / Paper 1 / 1 / Solution
- Past exam of the relativistic Astrophysics and Cosmology course of the University of Cambridge / 2016 / Paper 1 / 1 / Solution
- Past exam of the relativistic Astrophysics and Cosmology course of the University of Cambridge / 2016 / Paper 1 / 2 / Solution
- Past exam of the relativity course of the University of Cambridge / 2016 / Paper 1 / 1 / b / Solution
- Past exam of the relativity course of the University of Cambridge / 2018 / Section A / 1 / a / Solution
- Past exam of the short options paper of the physics Prelims of the University of Oxford / 2019 / S2 / 1 / c / Solution
- Past exam of the short options paper of the physics Prelims of the University of Oxford / 2019 / S3 / 2 / e / Solution
- Past exam of the short options paper of the physics Prelims of the University of Oxford / 2021 / S02 / 3 / d / Solution
- Past exam of the short options paper of the physics Prelims of the University of Oxford / 2021 / S03 / 2 / a / Solution
- Past exam of the short options paper of the physics Prelims of the University of Oxford / 2021 / S03 / 2 / b / Solution
- Past exam of the short options paper of the physics Prelims of the University of Oxford / 2021 / S03 / 2 / c / Solution
- Past exam of the short options paper of the physics Prelims of the University of Oxford / 2021 / S03 / 2 / d / Solution
- Past exam of the short options paper of the physics Prelims of the University of Oxford / 2021 / S03 / 3 / a / Solution
- Past exam of the short options paper of the physics Prelims of the University of Oxford / 2021 / S03 / 3 / c / Solution
- Past exam of the short options paper shared by Parts A and B of the physics course of the University of Oxford / 2019 / S10 / 2 / a / Solution
- Past exam of the short options paper shared by Parts A and B of the physics course of the University of Oxford / 2019 / S2 / 1 / c / Solution
- Past exam of the short options paper shared by Parts A and B of the physics course of the University of Oxford / 2019 / S7 / 2 / b / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2012 / S3 / 1 / 1 / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2012 / S3 / 1 / 2 / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2012 / S3 / 2 / 1 / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2012 / S3 / 2 / 6 / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2012 / S3 / 3 / 1 / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2012 / S7 / 1 / 4 / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2015 / S19 / 1 / a / 2 / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2016 / S2 / 2 / 2 / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2016 / S3 / 1 / 1 / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2016 / S3 / 3 / 1 / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2016 / S4 / 1 / 4 / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2016 / S7 / 2 / c / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2017 / S7 / 1 / c / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2018 / S19 / 2 / a / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2018 / S19 / 2 / b / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2018 / S19 / 3 / c / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2018 / S29 / 2 / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2018 / S7 / 1 / b / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2018 / S7 / 1 / d / Solution
- Past exam of the short options paper shared by Prelims and Parts A and B of the physics course of the University of Oxford / 2018 / S7 / 2 / b / Solution
- Past exam of the sub-atomic physics course of the University of Oxford / 2016 / 1 / d / Solution
- Past exam of the sub-atomic physics course of the University of Oxford / 2016 / 3 / d / Solution
- Past exam of the superconductivity and Quantum Coherence course of the University of Cambridge / 2015 / Paper 1 / 1 / d / Solution
- Past exam of the symmetry and relativity course of the University of Oxford / 2017 / 1 / d / Solution
- Past exam of the symmetry and relativity course of the University of Oxford / 2017 / 1 / e / Solution
- Past exam of the symmetry and relativity course of the University of Oxford / 2019 / 1 / e / Solution
- Past exam of the symmetry and relativity course of the University of Oxford / 2021 / 1 / c / Solution
- Past exam of the symmetry and relativity course of the University of Oxford / 2021 / 1 / d / Solution
- Past exam of the symmetry and relativity course of the University of Oxford / 2021 / 3 / a / ii / Solution
- Past exam of the theoretical mechanics course of the University of Oxford / 2008 / B / 5 / Solution
- Past exam of the theoretical physics I course of the University of Cambridge / 2012 / Paper 1 / 1 / a / Solution
- Past exam of the theoretical physics I course of the University of Cambridge / 2012 / Paper 1 / 1 / d / Solution
- Past exam of the theoretical physics I course of the University of Cambridge / 2013 / Paper 1 / 2 / a / Solution
- Past exam of the theoretical physics I course of the University of Cambridge / 2015 / Paper 1 / 2 / a / Solution
- Past exam of the theoretical physics I course of the University of Cambridge / 2015 / Paper 1 / 4 / a / Solution
- Past exam of the theoretical physics I course of the University of Cambridge / 2016 / Paper 1 / 1 / a / Solution
- Past exam of the theoretical physics I course of the University of Cambridge / 2018 / 2 / a / Solution
- Past exam of the theoretical physics I course of the University of Cambridge / 2019 / 2 / Solution
- Past exam of the theoretical physics I course of the University of Cambridge / 2022 / 1 / a / Solution
- Past exam of the theoretical physics I course of the University of Cambridge / 2022 / 2 / b / Solution
- Past exam of the theoretical physics II course of the University of Cambridge / 2013 / Paper 1 / 6 / c / Solution
- Past exam of the thermal and statistical physics course of the University of Cambridge / 2016 / Paper 1 / 3 / Solution
- Past exam of the thermal and statistical physics course of the University of Cambridge / 2017 / 2 / a / Solution
- Past exam of the thermal physics course of the University of Oxford / 2016 / 1 / iii / Solution
- Perfectly inelastic collision
- Perpendicular neutron recoil and phonon absorption
- Photodissociation
- Photoelectric effect
- Photoelectron
- Photoelectron binding energy reference
- Photoemission spectroscopy
- Photogate measurement of acceleration down an incline
- Pion decay at rest in emulsion
- Planar effusion flux
- Post-shock capture criterion in ballistic accretion
- Pressure-work energy balance for a spherical bubble
- Principal moment of inertia
- Proton exclusion by magnetic rigidity and range
- Quantum harmonic oscillator
- Quantum resonance of the kicked rotor
- Quantum variational principle
- Quartic-inflation expansion from Planck density
- Quartic-inflation prompt-reheating estimate
- Quasi-static tether contraction
- Q value
- Radial impulse
- Radial kick from a circular Kepler orbit
- Radial momentum operator
- Radius change at constant angular momentum
- Recoil
- Recoil energy
- Recoil-free nuclear transition
- Recombination cooling of ionized hydrogen
- Recombination-weighted electron energy
- Reduced mass
- Reflected inertia of a no-slip wheel and roller
- Reflection of a string wave from a freely moving endpoint mass
- Relative speed retention in an oblique collision
- Relativistic detuning of a cyclotron
- Relativistic kinetic energy
- Relaxation to the slow-roll attractor
- Resistive damping of an Alfvén wave
- Resonance channel threshold conversion
- Rest mass of a coalescing relativistic collision
- Reynolds-stress energy production in a shearing sheet
- Rigid rotation minimizes kinetic energy at fixed angular momentum
- Rolling-cylinder loop contact threshold
- Rolling inside a fixed circular cylinder
- Rotational equipartition in a rough-ball gas
- Rotational kinetic energy
- Rutherford differential cross-section
- Rutherford scattering
- Schrödinger equation
- Sensible heat
- Series RLC circuit
- Simple harmonic motion
- Singular kinetic matrix in small oscillations
- Sisyphus cooling
- Slow neutron
- Slow-roll normalization for exponential inflation
- Small oscillations of a disk attached to prestretched radial springs
- Small-slope particle motion on a height graph
- Solenoidal time-of-flight energy window
- Specific kinetic energy
- Spectral triad interaction
- Sphere rolling in a symmetric groove
- Spherical Thomas–Fermi condensate
- Spring-mounted rolling cylinder
- Stagnation enthalpy
- Stagnation temperature
- Standing wave phase and energy
- State function
- Static friction
- Steady-flow energy balance
- Stellar kinetic-energy tensor
- Stellar pressure-energy tensor
- Stochastic heating
- Stopping potential
- Stratified mixing energy budget
- Sub-Doppler cooling
- Surface-gravity-wave energy
- Symmetric relativistic equal-mass scattering angle
- Symmetric two-photon annihilation angle
- Temperature
- Thermal neutron
- Thermionic tail-flux derivation
- Thermomechanical effect
- Thomas–Fermi approximation for a condensate
- Three-dimensional free-electron density of states
- Three-step model of high harmonic generation
- Torricelli's law
- Turbulent energy spectrum
- Two-ball elastic bounce
- Two-dimensional Thomas–Fermi condensate
- Two hinged rods with both ends sliding on a floor
- Two-layer quasi-geostrophic energy conservation
- Two-particle relative coordinate
- Ultrarelativistic magnetic bending radius
- Unit-direction kinetic-energy identity
- Vacuum domination by a scalar field
- Vacuum-window implosion energy estimate
- Van der Waals throttling model
- Velocity alignment
- Velocity-alignment energy dissipation
- Velocity-selected magnetic mass analyzer
- Velocity-space diffusion
- Vertical modes of a horizontally constrained suspended bar
- Virial radius from turnaround energy
- Virial theorem
- Virial theorem on a Kepler ellipse
- Wall-impact speed distribution
- Weak Boltzmann collision identity
- Work
- Work-energy theorem
- X-ray fluorescence
- X-ray photoelectron spectroscopy
- X-ray tube
- X-ray tube cutoff
Discussion (0) New discussion
There are no discussions about this article yet.

