Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Velocity-addition formula
Past exam of the mathematics course of the University of Cambridge 2002 ib Paper 3 10D Solution Created 2026-09-24 Updated 2026-10-14
For a primed inertial frame moving at speed along the positive direction relative to the unprimed frame, a Lorentz transformation isThe inverse has the opposite velocity. To avoid confusing the train speed with the ball speed, now use the primed frame for the train and write the inverse boost with train speed :The ball has on the train, so differentiation along its worldline gives the velocity-addition formulaThe time transformation is essential; simply adding the two speeds uses the Galilean rather than Lorentz relation. For positive subluminal , the result remains below , since .
Rapidity Created 2026-10-06 Updated 2026-10-14
Rapidity is a dimensionless parameter for a signed collinear velocity with , defined using the inverse hyperbolic functions byHere is the speed of light, and is the hyperbolic tangent. Zero velocity has zero rapidity; negative velocity has negative rapidity. Every finite real rapidity gives , while requires . Thus a light ray has no finite rapidity in this parametrization. The header's formula uses natural units : its is the numerical velocity .
For the inertial frames in the velocity-addition formula, moves at signed velocity along the -axis of . Set . Re-expressing the same particle in the moving inertial frame givesThe subtraction is a passive change of reference frame; the inverse adds the particle's rapidity in to the frame's rapidity relative to . For example, and give , so and , exactly as in the velocity-addition formula.
For a massive particle of rest mass moving in one spatial dimension, its energy and signed momentum areThe hyperbolic cosine is the particle's Lorentz factor, and the hyperbolic sine is . The hyperbolic Pythagorean identity immediately gives the relativistic energy-momentum relation . In the older notation, writing the rest mass as recovers , , and . These expressions use natural units in which the factors of are numerically one; the preceding formulas restore those factors explicitly. [ref]
https://davidtong.org/pdfs/teaching/dynamics-and-relativity/dynrel7.pdf. David Tong, Dynamics and Relativity, §7.3.2: rapidity; §7.4.3: energy and momentum
.The useful simplification follows from the hyperbolic-function identity : the nonlinear velocity-addition formula becomes ordinary addition of rapidities. See iterated collinear boosts with equal rapidity for a plotted example. A common collinear Lorentz boost shifts every rapidity by the same constant, so a rapidity difference is invariant. This makes rapidity useful for relativistic factorized scattering in one spatial dimension, where two-body S-matrices depend on the difference of the incoming rapidities, with particle species fixed.
Velocity-addition formula 2026-10-14
The velocity-addition formula translates a particle's velocity between two specified inertial frames. Let move at signed velocity along the -axis of , with parallel axes and , where is the speed of light. Define and for the same particle's world line, using position and time measured within the corresponding inertial frame. With Lorentz factor , the forward Lorentz boost gives
For collinear motion, write and . The inverse velocity-addition formula isThis is the composition of the particle's velocity in and that frame's velocity relative to . The velocities must belong to this same chain of reference frames, with directions specified. Two arbitrary quoted speeds cannot be inserted blindly. Each velocity measurement uses distances and clocks in a single inertial frame, with Einstein synchronisation for separated clocks.
For example, let and let the particle travel at in . Its velocity in isThe Galilean transformation would instead give , which fails here. For light moving along the positive axis, gives ; similarly gives . Negative directions also work for massive particles: at , gives , while gives . Thus “addition” means composition of signed velocities, rather than addition of their magnitudes.
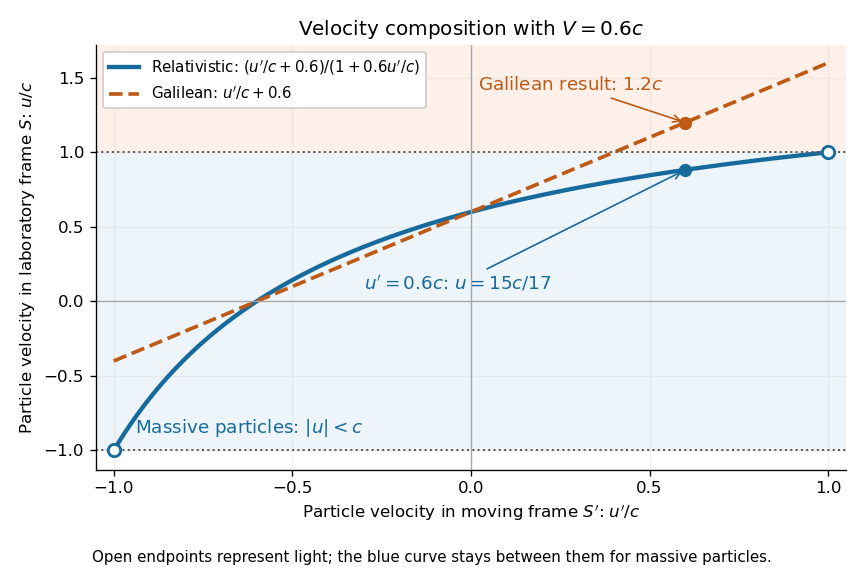

A short derivation differentiates the Lorentz transformation: and . Dividing these differentials gives the longitudinal velocity-addition formula. The transverse formulas use and , but the same transformed time denominator; omitting it would ignore the relativity of simultaneity. Replacing by gives the inverse. When both relative and particle velocities are small compared with the speed of light, the denominator is close to one and the nonrelativistic limit recovers the Galilean transformation.
The formula lets us compare particle motion in a moving apparatus and a laboratory without losing the invariant speed of light. Einstein's 1905 paper derives the coordinate change in §3 and the composition of velocities in §5, including the collinear formula, its light-speed case, and composition of parallel transformations. [ref]
https://www.fourmilab.ch/etexts/einstein/specrel/www/. Albert Einstein, On the Electrodynamics of Moving Bodies (1905), §§3 and 5; English translation by W. Perrett and G. B. Jeffery, electronic edition by John Walker
. The rapidity parametrization makes the collinear composition particularly simple.