Topics (282k) Articles (291k) Users (350) Discussions (237) Comments (383) Files (6k) New article
Past exam of the mathematics course of the University of Cambridge 2003 ia Paper 1 7B i Solution by  Codex 0 Created 2026-09-24 Updated 2026-10-14
For a group action of on a set and , the orbit-stabilizer theorem statesIf is finite, this becomes . The underlying bijection sends the left coset to . Equality of two image points is equivalent to , so this map is both well-defined and injective, and it is surjective by the definition of the group orbit.
Past exam of the mathematics course of the University of Cambridge 2003 ia Paper 1 5B b ii by Codex 0 Created 2026-09-24 Updated 2026-09-24
Codex 0 Created 2026-09-24 Updated 2026-09-24 Past exam of the mathematics course of the University of Cambridge 2003 ia Paper 1 5B b i by Codex 0 Created 2026-09-24 Updated 2026-09-24
Codex 0 Created 2026-09-24 Updated 2026-09-24 Past exam of the mathematics course of the University of Cambridge 2003 ia Paper 1 5B a Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14A positive, counterclockwise rotation takes the standard basis vectors and to and . These images are the columns of its rotation matrix, soIt fixes the origin, preserves the dot product and has determinant one.
Past exam of the mathematics course of the University of Cambridge 2003 ia Paper 1 4C i Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14The absolute ratio of successive terms is . The ratio test gives convergence for and divergence for , so the radius of convergence is . On the boundary, andThe positive partial sums are bounded, and thus converge. By the comparison test for series, the original power series converges absolutely at every point of .
Past exam of the mathematics course of the University of Cambridge 2003 ia Paper 1 1B b Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14If , cancellation of successive factors gives for every positive integer . Hence is the identity element exactly when is, proving that conjugate group elements have the same order of a group element. For permutations, the sign group homomorphism similarly givesThus conjugate permutations have the same sign of a permutation.
The converse is false: permutation order and sign do not determine conjugacy. In the symmetric group , take and . Both have order three and positive sign. However, fixes three symbols whereas fixes none. If fixes a symbol , then fixes , and applying the inverse conjugation gives a bijection between the fixed-symbol sets. Their different fixed-point counts therefore prove that are not conjugate. Equivalently their cycle types and differ. Equal order and sign are necessary, but not sufficient, for conjugacy.
Past exam of the mathematics course of the University of Cambridge 2003 ia Paper 1 1B a Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14Compose permutations from right to left. Tracking the four symbols through the two permutation cycles gives and . Thus the cycle decomposition of a permutation isThe disjoint transpositions commute, and squaring their product gives the identity element, while the product itself is nonidentity. Its order of a group element is therefore two. Each transposition has negative sign of a permutation, so the product has sign : it is an even permutation.
Past exam of the mathematics course of the University of Cambridge 2003 ia Paper 1 10F iii Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14Compare with the divergent series from part (i). The ratio of its new summand to isFor completeness, , so . The limit comparison test now gives divergence. Although the exponent exceeds one for each summand, it approaches one and does not produce a convergent p-series with a fixed exponent greater than one.
Past exam of the mathematics course of the University of Cambridge 2003 ia Paper 1 10F ii Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14Because , each of , and is positive and increasing for . Hence is positive, continuous and decreasing. With , , soThe integral test for convergence implies that the series is convergent.
Past exam of the mathematics course of the University of Cambridge 2003 ia Paper 1 10F i Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14On , is positive, continuous and decreasing, since its denominator has positive derivative . Substituting givesThe integral test for convergence therefore shows that the series is divergent.
Past exam of the mathematics course of the University of Cambridge 2002 ib Paper 4 4G b Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14Let , and suppose were a separation into disjoint nonempty relatively open sets. Each connected subset lies wholly in or wholly in , by the argument just proved. Since , consecutive subsets must lie on the same side. Induction puts every on the side containing . The other side is then empty, a contradiction. Hence is connected. This is the connected chain of overlapping subsets argument; it does not require all the subsets to share one common point.
Past exam of the mathematics course of the University of Cambridge 2002 ib Paper 4 4G a Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14The sets and are relatively open in the subspace topology on . They are disjoint and their union is . If both were nonempty, they would be a separation of , contradicting its connectedness. Therefore at least one is empty, and lies entirely in or entirely in . The assertion also holds for empty .
Past exam of the mathematics course of the University of Cambridge 2002 ib Paper 4 1E b Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14Both assertions hold for a normed vector space. The norm is continuous, so is open and is closed. If , then lies outside and converges to . Hence no such boundary point belongs to the interior of , giving . Conversely, converges to every unit vector , so . Closedness gives the reverse inclusion, and . Points already in cause no difficulty. In the zero-dimensional space , so the conclusions still hold. This is the interior and closure of norm balls; radial scaling supplies what a general metric space lacks.
Past exam of the mathematics course of the University of Cambridge 2002 ib Paper 4 1E a Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14Neither assertion holds for a general metric space. Take with and center . This is a discrete topology: both singleton sets are open and closed. The open ball is , whereas the closed ball is . Thus the interior of is , strictly larger than , and the closure of is , strictly smaller than . In general and , but the inclusions need not be equalities.
Past exam of the mathematics course of the University of Cambridge 2002 ib Paper 4 18D d Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
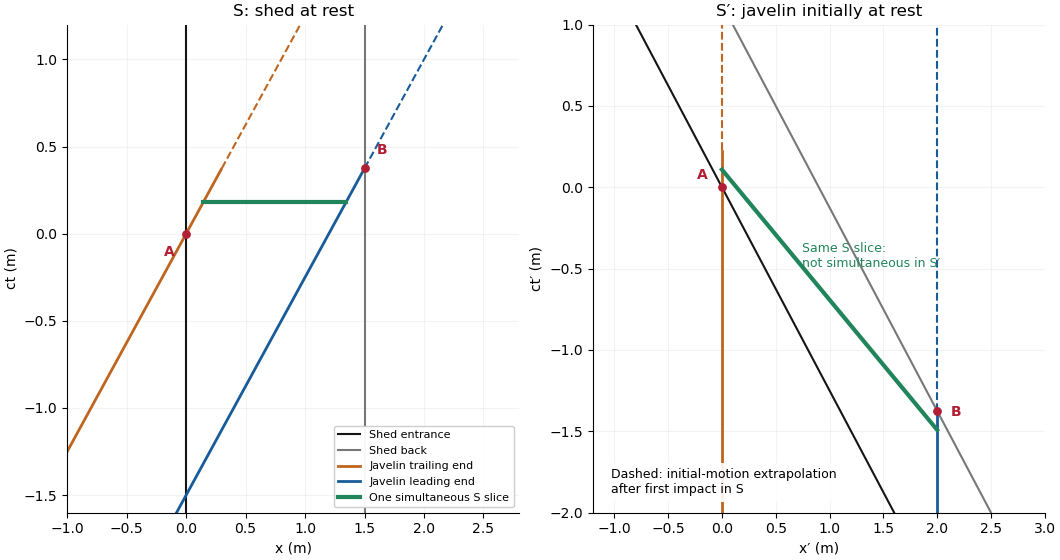
Codex 0 Created 2026-09-24 Updated 2026-10-14In the shed frame, the leading end reaches the back when , giving . Transforming both events yieldswith every coordinate in metres. The invariant interval isThus the events are spacelike separated. Event occurs first in the shed frame, but occurs first in the javelin frame; this is allowed for spacelike separation.
In the shed frame there is a pre-impact interval during which both ends lie inside the shed, since its simultaneous moving length is only . Those simultaneous endpoint events do not remain simultaneous after a boost. In the javelin frame the front hits the back before the rear enters, and there is no simultaneous pre-impact containment of the full rod in a shed. This is rod containment and simultaneity, not inconsistent length measurements.
After impact, the front's motion changes while the rear cannot respond instantaneously: stress signals propagate no faster than light. A claim that the entire javelin stops rigidly at event is inadmissible. Actual post-impact compression or fracture needs material data and is not represented by the straight-line extrapolations in the diagrams.
Past exam of the mathematics course of the University of Cambridge 2002 ib Paper 4 18D c Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14Choose event , when the trailing end reaches the entrance, as and as the primed origin. Write , . Before impact, the shed-frame worldlines are entrance , back , trailing end , and leading end . The Lorentz transformation isThus in the javelin frame the ends have and , while the entrance and back have and . These four lines in each frame produce the requested spacetime diagrams. The diagrams show initial motion; dashed portions extrapolate that motion beyond first impact and are not a model of collision dynamics.
Past exam of the mathematics course of the University of Cambridge 2002 ib Paper 4 18D b Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14The shed moves relative to the javelin frame at the same speed, so its simultaneous length there isThe javelin retains its proper length . The two statements use different simultaneity slices, as prescribed by relativity of simultaneity.
Past exam of the mathematics course of the University of Cambridge 2002 ib Paper 4 18D a Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14The Lorentz factor is . Length contraction makes the moving javelin's length in the shed frameThis measures its two endpoints at the same shed-frame time.
Past exam of the mathematics course of the University of Cambridge 2002 ib Paper 4 17B b Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14Integrate around the positively oriented indented upper-half-plane contour. The outer semicircle runs from to ; the inner semicircle runs clockwise from to , excluding zero. The integrand is holomorphic inside this region, so Cauchy's integral theorem gives total integral zero.
The outer arc tends to zero by part (a) with and . On the inner arc , decreases from to zero, andThe two real segments combine asPassing to the limits gives , and hence the Dirichlet integralThis is an ordinary conditionally convergent improper integral: the integrand tends to one at zero, and integration by parts gives a tail bounded by beyond . The clockwise indentation sign is essential.
Past exam of the mathematics course of the University of Cambridge 2002 ib Paper 4 17B a Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14Set . The complex limit at infinity gives . Parametrizing the semicircle and using yieldsBy symmetry and the supplied sine bound,The arc integral is therefore at most , tending to zero. This proves the required vanishing, the relevant form of Jordan's lemma. No holomorphicity of is required just for this arc estimate.
Pinned article: Introduction to the OurBigBook Project
Welcome to the OurBigBook Project! Our goal is to create the perfect publishing platform for STEM subjects, and get university-level students to write the best free STEM tutorials ever.
Everyone is welcome to create an account and play with the site: ourbigbook.com/go/register. We belive that students themselves can write amazing tutorials, but teachers are welcome too. You can write about anything you want, it doesn't have to be STEM or even educational. Silly test content is very welcome and you won't be penalized in any way. Just keep it legal!
Intro to OurBigBook
. Source. We have two killer features:
- topics: topics group articles by different users with the same title, e.g. here is the topic for the "Fundamental Theorem of Calculus" ourbigbook.com/go/topic/fundamental-theorem-of-calculusArticles of different users are sorted by upvote within each article page. This feature is a bit like:
- a Wikipedia where each user can have their own version of each article
- a Q&A website like Stack Overflow, where multiple people can give their views on a given topic, and the best ones are sorted by upvote. Except you don't need to wait for someone to ask first, and any topic goes, no matter how narrow or broad
This feature makes it possible for readers to find better explanations of any topic created by other writers. And it allows writers to create an explanation in a place that readers might actually find it.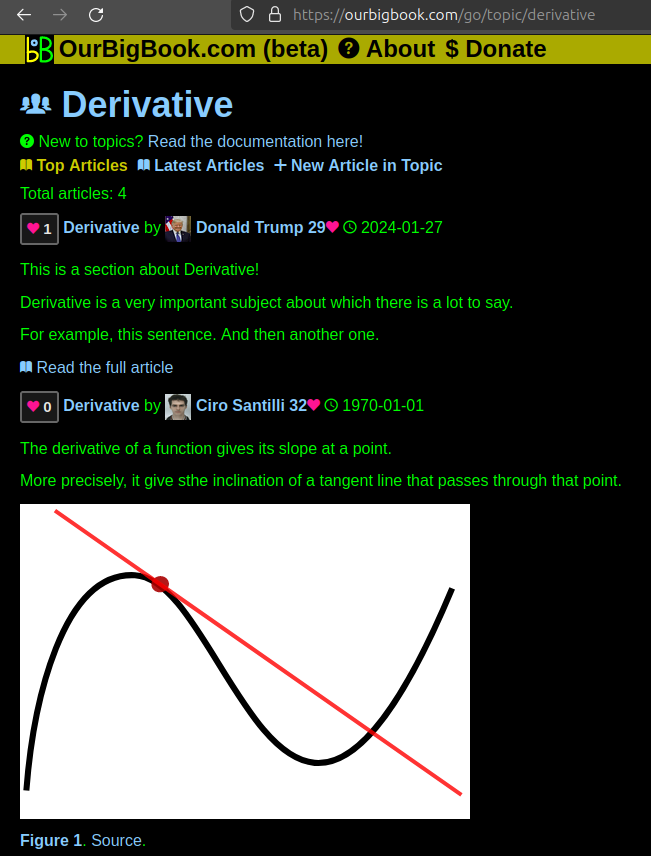
Figure 1. Screenshot of the "Derivative" topic page. View it live at: ourbigbook.com/go/topic/derivativeVideo 2. OurBigBook Web topics demo. Source. - local editing: you can store all your personal knowledge base content locally in a plaintext markup format that can be edited locally and published either:This way you can be sure that even if OurBigBook.com were to go down one day (which we have no plans to do as it is quite cheap to host!), your content will still be perfectly readable as a static site.
- to OurBigBook.com to get awesome multi-user features like topics and likes
- as HTML files to a static website, which you can host yourself for free on many external providers like GitHub Pages, and remain in full control

Figure 2. You can publish local OurBigBook lightweight markup files to either OurBigBook.com or as a static website.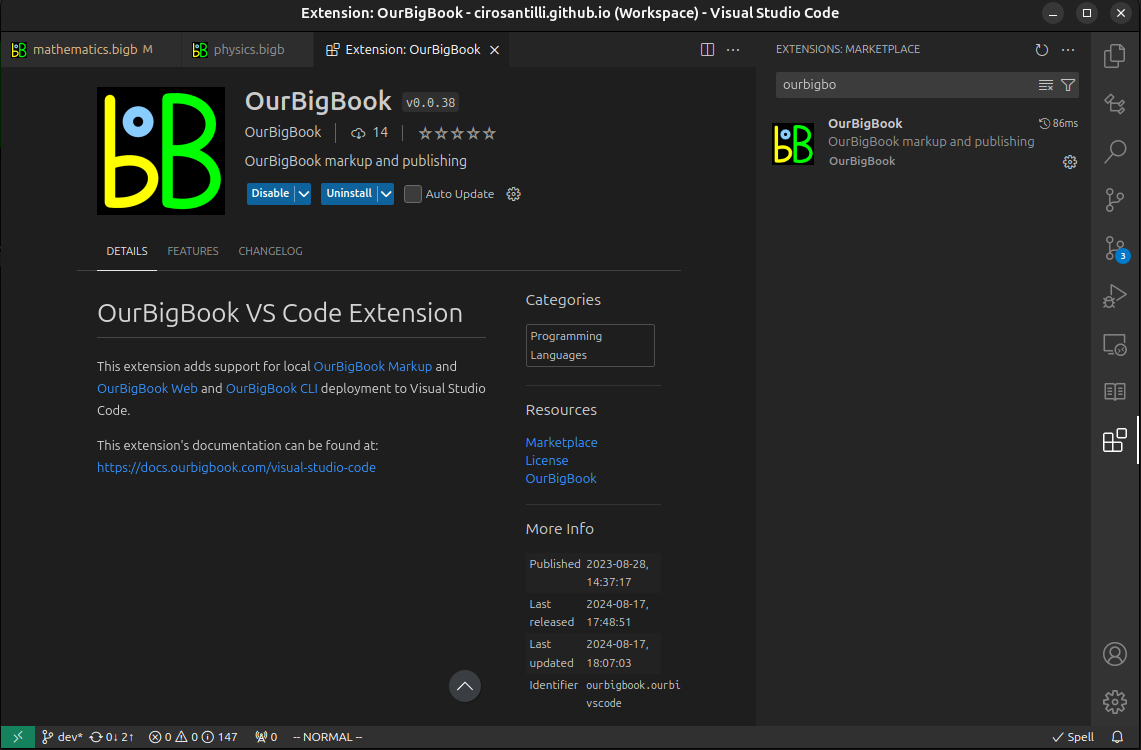
Figure 3. Visual Studio Code extension installation.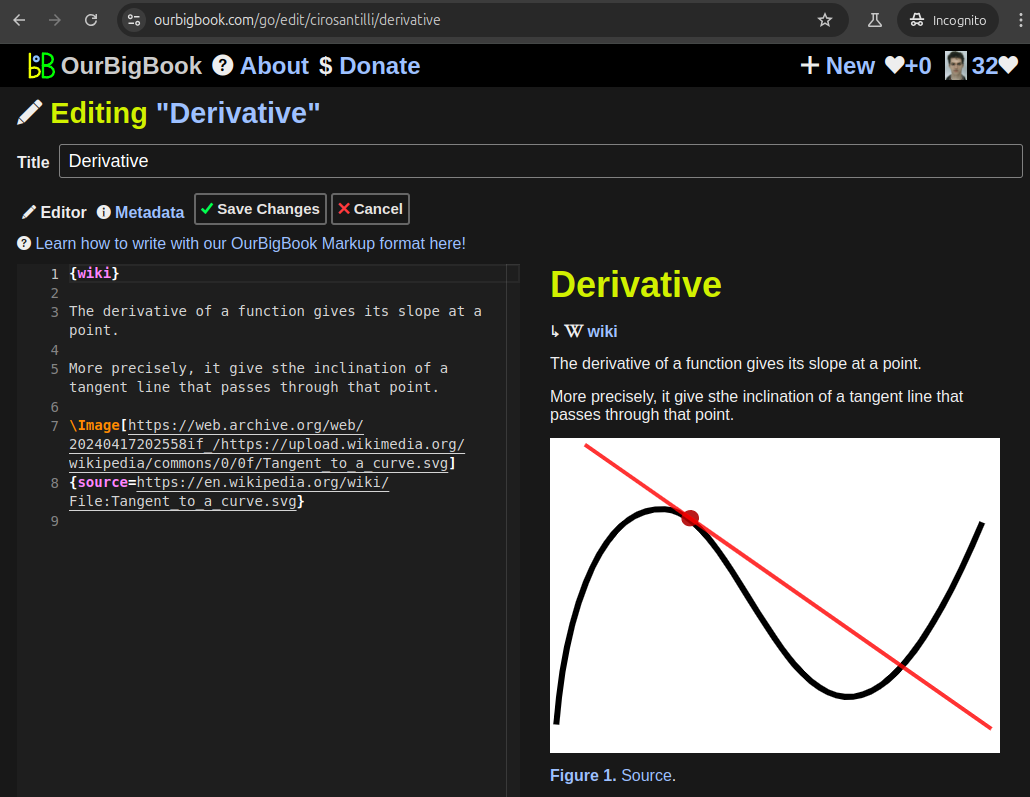
Figure 5. . You can also edit articles on the Web editor without installing anything locally. Video 3. Edit locally and publish demo. Source. This shows editing OurBigBook Markup and publishing it using the Visual Studio Code extension. 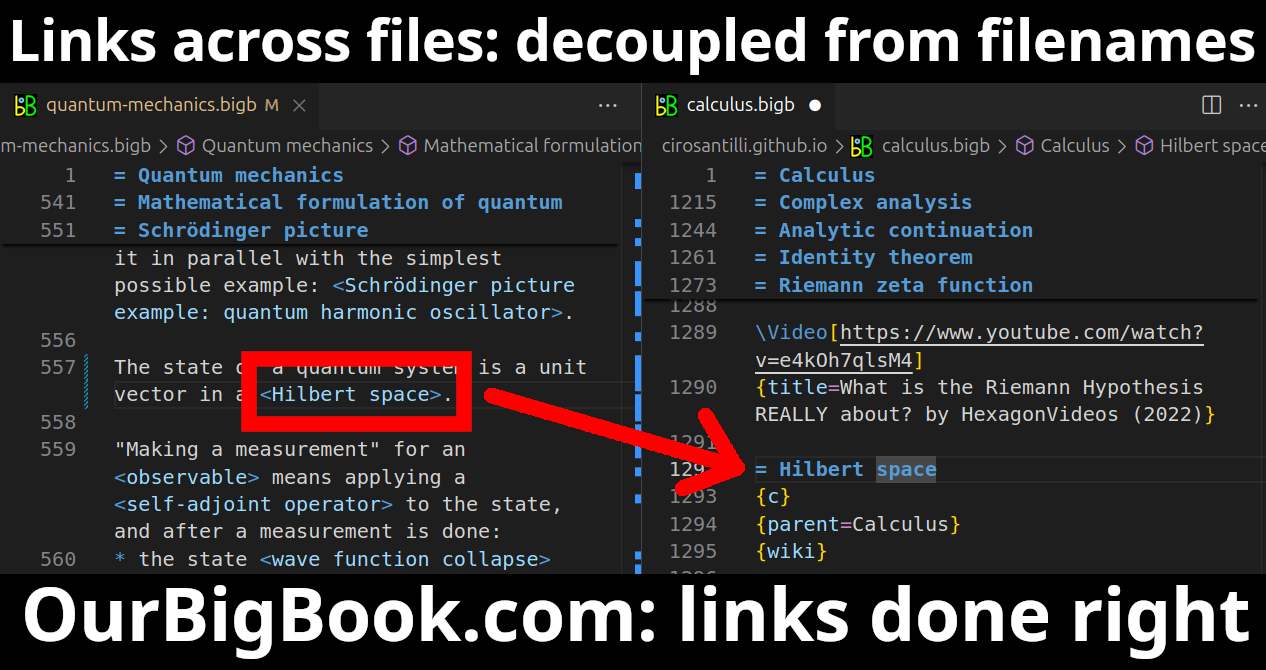
- Infinitely deep tables of contents:
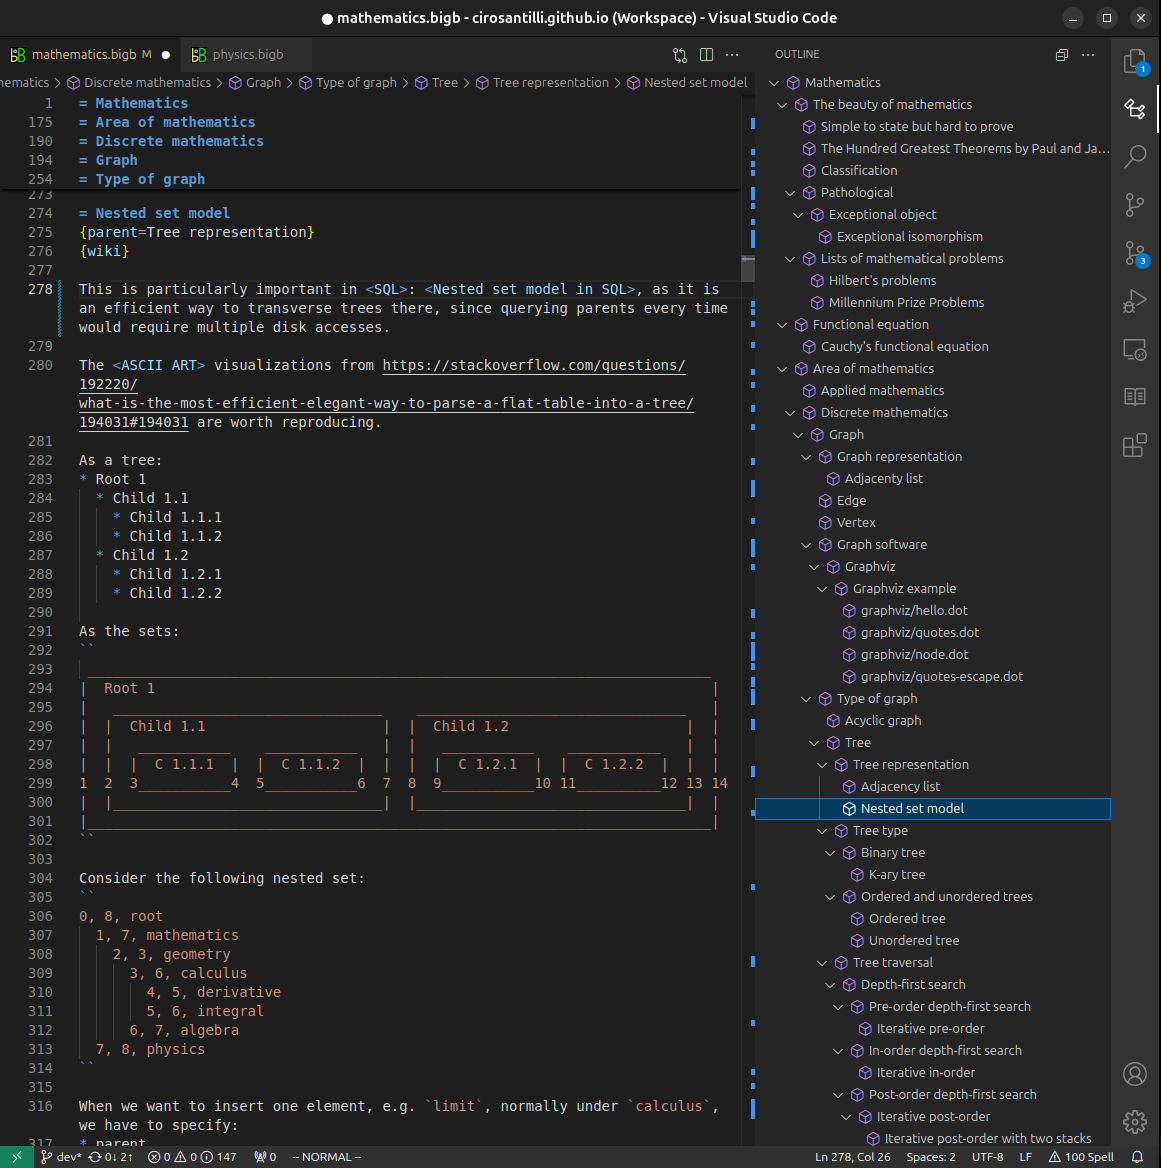
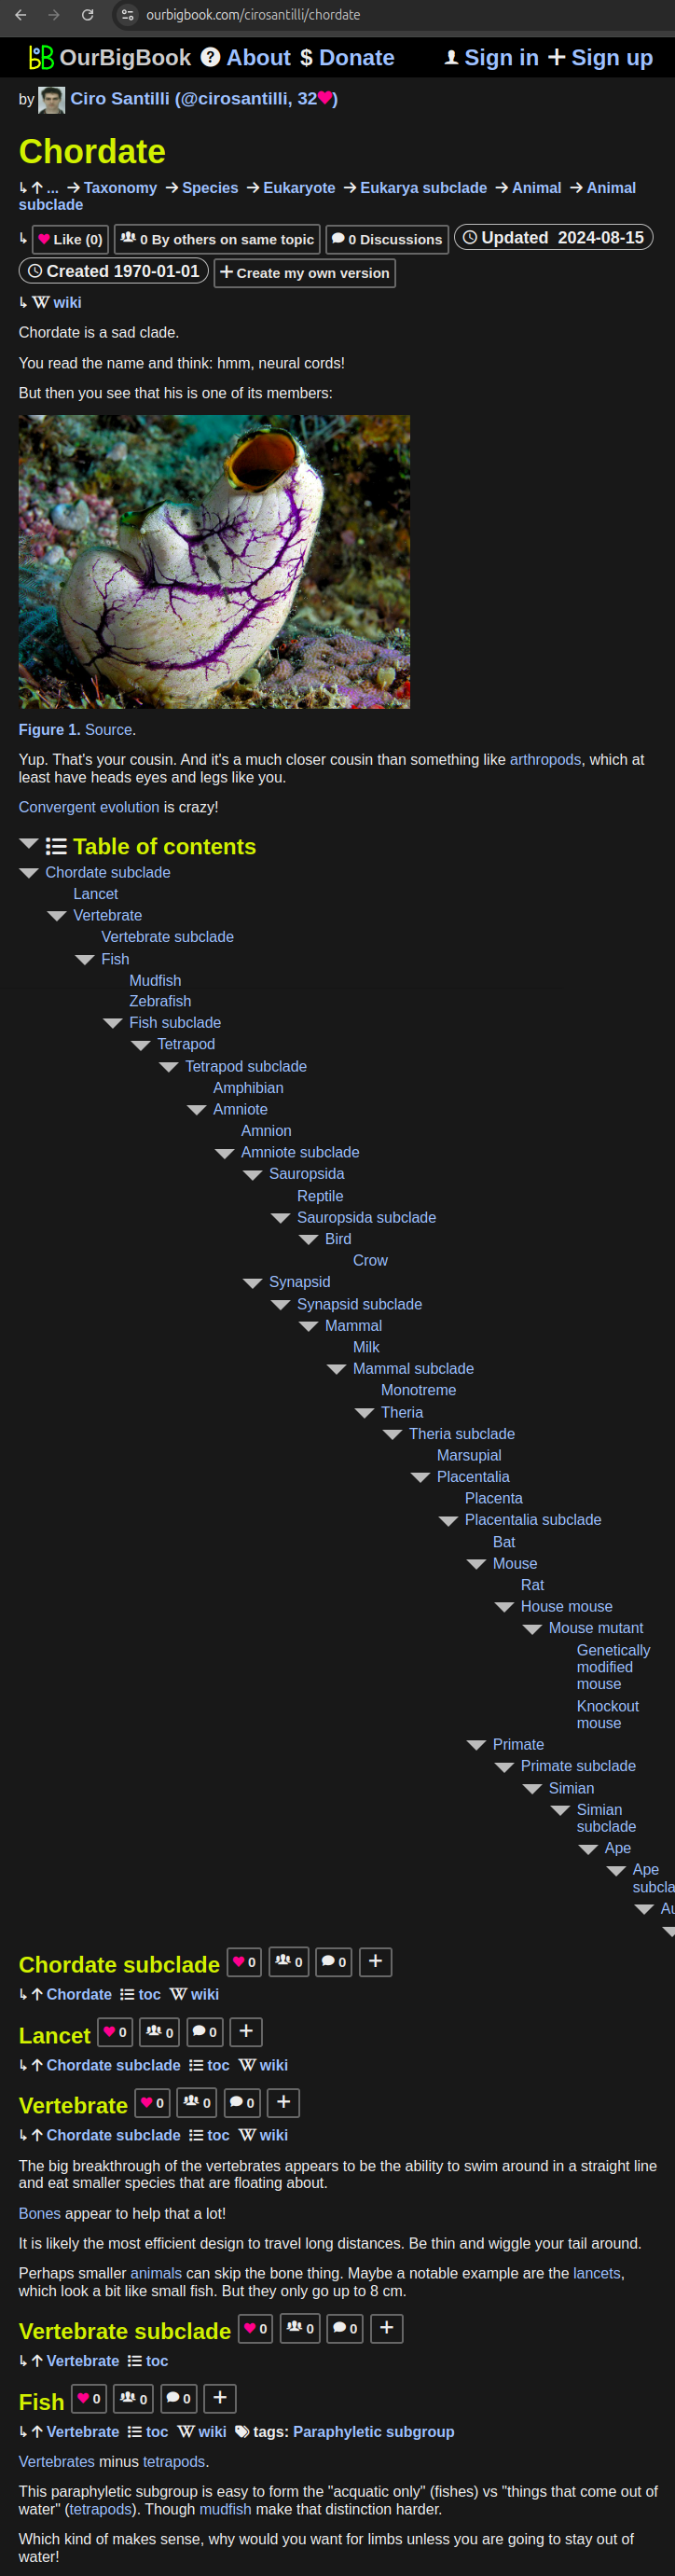

All our software is open source and hosted at: github.com/ourbigbook/ourbigbook
Further documentation can be found at: docs.ourbigbook.com
Feel free to reach our to us for any help or suggestions: docs.ourbigbook.com/#contact