
Self-adjoint differential operator Created 2026-09-24 Updated 2026-09-24
A differential operator is self-adjoint when integration by parts makes its inner products symmetric on its domain.
Sturm-Liouville problem Created 2026-09-24 Updated 2026-10-03
A regular Sturm-Liouville eigenvalue problem has the formon a bounded interval with self-adjoint boundary conditions and positive weight .
Dominant energy condition Created 2026-09-24 Updated 2026-09-28
The dominant energy condition requires the energy flux measured by every future-directed timelike observer to be future-directed and causal. Equivalently, for every pair of future-directed causal vectors and under the convention.
Weak energy condition Created 2026-09-24 Updated 2026-09-28
The weak energy condition requiresfor every timelike vector , so every observer measures nonnegative energy density.
Conserved Klein-Gordon scalar stress-energy ansatz Created 2026-09-24 Updated 2026-09-24
Null energy condition Created 2026-09-24 Updated 2026-09-28
The null energy condition requires for every null vector . Through the Einstein field equations this is equivalent to when the cosmological term is absent.
Streamline classification of a planar linear saddle or centre Created 2026-09-24 Updated 2026-10-06
For , the stream function gives hyperbolic streamlines and a saddle when , while gives elliptical streamlines and a centre.
Binary star Created 2026-09-24 Updated 2026-09-24
Stellar evolution Created 2026-09-24 Updated 2026-09-24
Stellar evolution is the change of a star's structure and composition as nuclear reactions, energy transport, mass loss, and interactions proceed.
Main sequence Created 2026-09-24 Updated 2026-09-24
Stellar nuclear fusion Created 2026-09-24 Updated 2026-09-24
Stellar nuclear fusion converts light nuclei into more tightly bound nuclei and supplies most main-sequence stellar luminosity.
Stellar structure Created 2026-09-24 Updated 2026-09-28
Stellar structure follows from mass conservation, hydrostatic equilibrium, energy generation, and energy transport together with an equation of state and opacity law.
Grouped exponential observation Created 2026-09-24 Updated 2026-10-14
Flooring an exponential variable of rate produces a geometric variable on the nonnegative integers with success probability .
Cramér-Rao bound Created 2026-09-24 Updated 2026-10-14
For a regular scalar model with score function and Fisher information , an estimator with mean satisfiesIndeed, differentiating gives , and the Cauchy-Schwarz inequality gives the bound.
Risk function Created 2026-09-24 Updated 2026-10-14
Bootstrapping (statistics) Created 2026-09-24 Updated 2026-10-18
The bootstrap approximates a sampling distribution by repeatedly sampling with replacement from the empirical measure of the observed data. In the ordinary nonparametric version, observations are assumed independent and identically distributed; a bootstrap sample has the same size as the original statistical sample. A statistic, such as a sample mean or sample median, is recomputed on each resample. Its variation across resamples estimates how the original statistic would vary across repeated sampling from the unknown probability distribution.[ref]
Lecture 12: The Bootstrap. UW STAT 535: Statistical Machine Learning, Autumn 2026; The Bootstrap, resampling procedure; High level idea of how bootstrap works, conditional empirical sampling law
The key distinction is between the observed statistical sample and its still-unknown source probability distribution. Condition on the observed values and form the empirical measureHere is a Dirac measure. Draw independent indices from the uniform distribution on a finite set and set . Each observed slot has probability on every draw. If equal values occupy several slots, their total probability is the sum of those slot probabilities; distinct observed values need not be equally likely. A star denotes this conditional resampling experiment. There are equally likely ordered index sequences, although bootstrap count vectors and statistics can combine many such sequences.
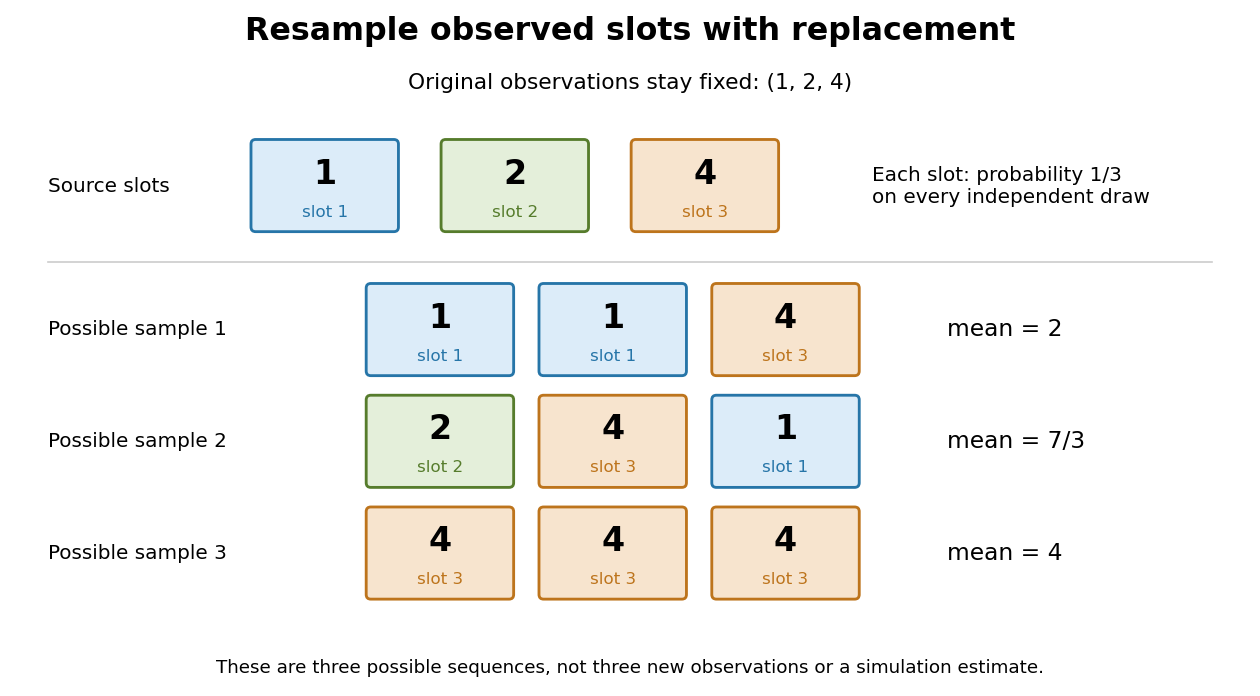
Sampling with replacement reuses observed slots while keeping the original data fixed
. Original schematic for observations . Three possible ordered bootstrap samples have different sample means. Their colors identify source slots; none of these samples is new evidence about the unknown probability distribution. Details.
A complicated sampling distribution need not stop statistical inference when recomputing the statistic is easy. The bootstrap reuses that calculation on simulated datasets. The plug-in estimator principle replaces the unknown probability measure by in the whole repeated-sampling experiment. Whether that substitution approximates the target sampling distribution needs an appropriate bootstrap consistency theorem for the sample mean or a result for the particular statistic. A larger number of resamples reduces Monte Carlo error; it cannot repair the bootstrap failure for a uniform endpoint, an unrepresentative statistical sample or ignored statistical dependence.[ref]
Lecture 12: The Bootstrap. UW STAT 535: Statistical Machine Learning, Autumn 2026; High level idea of how bootstrap works; Bootstrap and Statistical Functionals, conditional variance and bootstrap variance consistency; Failure of the bootstrap, uniform-endpoint counterexample
Quadratic discriminant analysis Created 2026-09-24 Updated 2026-09-24
Quadratic discriminant analysis uses class-conditional Gaussian distributions with class-dependent covariance matrices. Their log density ratio is a quadratic polynomial in the observation.
Linear discriminant analysis Created 2026-09-24 Updated 2026-10-03
LDA assumes class-conditional Gaussian distributions with a shared covariance matrix, producing affine log odds.
Gaussian conditional expectation Created 2026-09-24 Updated 2026-10-03
Logistic distribution Created 2026-09-24 Updated 2026-09-24
There are unlisted articles, also show them or only show them.