Gear contact ratio measures how much successive tooth engagements overlap. For an external spur gear pair, its transverse value iswhere is usable gear path of contact length along the gear line of action and is gear base pitch. One tooth pair remains engaged while contact advances through length ; successive pairs begin after an advance of . Thus is also the ideal mean number of tooth pairs simultaneously engaged.[ref]
For a tip-limited, noninterfering external involute pair with tip radii , base radii , axis separation and operating pressure angle , right-triangle geometry givesFor an original example, use module , tooth counts 20 and 40, reference angle and standard separation . With tip radii and , the formula gives and , hence .
In the ideal periodic timing model, two tooth pairs are engaged for about of a tooth-passage period and one pair for about . This does not mean that force is divided equally between engaged pairs: tooth flexibility and contact geometry affect load sharing. A value below one would leave gaps in ideal engagement, while a value exactly one leaves no overlap margin for tolerances and deformation.
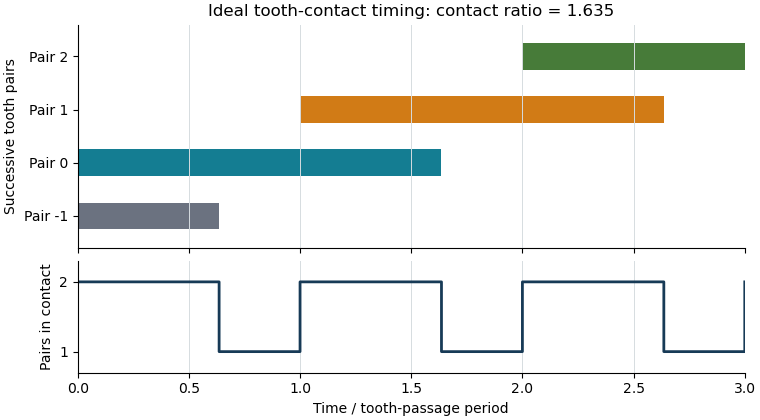

The plot shows contact timing, rather than physical tooth shapes or force sharing. For helical gears, the transverse measure must additionally be distinguished from gear overlap ratio caused by the inclination of teeth across the gear face. Finally, real usable contact can be shortened by modified or unavailable flank portions; the tip-circle formula is conditional on its stated geometric assumptions.
Gear overlap ratio measures the additional engagement overlap caused by a helical gear's tooth inclination across its gear face width. It is distinct from the transverse gear contact ratio, which measures contact length within one transverse section. For face width , reference gear helix angle and gear normal module ,where is gear transverse module and is gear axial pitch.[ref]
Elements of Metric Gear Technology by SDP-SI. §11, Table11-3, “Axial (Overlap) Contact Ratio”, helical-gear equation
Unwrapping the reference cylinder explains the ratio: moving across axial width shifts the tooth pattern circumferentially by . Dividing this shift by gear transverse pitch counts how many tooth spacings the engagement progresses across the face.
For an original example, , and giveDoubling the face width doubles this geometric overlap if the other parameters stay fixed. At the spur gear limit , the overlap contribution tends to zero.
In the ideal cylindrical-helical model, total geometric contact ratio is the sum of transverse and axial contributions, . This does not specify a uniform division of load: flexibility, alignment and the usable flank region affect actual contact. Increasing helix angle can improve overlap while also increasing gear axial force; increasing width also changes the alignment and support demands. These are related geometric tradeoffs, not a guarantee of a specified noise level or load capacity.
Articles by others on the same topic
There are currently no matching articles.