Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Isolated vertex
2-core of a graph Created 2026-10-14 Updated 2026-10-18
The 2-core is what remains of a finite simple graph after repeatedly removing every vertex with fewer than two surviving graph neighbours. It strips away dangling trees while keeping the part that can support itself under this local rule. Precisely, for an undirected graph , its 2-core is the unique maximum by set inclusion induced subgraph such thatThe empty vertex set is allowed: the condition is then vacuous, without needing to define the minimum degree of the empty graph. "Maximum by inclusion" means that contains every other vertex set satisfying the condition. It is stronger than merely saying that one chosen set cannot be enlarged: the 2-core simultaneously contains all possible qualifying induced subgraphs. In this particular family, every inclusion-maximal qualifying set does equal that unique maximum; the union argument in why the 2-core is unique explains why. [ref]
An O(m) Algorithm for Cores Decomposition of Networks by Vladimir Batagelj and Matjaž Zaveršnik. Batagelj and Zaveršnik, An O(m) Algorithm for Cores Decomposition of Networks, §2, definition of a core
For a complete worked example, let denote the edge and takeThe triangle in a graph has a branching tail attached at , and is an isolated vertex. In alphabetical order the initial degrees of vertices are . Deleting turns into a leaf of a graph; deleting leaves with degree of a vertex two; deleting changes no other degree of a vertex. Now delete , which makes a leaf of a graph, and finally delete . Exactly the three edges of remain: .
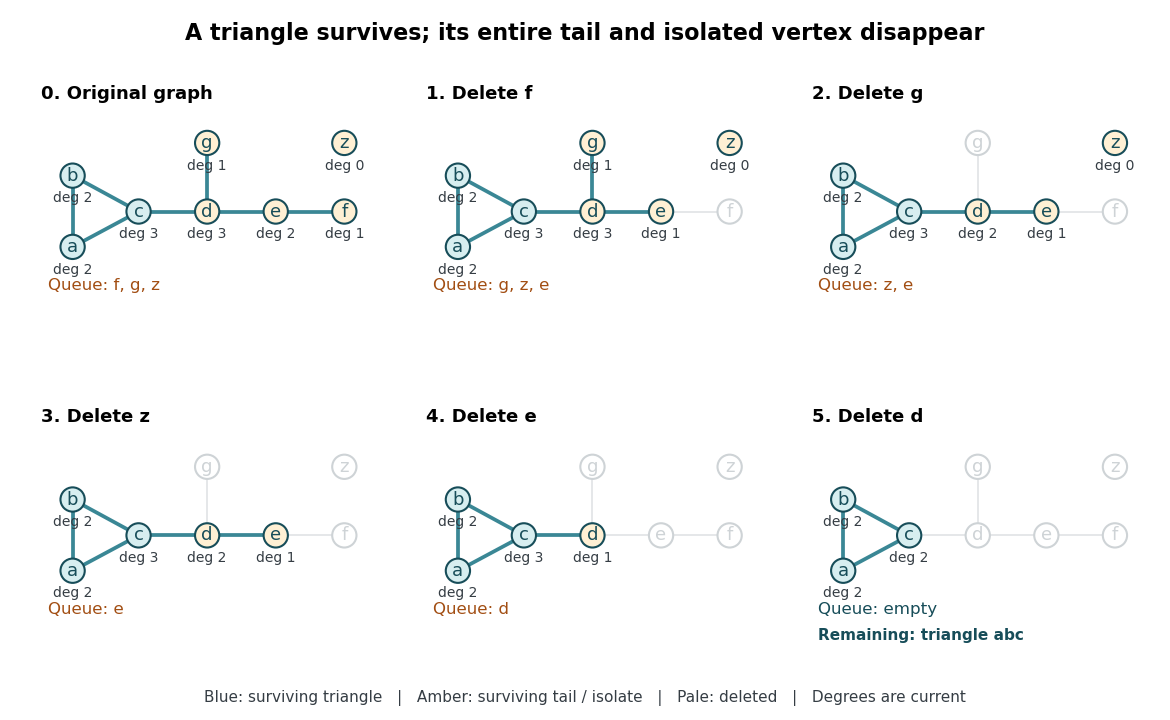
The complete leaf pruning for the 2-core trace: each panel recomputes the displayed degrees of vertices from the surviving induced subgraph, while the FIFO queue determines the next deletion
. Details. A forest has empty 2-core: every nonempty finite forest has an isolated vertex or a leaf of a graph, so deletion cannot stop at a nonempty remainder. In particular, an isolated edge, an isolated vertex, a path graph, and the empty graph all have empty 2-core. Every cycle graph is its own 2-core. Two disjoint triangles in a graph also form their own 2-core, so a 2-core need not be a connected graph; attaching a tree to either triangle changes neither surviving triangle.
Bipartite graph Created 2026-09-24 Updated 2026-10-14
A bipartite graph separates its vertices into two independent sets: every edge goes from one part to the other. Here is a finite simple graph and an undirected graph, with no self-loops and no repeated edges. The two parts satisfyThus neither part contains an edge. The parts need not have equal sizes, and some pairs across them may have no edge; requiring every cross pair gives a complete bipartite graph. The independent set and cross-edge definitions are equivalent.[ref]
The Basics (author-hosted chapter preview). Section 1.1, printed p. 3, independent vertices; Section 1.6, printed p. 17, bipartite and complete multipartite graphs
For example, the six-vertex cycle graph with edges has parts and . Drawing the same graph as a hexagon or in two columns changes neither its edges nor its bipartite property. An extra isolated vertex can go in either part.
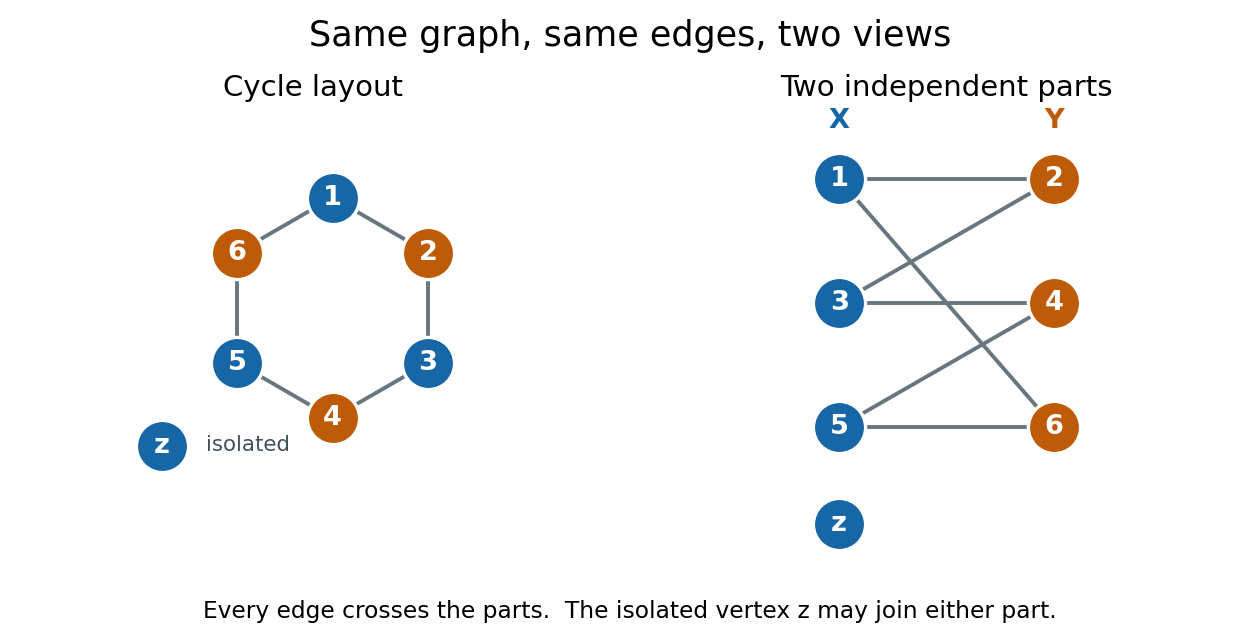
We allow either part to be empty. Consequently a graph with no edges is bipartite, even when ; choose , . Here "two colours" means two colours are available, with no requirement to use both. This convention explicitly includes the empty case, whereas definitions requiring two nonempty classes need an exception. For several connected components of a graph, choose the two parts separately in each graph component and take their unions. In a nonempty connected graph that is bipartite, fixing one vertex's colour forces all others along graph paths, so its two-colour assignment is unique up to swapping the colours. Each graph component, including an isolated vertex, can be swapped independently.
The two-colourability criterion for bipartite graphs identifies these parts with the colour classes of a proper vertex colouring: assign colour to and colour to , so adjacent vertices have different colours. More surprisingly, the odd-cycle characterization of bipartite graphs turns a global requirement into one precise obstruction:This statement is for the finite undirected graph and simple graph model above; a graph cycle has distinct vertices except for the repeated starting vertex. Along a graph cycle in a bipartite graph, colours alternate, so returning to the starting colour takes an even number of edges. Therefore any odd cycle, whether or not other edges join its vertices, prevents a bipartite split.[ref]
The Basics (author-hosted chapter preview). Section 1.6, Proposition 1.6.1 and proof, printed pp. 17–18
Breadth-first search supplies the converse constructively. Start an uncoloured vertex with colour , and use a FIFO queue to explore its graph component. When an edge first discovers , give the opposite colour to , record as its parent in a rooted tree, and enqueue . If both endpoints of any scanned edge already have the same colour, stop with a conflict. Restart from an uncoloured vertex until every graph component has been examined. If no conflict occurs, all edges cross the two colour classes, which are the required independent sets.[ref]
A conflict also explains the failure. In the rooted tree produced by breadth-first search, let be the graph distance from . The colour of is its distance's integer parity. An edge in an undirected graph satisfies , so equal colours force . Follow the two parent chains upward to their lowest common ancestor , discard the shared graph path from to , and join the remaining two graph paths with the conflict edge . The result is a genuine graph cycle withedges, an odd integer. The two branches have no shared vertices except , so this is more than a closed walk. This odd cycle is a certificate that anyone can check directly, using only its listed vertices and edges.
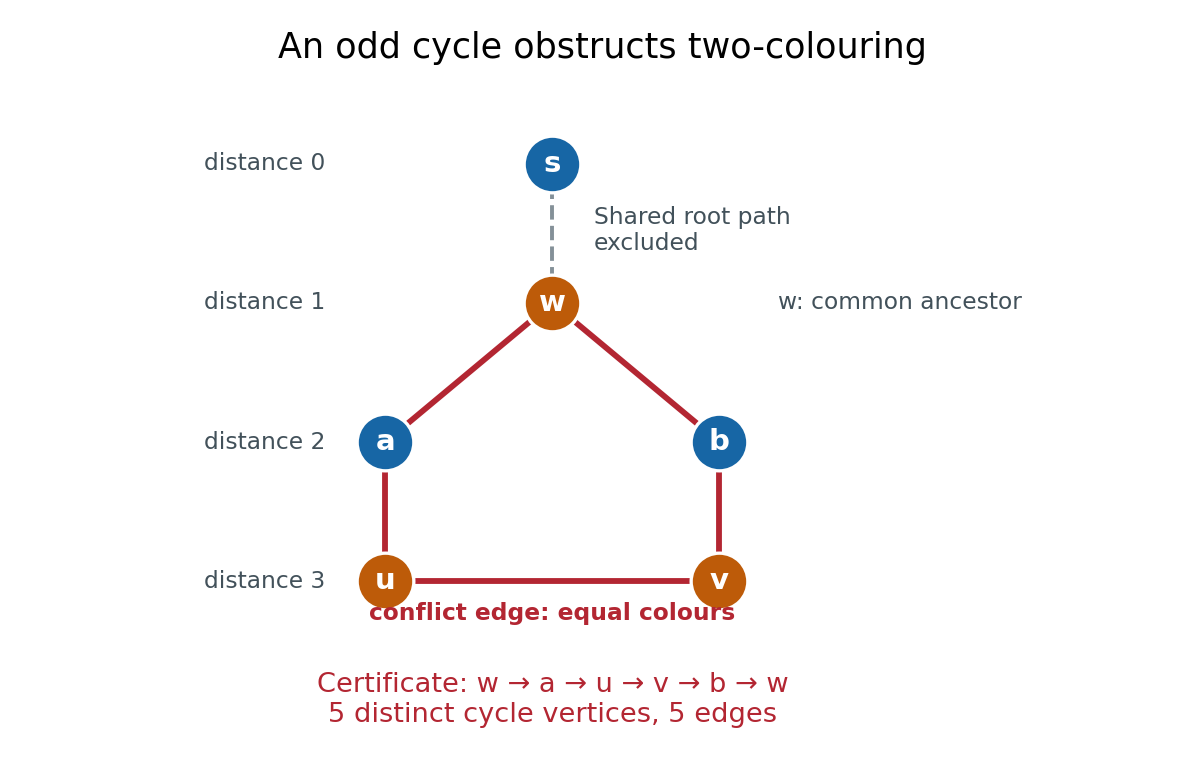


In the example, breadth-first search from gives , , and . The conflict edge closes the odd cycle , with five edges. The common edge is excluded. Thus the same procedure returns either two independent sets covering , or an explicit odd cycle. With adjacency lists and constant-time FIFO queue operations, its time complexity is in Big O notation, with additional storage.[ref]
The two parts often have a practical meaning: workers and jobs, with an edge exactly when a worker can perform a job. A matching in a graph chooses compatible worker–job pairs with no reused endpoint; merely being bipartite does not guarantee enough compatible pairs. Hall's marriage theorem characterizes when every worker can be matched, and the assignment problem adds costs to seek an optimal assignment. These connections make the bipartite structure useful after recognition, as the starting point for selecting edges under constraints.
Bipartition of a graph 2026-10-25
A bipartition of a graph divides its vertex set into two independent sets, so every edge joins different parts. A graph admitting such a partition of a set is a bipartite graph. The two parts are not generally unique: separate connected components of a graph can have their sides exchanged independently, and isolated vertices can be assigned to either part.
For fixed real , the number of isolated vertices in a binomial random graph with converges to a Poisson distribution of mean . Its fixed factorial moments tend to . A union bound for small connected components, together with exclusion of intermediate components, shows that isolated vertices are asymptotically the only obstruction to connectivity. Thus the displayed limit is the zero-mass of that Poisson distribution.
Edge cover 2026-10-24
An edge cover of a finite graph is a subset of its edges incident to every vertex. It exists if and only if there is no isolated vertex, with the empty graph covered by the empty set. A minimum-cardinality edge cover uses as few edges as possible; a minimum-weight edge cover minimizes their total weight. These objectives are related to maximum cardinality matching and maximum-weight matching, respectively, by the edge cover and matching identity and minimum-weight edge cover by matching savings.
Edge cover and matching identity 2026-10-25
If a finite graph has no isolated vertex, its minimum edge cover cardinality and matching number sum to its number of vertices.
Proof. Start with a maximum cardinality matching . Its unmatched vertices in a matching form an independent set, since an edge between two of them could be added. Add one incident edge for each such vertex. They are distinct, giving an edge cover of size .
Conversely, in any inclusion-minimal edge cover , every edge has an endpoint of vertex degree one in ; otherwise it could be removed. Thus each component is a star graph: two vertices of vertex degree at least two in one component would produce a graph path containing an edge with both endpoints of vertex degree at least two. If there are components, . Selecting one edge from each star graph gives a matching in a graph of size , so and . A minimum-cardinality edge cover is inclusion-minimal, completing the proof. The constructive first half also gives a polynomial-time algorithm once a maximum cardinality matching is available.
Edge support of a graph 2026-10-14
For a finite undirected multigraph , its edge support of a graph is the subgraph with . It removes exactly the isolated vertices, retaining every edge, including self-loops and parallel edges. When , connectivity of this subgraph is the relevant condition for an Eulerian trail or Euler circuit.
If every pair of graphs in a family on has a graph intersection without an isolated vertex, the family has at most members. At each vertex, its possible graph neighbourhoods form an intersecting family, of size at most . Every edge occurs in two such neighbourhood projections. Shearer inequality bounds twice the full information entropy by the sum of their information entropies.
Euler circuit Created 2026-10-07 Updated 2026-10-14
An Euler circuit, also called an Euler tour, is an Eulerian trail whose final vertex equals its initial vertex. Its length is . It can revisit other vertices, unlike a Hamiltonian cycle, which visits each vertex once before returning to the start. For a finite undirected multigraph with at least one edge, an Euler circuit exists exactly when the edge support of a graph is a connected graph and every vertex degree is even.
For example, let be distinct parallel edges joining , let be a self-loop at , and add an isolated vertex . Then , and is an Euler tour. The self-loop supplies one traversal and two incidences; need not be visited. Replacing by a single edge changes both vertex degrees to odd numbers and removes the possibility of an Euler circuit. Thus collapsing parallel edges can change the answer.
Two triangles in a graph sharing one vertex give another instructive Euler circuit: . The shared vertex has vertex degree four, the others have vertex degree two, and is revisited between the two closed trails. This is precisely the splice used by Hierholzer's algorithm.
Eulerian graph Created 2026-09-24 Updated 2026-10-14
An Eulerian graph has an Euler circuit: a closed trail traversing every edge exactly once. Here the graph is a finite undirected graph, possibly a multigraph with self-loops. Parallel edges retain distinct identities, and each self-loop contributes two to its vertex degree. Repeated vertices are allowed. This models inspecting every road segment once, even when a junction must be revisited.
For a nonempty set of edges, the Euler circuit criterion requires a connected graph only on the edge support of a graph: isolated vertices impose no travel requirement. A single vertex with a self-loop and two vertices joined by two parallel edges are both Eulerian graphs. Neither requires three vertices. With no edges and at least one vertex, we allow the zero-length trail at that vertex as an Euler circuit; the graph with no vertices has no such walk.
The motivating Seven Bridges of Königsberg problem asks for an Eulerian trail, which need not return to its starting vertex. In Leonhard Euler's Solutio problematis ad geometriam situs pertinentis by Leonhard Euler, §2 poses the bridge-crossing question and §§4–6 encode land regions by letters. The river's shape drops out: only the connections matter. The paper was written in 1735 and published in 1741, according to the Euler Archive; the journal volume carries the nominal year 1736.[ref]
Eulerian trail 2026-10-14
An Eulerian trail, also called an Eulerian path, is a trail in a graph traversing every edge exactly once. The name Eulerian path does not require a graph path: vertices may repeat. A Hamiltonian path instead visits every vertex exactly once, and may omit edges. An Eulerian trail may omit isolated vertices, so these are different coverage requirements.
For a finite undirected multigraph with at least one edge, allowing self-loops, an Eulerian trail exists exactly when the edge support of a graph is a connected graph and there are zero or two vertices of odd vertex degree. In the two-odd-vertex case they must be the two distinct endpoints; in the zero-odd-vertex case every Eulerian trail is an Euler circuit. Count a self-loop twice in the vertex degree but once in the trail, and count each parallel edge separately.[ref]
Math 530 Spring 2023, Lecture 6: Multigraphs and digraphs. pp. 1–3, Theorem 1.1.2 and the note about isolated vertices
The parity obstruction is local: each intermediate visit pairs an arriving edge with a departing edge. Only the distinct endpoints can have an unpaired incidence. The handshaking lemma, , also shows that the number of vertices with odd vertex degree is even. Sufficiency in the two-endpoint case reduces to the Euler circuit criterion: add one extra edge between the odd vertices, construct an Euler circuit, rotate its record to start with the extra edge, then delete that edge. The remaining trail has the required endpoints.
For the Seven Bridges of Königsberg multigraph, the vertex degrees at are , so no Eulerian trail exists. Remove the unique edge : the vertex degrees become , and a six-edge Eulerian trail runs from to . Label the parallel edges between and between ; label by and by . A complete record is . It revisits while using every remaining edge once.
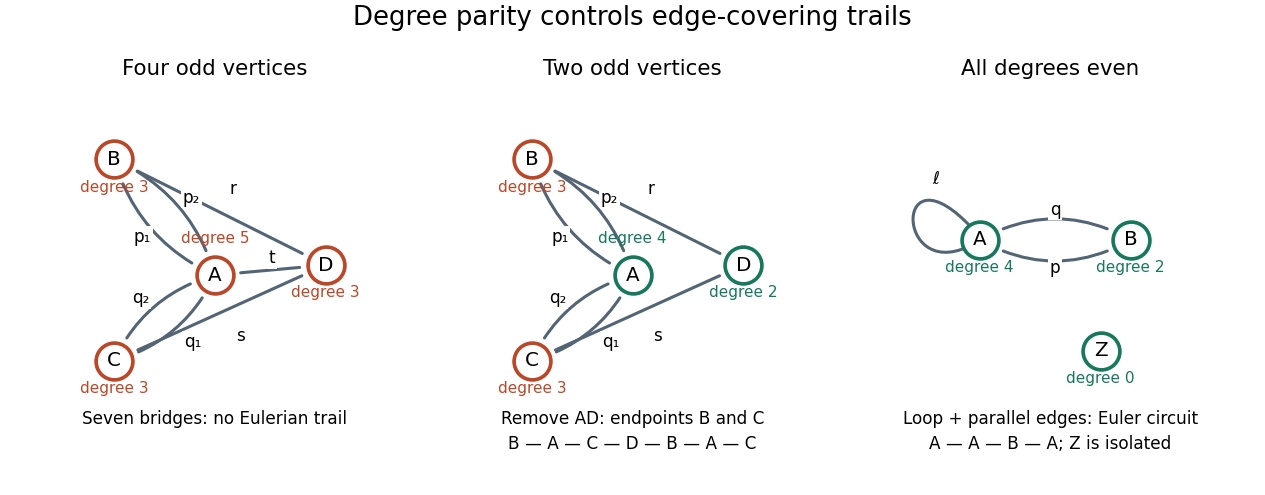
Four odd vertex degrees forbid an Eulerian trail; two allow distinct endpoints; zero allow an Euler circuit
. Details. 
Hall obstruction 2026-10-14
A Hall obstruction is a left subset with fewer distinct neighbours than vertices. At most members of can be matched, so at least must remain unmatched. The pigeonhole principle proves failure without enumerating every proposed assignment.
For a stronger counterexample than an isolated vertex, take and withEvery vertex has positive degree of a vertex, the sides have equal cardinality, and . Every two-vertex left subset also passes the Hall condition. Nevertheless has only , so rules out matching saturation of .
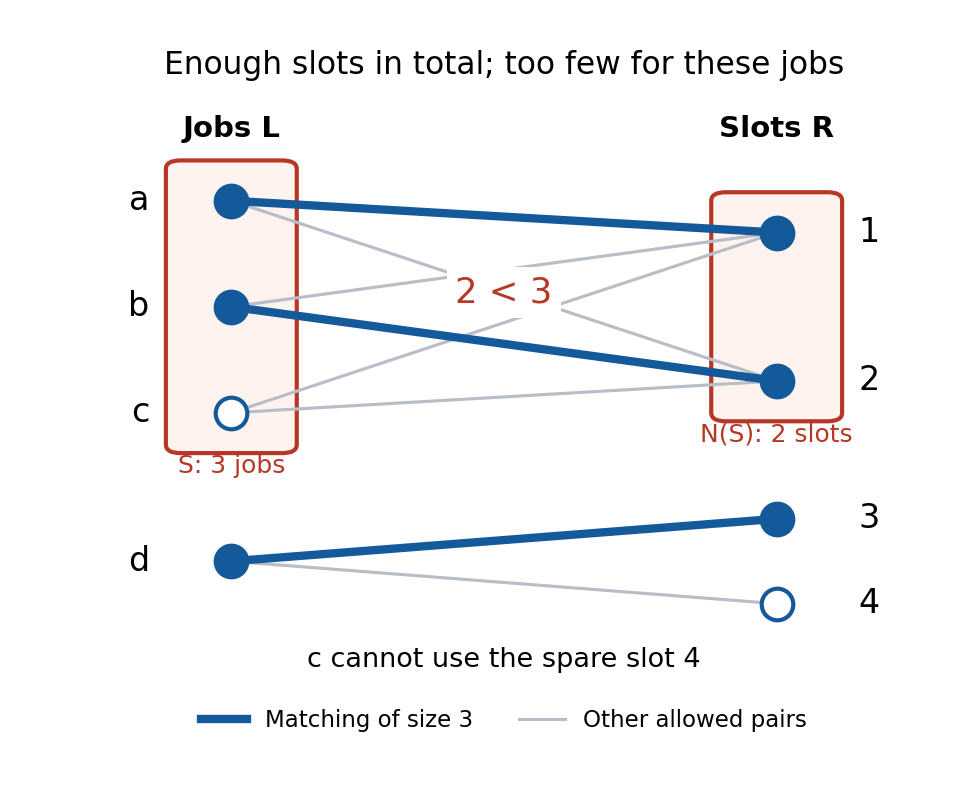

All sixteen left subsets can be checked by writing and if , otherwise . ThenOnly violates the Hall condition. Every matching in a graph uses at most two edges incident to and at most one incident to , so the matching number is three. There are exactly twelve size-three matchings in a graph: choose two of in three ways, assign them to in two ways, and choose or for . Thus the obstruction identifies the bottleneck: adding availability only for cannot help; allowing to use slot permits , a perfect matching.
Independent vertex cover 2026-10-25
An independent vertex cover is a vertex cover that is also an independent set. Its complement is an independent set as well, since the cover condition forbids edges entirely in that complement. Thus such a cover is a side of a bipartition of the graph. This standard definition is stronger than independent dominating set on graphs without isolated vertices, and remains a different notion when isolated vertices are present. In a nonempty simple graph, two possibly repeated witnesses with and no edge outside express existence of an independent vertex cover of size at most two.
Leaf pruning for the 2-core 2026-10-18
Use adjacency lists and a FIFO queue to implement the deletion rule in time complexity . Compute each initial degree of a vertex once, mark every vertex alive, and put all vertices of degree of a vertex zero or one in the FIFO queue. Each vertex is inserted at most once. Repeatedly remove the front vertex , mark it dead, and traverse its original adjacency list. For each still-alive graph neighbour , decrease the stored degree of a vertex of by one; if it has just become one, append . A vertex already queued can drop from one to zero before its turn, but it stays queued and requires no second insertion. Stop when the FIFO queue is empty; the alive vertices induce .
For the displayed example, initially enqueue in that order. The successive FIFO queues, after each deletion and all its updates, areThis explains the delayed deletion of : its initial degree of a vertex was three, but the relevant degree of a vertex is always its current one in the surviving induced subgraph. Removing only the original vertices of degree of a vertex one would give the wrong answer.
Initialization inspects every vertex and every adjacency list entry once. During deletion each original adjacency list is traversed at most once, so at most entries are inspected in an undirected graph. All insertions, removals and stored-degree updates cost constant time each. Thus total time complexity is and additional storage, beyond the adjacency lists, is . The cost includes isolated vertices; repeatedly rescanning the whole surviving graph after each deletion would lose this bound. The single-threshold FIFO queue method is enough for the 2-core; the full k-core of a graph decomposition computes all thresholds.
Logarithmic-regime giant component 2026-10-07
Fix , , and with . A binomial random graph has one giant component of the displayed order and all other graph components are tree components of orders at most , with high probability. The expected value and variance of the isolated vertex count concentrate it around . A Cayley formula upper bound for connected sets excludes component sizes through a small fixed fraction of ; the empty-graph cut bound excludes the remaining sizes up to . An extra-edge count excludes cyclic small graph components. The expected value of the number of vertices in small nonisolated tree components is , where . The Markov inequality completes the count of vertices outside the unique large graph component.
Marked-set connectivity threshold Created 2026-10-07 Updated 2026-10-14
For a fixed set of vertices, let be the first step at which they all belong to one graph component. In the uniform random graph process, lies between and with high probability for every . Below that scale the marked isolated vertex count has divergent expected value and small relative variance. Above it the logarithmic-regime giant component misses vertices; exchangeability and a union bound show that none are marked. The label coupling then transfers the two assertions to the process.
Minimum-weight edge cover 2026-10-25
An edge cover minimizing the sum of selected edge weights. For nonnegative weights and no isolated vertex, it is computable in polynomial time by the minimum-weight edge cover by matching savings construction. It need not have minimum cardinality.
For a finite graph without an isolated vertex and with nonnegative edge weights, put and let attain this minimum. Define savings and baseline . A maximum-weight matching with weights , allowing arbitrary cardinality, gives a minimum-weight edge coverIt replaces separate cheapest coverage of two endpoints by a shared edge when doing so saves enough weight. Savings can be negative even though original costs are nonnegative; such edges need not be selected.
Proof. The construction covers all vertices. Duplicate selected edges are counted once, so nonnegative weights give . Take an optimal edge cover and delete redundant edges to make it inclusion-minimal without increasing cost. Its components are star graphs, by the argument for the edge cover and matching identity. Select one edge from each component to obtain a matching in a graph . A component with center , selected leaf and other leaves contributes to , at most its total edge weight since . Thus . Maximizing giveswhich proves both the construction and the displayed identity, including zero-weight cases. One call to a general-graph maximum-weight matching polynomial-time algorithm suffices, together with linear-time preprocessing. Choosing a maximum cardinality matching under these modified weights would impose an unnecessary constraint and can spoil the reduction.[ref]
Maximum-weight matching documentation by NetworkX. max_weight_matching, maxcardinality=False, and Notes on polynomial running time
Mycielskian chromatic increase 2026-10-14
For a nonempty finite simple graph, the upper bound copies an optimal proper vertex colouring to its Mycielski shadow vertices and gives the Mycielski apex a fresh colour. For the lower bound, suppose uses colours, with coloured . Shadows avoid . Replace colour at each original by 's colour. Changed originals form an independent set; unchanged neighbours differ because is an edge. This proper vertex colouring of uses colours, contradicting its chromatic number.[ref]
Mycielski graphs and PR proofs by Emre Yolcu and others. §4.1, Proposition 1 and proof, manuscript pp. 6–7
The nonempty condition means , not . An edgeless -vertex graph with has chromatic number one; its Mycielskian is a star graph on together with isolated vertices, and needs two colours. If has no vertices, is a single vertex, so the same formula also holds with the convention .
Past exam of the computer science course of the University of Oxford 2018 Algorithms 3 b Solution 2026-10-31
Let be the set of isolated vertices of the finite simple graph . Introduce a nonnegative integer for every vertex. Use the integer programEvery nonisolated vertex belongs to an edge, whose inequality and the other endpoint's nonnegativity already imply . The explicit bounds on therefore make all variables binary. For an integer feasible point, is an independent set, and its cardinality is the objective. Conversely the indicator vector of any independent set is feasible. Thus the optimal value is the maximum independent set size. Including the isolated-vertex bounds is essential for an arbitrary graph; without them the formulation would be unbounded whenever an isolated vertex is present.