The rotating-frame derivative formula is . Applying it twice to the position vector, with constant angular velocity, givesSolving for identifies the displayed terms: its left side is the acceleration relative to the rotating reference frame, the first right-hand term is the inertial acceleration, is the Coriolis acceleration, and is the outward centrifugal acceleration.
For a particle of mass , replace by the actual force divided by using Newton's second law. The remaining terms then appear as apparent forces in . There is no Euler acceleration because is constant and no translational acceleration term because the common origin is fixed in the inertial frame.
The original PDF measures at the rim point , from the positive -axis to ; it is not the angle at the centre of the circle. The converted TeX omits this entire subpart. In rotating Cartesian coordinate system, the centre is , and the nonzero intersection of the ray with has . ThereforeThe second form stays regular even at the rim point , where the polar radius is zero. Define the outward unit normal from the centre and the increasing-angle unit tangent vector byThe first two derivatives in the rotating reference frame are and . These describe a bead on a horizontal hoop rotating about its rim.
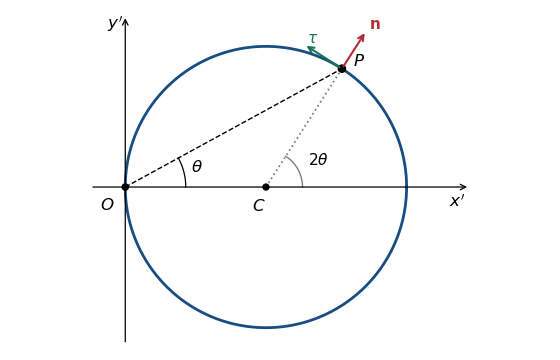
Because the contact is frictionless, the horizontal normal force is , with a signed outward component. Any vertical contact component balances Newtonian gravity and does not enter the horizontal equations. With , the rotating reference frame equation givesSince , , and , its normal and tangential components areHence the requested horizontal force vector isIts magnitude is the absolute value of the scalar coefficient. That coefficient need not always be negative: the constraint can exert either sign of normal force, depending on the bead's relative velocity. The tangential equation, which does not contain the reaction, is .
For nonzero , the equilibrium points satisfy . The equilibrium point is stable: it puts the bead at the point farthest from the rotation axis. Writing small in the tangential ordinary differential equation givesThus the small oscillation is simple harmonic motion, with angular frequency and ordinary frequency .
The endpoints represent the same rim point . A perturbation there instead satisfies and is unstable. Equivalently, the centrifugal potential along the hoop is , whose minimum is at zero and maximum at . If , every bead position with zero relative velocity is an equilibrium point, but perturbing that velocity produces unrestored drift; there is no nonzero restoring frequency.
Articles by others on the same topic
There are currently no matching articles.