
Write and . For a real variation, with ,Suitable endpoint conditions are homogeneous Dirichlet boundary conditions, homogeneous Neumann boundary conditions , or one of each. They remove the variation boundary term and the product . Stationarity for all interior variations is equivalent toConversely, multiplication of an eigenfunction equation by and integration by parts gives , hence . General Robin data require their boundary-energy contributions unless these endpoint products happen to vanish.
Use an eigenbasis orthonormal with respect to the weight: . For complex coefficients use the Hermitian version of the quotient, with absolute squares. Self-adjointness givesWhen , dividing numerator and denominator by yieldsIf , these ratios are undefined, but the unscaled formula and upper-bound conclusion remain valid. The assumptions are a problem with a self-adjoint operator bounded below and a complete eigenbasis, with the trial function in its energy-form domain. The Rayleigh-Ritz method minimizes this quotient over an admissible trial family, obtaining an upper bound on . Higher eigenfunctions are stationary directions and need not be unrestricted extrema.
Use the full field in the PDF, including the exponential term missing from the transcription. Its divergence isThe exponential in the third component has zero derivative. In cylindrical coordinates, the solid has and . Therefore the divergence theorem gives the outward fluxThe integration includes the entire closed boundary, both cap and base.
For a sufficiently smooth vector field on a volume with piecewise smooth closed boundary and outward unit normal vector, the divergence theorem statesExpanding the divergence of a cross product by the product rule gives . Apply the theorem to to obtain
Work in a Cartesian coordinate system, write , and use the Einstein summation convention. For a twice continuously differentiable vector field, the contraction of two Levi-Civita symbols givesHere the Kronecker deltas select components, and equality of mixed partial derivatives gives the curl of the curl identityFor the second identity, the same contraction followed by the product rule yieldsThus the curl of a cross product isThe directional derivatives in the last two terms act on the vector field immediately to their right.
Label the triangle vertices counterclockwise. Let rotate by counterclockwise and let reflect across the line through vertex 1 and the midpoint of the opposite side. The dihedral group has elements , with and .
The action on vertices identifies them with these permutations, with the rightmost operation applied first:The minimal number of generators is two, and is one minimal generating set. They produce every displayed element. A one-element generating set would make the group cyclic, but every nonidentity element has order two or three, never six.
The vertex-action map preserves composition, hence is a group homomorphism from to the symmetric group . The displayed actions are all six distinct permutations of three vertices, so the map is both injective and surjective. ThereforeThis identification uses the convention , with the subscript counting polygon vertices.
The image of a group homomorphism contains . If and lie in the image, then also lies there. The subgroup test proves .
The kernel of a group homomorphism is . It is nonempty and closed under for , so it is a subgroup. For any and ,Thus . Replacing by gives the reverse inclusion, provingFinally, if and , then . Thus forces , establishing injectivity. Conversely an injective homomorphism has trivial kernel, soNone of these arguments requires either group to be finite.
A subgroup is a normal subgroup when conjugation by every group element preserves it:Equivalently, for every ; normality permits the cosets to inherit a quotient-group multiplication.
A group homomorphism is a map preserving multiplication:It consequently sends identity to identity and inverses to inverses, since and .
For the intended finite nontrivial case, let have composite order . Choose a prime divisor of , with . Thenis a nontrivial proper cyclic subgroup of order . Indeed , and no smaller positive power is the identity because has order . Thus .
If the source also allows an infinite cyclic group, is a proper cyclic subgroup: its powers have even exponents and do not include . The trivial group, of order one, is an exception to the literal formulation “not of prime order”: it has no proper subgroup at all. The nontriviality assumption is therefore necessary for that general wording. These facts are instances of subgroups and quotients of a cyclic group.
Let be prime and choose . Its order divides by part (iii), and cannot be one. Hence its order is , so its generated subgroup has the same number of elements as the whole group:This proves that a group of prime order is cyclic. In fact every nonidentity element is a generator. No commutativity assumption was needed; it follows from cyclicity.
The order of a group element is the least positive integer such that , or infinity if there is no such integer. In a finite group such a exists, because two powers among must coincide.
The powers are distinct: a repetition with exponents differing by less than would contradict its minimality. Division of any exponent by shows that these are all the elements of the cyclic subgroup . Thus . Applying Lagrange's theorem givesIn particular the identity has order one, and every nonidentity element has order greater than one. The divisibility assertion here concerns finite group order.
Interpret the functions as maps on , so every reciprocal is defined. Let , , and . With the left factor applied last, direct function composition gives the Cayley tableThe table proves closure and identifies as the identity. Every element is its own inverse. Associativity is inherited from composition of maps, so the set is a group. The three nonidentity elements are commuting involutions.
Its subgroups areThere are no others: a subgroup containing two distinct nonidentity elements also contains their product, the third, and hence is the whole group; a subgroup containing just one has order two.
The abstract dihedral group has commuting generators with , for example a rectangle's half-turn and reflection in one axis. The assignment , , , respects products and is bijective. ThusThis is the group generated by sign reversal and reciprocation, a realization of the Klein four-group. The nonzero domain is essential; treating these as functions defined at zero would not give the stated group.
Since both initial displacements vanish, only sine terms are needed. Resolve the velocity into the two normal modes:Each modal initial velocity must be divided by its angular frequency to obtain its displacement amplitude. ThereforeExplicitly,At zero, both displacements vanish and differentiation gives . The motion combines the in-phase and out-of-phase modes, with opposite signed modal velocity coefficients. Their different frequencies produce changing constructive and destructive interference in the physical coordinates, so motion is transferred through the coupling spring. This does not require assuming equal masses or exact periodic transfer of all the energy.
The displacement directions specified at release give . Let . By initial-data decomposition into two normal modes, write . Solving the two coordinate equations givesZero initial velocities remove the sine terms, soIn components,Substitution at zero gives , , and both derivatives vanish. For unequal masses both normal modes are generally present. When , , , so only the higher mode survives: and .
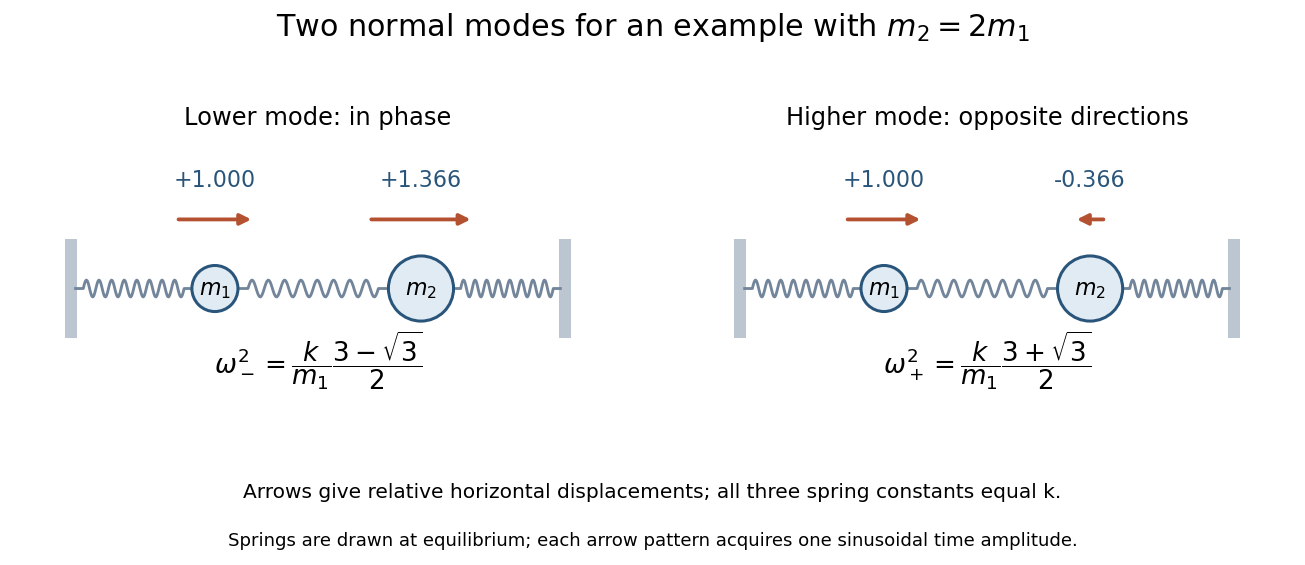
Take both displacement coordinates positive to the right. The kinetic energy and elastic potential energy areThus the equations of motion are and . With , the generalized eigenvalue problem for small oscillations isIts determinant gives . Put . The two-mass three-spring normal modes haveBoth squared frequencies are positive because . Also , so and : the lower mode moves the masses in phase, and the higher mode moves them oppositely. A general mode is an arbitrary sinusoidal amplitude multiplying its fixed shape.
For equal masses these reduce to , and , . For unequal masses the vectors need not be Euclidean-orthogonal; they are orthogonal in the mass inner product, .

Write the curl and cross product with the Levi-Civita symbol, then use its contraction identity:Expanding with the product rule givesRecognize the divergence in the first and third terms, and the directional derivatives in the other two. The curl of a cross product identity is thereforeThe derivatives act on both vector fields. No assumption of vanishing divergence or spatially constant fields has been made.
Start from the three-index transformation law and contract the first two Cartesian indices:Orthogonality supplies , where is the Kronecker delta. The remaining factor is exactly the vector transformation rule. Therefore is a vector.
This tensor contraction removes two indices by pairing them through the Euclidean metric. In general nonorthonormal coordinates, contraction must use the appropriate metric or pair a covariant and a contravariant index; the bare repeated-lower-index sum relies on Cartesian orthonormal coordinates.
Let be the rank-two tensor and the vector. The components of their tensor product are . Applying the transformation rules givesThe product therefore obeys the three-index tensor component transformation law, proving that is a rank-three tensor. Tensor-product order adds because no pair of indices is summed out.
The tensor contraction of a symmetric tensor with an antisymmetric one vanishes. Rename the two summed indices and use their opposite exchange symmetries:Hence . Using the decomposition from part (iii) givesThis is orthogonality of the real symmetric and antisymmetric matrix subspaces under the Frobenius inner product. It is a summed scalar identity, not an assertion about the unsummed products of individual entries.
Adding and subtracting the transpose uniquely separates a Cartesian second-rank tensor into its symmetric tensor and antisymmetric tensor parts:Then , and . Both parts transform as tensors because transposition commutes with the orthogonal similarity . Uniqueness follows by taking the symmetric and antisymmetric parts of any such decomposition.
There are unlisted articles, also show them or only show them.