The Hessian of potential energy at an equilibrium. With a positive mechanical mass matrix, its generalized eigenvalues give squared small-oscillation frequencies. Distinct normal modes are orthogonal in the mass-weighted inner product.
The symmetric coefficient matrix of kinetic energy to second order in generalized velocities. For independent horizontal point-mass coordinates it is diagonal, with the particle masses on the diagonal. Together with the mechanical stiffness matrix it gives the generalized eigenvalue problem for small oscillations.
Three equal point masses move in a plane and are connected pairwise by ideal springs of equal positive stiffness . At an unstretched equilateral triangle equilibrium, let be the vertex positions relative to the centre, and let be small displacements. If , the quadratic potential energy is , and the kinetic energy is .
There are three independent zero-frequency motions: two common translations and the infinitesimal rigid rotation , where . The uniform radial motion is the breathing normal mode, with . The two shear modes are and , each with .
For a compact proof of the spectrum, form the matrix taking the six displacement components to the three first-order spring extensions, orienting the three edges cyclically. Its row norms squared are two, and every pair of rows has inner product . Thus , with eigenvalues . The nonzero eigenvalues of are the same, so the stiffness matrix has the three positive values in the title and a three-dimensional kernel of a linear map. The three rigid motions span that kernel. A zero mode has time factor rather than a nonconstant periodic oscillation.
A horizontal bar of mass hangs from a spring of incremental stiffness , and two equal masses hang separately from the bar through springs of stiffness . The bar remains horizontal and all motion is vertical. For physical displacements from the loaded equilibrium, the kinetic energy and quadratic potential energy areGravity determines the static extensions; its linear terms cancel at equilibrium. Exchange of the lower masses splits the normal modes into the antisymmetric mode with , and two symmetric modes . The latter obey and . Their determinant gives the title quadratic in , and . For , their squared angular frequencies are , with displacement ratios respectively. The lower symmetric mode moves all masses in phase; the higher one moves the lower pair against the bar.
Let three equal masses move vertically, with one spring of stiffness attaching mass 1 to a fixed support and two further springs of the same stiffness attaching masses 2 and 3 separately to mass 1. For absolute downward displacements from equilibrium, the small-oscillation mass and stiffness matrices areThe normal modes haveExchange symmetry of the two lower masses gives the antisymmetric mode with mass 1 stationary. In the symmetric sector, put ; the reduced equations give , producing the remaining two frequencies. The lower mode moves all masses in phase; in the higher mode the lower pair moves against the upper mass.
Using individual rope-length changes instead gives . In those generalized coordinates and . Mode amplitudes must therefore be identified as physical displacements or rope-length changes before interpreting them. The model assumes taut elastic elements and small vertical motion; gravity shifts the equilibrium extensions.
For three collinear masses , with , , connected consecutively by two springs of stiffness and with free ends, let denote displacements from an equilibrium. The kinetic energy and potential energy are , , whereThe generalized eigenvalue problem for small oscillations hasDirect substitution verifies each pair; the three distinct eigenvalues exhaust the three-dimensional problem. The zero normal mode translates the complete system without extending either spring. The second holds the middle mass fixed while the end masses move oppositely. The third moves the end masses together and the middle mass oppositely, leaving the centre of mass fixed.
For mass-matrix orthogonality of normal modes, the squared norms are respectively , and . Dividing each shape by its corresponding square root gives . The general motion is a linear combination of the two oscillatory modes and ; the latter describes free translation with constant velocity.
For end masses , central mass and two equal springs of stiffness , use the normal modes , and . Their squared frequencies are , and . The prescribed velocity decomposes asThusThe zero mode is a uniform center-of-mass motion, with conserved total momentum and velocity . The other two modes have fixed centre of mass. Dividing their velocity coefficients by their nonzero frequencies gives the sinusoidal displacement amplitudes; for the zero mode the correct time dependence is linear rather than a bounded sine. This distinguishes translation of the complete system from its internal vibration.
For symmetric stiffness matrix and positive-definite mass matrix , eigenvectors ofwith distinct squared frequencies satisfyThus normal modes are orthogonal in the kinetic-energy inner product.
For equal lengths and mass ratio , the squared angular frequencies are , where is the upper mass, the lower mass, and . The equal-mass case admits particularly simple mode shapes.
Use the ideal model of the double pendulum, with both angles measured from the downward vertical. Around , the Taylor expansions and give the quadratic LagrangianHere both angles and their angular velocities are counted as small. Consequently the correction to is fourth order and does not enter . The Euler-Lagrange equations give . The mass matrix is not diagonal: an angular motion of the upper rod carries the lower mass too.[ref]
Classical Dynamics by David Tong. Classical Dynamics, chapter 2, §2.6.1, printed pp. 41–42, equations (2.130)–(2.132): equal-mass, equal-length linearized double pendulum
For a normal mode, put with fixed amplitude vector . The resulting generalized eigenvalue problem for small oscillations is . With , its characteristic equation isSolving this quadratic and using the second row, , givesThe lower-frequency normal mode has the rods in phase, with the lower angle times the upper one. The higher-frequency normal mode has opposite signs, corresponding to an oscillation phase difference of . These are ratios of absolute angles. The horizontal displacements are instead and ; their ratios are and respectively. Thus the lower mass moves horizontally opposite to the upper mass in the faster normal mode.
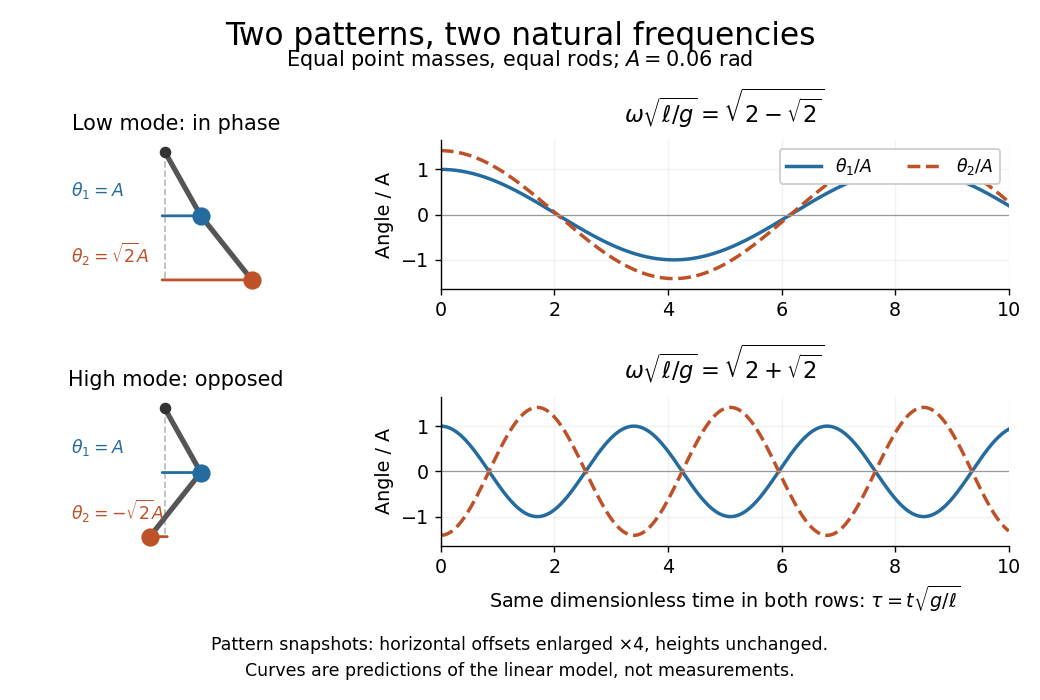

Both squared angular frequencies are positive. Their ratio satisfies , independently of , and . For a constructed model with and , the angular frequencies are approximately and , and the oscillation periods are and . Doubling both masses leaves these unchanged; multiplying both rod lengths by four doubles both oscillation periods.
The eigenvectors are not orthogonal in the ordinary dot product: . They satisfy mass-matrix orthogonality of normal modes, sinceWriting therefore removes the cross terms from both quadratic energies. The two normal coordinates satisfy . This is why the normal modes are useful: one coupled system becomes two independently evolving harmonic oscillators, and any small release can be decomposed into them. At larger angles, the discarded terms in the double pendulum equations of motion matter and this exact linear superposition no longer applies.
For equal point masses and upper/lower massless rods of length , angular coordinates from the downward vertical give mass matrix and stiffness matrix . The generalized eigenvalue problem reduces to , where . The slow mode has angular-amplitude ratio , and the fast mode has ratio .
For equal rod lengths , upper mass and lower mass , use horizontal displacements , at first order. The quadratic kinetic energy is , while the stiffness matrix isThe generalized eigenvalue problem for small oscillations is , not . In particular the lower Euler-Lagrange equation is , independent of the lower mass factor after division by that mass. This reproduces the normal modes of a double pendulum and distinguishes the mechanical mass matrix from its stiffness matrix.
An upper mass and lower mass joined by equal light strings of length have small-angle mass and stiffness matrices and . The squared frequencies are and , with angular eigenvectors and respectively. Equal-angle release decomposes with coefficients and . The angles are measured from vertical, not between strings.
Release the upper rod at radians while keeping the lower rod vertical, , with both angular velocities zero. The initial condition is the sum . The solution from linearization is thereforeAt release the lower angle vanishes by cancellation between the two normal modes. Their different angular frequencies then destroy that cancellation. Differentiating twice gives and , agreeing with the small-angle limit of the exact double pendulum equations of motion.
The quadratic mechanical energy at release is . Each normal mode contributes half, because . Equal coordinate amplitudes need not mean equal energies in general; here the modal inertias and squared angular frequencies happen to compensate. Releasing instead along or , with zero angular velocities, excites just one normal mode.
A weakly coupled degenerate pair can split by order when the small parameter enters a singular mass or stiffness matrix.
If the mass and stiffness matrices commute with a permutation representation, each symmetry subspace is invariant under the generalized eigenvalue problem for small oscillations. On an irreducible subspace, Schur lemma forces a commuting operator to be scalar, producing a degenerate normal mode multiplet.
Connect every pair among moving scalar coordinates and one fixed coordinate by identical springs of stiffness . The coupling pattern is the complete graph with one vertex fixed. Its potential energy is . The moving-coordinate stiffness matrix is the principal submatrix displayed in the header. For equal masses , the uniform normal mode has squared angular frequency , while every sum-zero vector has squared angular frequency . There are such degenerate modes. This follows directly from the Laplacian spectrum of a complete graph and its rank-one matrix form. Constant gravitational forces shift the equilibrium without changing the stiffness.
For two masses, connect each to a fixed anchor and to the other mass with equal stiffness . Set to choose units. The squared angular frequencies have characteristic equation . Requiring a frequency ratio of two means that these roots are and . Their sum and product give , yielding the two reciprocal ratios in the header. Restoring units multiplies all squared frequencies by , leaving the permitted mass ratios unchanged. The term octave refers here only to this two-to-one ratio.
Let three equal masses move on a circle of radius , and let the potential be with . At equal spacing , angular displacements have a zero-frequency rigid-rotation mode and a two-dimensional sum-zero eigenspace withThe two vibrational modes are degenerate by the permutation symmetry.
For three unit masses with unit springs between every pair and one unit spring anchoring each mass to the origin,where is the all-ones matrix. The collective mode has angular frequency , while the two-dimensional sum-zero subspace has angular frequency .
For equal masses , wall-spring constants , and coupling-spring constant , the small-oscillation mass and stiffness matrices areIf , , and , the squared normal frequencies are
For two equal masses with equal wall springs released with displacements , their second displacement is , where is the mean of the two positive normal mode frequencies and their difference. The first nonzero time with is a fast turning point, not the slow maximum of its beat envelope. With , writing gives . Thus , using the first root of in . The envelope instead first reaches its maximum at .
Articles by others on the same topic
There are currently no matching articles.