A locally ringed space is a ringed space whose stalk is a local ring at every point. Morphisms of locally ringed spaces induce local homomorphisms on stalks.
For a ringed space , a sheaf of -modules is a sheaf such that every is an -module and restriction maps preserve scalar multiplication.
A sheaf of rings assigns a ring to each open subset , and restriction ring homomorphisms for inclusions, satisfying locality and gluing. Compatible sections on an open cover must glue uniquely to a section on its union. Real-valued continuous functions on a topological space form a sheaf of rings under pointwise addition and multiplication: functions agreeing on overlaps define exactly one continuous global function. A constant presheaf is not generally already a sheaf; locally constant functions provide the corresponding sheaf construction.
A morphism of ringed spaces from to consists of a continuous map and a morphism of sheaves of rings. Equivalently, for every open , it gives compatible ring homomorphisms . Functions pull back against the direction of the point map: a section is sent to in the familiar smooth example. A morphism of locally ringed spaces further requires the induced maps on stalks to be local homomorphisms.
Splitting of rational primes in a quadratic field by  Codex 0 Created 2026-09-24 Updated 2026-11-05
For a quadratic field of discriminant and a rational prime , the ideal splits into two distinct prime ideals, remains prime, or ramifies according as the quadratic character is , , or . The corresponding prime-ideal norms are , , and , respectively.
A ring homomorphism preserves addition, multiplication, and, under the convention used here, the multiplicative identity.
A commutative ring is a ring in which multiplication satisfies for every pair. The integers and the polynomial ring are examples. So is , the quotient ring whose elements are residue classes in modular arithmetic. We represent these by and reduce each sum or product to its remainder. All following calculations modulo use this convention.
In , , although neither factor is zero. Thus and are zero divisors: nonzero elements whose product with another nonzero element can vanish. Also . Removing the common factor would falsely assert . The entire row for multiplication by isThe repetitions explain the linear congruences directly. The equation has exactly the two solutions , whereas has none. A common factor can erase information, and a nonzero coefficient does not guarantee that an equation has a solution.
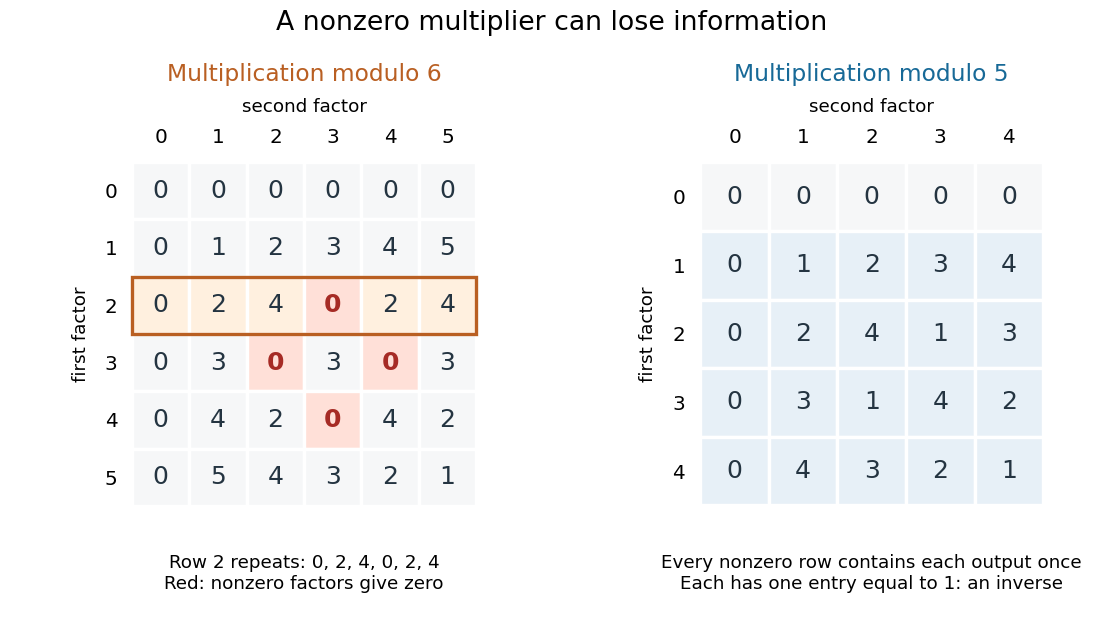
A unit in a ring is an element with a multiplicative inverse, meaning for some . In , the units are exactly and , since . The other nonzero elements, , are zero divisors; for , use . In a nonzero commutative ring, a unit cannot be a zero divisor: multiplying by its multiplicative inverse forces . But a nonzero element need not be a unit or a zero divisor: the integer is neither in .
By contrast, in , every row for a nonzero multiplier is a permutation of . Each such row contains exactly once, giving a multiplicative inverse: , , , and . Hence this commutative ring is a field. For example, now has the unique solution . Reading the tables reveals which algebraic steps the arithmetic permits.
On an oriented Riemannian -manifold, the volume form is the unique positive -form taking value one on every positively oriented orthonormal frame. In positive local coordinates,
In a coordinate frame, the Levi-Civita connection is determined byThe coefficients are the Christoffel symbols. They are not the components of a tensor because a coordinate change contributes second derivatives.
A geodesic is a curve whose tangent vector is parallel along itself under the Levi-Civita connection. With an affine parameter it has zero covariant acceleration:This is the Riemannian manifold version of moving straight ahead with constant speed. Its coordinate form is the geodesic equation. In Euclidean space it becomes , giving straight lines. On an embedded surface with its induced metric, the ordinary acceleration of such a curve is normal to the surface: all acceleration is used to follow the surface, rather than to turn within it.
On a unit round sphere, the great circle has , which is normal to the sphere. Two points at and can be joined along that circle by the short arc of length or the long arc of length . Each admits a constant-speed geodesic parametrization, yet only the short arc realizes their great-circle distance.
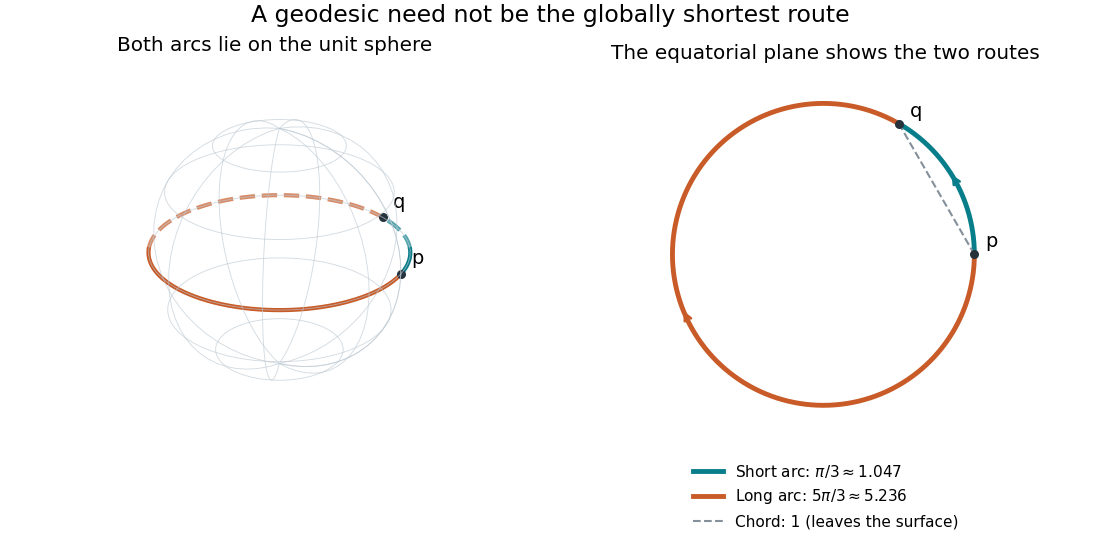


Every geodesic minimizes arc length on sufficiently short subarcs. A long segment can cease to be globally minimizing, as the sphere example shows; the first loss from a starting point is described by the cut locus. Thus “locally straight” and “shortest route between these endpoints” are distinct assertions. On a circular cylinder, different winding gives the same distinction, made explicit by Riemannian distance on a circular cylinder.
This provides a useful division of work. The geodesic equation predicts a path from an initial point and tangent vector; comparing arc lengths decides which candidate solves a global shortest-route problem. Variations of energy of a curve give the equation as an Euler-Lagrange equation, offering a proof outline and a connection with classical mechanics. [ref]
https://www.math.ucla.edu/~petersen/RG.pdf. Peter Petersen, Riemannian Geometry, chapter 5: geodesics, distance and first variation
.An isometry between metric spaces preserves every distance. A Riemannian isometry preserves the Riemannian metric and therefore distances, angles, geodesics, and intrinsic curvature.
For Riemannian manifolds and , the product metric on is . Its Levi-Civita connection and curvature split by factors, so its Ricci and scalar curvatures are the corresponding sums.
There are unlisted articles, also show them or only show them.