A topological space is a set together with a topology , a family of subsets satisfyingHere is the power set; the union may have arbitrarily many members, while the intersection must be finite. The members of are the open sets. These are axioms about subsets, with no assumed metric or surrounding Euclidean space. [ref]
https://www.maths.ox.ac.uk/system/files/attachments/Preliminary%20Reading%20%281%29.pdf. Richard Haydon, Oxford topology preliminaries, Definition 0.1
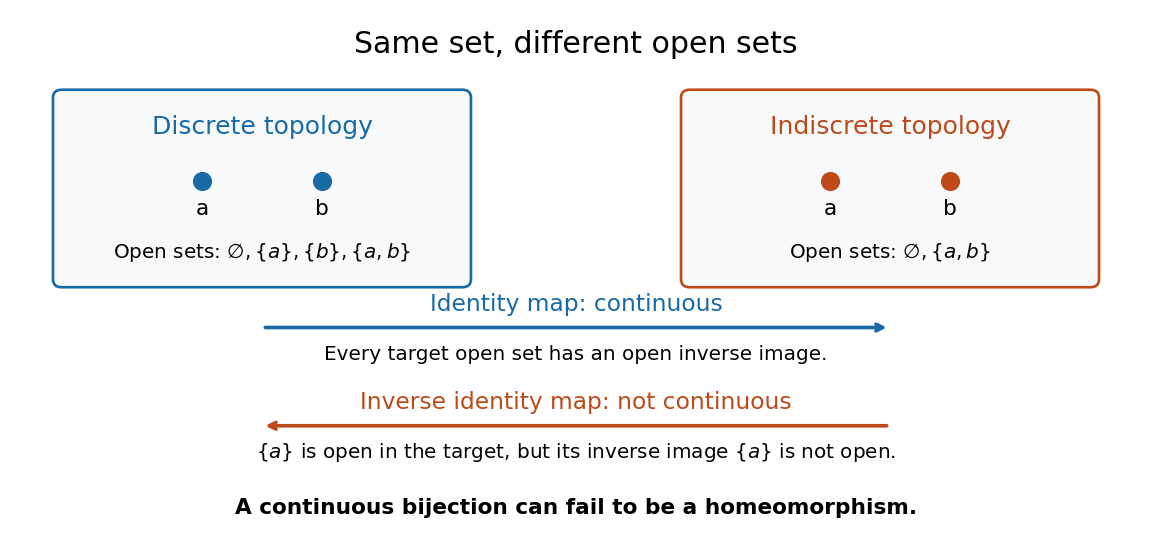
For , the discrete topology is , while the indiscrete topology is . Both satisfy the axioms. They describe different topological spaces on the same set: the first is Hausdorff and disconnected, while the second is connected and not Hausdorff. Each is compact because is a finite set.
The identity function is a continuous map: the only target open sets have inverse images and . Its inverse is not a continuous map, since the target open set has inverse image , which is not an open set in . Thus even a continuous bijection need not be a homeomorphism.
A Lindelöf space is a topological space in which every open cover has a countable subcover. A closed discrete subset of a Lindelöf space must be countable: cover each of its points by an open set meeting it at only that point and add the open complement. In a metrizable space, the Lindelöf property is equivalent to topological separability.
Choose an uncountable set and a point . Every point other than is isolated, and a set containing is open precisely when its complement is countable. Equivalently, the closed sets are all subsets containing together with all countable subsets. Arbitrary intersections and finite unions preserve this latter condition, so it defines a topology.
Every convergent sequence in this space is eventually equal to its limit. Indeed the set of its values different from its limit is countable and closed; its complement is an open neighbourhood of the limit. Eventual membership in this complement forces eventual equality. Nevertheless is not isolated, because its singleton has uncountable complement. In particular sequence convergence alone does not determine this topology.
A real-valued function on this space is continuous exactly when is countable. Sufficiency follows by considering the preimages of closed subsets of the real line: each either contains or is a subset of that countable exceptional set. For necessity, each set is closed and excludes , hence is countable; their countable union is the exceptional set.
A topological space is first-countable when each point has a countable neighbourhood basis. Every metric space is first-countable: the open balls form such a basis. A subset of a first-countable space remains first-countable in its subspace topology, since intersecting a local basis with the subset preserves the defining containment property. Thus a space failing first countability cannot be homeomorphic to any subset of a metric space.
The Warsaw circle joins the two path components of a closed topologist's sine curve by an arc attached at their outer endpoints. It is path-connected and has trivial fundamental group, yet admits a continuous map to the circle with no continuous lift to its real-line covering space. Set the map equal to on the closed topologist's sine curve and wind once on the joining arc. A lift would be constant on each path component of the sine curve, with the same constant on both by continuity, but would change by along the joining arc. This proves that the map is not null-homotopic, by the homotopy lifting theorem for a covering map. Thus finiteness of the fundamental group alone cannot replace local path connectedness in the usual lifting criterion for a covering space.
A sequence in a topological space converges to if every open neighbourhood of contains all sufficiently late terms:For a metric space, this is the usual limit of a sequence condition expressed through open balls. For a Hausdorff space, distinct proposed limits have disjoint open neighbourhoods, so a sequence cannot eventually stay in both and the limit is unique. The sequence convergence in the cofinite topology demonstrates what can change when that separation property is absent.[ref]
Chapter 1: Topological spaces. Definition 1.5.5, Proposition 1.5.11 and Proposition 1.6.20: neighbourhood convergence, uniqueness and the metric formulation
An open map sends each open set to an open set; a closed map sends each closed set to a closed set. These properties concern images, whereas continuity concerns inverse images of open sets. Neither openness nor closedness alone implies continuity.
A space partitioned into manifold strata, with a locally finite frontier-compatible partition. In the conical setting, a neighbourhood of a point in an -dimensional stratum has the form , respecting the strata, for a compact stratified link .
A stratum is one manifold piece of a stratification, with locally constant dimension and prescribed conical normal neighbourhoods. Its codimension in a pure -dimensional space is minus its dimension.
An -dimensional conically stratified space has a closed filtration , with each nonempty a -manifold, , and dense top stratum. At an -stratum the conical link is a compact -dimensional stratified pseudomanifold. In dimension zero a compact link is a finite set. Connected links are an additional normality condition, not part of this definition.
The link of an isolated stratum of a closed two-dimensional pseudomanifold is a finite disjoint union of circles. Separate these branches, replacing the cone on their union by separate disks. This produces a closed surface and a finite surjective map to the original space, a homeomorphism on the regular stratum. Orientations on the regular stratum extend over the disks.
A rational Witt space is a stratified pseudomanifold such that the link of every stratum of odd codimension satisfies . This removes the only difference between lower and upper middle extensions and gives rational middle-perversity Poincare duality on closed oriented Witt spaces.
A compact stratified space with boundary is a Witt space with collared boundary when its interior and boundary are Witt spaces and a stratified neighbourhood of the boundary is , with product stratification. Orientations are carried by the regular strata and induce the usual boundary orientation.
The compact space in a stratified neighbourhood is the link of the stratum. Its dimension is one less than the codimension of that stratum. A disconnected link records distinct local branches.
Give the topology whose nonempty open sets are and the finite initial segments. Every nonempty open set contains , so any two nonempty open sets intersect. A continuous map from this topological space into a Hausdorff space is constant: distinct image points would have disjoint open neighbourhoods, whose inverse images would be disjoint nonempty open sets. This includes continuous real-valued maps.
A space is sigma-compact if it is a countable union of compact subsets. A locally compact, sigma-compact metrizable space is second countable: each compact metrizable subset has a countable dense set, their union is countable and dense, and a separable metric space has a countable basis.
A topological space is sober when every nonempty irreducible closed subset is the closure of a unique point. Every Hausdorff space is sober. In contrast, an infinite set with the cofinite topology has the whole space irreducible and closed, while every singleton is closed, so it is not sober.
The sobrification has one point for every nonempty irreducible closed subset of , with opens . Irreducibility gives , and the map from original opens to these opens is bijective, detected by singleton closures. An irreducible closed subset of the new space has complement ; is an irreducible closed subset of and uniquely generates it. Thus the new space is a sober space.
A topological space is separable when it has a countable dense subset. The topology is part of the assertion: a dual may be separable in its weak-star topology and not in its norm topology. A compact metric space is separable by taking the union of finite nets at scales tending to zero.
A G-delta set is a countable intersection of open subsets of a topological space. In a complete metric space these are precisely the topologically complete subspaces, by the G-delta criterion for topological completeness.
A net is a family indexed by a directed ordered set: every pair of indices has a common upper bound. It converges to when it is eventually in every neighbourhood of . Unlike sequences, nets characterize closure in every topological space: a point is in the closure of a set precisely when some net in that set converges to it.
A subnet is obtained from a net by an order-preserving cofinal map from another directed index set. It preserves any limit of the original net, and eventual properties still hold along it. Every net in a compact set has a convergent subnet. This supplies compactness arguments when sequential compactness is unavailable.
A separation axiom is a condition on a topological space expressing how points or closed subsets can be distinguished by open sets. The Kolmogorov space condition distinguishes distinct points by some open set; the T1 space condition makes every point closed; the stronger Hausdorff space condition gives disjoint neighbourhoods to distinct points.
A topological space is regular when a point and a closed set not containing it have disjoint open neighborhoods. Equivalently, for every point in an open set , there is an open with . To obtain shrinking, separate from the closed complement of ; the closure of the point's neighborhood avoids the other neighborhood. Conversely use such a shrinking and the complement of its closure. This definition alone does not require .
A T3 space is a regular topological space which is also a T1 space. Every metric space has this property: singletons are closed, and a sufficiently small ball about a point outside a closed set has closure avoiding that set. A second-countable T3 space is a metrizable space by Urysohn's metrization theorem.
A topological space is totally separated when any two distinct points are separated by a clopen set. Such a space has no nontrivial connected subset. A zero-dimensional space with its usual clopen-base definition and is totally separated. Conversely these conditions agree for compact Hausdorff spaces by the Šura-Bura lemma and compactness, although the definitions should not be conflated for arbitrary spaces. Any closed totally separated subset of the unit square is nowhere dense, since every nonempty relatively open subset of the square contains a nontrivial connected line segment. Restricting a clopen set separating the segment's endpoints would disconnect that segment.
A topological space is T1 when every point is a closed point. Equivalently, for distinct there is an open set containing but not , and an open set containing but not . These open sets need not be disjoint. Every Hausdorff space is T1, but an infinite set with its cofinite topology is T1 without being Hausdorff.
A point of a topological space is closed when its singleton is a closed set. In a T1 space every point is closed. The closed points of an affine scheme are its maximal ideals; the closure of the point corresponding to is .
A topological space has local connectedness when every point has a neighborhood basis of connected open sets. In particular, a planar domain has local connectedness, but its domain boundary need not be. Local connectedness of the boundary is the condition governing a continuous extension of a conformal bijection to the parametrizing circle.
The boundary of a subset of a topological space consists of the points whose every neighbourhood in meets both and its complement . Equivalently,Here the two operations are closure and interior. The second formula shows that the boundary is a closed set and that and its complement have the same boundary. It locates precisely the points where membership cannot be decided from a small neighbourhood alone. [ref]
For in the usual real line, the interior is , the closure is , and the boundary is . In particular, belongs both to and to its boundary, while belongs to the boundary but not to . A boundary point need not be excluded from the original set: open sets exclude all their boundary points, closed sets contain all theirs, and this half-open interval does one of each.
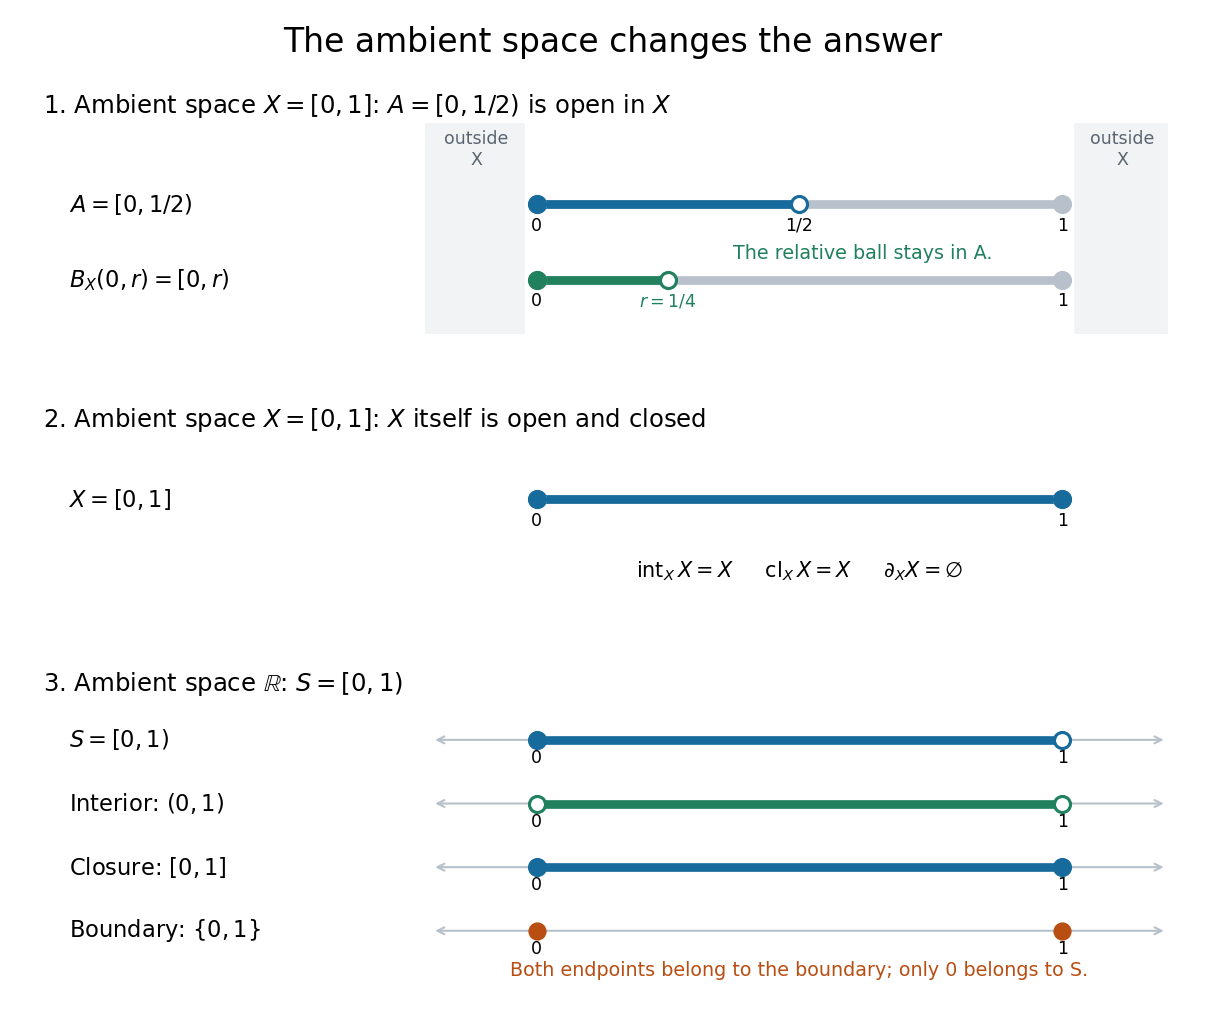
The upper panel visualizes the relative example from open set: for and , an open ball about zero in is when . This open ball stays in ; points outside are not required. The middle panel shows that is clopen in itself, with interior and closure both and empty boundary, although its boundary in the real line is . The lower panel returns to ambient space and separates the interior, closure, and boundary of ; both marked boundary points are included in the boundary itself.
A point belonging to the boundary of a set: every open neighborhood meets both the set and its complement.
A connected component of a boundary. A surface with a hole can have several boundary components, each with its own induced boundary orientation.
The boundary of a planar domain is its boundary of a set. It is distinct from the boundary of a parametrizing interval: a curve can begin on while all its positive-time points lie inside .
A basis of a topology is a family of open sets such that every open set is a union of members of that family. Equivalently, every point of every open set lies in a basis member contained in it. The rectangles form a basis for the product topology of two spaces. This topological meaning differs from a linear-algebra basis.
A family of open subsets is a subbasis of a topology when its finite intersections form a basis of a topology, including the empty intersection equal to the entire space. For the product topology, inverse images of open sets under the product projections form the standard subbasis of a topology. A map into the space is continuous if the inverse image of every subbasic set is open.
A second-countable topological space has a countable collection of open sets such that every open set is a union of members of that collection. A space covered by countably many open manifold charts is second countable because each coordinate domain has a countable basis of rational balls.
A topological space is paracompact when every open cover has a locally finite open refinement. Every metric space and every second-countable topological manifold is paracompact.
A topological space is when every pair of distinct points is distinguished by an open set containing exactly one of them.
The Sierpiński space is with open sets , , and . Continuous maps are in bijection with open subsets of through .
For a T0 space , evaluation against all continuous maps is a homeomorphism onto its image under the mapinto a power of the Sierpiński space. The axiom makes it injective, and the coordinate inverse images of recover every open subset of .
A map between topological spaces is continuous when every open set has an inverse image that is an open set in . The notation denotes a subset, so need not have an inverse function.
For the continuous map , , with the usual metric topology,The two open intervals form an open set; an inverse image can split into separate pieces without violating continuity. The defining condition concerns inverse images, rather than images: here is not an open set in the real line. Checking this one inverse image illustrates the definition; it alone does not prove continuity for all target open sets.
For a continuous map into a metric space, : an open neighborhood of an image point pulls back to a neighborhood meeting . A bounded set lies in a closed ball, and its closure lies in the same ball because distance from the centre is a continuous function. The displayed boundedness conclusion follows. Neither compactness of the domain nor uniform continuity of the map is needed.
A function of several variables is separately continuous when it is continuous in each variable with the others fixed. This is weaker than joint continuity in the product topology. Functions with narrow rectangular supports provide useful examples distinguishing convergence in topologies generated by separate continuity from Euclidean convergence.
Let with both coordinates nonzero, , , and . The displayed function equals one at every and zero on both coordinate axes. Each coordinate line off the corresponding axis meets only finitely many supports, so its restriction is a finite maximum of continuous functions. On the axes it is zero. Hence is separately continuous and disproves convergence of this sequence in any topology making every separately continuous function continuous. Isotropic radial bumps need not have this property when one coordinate approaches zero much faster than the other.
A function between topological spaces is continuous if and only if for every subset , where the bars denote closure. For a continuous , pull back an open neighbourhood of for ; its preimage meets , so the neighbourhood meets . Conversely, apply the inclusion to with closed. Then implies , so the preimage of every closed subset is closed and is continuous.
A function between topological spaces is continuous exactly when the inverse image of every closed set in is closed in . The defining open set criterion is equivalent, because . This criterion concerns inverse images; a continuous map need not be a closed map.
A continuous map that is also an injective function. A continuous injection need not be a topological embedding: its inverse on its image need not be continuous. If its source is a compact space and its target is a Hausdorff space, however, the compact-to-Hausdorff continuous bijection theorem makes that inverse continuous.
A continuous bijection is a continuous map that is a bijection. It need not be a homeomorphism, since its inverse function need not be continuous. The compact-to-Hausdorff continuous bijection theorem supplies a useful sufficient condition for the stronger conclusion.
For continuous maps and , a continuous lift of through is a continuous map with . Existence and uniqueness require additional hypotheses; the lifting criterion for a covering space states a useful existence criterion when is a covering map and is path-connected and locally path-connected.
The continuous map projecting a real number onto the closed interval , with . It equals below the interval, equals the input inside it, and equals above it. It is nondecreasing and has Lipschitz constant one.
A continuous map injective map that is a homeomorphism onto its image with the subspace topology. A continuous map injective map from a compact space into a Hausdorff space is a topological embedding.
Continuous functions on a normal Hausdorff space separate points and closed sets by Urysohn's lemma. The evaluation map into the product of their codomains is injective and continuous. For each point in an open set, a coordinate equal to one there and zero outside the open set detects a smaller coordinate neighborhood, proving the inverse topology.
A subset is C-embedded if every continuous real-valued function on its subspace topology extends continuously to . Closed subsets of normal spaces have this property by the Tietze extension theorem. The condition also makes sense for nonclosed subsets.
A subset is Cb-embedded if every bounded continuous real-valued function on it extends to a bounded continuous real-valued function on the ambient space. A bounded extension can be clipped to preserve the original bound. This is weaker than C-embeddedness: the natural numbers in their Stone-Čech compactification have the bounded extension property, but their unbounded identity function cannot extend to a compact space.
A family of maps with a common domain determines the displayed map into the Cartesian product of their codomains. It is injective exactly when the family separates points. For continuous coordinate maps it is continuous in the product topology. If inverse images of open sets under the coordinates generate the original topology, the inverse from the image is also continuous; thus the map is a topological embedding. A basis of such inverse images, as opposed to a subbasis, is a sufficient stronger hypothesis.
Every topological space, including one without the T0 space property, embeds into a power of this three-point space. For each open set , use a coordinate equal to on and elsewhere. Its inverse image of the only proper nonempty open set is . For each point , add a coordinate equal to at and elsewhere. These coordinates are continuous because the subspace has the indiscrete topology, and they separate all points. The combined diagonal map is injective and induces precisely the original topology, hence is a topological embedding.
A retraction of a topological space onto a subspace is a continuous map whose restriction to is the identity.
The closed unit ball in the infinite-dimensional real Hilbert space admits a retraction onto its unit sphere. Write for the forward unilateral shift operator and set . Then and : equality would force all coordinates of to coincide, hence vanish, contradicting .
For , setThe nonvanishing denominator makes a continuous map. Expanding its squared norm gives . On , the fraction is one, so . Thus the finite-dimensional no-retraction theorem does not extend to this closed unit ball.
Removing any interior point from the Euclidean closed unit ball allows a retraction onto its unit sphere. For , the positive root of isThen is a continuous map on the punctured closed unit ball, has norm one, and fixes its boundary because there. The quadratic equation has one positive and one negative root since , so the chosen root is unambiguous.
A once-punctured genus- closed orientable surface retracts to a wedge of circles. A retraction from would inject its degree-one cohomology as an isotropic subspace of a symplectic vector space for the Poincare duality pairing, since the punctured surface has zero degree-two cohomology. The maximal isotropic dimension is , giving . Equality is realized by folding the double of the punctured surface onto one copy. Additional handles in the other copy can be pinched away while fixing the joining boundary, proving sufficiency for every embedding of such a one-boundary subsurface when .
A subset of a topological space is locally closed if for an open set and a closed set . Equivalently, is open in its closure , or is closed in . For the equivalence, implies , so . Relative complementation proves the second condition implies the third. Conversely, if is closed, then is such an intersection.
A topological subspace of a topological space is a subset equipped with the subspace topology inherited from .
The one-point compactification of a locally compact noncompact Hausdorff space adjoins one point whose neighbourhoods are complements of compact subsets. The result is compact Hausdorff.
For locally compact noncompact Hausdorff spaces, a continuous proper map extends continuously to their one-point compactifications by the displayed rule. The inverse image of is , a neighborhood of infinity because the inverse image of a compact set is compact. The extension itself is proper, since it is continuous from a compact space to a Hausdorff space. A nonproper map can fail to admit any continuous extension: projection sends two vertical sequences escaping to the same point at infinity to two distinct constant sequences, incompatible with continuity at that point.
The one-point compactification of an uncountable discrete space is a hereditarily normal space but not a perfectly normal space. A subspace missing is discrete; one containing it is closed, hence compact Hausdorff and normal. However, every neighborhood of misses only finitely many points of . A countable intersection misses at most countably many points, so the closed singleton is not a G-delta set.
The Hawaiian earring is the union of a countable family of circles tangent at one point, with their radii tending to zero, endowed with its planar subspace topology. Equivalently it is the one-point compactification of a countable disjoint union of real lines. Every neighbourhood of the common point contains all but finitely many whole circles. This compact topological space is not locally contractible there and has different singular homology from the infinite CW complex wedge of circles.
The first integral singular homology of the Hawaiian earring has a direct summand isomorphic to . This consequence of its structural homology theorem suffices, through the universal coefficient theorem for cohomology and nonzero Ext of the rationals with integer coefficients, to show that its integral is nonzero. The precise structural theorem is Theorem 3.1 of www.sas.rochester.edu/mth/sites/doug-ravenel/otherpapers/eda-kawamura2.pdf.
The circle is the subspace , equivalently the quotient of a closed interval obtained by identifying its endpoints.
Every continuous injective map is a homeomorphism. After normalizing by a rotation, it is homotopic either to the identity or to complex conjugation, and has degree or .
To see this without assuming surjectivity, lift on through the covering map to a path with . Injectivity makes injective on , hence strictly monotone. Its endpoint is an integer. Strict monotonicity excludes ; if , the intermediate value theorem gives an interior integer value, contradicting injectivity of . Thus , and descends to a homotopy from to . If omitted a point, a continuous branch of the complex argument on the punctured circle would make it null-homotopic, contradicting this nonzero degree. Hence it is surjective. A continuous bijection from a compact space to a Hausdorff space is a homeomorphism.
For real and complex , if , completing the square gives . A positive right side gives a circle; zero gives a single point; a negative value gives the empty set. If and , the equation is the straight line . If , it describes the whole complex plane when , and the empty set otherwise. Thus unrestricted coefficients require both the single-point and whole-plane degeneracies.
The maximum distance between a circular arc and its chord of length . For radius and , expansion gives . In a uniform transverse magnetic field, a charged track has , so the sagitta measures its momentum.
Given three mutually externally tangent circles, the inner Soddy circle lies in their curvilinear triangular gap and is tangent to all three. The Descartes' circle theorem determines its radius from the three given radii.
The power of a point relative to a circle with center and radius is . If a line through meets the circle at and , the product of the directed distances and equals this quantity.
Two distinct circles are tangent when they meet at exactly one point. For external tangency the distance between centers is the sum of the radii; for internal tangency it is their absolute difference. These relations turn many circle packing problems into exact distance equations.
Four positive-radius circles with pairwise disjoint interiors, successive external tangencies, and four distinct contact points have those contact points on a circle. Apply the reciprocal Möbius transformation at one contact . The two circles through become disjoint parallel lines; the other two disks lie between them and avoid zero. Collinearity for tangent circles between parallel lines places the three finite transformed contacts on a straight line. That straight line misses zero: otherwise its segment across the strip would pass through zero, while that segment is contained in the two transformed closed disks. Its inverse is therefore a genuine circle through , containing all four original contacts. Allowing internal tangency without the pictured disjoint-interior hypotheses admits collinear degeneracies instead.
Let two positive-radius circles have external tangency at and lie in the closed strip between two parallel lines, touching opposite boundaries at . Then are collinear. To prove this, choose coordinates with the boundaries , put and , and write the centres as , . The contact point isThe closed line segment is contained in the union of the two closed disks: its portions from to and from to are chords. The strip and external tangency hypotheses are essential to this particular formulation.
Two distinct positive-radius circles have internal tangency when their boundaries meet at exactly one point and one disk contains the other. Their centre separation equals the absolute difference of their radii.
Two distinct positive-radius circles have external tangency when their closed disks meet at exactly one point. The Euclidean distance between their centres equals the sum of their radii. The contact point divides the segment of centres internally in the ratio .
At a point on a circle with centre , the tangent line is perpendicular to the radius . For example, differentiating along a parametric curve on the circle gives , showing that the radial vector and tangent direction are orthogonal vectors. Conversely, the perpendicular straight line through has only that point in common with the circle: for a nonzero displacement along it, .
A circular segment is the part of a disk bounded by a chord and one of the two circular arcs joining its endpoints. For radius and the chosen arc's central angle in radians, its area is . Subtract the signed central triangle of area from the circular sector of area . Angles below give the smaller segment and angles above the larger one.
Take a circle of radius , a vertex on its circumference, and two chords from symmetric about the diameter through . If their angle is , choose the arc between their other endpoints that does not contain . The area bounded by the two chords and that arc is . To calculate it, set and the other endpoints to . Their triangle has area , and the adjoining circular segment, of central angle , has area . The sum gives the formula, including the limiting zero-area and full-disk cases.
A circular arc is a connected portion of a circle. For radius and subtended central angle measured in radians, its arc length is . Two distinct endpoints determine two circular arcs: when they are not opposite, the minor arc has and the major arc has . Opposite endpoints determine two semicircles. The straight line segment joining the endpoints is a chord, rather than the curved circular arc itself.
A circular sector is the portion of a disc between two radii and the connecting circle arc. If its radius is and its central angle is radians, its area isIndeed, polar coordinates give . The full disc corresponds to , a semicircle to , and a quarter-disc to . In a solid with horizontal sector cross-sections, radius and angle , its volume is . Holding the angles and heights fixed while scaling every radius by a factor scales that volume by .
Half of a circle, with endpoints at opposite ends of a diameter. For radius , the upper semicircle in the complex plane is parametrized by , , going counterclockwise from to .
A chord joins two points of a circle by a straight segment. If the circle has radius and the chord midpoint lies a distance from its center, the perpendicular bisector and Pythagorean theorem give the displayed length. The length exceeds that of an inscribed equilateral triangle precisely when .
For real and complex , completing the square in gives center and radius , when the radicand is nonnegative. The displayed map is reflection in the line through and : it preserves the complex modulus, fixes the center, and squares to the identity. Hence it maps the circle onto itself, including a radius-zero degeneration.
For two nonempty planar circles with centers and radii , the greatest Euclidean distance between their points is the displayed expression. The triangle inequality gives the upper bound. When the centers differ, choose the two boundary points outward along the line of centers to attain it; when they coincide, choose opposite radial directions. For any third nonempty circle and a point on it, proves . This is not a metric, since for a positive-radius circle.
A cyclic chain of distinct circles between two disjoint circle boundaries, each tangent to both boundaries and its two neighbours. In concentric coordinates with inner radius and outer radius , the chain circles have radius and centre distance . A simple disjoint chain with closes when .
If a simple Steiner chain closes after circles, rotating the starting circle between concentric boundaries gives another closed -circle chain. Applying a Möbius transformation proves the corresponding statement for arbitrary boundary circles. Construction must stay in the same intervening family and proceed without reversing the chosen direction. Merely choosing arbitrary circles tangent to the preceding circle permits backtracking and does not assert closure.
For a Steiner chain between concentric circles, tangencies of neighbouring circles are midpoints of their centres and lie on the circle of radius . Under a Möbius transformation, their locus is a generalized circle, which may be a line. An ordinary-circle conclusion requires the pole of the inverse transformation to avoid the original locus.
An equation , with and real coefficients, becomes after squaring. If , completing the square gives a circle. The original locus is only the part where . Checking this sign on the candidate circle prevents extraneous points introduced by squaring. This method combines the complex modulus with elementary conic geometry.
The radius of a circle or sphere is the Euclidean distance from its centre to its boundary. The diameter is twice the radius.
The Wallis product isIts finite product is . The Wallis integrals give , proving both convergence of the product and its value. The strict integral bounds also give .
Assuming and integrating a suitably normalized polynomial times produces a positive integer that tends to zero as the polynomial degree grows. This contradiction proves that is an irrational number.
The circumference of a circle is its boundary arc length. For radius , it equals . This growing boundary length accounts for the radial factor in the Rayleigh distribution.
Articles were limited to the first 100 out of 110 total.
Articles by others on the same topic

A **topological space** is a fundamental concept in the field of topology, which is a branch of mathematics that studies properties of space that are preserved under continuous transformations. A topological space is defined by a set of points, along with a structure that tells us how these points relate to one another in terms of "closeness" or "continuity.


