A control point is an editable geometric handle used to specify a curve or surface through a basis or refinement rule. The handle is part of the representation; it need not be a point on the resulting curve. In a Bézier curve, the control points are the geometric coefficients of the Bernstein basis. Joining them in order gives a control polygon, which makes the handles easy to manipulate without drawing the curve as a chain of line segments.[ref]
Curves and Surfaces in Geometric Modeling: Theory and Algorithms by Jean Gallier. §4.3, pp. 132–133: control points and Bernstein representation; §5.1, p. 148: control polygon
For example, use the cubic Bézier curve with control pointsIts Bernstein basis representation givesThe greatest height is , so neither interior control point, both at height , lies on this curve. The endpoint control points do lie on it: and . This separates interpolation, which requires passage through prescribed data, from an approximating representation, which uses handles to shape a curve without requiring passage through every handle. If measured points must be interpolated, choose control points to satisfy those constraints; simply using the measured points as the handles of a Bézier curve does not enforce interpolation.
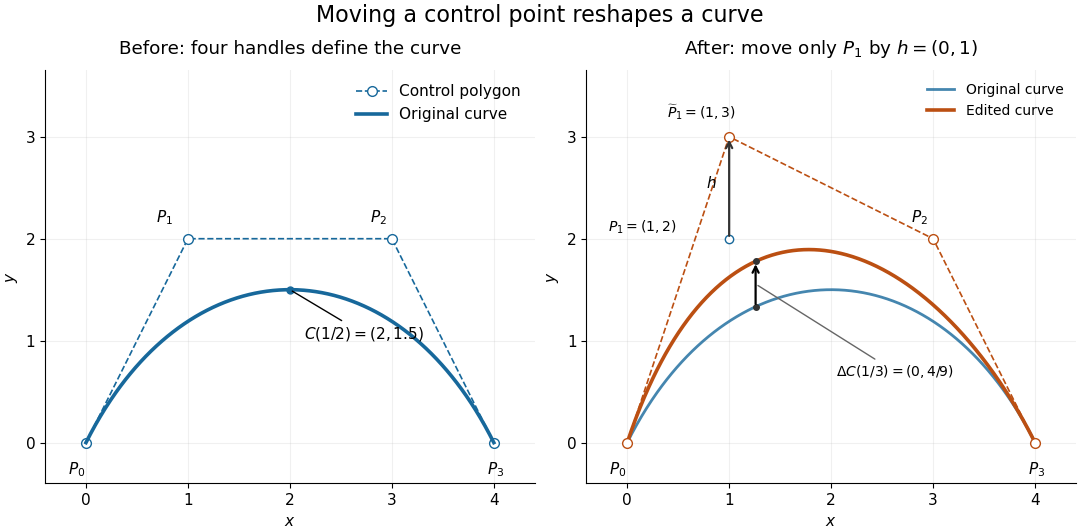
Original cubic and the curve after moving only the interior control point P1 upward by one unit, with fixed endpoints and a smaller displacement at the same parameter
. Details. 
Now move only by the vector , giving . With the Bernstein basis and parameter unchanged, the new curve isAt this gives , a displacement despite moving the handle by a full unit. Both endpoints stay fixed because the coefficient vanishes there. Thus dragging a control point shapes a whole range of the curve; it does not generally drag an arbitrary selected point on the curve by the same vector. The control-point influence on a curve tells us exactly how much each parameter value moves.
For a parametric curve represented by fixed scalar functions and control points in Euclidean space, writeThe influence function of this handle is : the resulting displacement vector is , and its norm is . These are exact finite changes, not only a first-order estimate. Where is negative the displacement points opposite to . Where , the curve is unchanged at that parameter.
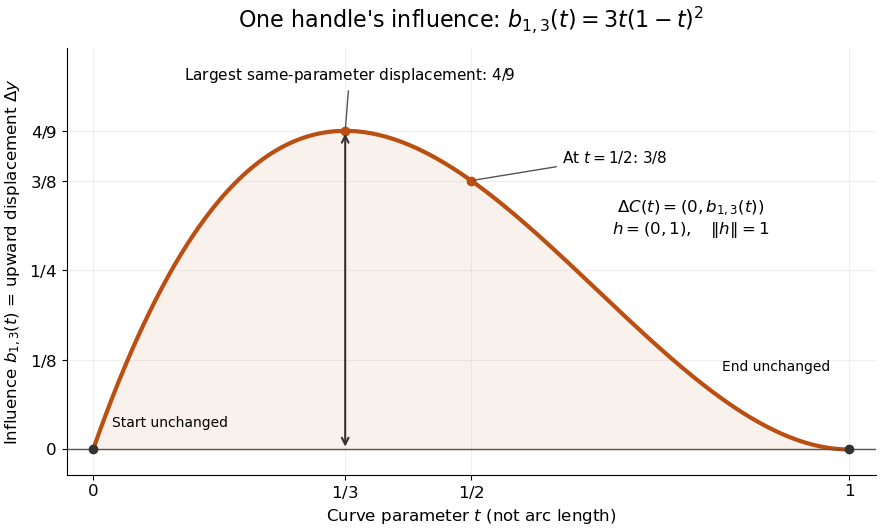
The influence coefficient 3t(1-t)^2 equals the vertical displacement for a unit upward move of P1, reaches 4/9 at t=1/3, and vanishes at both endpoints
. Details. 
For the cubic Bézier curve above, the Bernstein basis influence function is . Its derivative isIt increases up to and decreases thereafter on . Consequently the largest displacement at corresponding parameters isFor it is . This is a comparison at the same parameter. A geometric closest-distance comparison, as in a closest-point search on a subdivision curve, instead minimizes over another parameter:The closest parameter can differ from , so is not automatically a maximum closest-distance separation of the two curves. Neither parameter is assumed to be arc length.
The support of a function is the closure of the parameter values where . It bounds where a nonzero handle move can act, but may include boundary points where the actual displacement is zero. Here the support of a function is all of relative to the parameter domain, while the endpoints are unaffected. In contrast, a B-spline of order has support within in its spline knot sequence, so its handle affects only that parameter range; the support and Gram bandwidth of B-splines describes the same locality in another application. Changing the spline knots or the basis along with the handle requires a different comparison.
When the basis functions form a partition of unity, , each evaluation is an affine combination of the control points. Applying an affine map to all handles givesThis is affine equivariance of a geometric basis, also called affine covariance: affine maps preserve affine combinations. In particular, translating every handle by translates the whole curve by , whereas moving just one handle produces . The Bernstein basis has this partition of unity property.[ref]
Curves and Surfaces in Geometric Modeling: Theory and Algorithms by Jean Gallier. §4.3, pp. 132–133: Bernstein weights sum to one
Nonnegative weights further make evaluations convex combinations, giving the convex hull bound illustrated by the control polygon; nonnegativity is not needed for affine covariance.For a proof outline of the influence formula, subtract the two basis representations: every unchanged coefficient cancels, leaving . The same subtraction with several moved handles gives . No claim about interpolation, closest-point search on a subdivision curve or endpoint motion follows until the actual basis values are examined.
A mesh connecting a surface's control points according to the representation's indexing topology. A tensor-product surface basis gives a rectangular index grid and quadrilateral cells, even when its points in space are neither planar nor rectangular. The drawn mesh is a geometric skeleton, not generally the exact limit surface or an enclosing solid. Positive partition of unity coefficients give a convex hull bound on the relevant controls.
A control polygon joins successive control points by line segments. It gives an editable geometric skeleton, not usually the exact curve. An open control polygon has two ends; a closed control polygon also joins the last control point to the first. Store the first control point only once when using cyclic indices, so the closing edge is counted exactly once. Positive partition of unity basis functions place the curve inside the convex hull of its active control points; a convergent subdivision curve rule refines the control polygon toward its limit, with a certified error when an appropriate bound is available.
Articles by others on the same topic
There are currently no matching articles.