Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Frenet frame
Binormal vector 2026-10-05
The binormal is , the cross product of the unit tangent vector and principal normal vector. It is a unit vector perpendicular to both factors and completes the oriented Frenet frame.
For a continuously differentiable nonzero vector field , the curvature of a space curve following its direction isTake the unit tangent vector and differentiate with respect to arc length. The derivative of is parallel to and disappears from . Since , we have , proving the formula. It remains valid with zero curvature, even where the usual Frenet frame is undefined.
Past exam of the mathematics course of the University of Cambridge 2005 ia Paper 3 4A Solution Created 2026-09-24 Updated 2026-10-14
For the unit-speed curve, the unit tangent vector, curvature of a space curve, principal normal vector and binormal vector areDifferentiating gives , so form a positively oriented orthonormal basis. The hypothesis makes the principal normal vector well-defined.
To determine the sign of the torsion of a space curve without relying on a pictorial handedness convention, take , , and use the unit-speed circular helixWriting , direct differentiation gives its Frenet frame:ConsequentlyAt the marked point is , with , , and . For , points opposite to and the torsion of a space curve is positive. Replacing by reflects the circular helix across the horizontal plane and makes the torsion of a space curve negative; then points in the same direction as . The direction of increasing is fixed in both panels.
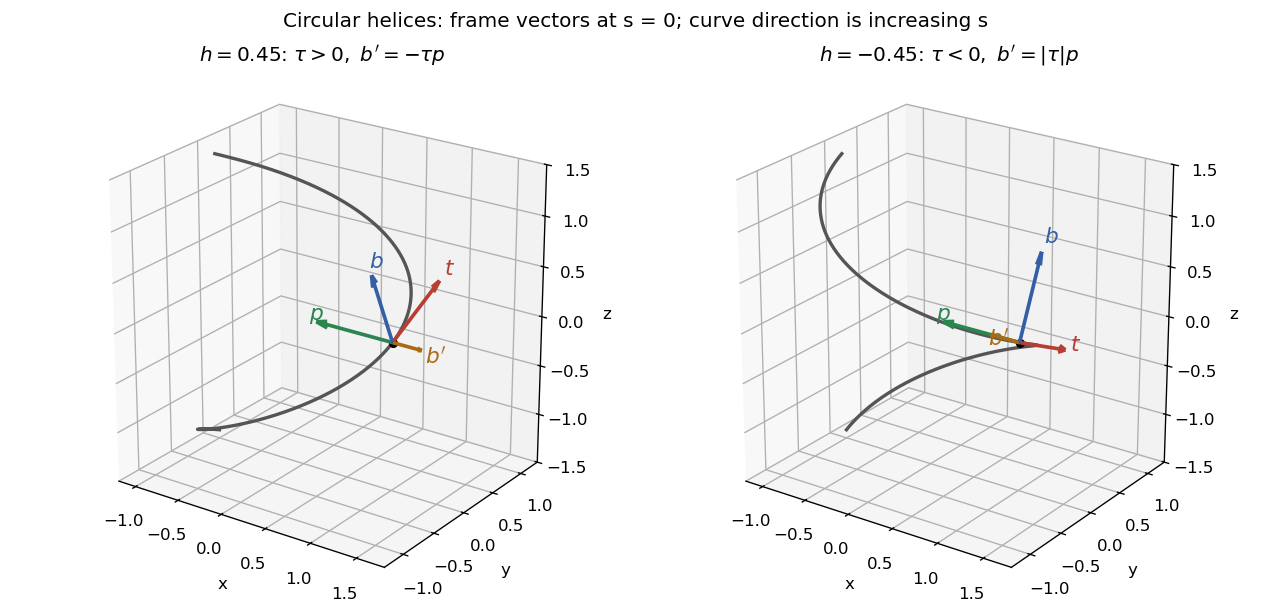
Unit-speed circular helices of opposite torsion, with tangent, principal normal, binormal and binormal derivative at the marked point
. Details. 
Past exam of the mathematics course of the University of Cambridge 2005 ii Paper 3 23H ii Solution Created 2026-09-24 Updated 2026-10-14
Let be the Frenet frame of the original space curve, with , , . Put . The normal-indicatrix arc-length satisfies , and its unit tangent is . On the unit sphere its outward normal is , and .
Differentiate in . The derivative of is parallel to and contributes nothing to its projection onto . The remaining derivative is , givingWith the alternative left-normal signed-curvature convention the displayed scalar changes sign, while the area conclusion is unchanged.
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 66 3 b Solution Created 2026-10-03 Updated 2026-10-14
Use the equal-time points to estimate velocity and acceleration with centered finite differences:At the endpoints use one-sided formulas of the desired order. A differentiated path and its time parametrization can instead supply these quantities. Let denote the gravitational acceleration, directed downwards. In the accelerating camera, the effective downward vector is , so the locally felt upward vector is . For a stationary camera this gives , fixing the sign.
The apparent-gravity camera frame is obtained by orthogonal projection and a cross product:When , are perpendicular unit vectors, and completes a right-handed orthonormal basis: . Also , so the felt-up vector lies in the plane, with its transverse component pointing towards positive .
The stated exclusion of ensures , but it does not ensure . If felt-up is parallel to travel, the roll angle is undetermined rather than the construction being impossible. Every transverse orthonormal basis then has the required plane property. For continuity, project the previous into and normalize it, using . If this projection is also too small, choose a coordinate unit vector least aligned with and project that vector instead. Switch to this transported choice near the parallel case to avoid numerical amplification. A stopped vehicle likewise needs a chosen limiting travel tangent vector, since its zero velocity itself has no direction. None of this requires a Frenet frame, which can fail where curvature vanishes.
Past exam of the mathematics course of the University of Cambridge 2009 ii Paper 2 25H a Solution Created 2026-09-24 Updated 2026-10-14
For an arclength-parametrized curve define the Frenet frame by , , and . Differentiating the unit lengths gives diagonal frame-derivative coefficients zero. Also implies , while . Define the torsion of a space curve by . Orthogonality then givesThese are the Frenet formulae. Differentiating also verifies the chosen torsion sign; equivalently .
Past exam of the mathematics course of the University of Cambridge 2009 ii Paper 2 25H b Solution Created 2026-09-24 Updated 2026-10-14
At a fixed initial parameter choose an orthogonal map sending to , to and to . Its determinant is . The transformed curve has Frenet frame , so its curvature is and its torsion is .
Both its frame and the frame of solve the same linear Frenet system with the same initial data. The uniqueness theorem for a linear ordinary differential system with continuous coefficients makes the frames identical on the whole interval. In particular , so their difference is a constant vector . ThusThe orientation-reversing rigid motion accounts for the reversal of torsion.
Past exam of the mathematics course of the University of Cambridge 2017 ia Paper 3 11B a Solution Created 2026-09-24 Updated 2026-10-05
For an arc-length parametrization, the unit tangent vector is , with . Its derivative is perpendicular to . The curvature of a space curve is ; where , its principal normal vector is , so . The binormal vector completes the positively oriented Frenet frame.
Differentiate to get . AlsoThus has only an component. Define the torsion of a space curve by , giving .
Next, , and differentiating the other inner products gives and . Hence the Frenet-Serret formulas areThese statements require enough smoothness, for example a curve with positive curvature on the interval under discussion. If , the unit tangent vector is still defined, but the standard principal normal vector, binormal vector and torsion of a space curve need not be; their existence cannot be inferred just from smoothness of the curve.
Past exam of the mathematics course of the University of Cambridge 2017 ia Paper 3 11B b Solution Created 2026-09-24 Updated 2026-10-05
Let and choose an orientation of a regular curve following the vector field. Its unit tangent vector is , where is constant along a connected regular segment. Arc length differentiation along that curve is . ThereforeTaking the cross product with removes the term parallel to :Where the Frenet frame exists, . ThusThe printed sign corresponds to orientation along or against the field. Taking magnitudes gives the orientation-independent curvature of an integral curve of a vector field, . This scalar formula also applies at zero curvature, where itself may be undefined.
Past exam of the mathematics course of the University of Cambridge 2017 ii Paper 2 23I Solution Created 2026-09-24 Updated 2026-10-05
For a regular parameter , the curvature and torsion of a space curve areThe torsion of a space curve requires . Reparameterize by arc length and set , , . Differentiating the pairwise inner products of this orthonormal Frenet frame shows that its derivative matrix is skew symmetric. Since , defining gives the Frenet-Serret formulasThe fundamental theorem of regular space curves says that prescribed smooth and smooth on an interval determine a unit-speed curve uniquely up to an orientation-preserving Euclidean rigid motion. Solve this frame's linear differential equation with an initial oriented orthonormal frame, then integrate ; uniqueness proves the assertion.
Under the intended convention that the shared parameter is arc length, equality on an open interval gives equal position and equal Frenet frames at one point. Equal give identical differential equations, so uniqueness gives . The printed “regular smooth” hypothesis alone does not establish this convention. Without common arc length, an orientation-preserving smooth change of speed that is the identity on but not elsewhere reparameterizes a circle into a counterexample: both curves have , and agree on , but differ elsewhere as parameterized curves.
For an oriented surface with unit normal , define normal curvature and geodesic curvature . ThusA unit-speed curve is a geodesic exactly when . If also , then , so it is a straight line. A vertical ruling of a circular cylinder is such a geodesic, although the cylinder contains no open piece of a plane. A nonconstant regular straight line cannot be a simple closed curve. Hence no planar patch is required, and such a geodesic cannot be simple and closed.
Past exam of the mathematics course of the University of Cambridge 2018 ii Paper 2 25I b Solution Created 2026-09-24 Updated 2026-10-03
For a unit-speed curve with nonzero curvature of a space curve , define the Frenet frameThe torsion of a space curve iswith this choice of convention.
For the requested example, take the unit-speed circleand the unit-speed circular helixBoth have the constant nonzero curvature , but their torsions are respectively and . A proper Euclidean motion of Euclidean three-space preserves torsion, so no such rigid motion relates the two curves.
Past exam of the mathematics course of the University of Cambridge 2021 ia Paper 3 9B a Solution Created 2026-09-24 Updated 2026-09-25
Past exam of the mathematics course of the University of Cambridge 2023 ii Paper 2 26G a Solution Created 2026-09-24 Updated 2026-09-25
Let be a regular curve parametrized by arc length, so . Define the Frenet frameand define the torsion byThus curvature requires two derivatives, while and torsion require ; the displayed classical torsion requires three derivatives. At a point where , and are not defined by this construction.
Since is an orthonormal frame, differentiating its inner products shows that its derivative matrix is skew-symmetric. The definition gives . Next,so . As and , we have ; hence . The Frenet-Serret formulas are therefore