Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Geodesic polar coordinates
Past exam of the mathematics course of the University of Cambridge 2005 ii Paper 2 24H Solution Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2010 ii Paper 4 24H ii Solution Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2010 ii Paper 4 24H i Solution Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2015 iii Paper 17 4 Solution Created 2026-10-03 Updated 2026-10-06
Write for the Levi-Civita connection and define its Christoffel symbols by . For the Riemannian metric matrix and its inverse ,A curve with affine parameter is a geodesic when , equivalentlyThe connection is metric compatible and torsion free; in particular . The coordinate velocities are , and the displayed coefficients are smooth functions of position.
For whose initial-value geodesic exists through time , with and , define . The domain is open and contains a neighborhood of zero. Indeed the geodesic equation is a smooth first-order ODE in ; the constant solution with initial velocity zero exists through time , and existence on a compact time interval and smooth dependence persist for nearby initial data. Reparameterization and uniqueness give wherever defined. Consequently the differential of the exponential map at zero isThe inverse function theorem gives a neighborhood of zero on which is a diffeomorphism onto a neighborhood of . Shrink to a ball in and choose an orthonormal basis there. Its linear coordinate functions composed with are the geodesic normal coordinates on . This establishes well-defined local coordinates without assuming geodesic completeness.
In these geodesic normal coordinates, every radial geodesic has coordinate expression . Its equation at reads for every . The coefficients are symmetric in by the torsion-free connection property. Evaluating at the coordinate unit vectors and their pairwise sums, or using the polarization identity, therefore givesThis is the fact that Christoffel symbols vanish at the center of normal coordinates. Also , since is the identity in an orthonormal basis.
For sufficiently small , the geodesic sphere is . It is a smooth hypersurface because is a diffeomorphism on the ball. It equals the local distance sphere for sufficiently small radius, as the length comparison below shows; no assertion of global smoothness for large radii is needed.
The full Gauss lemma isfor in a star-shaped domain of and . To prove it, set , and , for near zero. Every -curve is a geodesic and has squared speed . The torsion-free connection property and the commuting parameter fields give ; metric compatibility and then giveAt , , so . Integration from to followed by setting proves the boxed identity, because and . For any in the domain, a small neighborhood of its compact radial segment suffices for the variation. The zero vector is covered directly.
In particular, if , the images of the radial and spherical tangent directions are orthogonal; taking also proves preservation of radial length. Thus in geodesic polar coordinates the Riemannian metric has radial part and no mixed radial-angular term. Every curve in a small normal ball from its center to radial coordinate has length at least , by integrating the absolute radial derivative; the radial geodesic realizes this length. To exclude shortcuts leaving the ball, choose a larger normal ball of radius with compact closure in and restrict to : an escaping curve first reaches radial coordinate and already has length at least . This proves the asserted small-radius distance interpretation and orthogonality of radial geodesics to geodesic spheres.
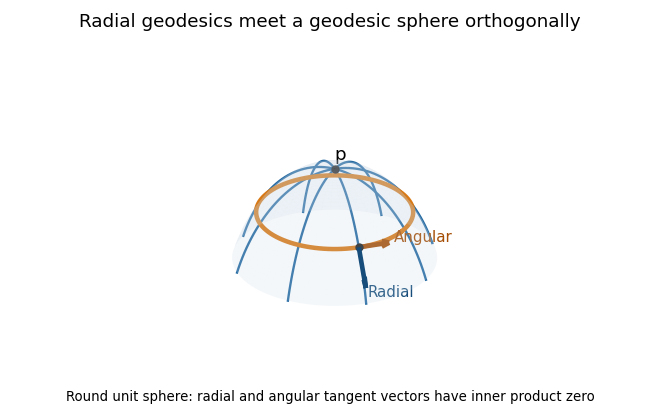
Radial geodesics and a geodesic sphere on the round unit sphere, with orthogonal radial and angular tangent vectors
. Past exam of the mathematics course of the University of Cambridge 2020 ii Paper 3 25I b Solution Created 2026-09-24 Updated 2026-09-29
Choose an orthonormal basis of and write . On a punctured disc on which the exponential map is a diffeomorphism, the mapdefines geodesic polar coordinates centred at . The curves are unit-speed geodesics, so the first coefficient of the first fundamental form isThe Gauss lemma says that radial and angular coordinate vectors are orthogonal, hence
The angular variation is a Jacobi field along each radial geodesic, with initial dataSince , smooth dependence of the geodesic flow givesConsequentlyas required.
Past exam of the mathematics course of the University of Cambridge 2020 ii Paper 4 25I d i Solution Created 2026-09-24 Updated 2026-10-03
False with the printed in the paper. Let the even-indexed surfaces be one fixed unit sphere and the odd-indexed surfaces one fixed ring torus. Thenbut infinitely many surfaces are tori. The two fixed surfaces lie in one ball and have uniformly bounded area. Their injectivity radii have a positive common lower bound, and compactness gives a common bound on , hence on every radial derivative . Thus this alternating sequence satisfies all four additional conditions as well.
The intended statement becomes true if is replaced byHere is the proof. Put , so . Choose maximizing distance from the centre of the fixed containing ball. The supporting-sphere curvature bound givesWrite and in geodesic polar coordinates. Choose a fixed sufficiently small and set . Conditions (3) and (4) allow to be chosen so that andThe Jacobi equation , with and , and the Sturm comparison theorem then give on this ball for a constant independent of . ConsequentlySince elsewhere and ,for all sufficiently large . Gauss-Bonnet forces , and the classification theorem for surfaces makes each such a sphere.
Past exam of the mathematics course of the University of Cambridge 2025 ii Paper 4 25I a Solution Created 2026-09-24 Updated 2026-09-25
For in a sufficiently small neighbourhood of , let be the geodesic satisfying and . The exponential map at isChoose an oriented orthonormal basis of , write , and define geodesic polar coordinates by