At an equilibrium point, and . The first equation gives or . Substituting in the second gives, respectively,These are all the equilibrium points. The Jacobian matrix of the vector field isAt ,The eigenvalue has algebraic multiplicity two and eigenspace . For the linearized coordinates , ,Both components tend to zero. The repeated eigenvalue with one independent eigenvector makes this a stable improper degenerate node, a sink equilibrium. The term is the signature of the nontrivial Jordan block. Since it is a hyperbolic equilibrium point, the linearization stability theorem gives local asymptotic stability of the nonlinear system. Approaching trajectories are tangent to the vertical eigendirection.
At ,One eigenvalue is positive and one negative, so this point is a saddle equilibrium. Its stable manifold is tangent to , and its unstable manifold is tangent to .
For the phase portrait, the nullclines areAbove the second line the vertical flow is downward, and below it upward. For , horizontal flow is to the right below and to the left above it; for the directions reverse. The line is invariant, with , so it flows toward . Together with the saddle's two invariant directions, these signs determine the sketch.
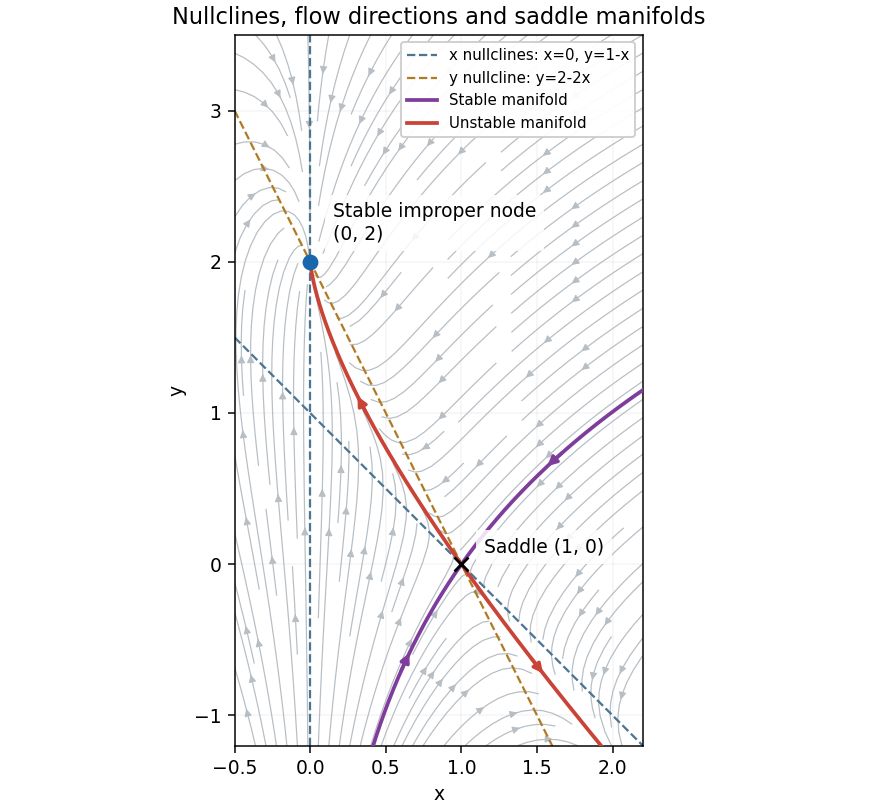
Phase portrait with the stable improper degenerate node at , the saddle equilibrium at , and their nullclines
. Details. 
The Bendixson-Dulac theorem says that a continuously differentiable planar vector field has no nonconstant periodic orbit in a simply connected region if a continuously differentiable Dulac function makes its rescaled divergence have one sign and not vanish identically on any open subset of that region. Isolated zeros of the divergence are allowed in this form.
Take the Dulac function to be one. For the exact vector field ,This is positive except at the origin. The plane is simply connected, so there are no nonconstant periodic solutions. Equivalently, a hypothetical closed trajectory would have zero outward flux of its tangent vector field, while Green's theorem would make that flux the strictly positive area integral of the divergence.
The origin is the only equilibrium point: forces , and then forces . Its Jacobian matrix is zero, so the linearized equations are . They give no stability classification.
Keeping cubic terms gives the homogeneous approximationIn a sector where , use as the independent variable and put . Dividing the two equations givesThe integrating factor gives , hence . Rearranging and renaming the arbitrary constant yields the implicit trajectoriesThis is the first integral of the cubic approximation, not an exact first integral of the higher-degree original system. The invariant axes, excluded by the divisions, must be added: on , ; on , . The diagonal trajectories correspond to . For fixed finite , non-axis trajectories approaching the origin satisfy , so their limiting tangent lines are the diagonals. This is the cubic planar flow with diagonal approach directions.
Every nonzero trajectory moves outward locally. For , the exact system givesThis implies departure from any fixed small circle for every nonzero starting point inside it: while a trajectory stayed inside forever, would eventually force negative. Thus the origin is unstable and repelling for both the cubic approximation and the full system. The argument establishes nonlinear instability despite the zero linearization.
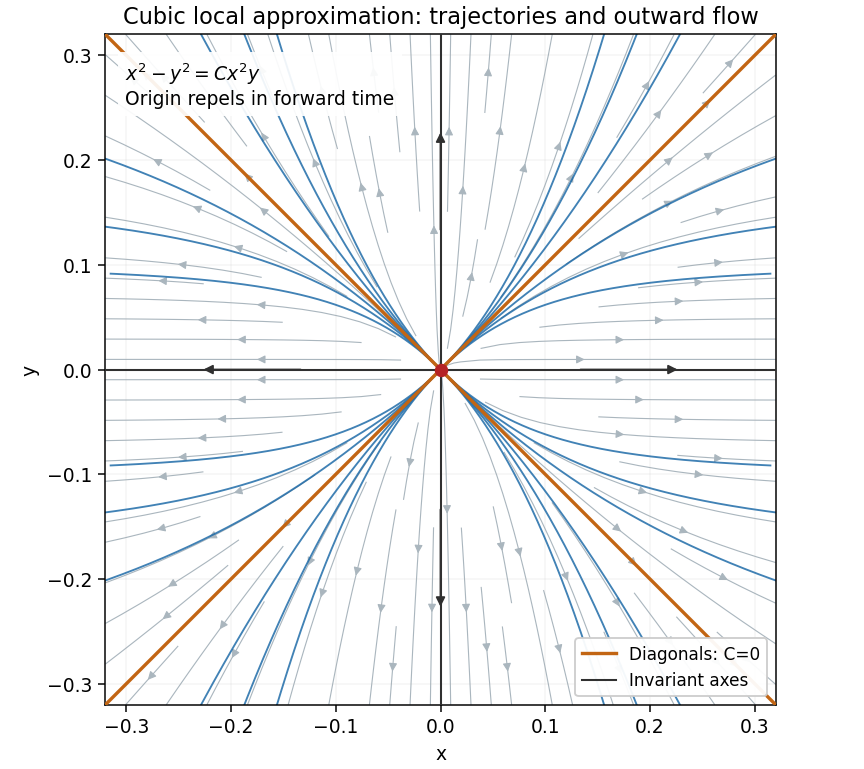
Implicit trajectories of the cubic approximation: invariant axes and diagonal limiting directions, with all forward arrows outward
. Details. 
Articles by others on the same topic
There are currently no matching articles.