A spatial image after a chosen dark interval is a different readout from continuously recording arrivals at a fixed probe. Here is an original idealised fluorescence imaging model: release a dilute cloud, let it move freely, then apply a short uniform probe pulse. Neglect collisions, residual forces, attenuation and motion during the pulse. Use each image's cloud centre to remove mean drift. Uniform gravity shifts that centre without changing the centred variance.
For each atom let along a horizontal imaging axis. Expanding the square about the expected values gives exactlyNo Gaussian distribution is needed for this variance identity. A jointly Gaussian distribution of initial positions and velocities does make the later density Gaussian. For a separable three-dimensional cloud viewed along , integration along the viewing direction gives the column densityHere is atom number. Integrating this image along leaves a one-dimensional Gaussian distribution with standard deviation . This is a projected density measurement, not a three-dimensional radius or a direct velocity histogram. Under the uniform, optically thin probe assumptions, expected fluorescence is proportional to this column density. A known, independent point spread function with finite variance adds its own variance to the measured width; probe duration and intensity gradients need separate treatment.
For a Maxwell-Boltzmann distribution, , where is atomic mass and the Boltzmann constant. For a nonthermal distribution this defines a directional second-moment temperature, which need not describe every feature of the distribution. A covariance between position and velocity can initially narrow the cloud even though is positive. The physical covariance matrix requires .
Choose , and , giving correlation coefficient . With in milliseconds, the numerical variance in square millimetres is . Its minimum occurs at , with standard deviation . These chosen values satisfy the covariance matrix constraint; early contraction is compatible with free motion.
Generate thirteen synthetic variance observations at equally spaced times from to , adding independent Gaussian noise of standard deviation . Linear least squares fits all three coefficients in . The example yields , and . With the chosen approximate sodium mass , the true is and the fitted value is . This is a fit to generated width data, not historical observations.
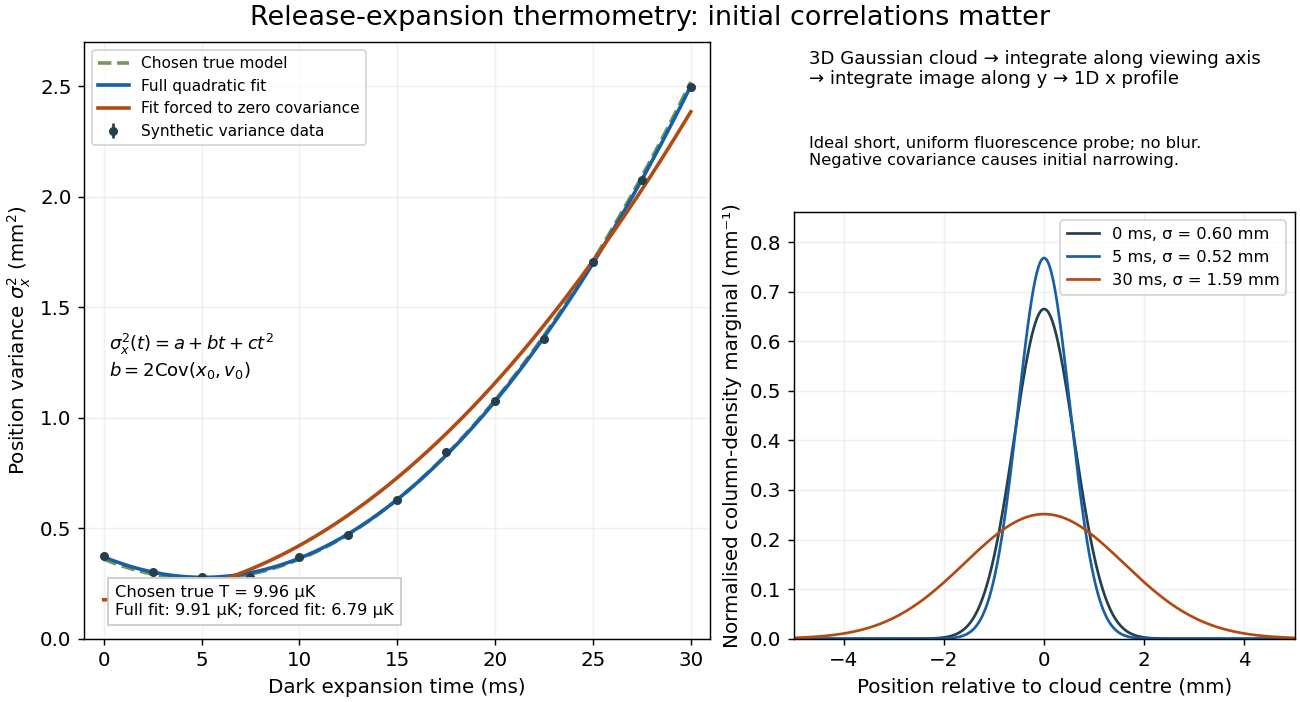

If the same data are fitted to , forcing , the inferred falls to . The omitted term is partly absorbed into both fitted coefficients. In noiseless linear least squares with a free intercept, its precise effect on the quadratic coefficient iswhere the subscript denotes equal-weight moments over the chosen observation times, using one consistent unit system. Since the ratio is positive for distinct nonnegative times, negative biases this estimate downwards. An incorrect release-time origin can also generate a linear term, so fitting it does not by itself identify a physical initial covariance. Timing calibration, spatial resolution, residual magnetic fields and probe-induced recoil energy remain separate controls. Neither a cold-looking image nor a single long expansion time identifies all three coefficients.
Articles by others on the same topic
There are currently no matching articles.