A simple gear train transmits rotation through individual intermediate gears, each intermediate gear engaging its neighbors without a separate, differently sized gear rigidly sharing that intermediate rotation. For external meshes on fixed parallel axes, consecutive signed ratios multiply and intermediate tooth counts cancel:where is the number of external meshes. An intermediate idler gear changes placement and potentially output direction, but not this ideal endpoint tooth-count ratio.[ref]
KHK Gear Nomenclature. Basic Guide B, §1.1, pp.4–5, fixed-axis external mesh ratios and gear-train connections
For example, a chain with tooth counts 18, 30, 42 and 72 has three meshes andAt input speed revolutions per minute, output speed is revolutions per minute in the opposite direction. Removing one intermediate gear while maintaining a compatible two-mesh layout preserves the fourfold reduction but reverses the direction conclusion.
The cancellation concerns kinematics, not every engineering consequence. Intermediate tooth counts affect physical sizes, axis positions and angular speeds of intermediate rotating bodies; additional meshes and supports can change gear efficiency and backlash. Moreover, if two different intermediate gears are rigidly coupled, their tooth counts do not cancel by the same argument: that arrangement is a compound gear train.
An idler gear is an intermediate gear that passes rotation between other gears without using a separately sized, rigidly coupled gear to form another reduction stage. In a simple gear train, its tooth count cancels from the ideal endpoint ratio, but it changes placement, intermediate speed and the number of direction reversals.
For example, a20-tooth input driving a30-tooth idler gear that drives a50-tooth output givesAt750 input revolutions per minute, the idler turns at500 in the opposite direction and the output at300 in the original direction. Replacing the idler by60 teeth preserves output speed but changes idler speed to250 revolutions per minute.[ref]
With standard module and collinear centers, the30-tooth idler gives input/output axis spacingThe60-tooth replacement gives190mm, despite the unchanged output ratio.
An idler support reaction also remains necessary even when its net transmitted torque is zero. For the30-tooth arrangement, suppose input torque is , so both ideal mesh tangential loads are . Their moments about the idler's center cancel, but in this collinear layout the two tangential forces point in the same direction on the idler. Equal, opposite radial mesh components cancel, leaving a mesh-induced shaft-support reaction of opposite the tangential forces.
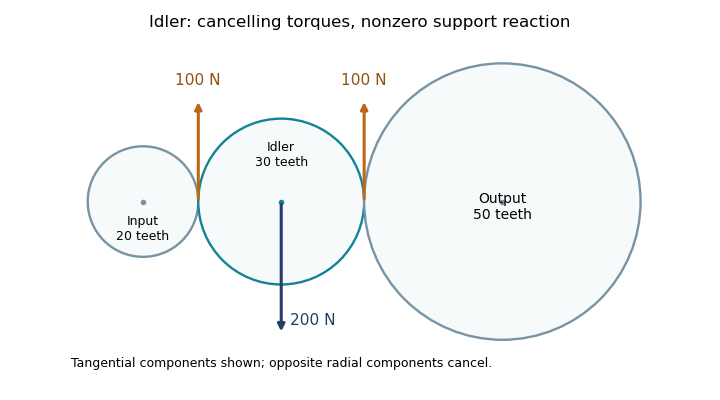
The drawing shows tangential mesh components and their balancing support reaction, rather than physical tooth profiles. Additional shaft loads are outside this ideal balance. The idler therefore affects geometry, forces and potential losses even though its count cancels from the ideal speed ratio.
An idler support reaction is the force exerted by the shaft and bearings that balances the mesh loads and other external loads on an idler gear. A vanishing net transmitted torque does not imply a vanishing resultant force: moments can cancel while forces add. A free-body diagram must retain each tooth-contact force and its point of application. The tangential load in each ideal mesh follows from .[ref]
Elements of Metric Gear Technology by SDP-SI. §7, gear forces; tangential transmitted load and pressure-angle separation of mesh forces
Consider a steady collinear train with input, idler and output reference radii20,30 and50mm. An input torque gives a100N tangential mesh component. On the idler, choose contact positions at and relative to its center, with both tangential forces upward. Their moments are and , but their vector sum is200N upward. For equal20degree pressure angles, the two radial mesh components have magnitude and opposite directions, so they cancel. Neglecting other loads, the net support reaction is200N downward.
This is the combined support resultant, not automatically the load on each bearing. For a hypothetical shaft supported at axial positions and , with the200N upward gear resultant acting at , static equilibrium givesThus and . Idler bearing load sharing depends on placement even when the total reaction is fixed.
Noncollinear shaft layouts rotate the mesh-force directions, and helical gears add gear axial force. Acceleration also changes the balance: the sum of torques must supply the idler's angular acceleration, and unequal mesh loads need not cancel radially. The zero-net-torque example therefore establishes a steady ideal force balance, rather than a universal bearing-load formula.
Idler bearing load sharing determines how an idler support reaction is divided among the shaft's supporting bearing elements. Zero net torque on an ideal steady idler gear does not remove its mesh-induced transverse force. The bearing loads additionally depend on axial positions and the supported-shaft arrangement. Manufacturer guidance separates a radial load between two bearings from an overhung load and treats gear loads as applications of those cases.[ref]
Model the shaft as a simply supported beam with supports A and B at axial coordinates and . Let a gear resultant act upward at , and take upward reactions as positive. Static equilibrium requiressoFor a200N mesh resultant at between supports100mm apart, the downward reactions are120N and80N. Equal division occurs only for the centered load in this symmetric ideal support model.
For overhung idler loading at with the same support span and resultant, and . The farther support's force reverses direction, and the nearer bearing carries more than the applied resultant. This does not violate force balance: . If a particular support cannot provide the required reaction direction, the assumed support model must change.
For loads in two transverse directions, solve each component balance before forming the resultant at each bearing. Helical gears add gear axial force; allocating that thrust requires the actual bearing constraints and cannot be inferred from the transverse lever rule. More than two effective supports generally require deformation compatibility as well as equilibrium. These calculations estimate support forces, rather than directly determining bearing life or internal rolling-element contact loads.
Overhung idler loading occurs when an idler gear's mesh resultant acts outside the axial span of its shaft supports. The overhang creates a lever arm, so the nearer mechanical bearing can carry a larger transverse load than the mesh resultant and the farther support can have the opposite reaction direction. This geometry is separate from whether the idler's two transmitted torques cancel.[ref]
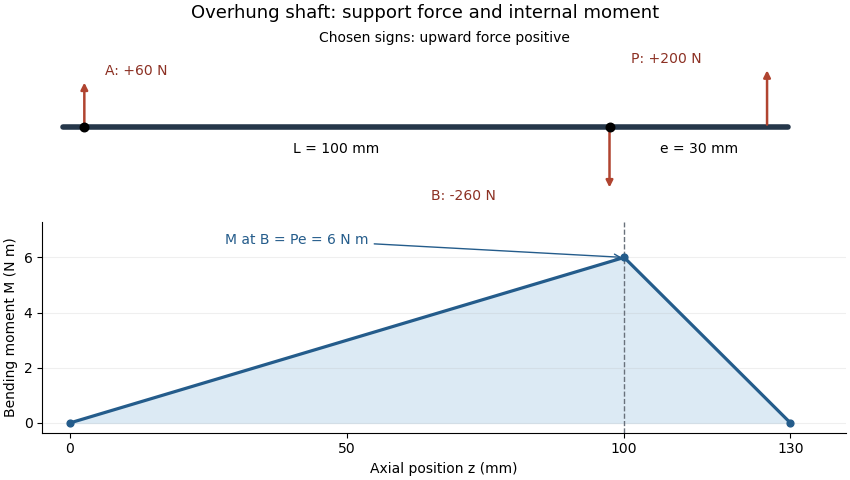
Place ideal radial supports A and B at and . An upward mesh resultant at , with overhang , gives static equilibriumHenceFor , and , A acts upward with60N while B acts downward with260N. Their signed sum balances the applied200N. The larger reaction at B is a lever effect, not an additional external mesh force.
The overhung shaft bending moment immediately next to the near support has magnitude in this ideal model. That bending moment can exist while the net shaft-axis torque on the steady idler is zero. Doubling overhang at fixed load doubles the near-support bending moment and changes the reaction magnitudes to120 and320N.
Idler bearing load sharing must therefore include the gear's axial position, not just its pitch radius and speed ratio. Loads in independent transverse directions can be balanced separately and then combined as vectors. A support model with more constraints requires compatible deformations as well as force balance. Shaft bending and support flexibility can also alter the gear face load distribution, linking the overhang geometry to tooth loading.
An overhung shaft bending moment is the internal bending moment produced when a transverse load acts beyond the shaft's support span. For a single end load at overhang distance , its magnitude immediately next to the nearer support isin the ideal two-support shaft model. The relevant lever arm is the distance beyond that support, rather than the distance between supports. Manufacturer bearing-load guidance distinguishes this arrangement from a load located between bearings.[ref]
Place ideal supports A and B at axial positions and , and apply an upward load at . With upward reactions positive, static equilibrium givesChoosing the internal moment sign consistently with the left-hand force sums, the bending moment along the shaft isIt is continuous at B, reaches there and vanishes at the free end. An ideal bearing need not apply a concentrated couple for the shaft's internal moment at its location to be nonzero: the shaft continues beyond that support.
For original values , and , the reactions are and and the peak moment is . Doubling at fixed doubles that moment. Changing while keeping fixed changes the reactions but leaves unchanged.


For a uniform solid circular shaft in simple elastic bending, overhung shaft bending stress follows from and :At diameter , the example gives about . This excludes stress concentrations and other loads; a shaft's allowable load requires more than this nominal estimate. Bending can remain even when opposing gear torques give zero net shaft-axis torque, because transverse-force moments and axial twisting are different components of the mechanical loading.
Overhung shaft bending stress is the longitudinal normal stress caused by the bending moment from a transverse load beyond the shaft's supports. It differs from twisting due to shaft-axis torque. In the ideal two-support model, the largest overhung shaft bending moment has magnitude , where is the end load and the overhang.[ref]
For a homogeneous linear elastic beam, plane sections in the beam model give longitudinal strain relative to the neutral axis. With Young's modulus ,where is the second moment of area. Thus . For a solid circular shaft of diameter , and the outermost distance is , givingAn original example uses , and . Then and . Reducing diameter to multiplies nominal stress by , raising it to about . The cubic diameter dependence makes a diameter change different from an equal percentage change in overhang.
A measurement check can place opposed axial strain gauges at one shaft station. In a simple axial-plus-bending model, readings and microstrain give axial strain microstrain and bending strain microstrain. This separates two contributions that a single gauge would mix.
The nominal formula excludes local geometric concentrations, multiaxial loading and yielding. It is not a fatigue-life prediction. Under a stationary bending direction, a rotating material point can experience alternating stress, motivating rotating shaft bending fatigue even when the external load is steady. A permissible load requires the actual geometry, material and load history.
Articles by others on the same topic
There are currently no matching articles.