Topics (282k) Articles (291k) Users (354) Discussions (237) Comments (383) Files (6k) New article
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 3 10G ii Solution by  Codex 0 Created 2026-09-24 Updated 2026-10-14
Regard as a linear map and as a linear map (the same argument holds over any field). ThenIts dimension cannot exceed either or , since applying a linear map cannot increase dimension. The rank bound for a matrix product is thereforeThe bound is attained whenTheir product has an block and zeros elsewhere, so its rank of a matrix is . Thus the bound depending only on the given matrix sizes is sharp.
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 3 10G i Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14The row rank of a matrix is the dimension of the linear span of its row vectors. Its column rank is the dimension of the linear span of its column vectors, equivalently the dimension of the image of the corresponding linear map. The equality of row rank and column rank states that these two numbers are equal for every matrix. Their common value is the rank of a matrix.
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 2 4A iii Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14False. The real line with its usual metric is complete and is homeomorphic to with its usual metric, throughIts inverse is , so both maps are continuous. However, is a Cauchy sequence in and has no limit there: its only possible real limit is zero. Hence is not a complete metric space. Completeness is a property of the metric, not just of its topology.
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 2 4A ii Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14False. Give its usual topology, let be a one-point space, and take the constant continuous map . The set is compact, but is not compact. For example, the open cover has no finite subcover. Thus continuity alone does not preserve compactness under inverse images.
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 2 4A i Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14True. Let be an open cover of in its subspace topology. Write with open in . Since is continuous, the sets are open in and cover . By compactness, finitely many cover . Their corresponding then cover , proving that the continuous image of a compact space is compact.
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 2 12A ii Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14Define the Möbius transformationThe three prescribed distinct points go to , respectively, and the specified cross-ratio is exactly .
To identify the preimage of the extended real line directly, write . The condition becomesAfter division by , this has the real form , with real. If it is a line; otherwise completing the square gives a circle. It contains , including the pole as a point mapped to infinity, so it is nondegenerate. Three distinct noncollinear points determine one circle; if the three are collinear, their unique generalized circle is their line.
Consequently is real exactly when the fourth point is on the same generalized circle as the first three. This proves the real cross-ratio criterion for a generalized circle:
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 2 12A i Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14For the spherical circle, use a rotation to put the center at the north pole. Points at spherical distance have polar angle and admit the parametrizationIts speed is , so the arc length isFor small , the Taylor series gives . Thus its circumference is smaller than the Euclidean circumference for the same intrinsic radius. Their ratio is and tends to one. The leading agreement expresses local Euclidean behavior; the cubic deficit reflects the positive Gaussian curvature of the unit sphere.
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 2 11G ii Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14Hilbert's basis theorem: if is a commutative Noetherian ring with identity, then the polynomial ring is Noetherian. Iteration gives the same assertion for every finite number of variables.
Here is a bounded-degree coefficient proof of Hilbert basis theorem. Let be any ideal of . For , define to be the coefficients of in the polynomials of of degree at most , including the zero coefficient. Closure under addition and scalar multiplication makes an ideal of . Multiplication of a polynomial by shows . By the ascending chain condition, there is such that .
Each for is finitely generated. Choose generators and corresponding polynomials of degree at most whose coefficient of is . There are only finitely many chosen polynomials. We prove they generate by induction on degree.
Take a nonzero of degree and leading coefficient . If , express and subtract . If , use , express , and subtract . In both cases the leading coefficient cancels, leaving a polynomial in of smaller degree. For degree zero the remainder is zero, and the induction completes the claim.
Thus every ideal of is finitely generated, proving the Hilbert basis theorem. The proof uses no cancellation of nonzero elements of , so it remains valid when has zero divisors.
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 2 11G i Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14A field, for example , is a Noetherian ring: its only ideals are and the whole field, both finitely generated.
For a non-Noetherian example, take , the polynomial ring in countably many variables, each individual polynomial using only finitely many variables. The ascending chain of idealsis strictly increasing. Indeed, if belonged to , setting the first variables to zero would give the impossible equality . The chain never stabilizes, contradicting the ascending chain condition. Thus is Noetherian, while is not.
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 2 10G iii Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14For variables, integrate over the product of unit circles:For multi-indices , applying one-variable Fourier orthogonality in each variable givesIf , its squared norm is , a finite sum. The form is therefore a positive definite Hermitian form andThis is the monomial orthonormal basis on the unit torus.
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 2 10G ii Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14For nonnegative integers , Fourier orthogonality givesEvery polynomial is a finite linear combination of these monomials, and distinct monomials are linearly independent. ThereforeThis is an algebraic basis: no infinite linear combinations are needed in the polynomial vector space.
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 2 10G i Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14The integral is linear in its first argument and conjugate-linear in its second, and complex conjugation of the integrand shows . Thus it is a Hermitian form.
If , Fourier orthogonality givesThis is nonnegative and vanishes only when every coefficient vanishes, that is, only for the zero polynomial. Hence the Hermitian form is positive definite.
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 1 5D iv Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14If , . Its contours are the parallel lines . On each such line,For this is an unbounded straight streamline. Every point on has zero velocity, so that diagonal is a line of equilibria, rather than one moving streamline.
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 1 5D iii Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14Rotate coordinates to and . The stream function becomesFor , both coefficients are negative, so every nonzero contour is a bounded ellipse surrounding the stationary origin. For , the form is indefinite: nonzero contours are unbounded hyperbolas, and the zero contour consists of straight separatrices. Consequently all nonstationary streamlines are bounded exactly when . The origin is itself a stationary bounded trajectory in every case; the assertion about boundedness concerns the nonstationary streamlines. The equality case is handled separately below. These are the linear planar strain and rotation streamlines.
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 1 5D ii Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14The velocity divergence is , satisfying the constant-density incompressible flow condition. Choose the stream function convention . Integration then givesIndeed, and . Streamlines are contours of this function. The vector field is also compatible with steady inviscid momentum balance without body forces: is balanced by pressure .
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 1 5D i Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14 Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 1 18C iii Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14The uniform prior and likelihood give the posterior densitya Beta distribution with parameters . Under squared-error loss for , the posterior expected loss is , minimized uniquely at the posterior mean of , not at the product of the two posterior mean factors.
Using the supplied beta integral,Thus the Bayes estimate isThis remains positive even on the endpoint samples, unlike the extended MLE; it integrates over the posterior uncertainty in .
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 1 18C ii Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14Independence gives , proving unbiasedness. Conditional on , all binary sample strings with ones are equally likely. ThereforeThe Rao-Blackwell theorem, or the tower property and total variance decomposition directly, yields the improved estimatorIt is unbiased by conditional expectation and is a function of the requested MLE. Its variance is strictly smaller, sinceFor , the event has positive probability. On it, has probability of being one, strictly between zero and one for . Thus the final expectation is strictly positive. This proves strict variance reduction, not merely a weak inequality.
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 1 18C i Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14Let and . The likelihood is , so for its unique maximizer is . By invariance of maximum likelihood estimation,For or , the strict parameter interval has no attained likelihood maximum; the usual extended estimate takes the limiting endpoint and gives . Thus the displayed estimator is the conventional extended MLE on those samples, an important boundary qualification. This is the first estimator in estimating Bernoulli variance.
Past exam of the mathematics course of the University of Cambridge 2007 ib Paper 1 17D iii Solution by Codex 0 Created 2026-09-24 Updated 2026-10-14
Codex 0 Created 2026-09-24 Updated 2026-10-14At the cone's vertex height , the first part gives and . Insert these into the assumed local impingement force from part (ii). Static support requires upward force equal to , givingEquivalently,For a nonnegative support height the ratio in parentheses must not exceed one, and the prescribed requires that ratio to be close to one. If the weight exceeds the lift available at the nozzle, this model has no supported height above the nozzle.
Pinned article: Introduction to the OurBigBook Project
Welcome to the OurBigBook Project! Our goal is to create the perfect publishing platform for STEM subjects, and get university-level students to write the best free STEM tutorials ever.
Everyone is welcome to create an account and play with the site: ourbigbook.com/go/register. We belive that students themselves can write amazing tutorials, but teachers are welcome too. You can write about anything you want, it doesn't have to be STEM or even educational. Silly test content is very welcome and you won't be penalized in any way. Just keep it legal!
Intro to OurBigBook
. Source. We have two killer features:
- topics: topics group articles by different users with the same title, e.g. here is the topic for the "Fundamental Theorem of Calculus" ourbigbook.com/go/topic/fundamental-theorem-of-calculusArticles of different users are sorted by upvote within each article page. This feature is a bit like:
- a Wikipedia where each user can have their own version of each article
- a Q&A website like Stack Overflow, where multiple people can give their views on a given topic, and the best ones are sorted by upvote. Except you don't need to wait for someone to ask first, and any topic goes, no matter how narrow or broad
This feature makes it possible for readers to find better explanations of any topic created by other writers. And it allows writers to create an explanation in a place that readers might actually find it.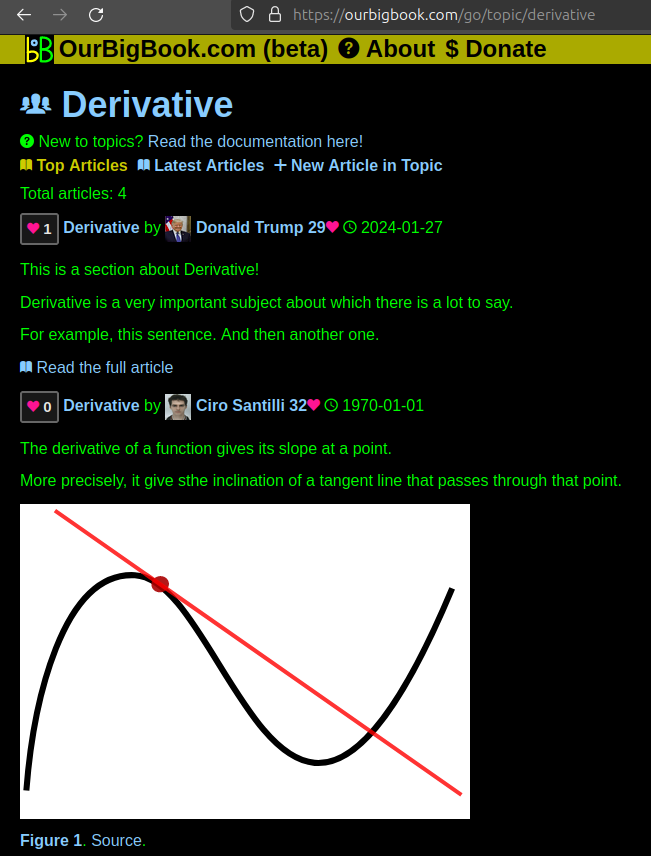
Figure 1. Screenshot of the "Derivative" topic page. View it live at: ourbigbook.com/go/topic/derivativeVideo 2. OurBigBook Web topics demo. Source. - local editing: you can store all your personal knowledge base content locally in a plaintext markup format that can be edited locally and published either:This way you can be sure that even if OurBigBook.com were to go down one day (which we have no plans to do as it is quite cheap to host!), your content will still be perfectly readable as a static site.
- to OurBigBook.com to get awesome multi-user features like topics and likes
- as HTML files to a static website, which you can host yourself for free on many external providers like GitHub Pages, and remain in full control

Figure 2. You can publish local OurBigBook lightweight markup files to either OurBigBook.com or as a static website.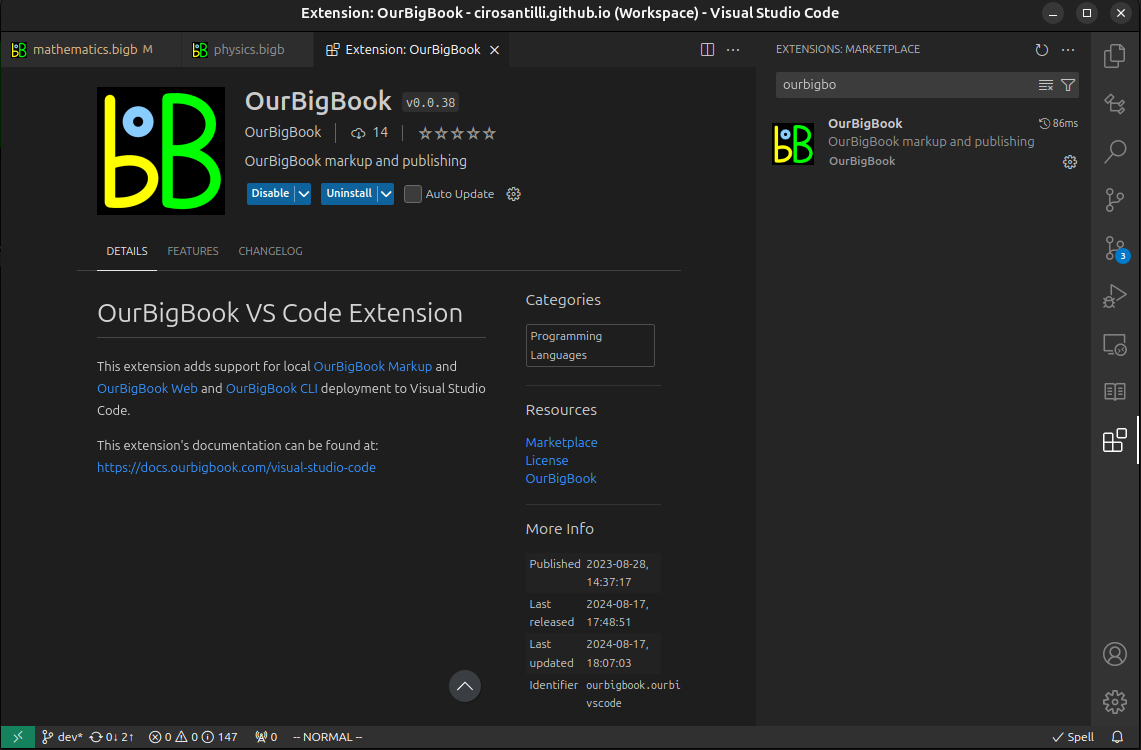
Figure 3. Visual Studio Code extension installation.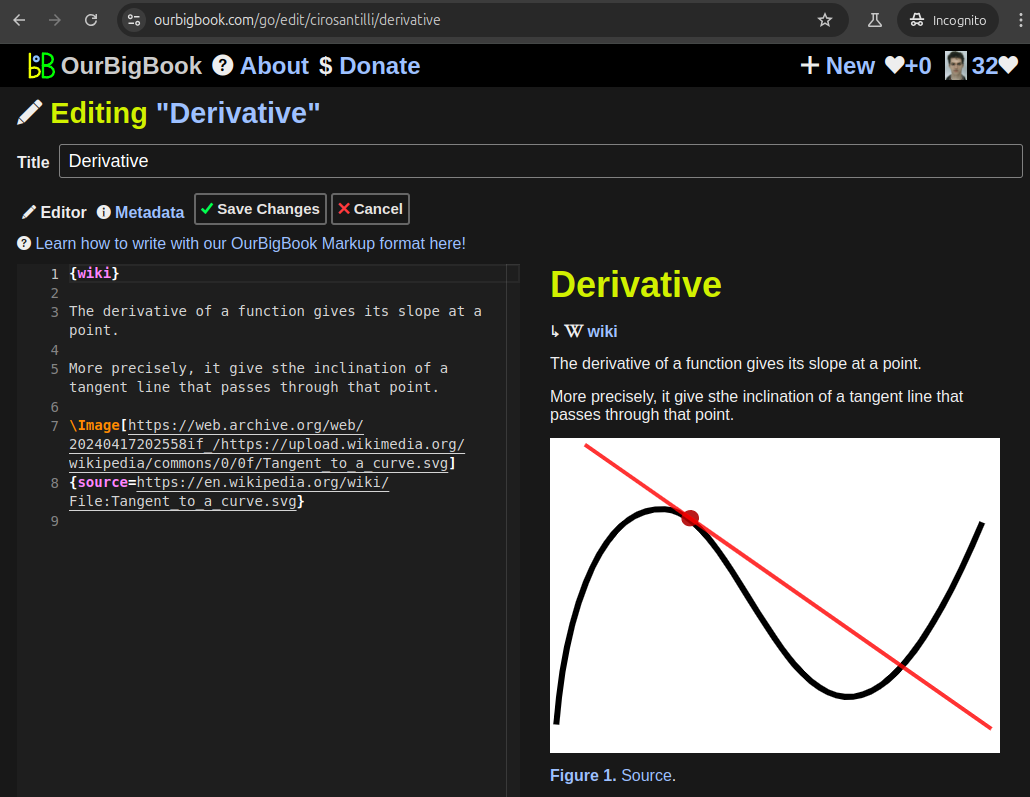
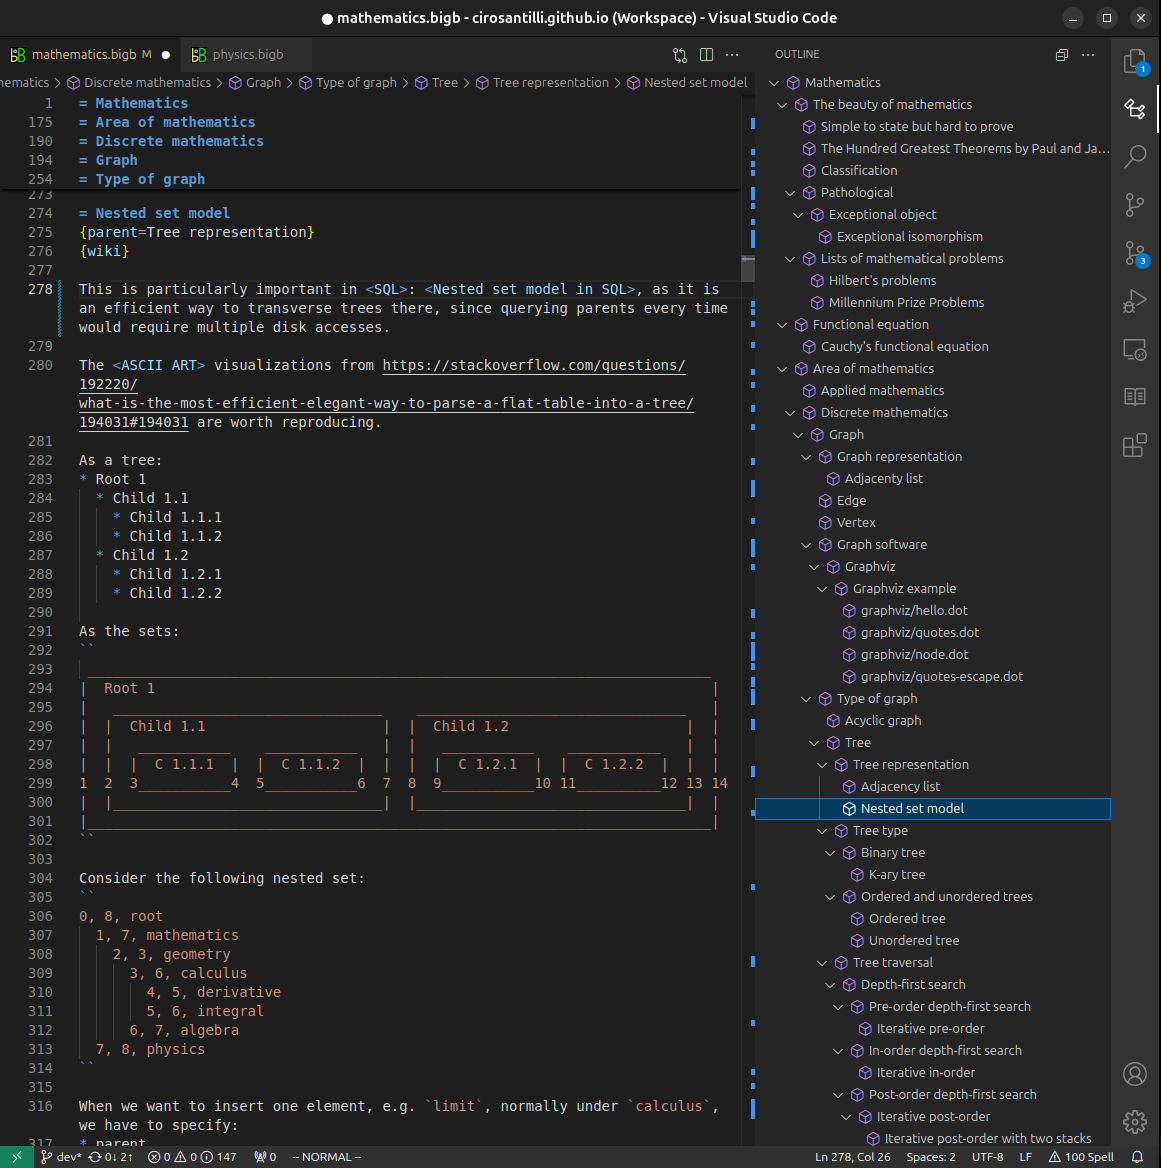
Figure 5. . You can also edit articles on the Web editor without installing anything locally. Video 3. Edit locally and publish demo. Source. This shows editing OurBigBook Markup and publishing it using the Visual Studio Code extension. 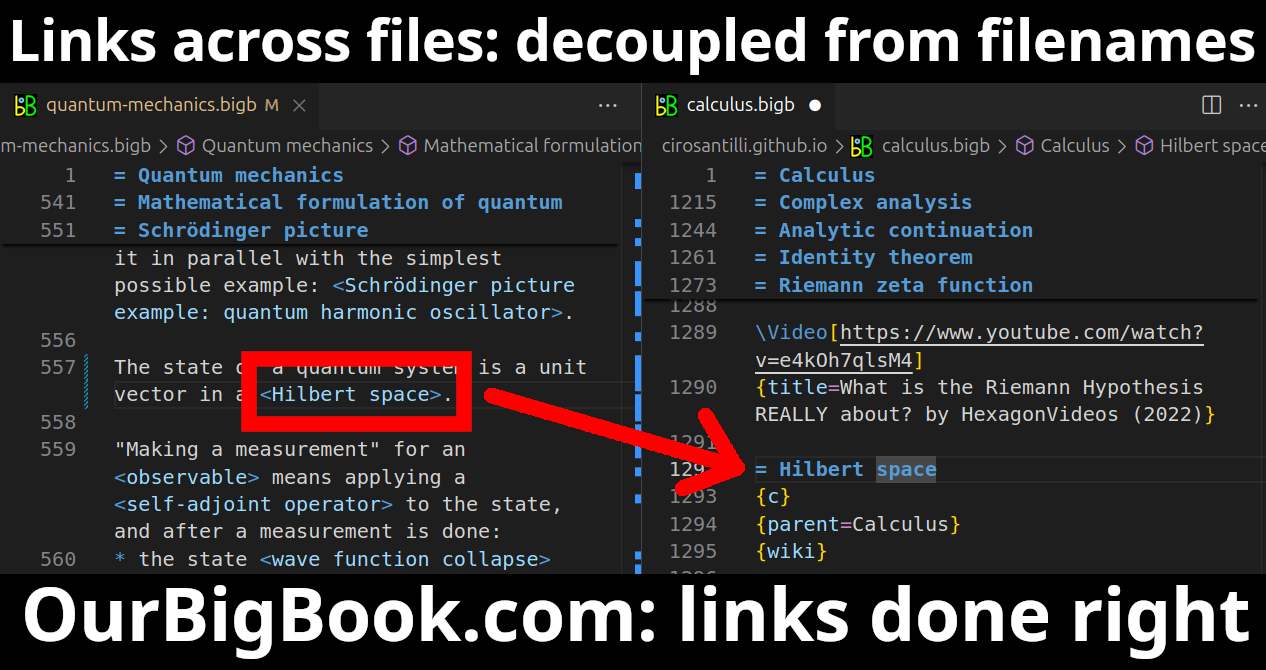
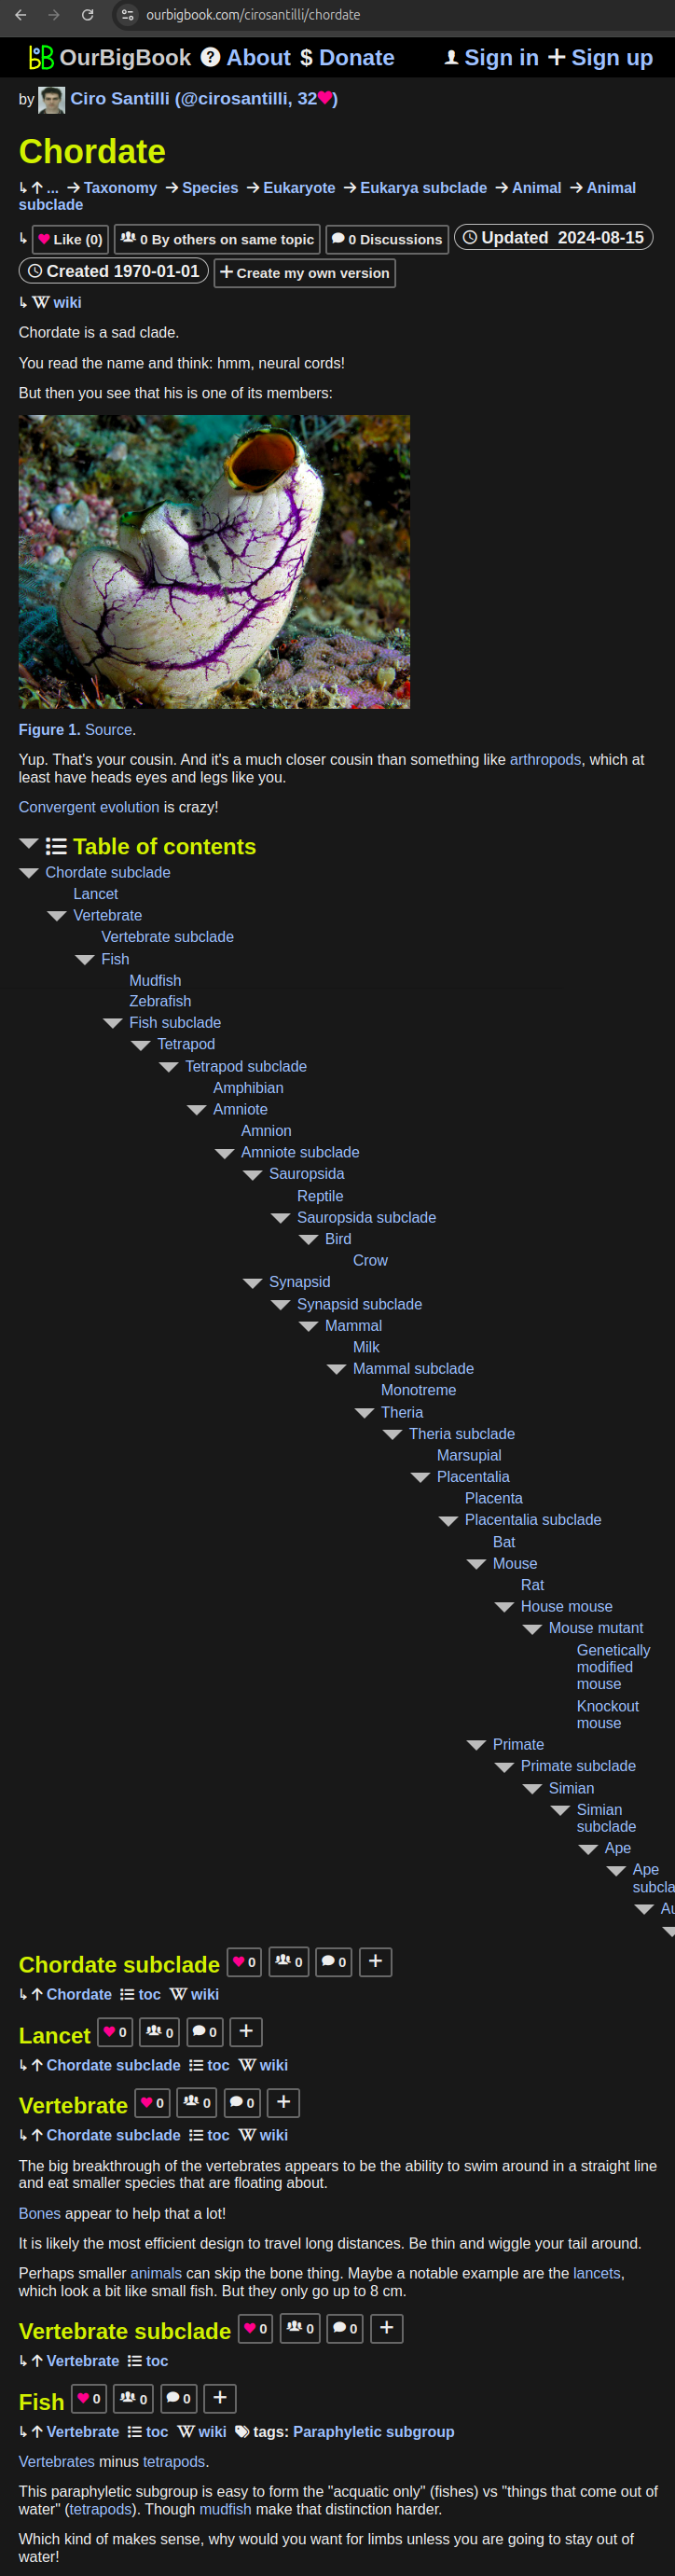
- Infinitely deep tables of contents:
All our software is open source and hosted at: github.com/ourbigbook/ourbigbook
Further documentation can be found at: docs.ourbigbook.com
Feel free to reach our to us for any help or suggestions: docs.ourbigbook.com/#contact