
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 8A b Solution Created 2026-09-24 Updated 2026-10-14
With the chain rule gives and . Substitution, initially for , givesThe transformed coefficients are and . At , both and are analytic; at , both and are analytic. Each point is singular because a normalized coefficient has a pole, but satisfies the regular singular point criterion for a second-order equation. Thus both points are regular singular points.
For a Frobenius method substitution , the lowest power gives the indicial equationThe repeated indicial root is zero. Setting and equating the coefficient of givesConsequently the analytic power-series solution of a differential equation isTaking reproduces the ellipse perimeter expansion.
For a second independent solution, normalize . Reduction of order and giveSince , this has the Logarithmic Frobenius solution formThe logarithm is on the real negative side, or a chosen complex logarithm on a slit complex neighborhood. Its nonzero logarithmic coefficient establishes independence. The physical perimeter is finite at , so it selects the analytic branch rather than this logarithmic one.
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 8A a Solution Created 2026-09-24 Updated 2026-10-14
Rewrite the integrand as . The binomial series, uniformly valid in for bounded below one, givesThe integrals of over a full period are respectively . Termwise integration therefore yields the ellipse perimeter expansion near a circle
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 7A c Solution Created 2026-09-24 Updated 2026-10-14
Both functions satisfy the constant-coefficient homogeneous linear differential equationIts characteristic polynomial is , so the general real solution is . The three initial conditions give , , and , henceHere the equation has continuous coefficients and nonzero highest-derivative coefficient everywhere. The uniqueness theorem for ordinary differential equations, applied to its three-component first-order system, gives a unique solution on the entire half-line.
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 7A b Solution Created 2026-09-24 Updated 2026-10-14
Direct calculation givesWhere , Abel identity gives , and substitution of either solution gives . ThusThese coefficients have singularities at odd multiples of . This does not contradict the Wronskian criterion: its continuous-coefficient interval hypothesis fails at those points.
On , the initial conditions uniquely select . The normalized differential equation is not defined on the whole interval , so the usual global uniqueness theorem for ordinary differential equations cannot give the global initial-value assertion as posed. No choice of finite coefficients at can repair the normalized equation while retaining both displayed solutions: at that point and its first derivative vanish, but its second derivative equals one.
The continuation through a zero of the leading ODE coefficient is a different problem: consider the multiplied, degenerate equationFor this different equation, a globally solution with the given initial data is uniquely . On each regular interval every solution is ; continuity of and at an odd multiple of forces both constants to agree across it. If only piecewise solutions away from the singular points are required, the may change and uniqueness fails. Thus the coefficient singularity and the intended solution regularity must be distinguished.
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 7A a Solution Created 2026-09-24 Updated 2026-10-14
The Wronskian isOn an interval where are continuous, the solutions are linearly independent exactly when at one point, equivalently when the Wronskian is nonzero throughout the interval. Differentiation and the homogeneous linear differential equation giveHence Abel identity reads . If , the two initial-data vectors are dependent; the uniqueness theorem for ordinary differential equations then makes the corresponding linear combination identically zero. This proves the converse as well as the necessity.
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 6A b iv Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 6A b iii Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 6A b ii Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 6A b i Created 2026-09-24 Updated 2026-09-24
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 6A a Solution Created 2026-09-24 Updated 2026-10-14
Work locally where the needed derivatives of the level set can be represented by the implicit function theorem. Differentiating while holding the indicated coordinate fixed givesMultiplying the three implicit differentiation formulas provesThis cyclic partial derivative identity is asserted where all three finite coordinate derivatives exist, in particular when . It is not a globally defined product at points where one of the necessary coordinate parametrizations is singular.
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 5A b Solution Created 2026-09-24 Updated 2026-10-14
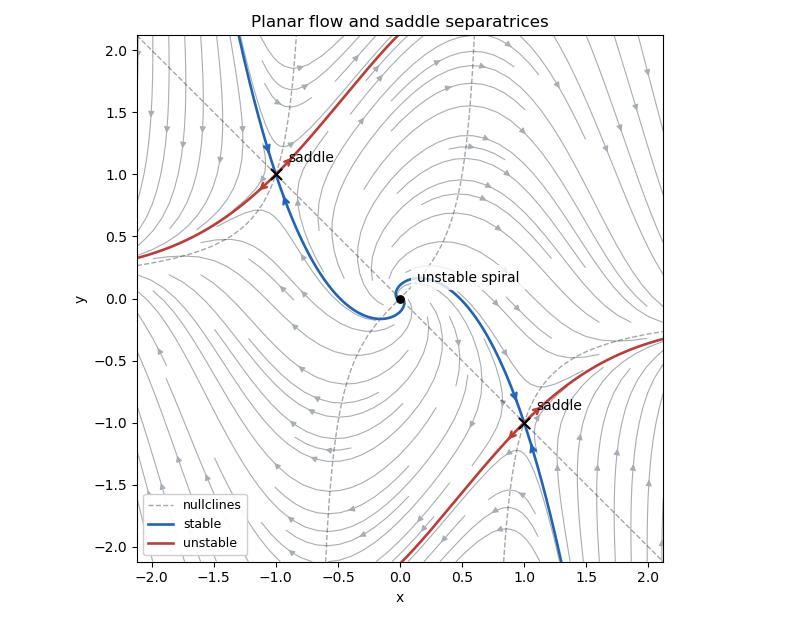
At a fixed point, the first equation gives . Substitution into the second gives , so the equilibrium points are . The Jacobian matrix isAt the origin its eigenvalues are , so the origin is an unstable spiral. The local rotation is clockwise: on the positive -axis the velocity points downward. At either nonzero equilibrium point,Thus both nonzero equilibria are saddles, with eigenvalues . The stable manifold is tangent to , and the unstable manifold to , at each saddle equilibrium. Since all these equilibrium points are hyperbolic, linear stability of a planar equilibrium gives their actual local types.
For the phase portrait, the nullclines are and , the latter defined away from . The horizontal direction has the sign of ; the vertical direction has the sign of . The system is invariant under , so trajectories occur in centrally symmetric pairs. The arrows below show these directions; the highlighted stable manifolds enter the saddle equilibria, whereas the highlighted unstable manifolds leave them.
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 5A a Solution Created 2026-09-24 Updated 2026-10-14
Combine the real variables into . The linear system of ordinary differential equations becomes , hence for arbitrary real . Taking real and imaginary parts givesThe two independent constants cover every real initial condition. In the phase plane, the distance from the origin grows as and the polar angle changes at rate . For the trajectories are outward logarithmic spirals; for they are outward straight rays.
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 3F c Solution Created 2026-09-24 Updated 2026-10-14
Construct independent copies of , also independent of , and define the random sum , taking the empty sum to be zero. Independence gives, conditional on ,The law of total expectation gives the transform composition for an independent random sumThe summands are nonnegative, so this equality is valid also as an extended-valued expectation. Where the right-hand side is finite, it is the ordinary moment-generating function of the constructed random sum. The construction does not assert a finite moment-generating function near zero for arbitrary : heavy tails can prevent this. For example a nonnegative with no positive exponential moments and already shows the necessary qualification.
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 3F b Solution Created 2026-09-24 Updated 2026-10-14
The moment-generating function is for real where this expectation is finite; a finite neighborhood of zero is usually required when speaking of an existing moment-generating function. For a standard normal distribution, completing the square givesThe translated Gaussian density integrates to one, so
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 3F a Solution Created 2026-09-24 Updated 2026-10-14
For a nonnegative integer-valued random variable, the probability generating function isinitially for , with . For the Poisson distribution, insert its probability mass function and sum the exponential series:Thus
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 2A b Solution Created 2026-09-24 Updated 2026-10-14
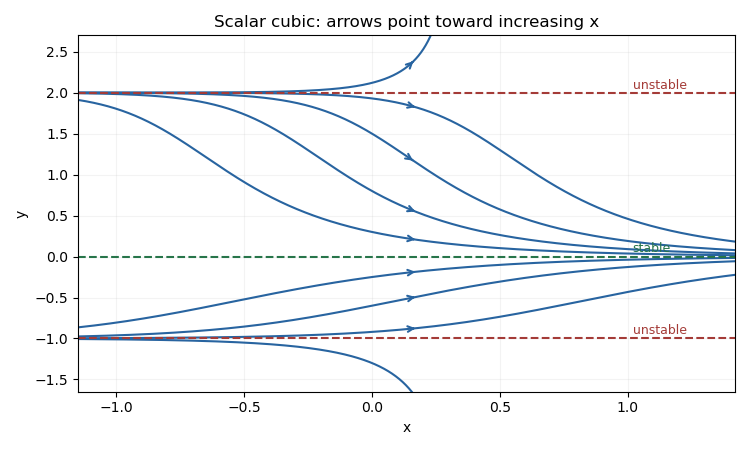
Factor the right-hand side as . Its equilibrium points are , and givesIndeed , and . The phase line has downward motion for , upward motion for , downward motion for , and upward motion for . The uniqueness of a smooth autonomous differential equation prevents trajectories from crossing an equilibrium point. Consequently trajectories starting between and approach zero as , while those outside that interval move away from the three equilibrium points. The constant trajectories and representative nonconstant trajectories are shown below.


Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 2A a Solution Created 2026-09-24 Updated 2026-10-14
An equilibrium of an autonomous differential equation is a constant with . Put . For differentiable , the linear stability analysis givesThus the linear perturbation is proportional to . More directly, continuity of makes point toward on both sides when , and away from it when . HenceThe sign refers to evolution toward increasing . If , linear stability analysis is inconclusive: the leading nonzero nonlinear term or the signs of on either side are needed. For example is attracting whereas is repelling, despite the same zero linear coefficient.
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 1A b Solution Created 2026-09-24 Updated 2026-10-14
Eliminate the free constant by comparing consecutive values:Therefore an appropriate inhomogeneous linear recurrence isIts homogeneous part has solution , and is a particular solution. A first-order linear recurrence relation has one arbitrary initial value, so this gives exactly the desired general solution.
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 1A a Solution Created 2026-09-24 Updated 2026-10-14
Substitution of into the linear recurrence relation gives . Since , division by proves the sequence is a solution exactly when .
For a nonzero triple root of a polynomial , the repeated characteristic root of a linear recurrence rule gives the three independent solutions . One way to see the polynomial factors is to write : the recurrence becomes the third forward difference operator applied to equal to zero, so is a quadratic polynomial. ThusThese three constants give arbitrary initial values , hence the full third-order solution. If , the recurrence instead reduces to : the first three values are arbitrary and every subsequent value is zero. The nonzero-root formula must not be used to discard those initial values.
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 12F b iii Created 2026-09-24 Updated 2026-09-24
There are unlisted articles, also show them or only show them.