
Convex polytope Created 2026-09-24 Updated 2026-10-14
A convex polytope is a bounded intersection of finitely many closed half-spaces, equivalently the convex hull of finitely many points.
Line segment Created 2026-09-24 Updated 2026-09-24
Closed half-space Created 2026-09-24 Updated 2026-10-14
This is the non-strict version of a half-space; replacing the inequality by a strict one gives the open version.
Convex combination Created 2026-09-24 Updated 2026-10-14
A convex combination is a finite weighted average of points in a real vector space. For , it has the formThe nonnegative coefficients forbid subtracting a component, and their unit sum keeps the result on the same affine scale as the inputs. With two points it parametrizes their line segment; equal coefficients give their centroid. A convex set contains every finite convex combination of its points. Conversely, the two-point case already gives the defining property of a convex set.[ref]
Convex Optimization by Stephen Boyd and Lieven Vandenberghe. §2.1.4, p. 24: finite combinations, weighted-average interpretation and convex hull
The distinction from a linear combination is concrete. Combining and with coefficients and gives , outside their line segment, despite the unit coefficient sum. Using two coefficients both equal to one gives here, but their sum is two, so it is not a convex combination with those coefficients. A numerical output may happen to coincide with a point admitting a different convex representation; the definition applies to the specified coefficients.
Nonnegative orthant Created 2026-09-24 Updated 2026-10-14
The nonnegative orthant consists of vectors whose coordinates are all nonnegative. Its interior is the positive orthant, where every coordinate is positive.
Projected gradient descent Created 2026-09-24 Updated 2026-10-14
This is the proximal gradient method when the nonsmooth term is the indicator of the feasible convex set, whose proximal operator is the metric projection.
Stiemke theorem Created 2026-09-24 Updated 2026-10-14
For a real matrix , exactly one of the following holds: there is with and , or there is with . Separating from the standard simplex proves the result; may then be normalized to sum to one.
Subdifferential Created 2026-09-24 Updated 2026-09-28
Swap test Created 2026-09-24 Updated 2026-10-14
Hadamard test Created 2026-09-24 Updated 2026-09-24
Controlled-NOT gate Created 2026-09-24 Updated 2026-10-06
Closure of a connected set Created 2026-09-24 Updated 2026-09-24
Product of connected spaces Created 2026-09-24 Updated 2026-10-03
The product of any family of connected spaces is connected. For two factors, fix and use the connected setsThey cover and all contain the connected horizontal slice .
Pairwise-intersecting connected cover Created 2026-09-24 Updated 2026-09-24
Integer-valued function criterion for connectedness Created 2026-09-24 Updated 2026-09-29
A topological space is connected exactly when every continuous map from it to the discrete space is constant. A disconnection produces a nonconstant indicator map, while the continuous image of a connected space in must be a singleton.
Continuous image of a connected space Created 2026-09-24 Updated 2026-10-14
If is a continuous map and is a connected space, then its image , with the subspace topology from , is a connected subset of . The whole codomain need not be connected; the assertion concerns the values actually attained. No injectivity is required.[ref]
For example, the continuous function maps the connected closed interval onto the connected closed interval , even though opposite inputs have the same output. The same continuous function maps the disconnected union onto . Thus a connected image does not imply a connected source: a continuous map can merge different connected components.
For a continuous function representing a continuous reading, and force some input with . Its image is a connected subset of the real line, hence a real interval containing both endpoint readings. For the synthetic model , the missing-value test is explicit: . A step reading equal to for and for skips , but fails continuity at .
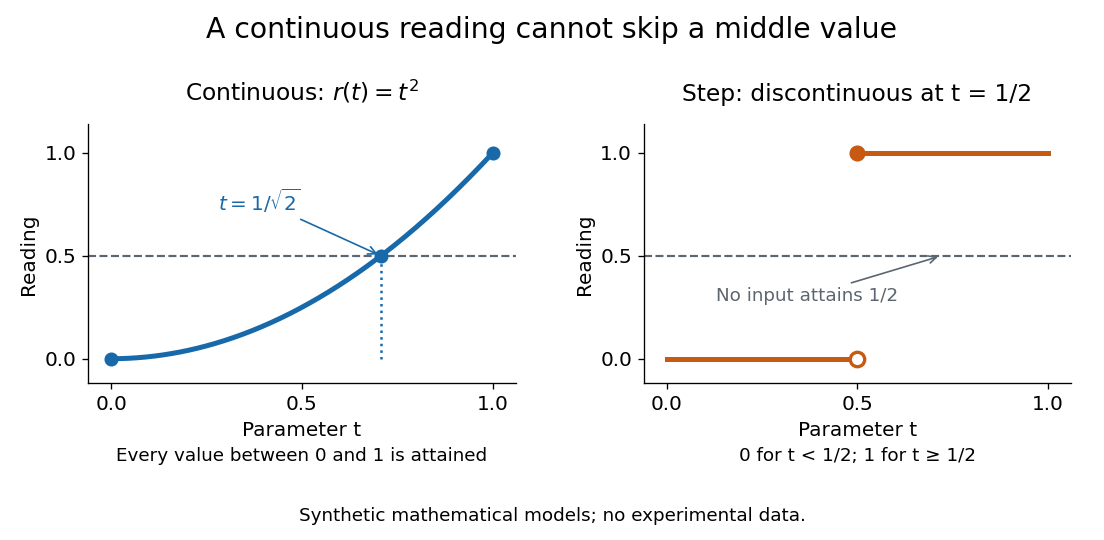

Proof outline: a separation of a topological space of into nonempty open subsets pulls back under to nonempty open subsets of . Their intersection is empty and their union is , contradicting connectedness. This also shows why a continuous map sends each connected component of its source into a single connected component of its target.
Connected component Created 2026-09-24 Updated 2026-10-14
A connected component of a topological space is a nonempty connected subset that is maximal under subset inclusion. If is a connected component and with a connected subset, then . Maximality means that no larger connected subset contains ; it does not mean largest cardinality among all connected subsets.
For example, the connected components of in the usual subspace topology of the real line are and . Each is a real interval, and no connected subset of the real line can meet both without containing the missing point . For the finite set in the same subspace topology, the three connected components are its singleton sets.
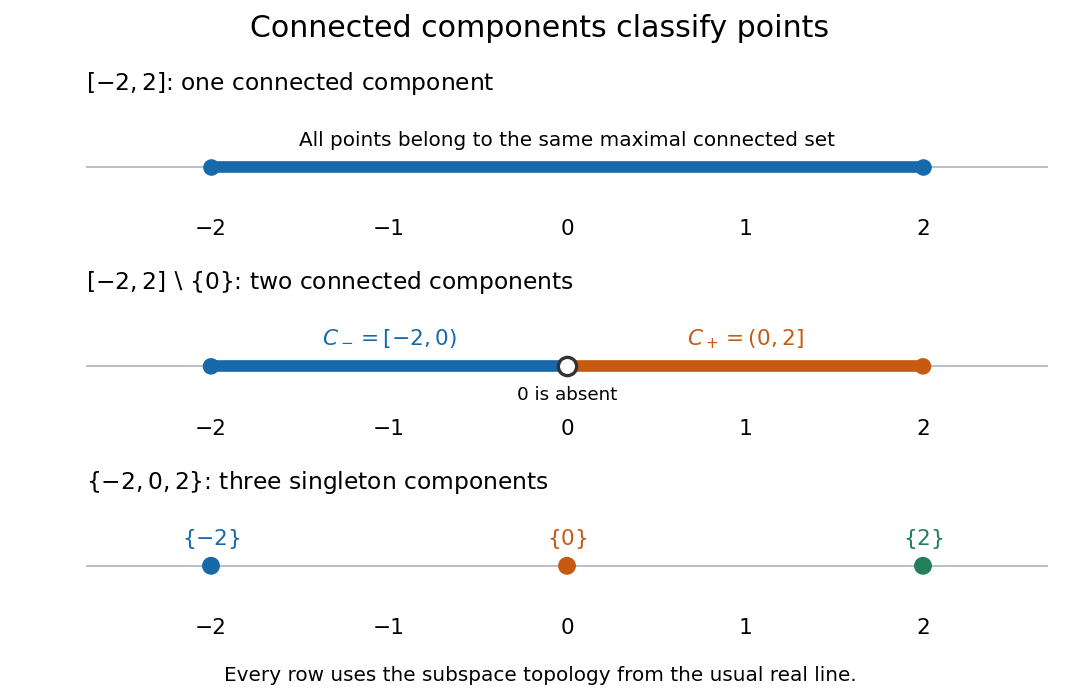
An intact real interval, an interval with an interior point removed, and a finite set have one, two, and three connected components in the usual subspace topology of the real line
. Details. 
Every point lies in exactly one connected component, constructed by taking the unionAll members contain , so their union is connected by connected union with a connected hub. The union includes every connected subset through , so it is maximal. Equivalently, defineThis is an equivalence relation: singleton sets give reflexivity, symmetry is immediate, and two connected subsets sharing the middle point have a connected union, giving transitivity. The equivalence classes are precisely the connected components. They form a partition of a set: they cover and any two are either equal or disjoint.[ref]
Chapter 3: Connected and compact spaces. Proposition 3.1.11, Definition 3.1.12 and Remark 3.1.16: maximal connected subsets and equivalence classes
Every nonempty connected subset lies within one connected component. Moreover, every connected component is closed in : closure of a connected set makes its closure connected, and maximality forces that closure to equal the original connected component. A connected component need not be open. For example, in with its usual subspace topology from the real line, all connected components are singleton sets, but is not open: every neighbourhood of in contains some .[ref]
Hyperbolic-cosine half-strip map Created 2026-09-24 Updated 2026-09-24
Holomorphic inverse function theorem Created 2026-09-24 Updated 2026-10-03
If a holomorphic function satisfies , then it has a holomorphic local inverse near and is conformal there. Its possible failures of local conformality are therefore its critical points.
Conformal equivalence Created 2026-09-24 Updated 2026-10-05
Two plane domains are conformally equivalent when there is a bijective holomorphic map between them whose inverse is holomorphic.
There are unlisted articles, also show them or only show them.