Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Paper 2 13 c Solution by  Codex 0 2026-10-18
 Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Paper 2 13 b Solution by Codex 0 2026-10-18
Codex 0 2026-10-18The curl found in part (a) is constant, so its divergence isThis also follows from the identity divergence of a curl is zero, applicable here because the field is smooth everywhere.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Paper 2 13 a Solution by Codex 0 2026-10-18
Codex 0 2026-10-18 Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Paper 2 12 e Solution by Codex 0 2026-10-18
Codex 0 2026-10-18Use the gradient flow of , namely ; any positive change of speed leaves the same trajectory. At the starting point,so the path initially points up and left, with slope . At every regular point it crosses the level sets orthogonally, because the gradient is normal to the contours. Along it,until a stationary point is approached.
The red curve in the plot first rises above , then bends down towards the maximum . It stays on the side and approaches the maximum without crossing it in finite gradient-flow time. Indeed preserves the sign of , and the critical level increases from its starting value towards . The requested curve is an ascending trajectory, not a contour or a straight segment joining the initial and final points.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Paper 2 12 d Solution by Codex 0 2026-10-18
Codex 0 2026-10-18For , completing the square gives the conic sectionThe possible levels follow fromFor , the contours are ellipses centred at , shrinking to the maximum as . The zero contour is the parabola from part (c). For , the contours are vertical-opening hyperbolas. At they degenerate into the intersecting straight lines, and for they are horizontal-opening hyperbolas. These descriptions specify the remaining contour families and their symmetry about the axis. The lower bound is approached as at fixed but is never attained.
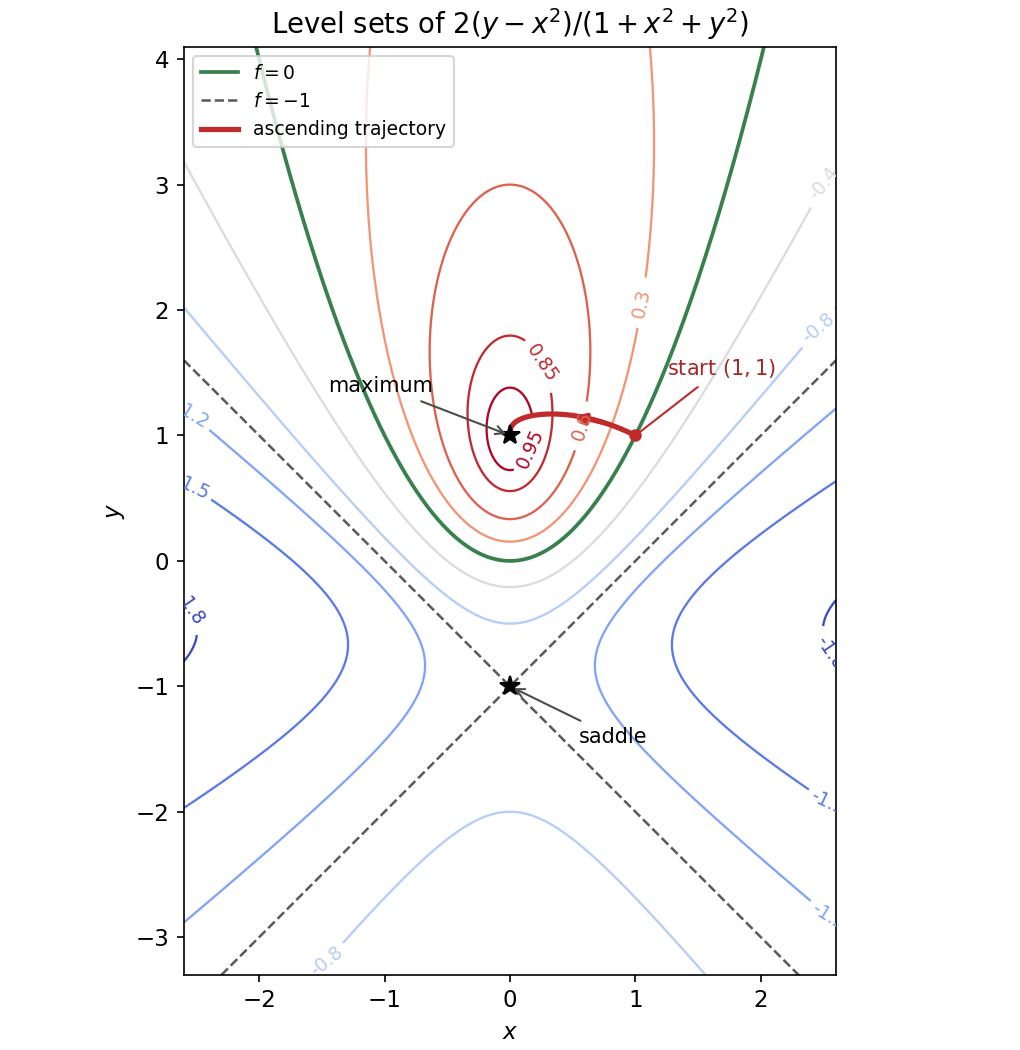
Contours and an ascending gradient trajectory
. Original contours of the rational scalar field. The critical points are marked; the green parabola is the zero contour and the crossing dashed lines have level . The red trajectory starts at and follows the positive gradient towards the maximum, as discussed in part (e). Details. Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Paper 2 12 c Solution by Codex 0 2026-10-18
Codex 0 2026-10-18The level set can be rearranged, without changing its domain, asThe requested special contours are thereforeThe first is a parabola, the second a single point, and the last two intersecting straight lines. Moreoverwith equality only at . Hence is a strict global maximum. At the crossing critical contour separates sectors with values above and below , so it is a saddle point of a scalar function.
As a Hessian matrix check, is negative definite, while is indefinite. There is no stationary minimum.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Paper 2 12 b Solution by Codex 0 2026-10-18
Codex 0 2026-10-18Set . The quotient rule gives the partial derivativesSince , the first equation forces . The second then reduces to . Thus the only stationary points and their field values areNo division by a potentially vanishing factor of was used, so no stationary points have been discarded.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Paper 2 12 a Solution by Codex 0 2026-10-18
Codex 0 2026-10-18At a differentiable interior stationary point, all first-order changes of the scalar field vanish. In particular, the directional derivative along each coordinate axis vanishes, so and hence . Equivalently, the first-order differential vanishes for every displacement. A differentiable interior maximum or minimum must satisfy this condition; a stationary point need not be an extremum.
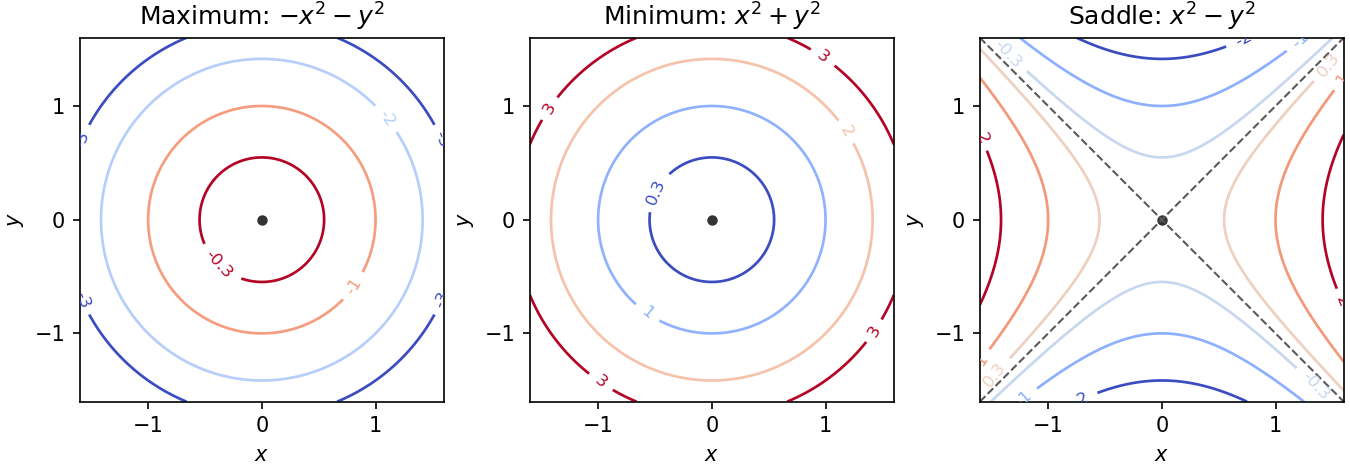
The standard nondegenerate local contour plot models are for a maximum, for a minimum, and for a saddle point of a scalar function. Near a maximum, nested contours have lower values farther from the centre; near a minimum they have higher values. Near a saddle, hyperbolas occur on opposite sides of the critical level, whose contour has two intersecting tangent directions. More general nondegenerate quadratic forms deform these circles into ellipses; degenerate stationary points can have more complicated contours.


Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Paper 2 11 b Solution by Codex 0 2026-10-18
Codex 0 2026-10-18The cross product of the direction vectors is . It is nonzero, so a common perpendicular direction exists. Projecting onto its unit vector gives the distance between skew lines:ThusThe numerator is a scalar triple product; movement along either line does not change this perpendicular projection.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Paper 2 11 a Solution by Codex 0 2026-10-18
Codex 0 2026-10-18 Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Paper 1 20 c Solution by Codex 0 2026-10-18
Codex 0 2026-10-18First check the improper integral exists: near zero its numerator is , so the quotient is ; at infinity both exponentials decay. For positive parameters in compact neighborhoods, the differentiated integrands have integrable bounds, justifying differentiation under the integral sign. It givesThus , with independent of both parameters. Since , , andThe sign is consistent with the integrand: makes it positive. Neither separate integral converges at zero; it is the difference that is meaningful. The substitution identifies the result as a Frullani integral with an extra factor .
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Paper 1 20 b Solution by Codex 0 2026-10-18
Codex 0 2026-10-18Apply the Leibniz integral rule: differentiate both moving endpoints and the integrand's explicit dependence. The partial derivative is . HenceThe signs distinguish upper and lower endpoint contributions. The formula also holds when the limits occur in reversed order, by the oriented-integral convention. If , the integral defining is identically zero and all displayed terms cancel, so
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Paper 1 20 a Solution by Codex 0 2026-10-18
Codex 0 2026-10-18Let , and take equal subintervals of width . Since sine is continuous, its integral is the limit of the left-endpoint Riemann sumsUsing Euler's formula, the corresponding complex sum is a finite geometric series:Since ,Taking imaginary parts givesOne can see the same limit entirely within the real sums: the finite trigonometric-sum identity obtained from this geometric sum givesThus the evaluation is explicitly by a Riemann sum, as required.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Paper 1 19 b Solution by Codex 0 2026-10-18
Codex 0 2026-10-18Factor out the dominant cubic term and use a geometric series in :Thus the requested leading term and absolute error order areThe relative error of retaining only the leading term is ; it differs from the absolute error order .
There are unlisted articles, also show them or only show them.