Source release: Oxford examination archive. The cover dates this examination to 9 June 2011, 9.30–11.00am. All 12 answer parts are solved below. The two numbered conditions inside 3(c) are hypotheses of its single optimality proof.
Use vertices . Reading each symmetric off-diagonal pair once gives the edge setHere abbreviates the undirected edge . The diagram displays these seven edges and no loops. The displayed square matrix is an adjacency matrix in the usual terminology: its two indices both label vertices. A vertex-edge incidence matrix would instead have one index for vertices and one for edges. This explains how the source's node-node terminology is being read.
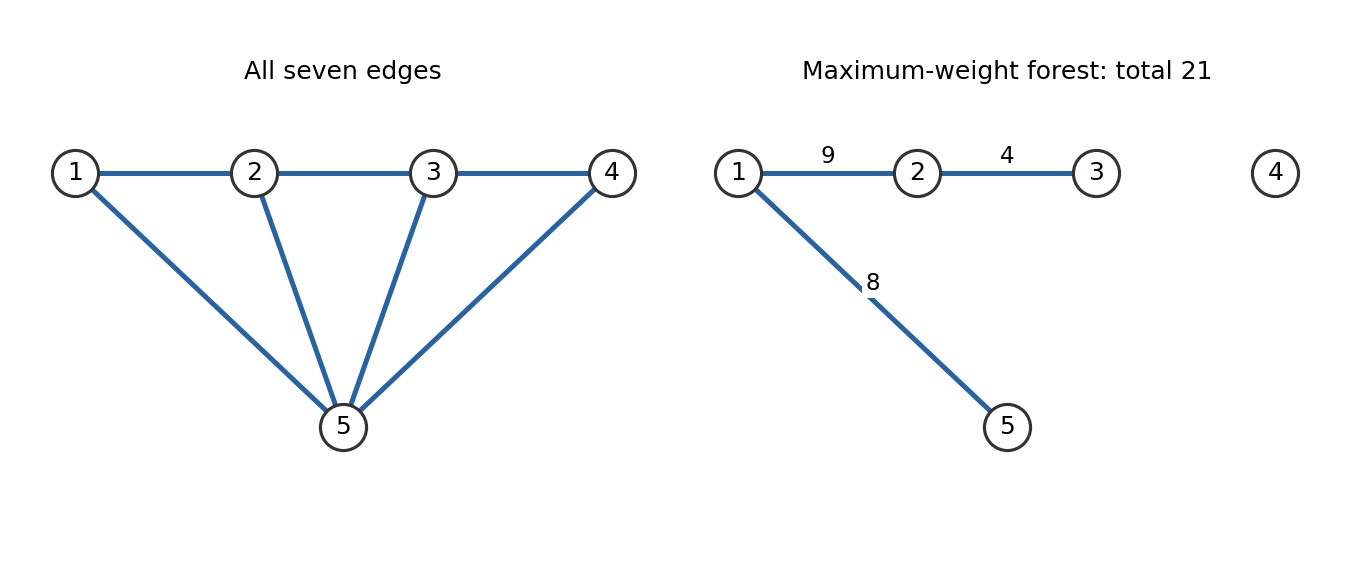
Use the maximum-weight version of Kruskal's algorithm: sort the edges by decreasing weight, start with no edges, and add an edge exactly when it joins different current connected components of a graph. For the maximum over all forests, skip negative-weight edges; removing a negative edge always preserves a forest and increases its weight. Zero-weight edges are optional. The matroid greedy algorithm for the graphic matroid proves this procedure optimal; it maximizes over independent sets rather than requiring a full basis.
The positive edges are considered in the orderAdmit and . Reject , since it closes the triangle on . Admit . Reject , since and are already joined by the path . Skip both negative edges incident with vertex four. ThereforeVertex four is isolated. Requiring a spanning tree would force a negative edge and solve a different optimization problem. With a disjoint-set data structure, sorting dominates the running time, giving .
On a finite ground set , a submodular rank function is a set function with the following properties:These are normalization, monotonicity, submodularity, and unit integer increments. In particular its values are nonnegative integers with . Equivalently, one can require an integer-valued normalized monotone submodular function with : diminishing returns then bounds every marginal increment by one. A general real-valued submodular function need not be a matroid rank.
The associated matroid isThus the graph's edges are the ground set, and the members of are its matroid independent sets.
For the specified rank, if is a forest, itself is an allowed choice in the rank maximum, so . Conversely, if , some forest has . Finiteness forces , so is a forest. Hence the independent sets are exactly all forests in , including the empty forest and forests with isolated vertices.
The matroid independence axioms can also be checked directly. The empty set is a forest, and deleting edges cannot create a cycle. For exchange, let forests have . If every edge of joined vertices within one component of , its restriction to each component would have at most edges. Summing would give , a contradiction. Thus some edge of joins two components of and can be added without creating a cycle. This proves augmentation and identifies as the graphic matroid.
For , write , and let count the connected components of , including isolated vertices. A maximal forest in each component has one fewer edge than vertices, so . The required forest polytope isWe prove both inclusions, using the matroid independence polytope argument explicitly.
If is a forest, is an independent subset of , so . Its indicator is nonnegative. All convex combinations of these indicators therefore lie in .
For the converse, take any real objective vector . List just its positive-weight edges as with , put , and set . Run the forest greedy algorithm on these edges and call the output . At every prefix, the accepted edges form a maximal forest of , soIndeed a previously rejected edge still has its endpoints joined later; therefore no rejected prefix edge can augment the chosen forest. A maximal forest spans every prefix component and has the stated size.
For every , dropping nonpositive objective terms and telescoping now givesThe last equality uses the same telescoping identity for the greedy indicator. If there are no positive coefficients, the empty forest attains the bound zero. Thus every linear objective over is maximized by a forest indicator.
The singleton inequalities give , so is compact. The convex hull of the finitely many forest indicators is also compact. If some were outside , the finite-dimensional separating hyperplane theorem would give with , contradicting the bound just proved. Therefore , completing the convex-hull proof.
An equivalent system indexed by vertex sets iswhere contains all edges with both ends in . The rank system implies this since . Conversely, split any edge set into its vertex components . Nonnegativity and the vertex inequalities give . Hence this second system describes the same polytope.
Let item have weight and profit . Define as the largest profit obtainable from the first items with capacity at most the nonnegative integer . Set . The last item is either absent or present once, giving the dynamic programming recursionThe two alternatives exhaust the feasible binary decisions. In the second alternative, deleting item leaves exactly the smaller subproblem with capacity , which proves the recurrence.
Fill rows , and within each row capacities . Store which alternative attains each maximum. Backtrack from : when exclusion was chosen, set and move to ; when inclusion was chosen, set and move to . Ties may be resolved either way. Thus the stored values yield an actual optimal selection, not just its objective value.
For items and capacity , the algorithm uses arithmetic operations and space with the full backtracking table. It is a pseudo-polynomial algorithm, since is a numerical capacity rather than its bit length. A value-only version can use one row, but must update capacities in decreasing order to avoid reusing the same item.
Applying the recurrence in source item order gives the complete tableAt inclusion wins, since . Thus and the residual capacity is two. Items three and two are too heavy for it, and item one exactly fits. ConsequentlyIts weight is . The recurrence proves that no binary selection with capacity seven has greater profit.
For each branch and bound node, relax the unfixed binary variables to . The fractional knapsack problem is solved by decreasing profit-to-weight ratios, hereIts value is an upper bound for the node's integer optimum. At the root, greedy filling gives and upper bound , so branch on .
In the child , the relaxed optimum is with value . Branch on . Taking leaves capacity two, giving the integral solution of value , our incumbent. Taking gives the integral relaxed optimum of value , so that node is closed.
In the child , item four cannot be selected in any integer feasible solution, since their combined weight is nine. Fixing is therefore valid binary feasibility propagation. Its LP optimum is with value . Branch on . The child leaves no residual capacity and has integral solution of value . The child has integral solution of value . Both are below the incumbent.
The complete short search isAll integer feasible solutions lie in these branches, and every terminal node is integral with value at most forty. Therefore the LP bounds and incumbent certify independently of the dynamic program.
The assignment constraint matrix has one row for each outgoing sum and one for each incoming sum. The column for has a one in outgoing row and incoming row . Negate all incoming rows. Each column now has exactly one and one , the node-arc incidence matrix of the directed bipartite graph from row vertices to column vertices.
Here is a direct proof that this signed matrix is totally unimodular. Consider any square submatrix and induct on its size. If a column has no nonzero entry, its determinant is zero. If a column has one nonzero entry, expansion along it reduces the determinant to plus or minus a smaller subdeterminant, hence to or . If every column has two nonzero entries, they have opposite signs, so each column sum is zero. The rows are then dependent and the determinant is zero. The size-one case is immediate, completing the induction.
Negating rows only changes signs of square subdeterminants. Thus the original assignment matrix is also a totally unimodular matrix. This proves the total unimodularity of directed incidence matrices argument directly in the required setting.
The integrality theorem for totally unimodular systems says that has integral vertices when is totally unimodular and is integral. Redundant equalities cause no problem. Here the row sums also force , so every integral feasible vertex is a binary assignment. The bounded nonempty LP relaxation has an optimal vertex, and therefore an optimal assignment. Hence the assignment problem can be solved by linear programming without a binary search; dedicated methods such as the Hungarian algorithm also exploit its polynomial-time structure. Multiple optimal assignments can have fractional convex combinations, so the conclusion concerns an optimal integral vertex, not every optimal LP point.
For any feasible assignment, the unit row and column sums giveThus the transformed objective differs by the fixed constantEvery feasible assignment shifts by that same amount, so all objective comparisons and all optimal assignments remain unchanged. The calculation also holds for fractional feasible points of the assignment LP relaxation. The numbers are assignment dual potentials.
Since every reduced weight is nonpositive and every feasible variable is nonnegative, any feasible assignment satisfiesFor , each selected entry has zero reduced weight, and each unselected entry has zero variable. Thus every product vanishes and equality holds:The two hypotheses therefore form one optimality certificate: the first provides a universal upper bound, and the second makes the proposed assignment attain it. This is weak duality plus complementary slackness for the maximization assignment problem. For a minimization assignment, the sign reverses: gives a lower bound, with equality on the selected arcs certifying optimality.
Use the minimization form in this part. Treat every diagonal arc as forbidden, not as a zero-cost loop. The assignment relaxation of the travelling salesman problem requires one incoming and one outgoing arc at each city but permits several disjoint directed cycles. Its optimum is a lower bound on the tour optimum.
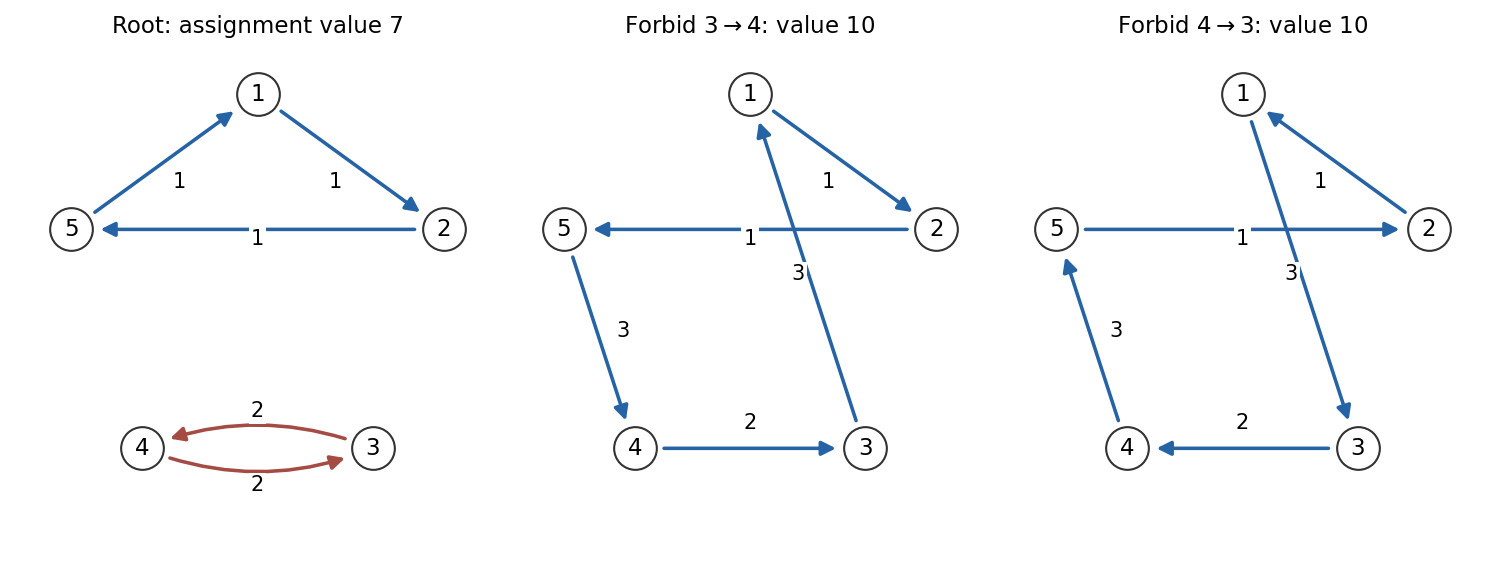
At the root chooseFor every allowed arc, . Their total is seven. The assignmentuses only tight arcs and has cost . The minimization certificate from part (c) therefore provesIt is not a tour, because it has a three-cycle and a two-cycle.
Branch on the two-cycle. Every five-city tour omits at least one of and , so the children and cover every possible tour. They may overlap, which does not invalidate the bounds.
For the child , useThese satisfy on every allowed arc of that child and sum to ten. The tourhas cost and uses tight arcs, certifying that the child assignment bound is exactly ten.
For the child , interchange the roles of cities three and four in those potentials. Its lower bound is again ten, attained bywith cost . Thus both first-level assignment optima are already tours.
There is a useful direct interpretation of the improved bound. Split the cities into and . A forbidden arc of the two-cycle forces an assignment arc from to , and balance forces at least one from to . Relative to the root potentials, each crossing arc has reduced cost , so any child assignment costs at least .
The first branching therefore completes the search: each child's lower bound equals a feasible tour value. Hence


Articles by others on the same topic
There are currently no matching articles.