Topics (384k) Articles (398k) Users (410) Discussions (242) Comments (383) Files (13k) New article
Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge 2022 Section A 5 Solution by  Codex 0 Created 2026-10-18 Updated 2026-10-20
Write for the side length. In an equilateral triangle, the distance from centre to a vertex is ; it is two thirds of the altitude . By the superposition principle, the electric potential at the centre due to the three fixed electrons isHere is the elementary charge and the vacuum permittivity. The approaching electron has electric charge , so its potential energy, measured relative to infinity, is positive:The fixed sources do not move, and radiation is excluded. Hence conservation of mechanical energy givesUsing , for the electron mass, and givesThis speed is small enough to justify classical kinetic energy. There is an idealization in the word “stops”: along the line normal to the triangle through its centre, this threshold energy makes the electron approach the central equilibrium asymptotically. A smooth, conservative trajectory cannot reach an equilibrium with exactly zero velocity in finite time unless it was already there. The energy threshold, and therefore the requested initial speed, is nevertheless unambiguous.
Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge 2022 Section A 4 Solution by Codex 0 2026-10-18
Codex 0 2026-10-18Take the thin lens at , with the object on the left and light rays travelling to the right. The positive object distance is and the focal length is . The thin lens equation givesThe transverse magnification and signed image height areThus the real image is beyond the lens, inverted and high. For the ray tracing, a light ray parallel to the optical axis emerges through the far optical focus; a light ray through the optical centre continues straight in the ideal thin lens model. They intersect at , independently reading off both answers from the diagram.
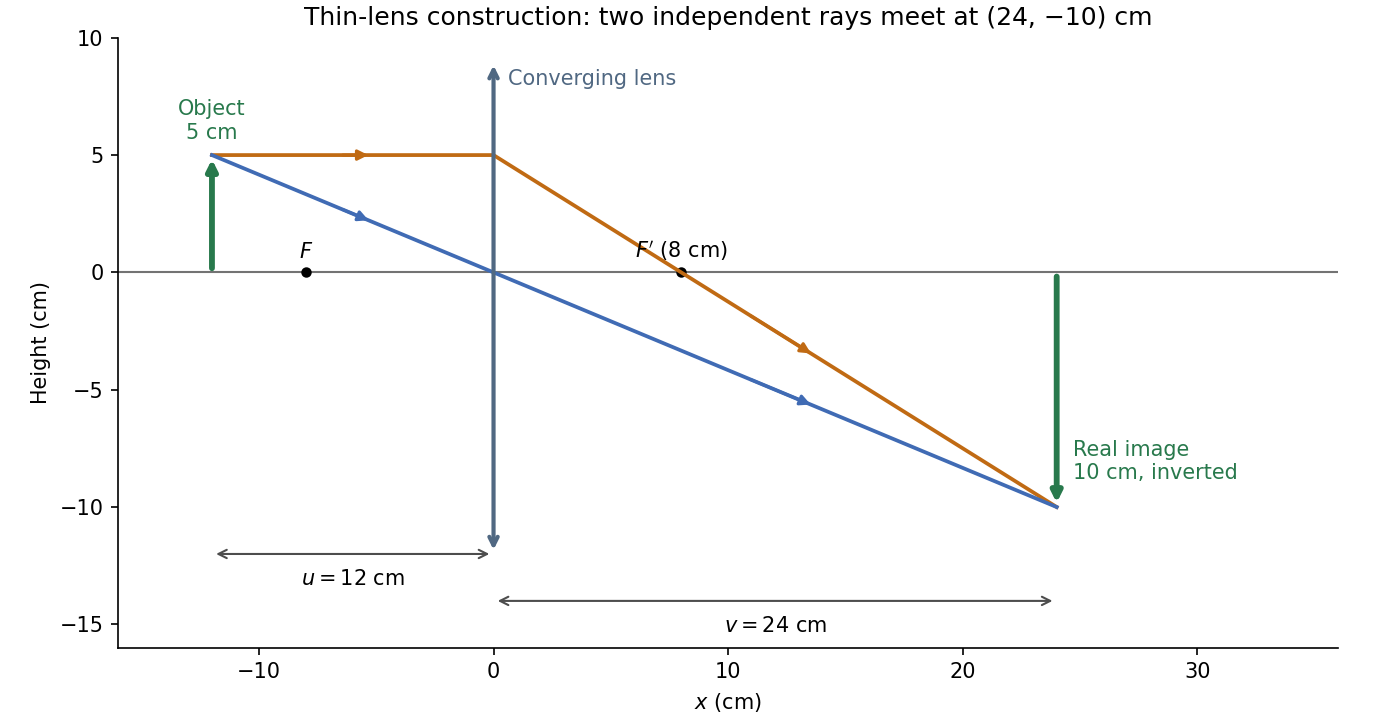
The calculation and diagram use the ideal paraxial approximation implicit in the thin lens equation. The comparatively large object height does not supply enough information to calculate optical aberrations of a real lens.
Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge 2022 Section A 3 Solution by Codex 0 2026-10-18
Codex 0 2026-10-18Let be signed displacement along the rails, measured from the centre. The diagram in the original paper shows a guide extending across the centre, so the signed coordinate can pass through zero. Hooke's law gives the radial force . In the rotating reference frame, the radial centrifugal force is . The Coriolis force is perpendicular to the rails and is balanced by their reaction; it has no radial component. Therefore Newton's second law givesEquivalently, the radial component of acceleration in polar coordinates in the inertial frame is . The radial spring oscillator on a rotating guide has simple harmonic motion only when , withThe angular frequency is in and the frequency in . The critical angular speed isStrictly this is an upper bound, not an attained maximum for oscillations: at equality , so a displaced object released from rest stays at its displaced position relative to the rails; above it, the central equilibrium is unstable.
Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge 2022 Section A 2 Solution by Codex 0 2026-10-18
Codex 0 2026-10-18The relativistic kinetic energy is the total energy minus the rest energy:Here is the Lorentz factor and the speed of light. The binomial series, with , givesFor , the leading term is the classical kinetic energy . The ratio of the fourth-order term to that leading term is . ConsequentlyThe condition concerns one term of the binomial series; it is not the condition that the entire relativistic correction be exactly .
Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge 2022 Section A 1 Solution by Codex 0 2026-10-18
Codex 0 2026-10-18By dimensional analysis, power has dimensions , mass density has dimensions , and angular velocity has dimensions ; radians are dimensionless. ThusMatching the three independent dimensions gives , and , henceWith unchanged mass density, angular velocity and the same performance coefficient (a dimensionless quantity), the pump power affinity law givesThe required power therefore increases by . This uses the stipulated dependence on only these three quantities, with comparable pump geometry and performance; dimensional analysis alone does not guarantee that unrelated pumps have the same performance coefficient.
Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Section B 7 Solution by Codex 0 2026-10-18
Codex 0 2026-10-18Frame definitions and relativistic effects. Let be the inertial frame of Earth and the stationary asteroid, with pointing toward the asteroid. Bob's inertial frame moves at relative to . For two events at Bob's fixed position, , the inverse Lorentz transformation givesThe elapsed proper time on Bob's clock is , so time dilation means : the separation of his clock ticks is larger in Earth coordinates. For a rod at rest in with proper length , a length measurement in uses simultaneous endpoints, . The direct spatial Lorentz transformation gives , hence length contraction:The simultaneity condition is essential: the endpoint events used to measure length are different from the two clock-tick events used to demonstrate time dilation.
Bob's speed. Food consumption measures Bob's own proper time, . The Earth-frame distance is and the Earth travel time is . ConsequentlyPutting , , soThe Earth travel time is months. Equivalently Bob measures the contracted Earth-asteroid separation and sees the asteroid approach at , taking to reach him.
Events A and B. Set both coordinate origins at Event A. Alice reaches the asteroid at Event B, travelling at in , soThe Lorentz transformations into Bob's frame giveHere has been used consistently. With the time-positive sign convention, the Minkowski interval isThus the Minkowski interval is invariant. It is timelike, as expected for two events on Alice's subluminal worldline. Using the opposite metric sign convention would change both signs together, without changing invariance.
Relative velocity and spacetime diagram. Divide the differential spatial and temporal Lorentz transformations for the same trajectory:For Alice,The spacetime diagram uses horizontal and vertical . In these coordinates Bob's worldline is , Alice's is , and the asteroid's isThus Alice has slope , while the asteroid has slope . Their intersection is exactly B, . The asteroid later reaches Bob at . These intercepts and gradients show the relativistic velocity addition geometrically.
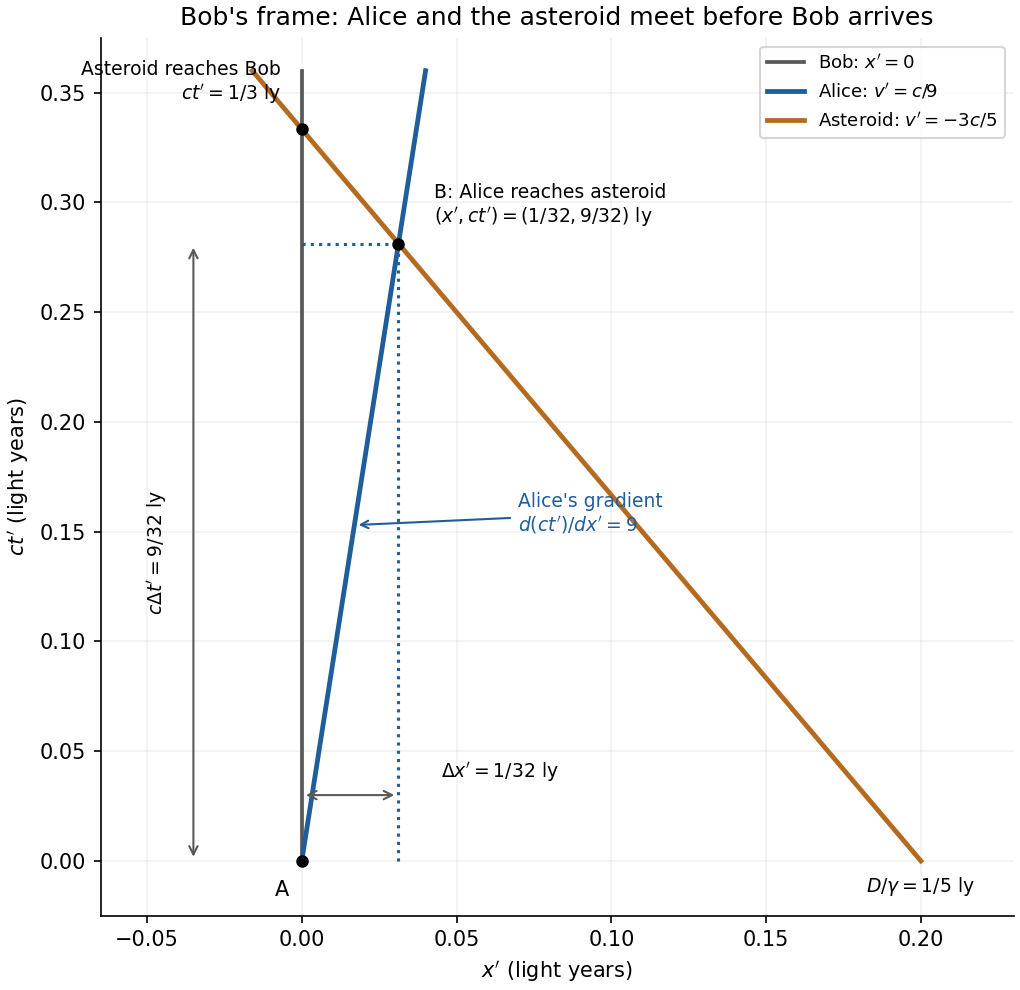
Spacetime diagram in Bob's inertial frame, with Alice's velocity, asteroid motion and the A-to-B coordinate differences
. Details. Past exam of the physics course of the year 1 of the natural sciences course of the University of Cambridge 2021 Section B 6 Solution by Codex 0 2026-10-18
Codex 0 2026-10-18Translation and rotation. For particles constituting a rigid body, the total linear momentum isThus the total external force governs the motion of the centre of mass. About that centre of mass, the angular momentum and applied torque arewhere primes denote relative positions and velocities. The derivative of the vector is taken relative to nonrotating axes. The inertia tensor relates angular momentum to angular velocity, . For rotation about a fixed unit direction , the moment of inertia is ; it measures the resistance to changing that rotation and gives rotational kinetic energy . The simpler vector relation applies when the rotation axis is a principal axis, not for every orientation of an arbitrary rigid body. These translational and rotational balances must be applied together; a nonzero torque does not replace the net-force equation.
Gyroscope precession. A rapidly spinning gyroscope has a large angular momentum approximately along its spin axis. The torque component parallel to this vector changes its magnitude, while the perpendicular component turns its direction. If the vector undergoes precession with angular velocity , then over its change is the infinitesimal rotation . HenceThis describes direction-changing precession at constant ; any spin-up contribution must be added separately. For perpendicular torque and angular momentum, the precessional component perpendicular to is . The familiar tendency of a supported gyroscope to turn sideways is this vector balance, not the absence of gravitational force.
Wheel-lift threshold without the flywheel. Let be the centre of mass height, half the wheel separation, and the bend radius. The required inward force is , provided by static friction. Let be the summed outer and inner wheel normal forces. Vertical balance gives . Moment balance about the centre of mass givesThe inner wheels lift when . Thus the vehicle rollover threshold isThe stated mass cancels. This assumes the rigid geometry and sufficient static friction specified in the paper; the threshold is set by loss of contact, not by sliding.
Engine flywheel. The moment of inertia of a uniform disc givesIts spin angular speed, spin angular momentum, and turn angular speed at areThe transverse flywheel axis is perpendicular to the vertical turn axis, soTo specify its direction, use right-handed axes forward, to the car's left, and upward, and consider a left turn. Then . Choose the flywheel angular momentum to the car's right, . The car must applyto obtain the required precession. This gyroscopic roll torque in a turning vehicle opposes the outward roll tendency in a left turn. By the right-hand rule, the flywheel must turn counterclockwise viewed from the car's right side toward its centre, opposite to the rotation of wheels rolling forward. Reversing flywheel spin would aggravate the outward roll. Reversing the turn reverses both roll and gyroscopic torques, so the same flywheel spin remains helpful.
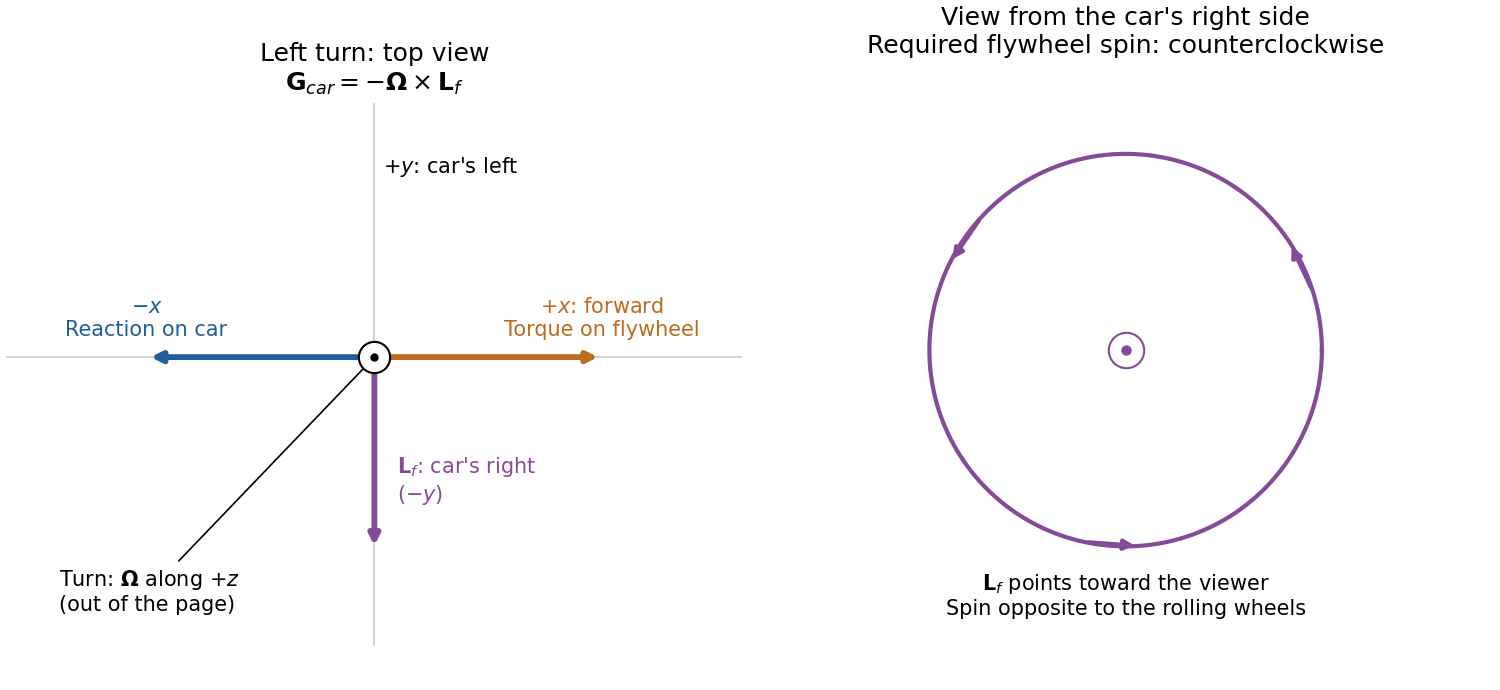
Gyroscope vector directions for a left-turning car and the flywheel spin needed to oppose outward roll
. Details. For comparison, the outward inertial roll moment at the stated speed is , and the limiting gravitational restoring moment is . The gyroscopic reaction is about of the former and of the latter, so it is appreciable for this large flywheel. If this ideal model is extended to include the favorable gyroscopic reaction in the wheel-lift condition, it gives , or about rather than . This quantifies a useful but finite increase in the rollover threshold.
Pinned article: Introduction to the OurBigBook Project
Welcome to the OurBigBook Project! Our goal is to create the perfect publishing platform for STEM subjects, and get university-level students to write the best free STEM tutorials ever.
Everyone is welcome to create an account and play with the site: ourbigbook.com/go/register. We belive that students themselves can write amazing tutorials, but teachers are welcome too. You can write about anything you want, it doesn't have to be STEM or even educational. Silly test content is very welcome and you won't be penalized in any way. Just keep it legal!
Intro to OurBigBook
. Source. We have two killer features:
- topics: topics group articles by different users with the same title, e.g. here is the topic for the "Fundamental Theorem of Calculus" ourbigbook.com/go/topic/fundamental-theorem-of-calculusArticles of different users are sorted by upvote within each article page. This feature is a bit like:
- a Wikipedia where each user can have their own version of each article
- a Q&A website like Stack Overflow, where multiple people can give their views on a given topic, and the best ones are sorted by upvote. Except you don't need to wait for someone to ask first, and any topic goes, no matter how narrow or broad
This feature makes it possible for readers to find better explanations of any topic created by other writers. And it allows writers to create an explanation in a place that readers might actually find it.
Figure 1. Screenshot of the "Derivative" topic page. View it live at: ourbigbook.com/go/topic/derivativeVideo 2. OurBigBook Web topics demo. Source. - local editing: you can store all your personal knowledge base content locally in a plaintext markup format that can be edited locally and published either:This way you can be sure that even if OurBigBook.com were to go down one day (which we have no plans to do as it is quite cheap to host!), your content will still be perfectly readable as a static site.
- to OurBigBook.com to get awesome multi-user features like topics and likes
- as HTML files to a static website, which you can host yourself for free on many external providers like GitHub Pages, and remain in full control

Figure 2. You can publish local OurBigBook lightweight markup files to either OurBigBook.com or as a static website.
Figure 3. Visual Studio Code extension installation.
Figure 5. . You can also edit articles on the Web editor without installing anything locally. Video 3. Edit locally and publish demo. Source. This shows editing OurBigBook Markup and publishing it using the Visual Studio Code extension. 
- Infinitely deep tables of contents:




All our software is open source and hosted at: github.com/ourbigbook/ourbigbook
Further documentation can be found at: docs.ourbigbook.com
Feel free to reach our to us for any help or suggestions: docs.ourbigbook.com/#contact