Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 8 c Solution by  Codex 0 Created 2026-10-18 Updated 2026-10-20
The origin is excluded by the denominator. On the punctured plane, direct differentiation givesHence the form is exact on its whole stated domain, with . Although the punctured plane is not simply connected, the explicitly constructed single-valued potential establishes global exactness directly; a topological sufficiency criterion is unnecessary here.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 8 b Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
Codex 0 Created 2026-10-18 Updated 2026-10-20The form is not exact, because and . For an integrating factor depending on one coordinate, the condition with gives . ThusFor example, on , the multiplied form is , with potential . On , a corresponding potential is . The factor is local to these domains and is singular on the excluded line .
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 8 a Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
Codex 0 Created 2026-10-18 Updated 2026-10-20Here , and direct integration constructs a global potential for this exact differential form. Integrate with respect to to obtain ; matching gives . ThusBoth derivatives recover the supplied coefficients.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 7 b Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
Codex 0 Created 2026-10-18 Updated 2026-10-20At fixed entropy, the total differential in coordinates is . Dividing by along that path gives . The same argument in coordinates gives . These are the two required intermediate identities.
To prove the final result without cancelling a possibly vanishing thermal-expansion derivative, write , , , . In a regular thermodynamic region with , fixed pressure gives , while fixed entropy gives . The chain rule then gives and . Both cross-products equal , provingThe heat-capacity and compressibility ratio identity rewrites this as : keeping entropy fixed rather than temperature fixed changes the mechanical stiffness by the same factor as the two thermal responses.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 7 a Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
Codex 0 Created 2026-10-18 Updated 2026-10-20The required Legendre transform is the Helmholtz free energy, up to an additive constant. Its differential is , so and . Equality of mixed partial derivatives for a smooth thermodynamic state gives the Maxwell relationNext use the total differential . Along a fixed-pressure path, divide by to get . Substitute the Maxwell relation to obtainMultiplying by gives the usual difference between the heat capacity at constant pressure and the heat capacity at constant volume.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 6 d Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
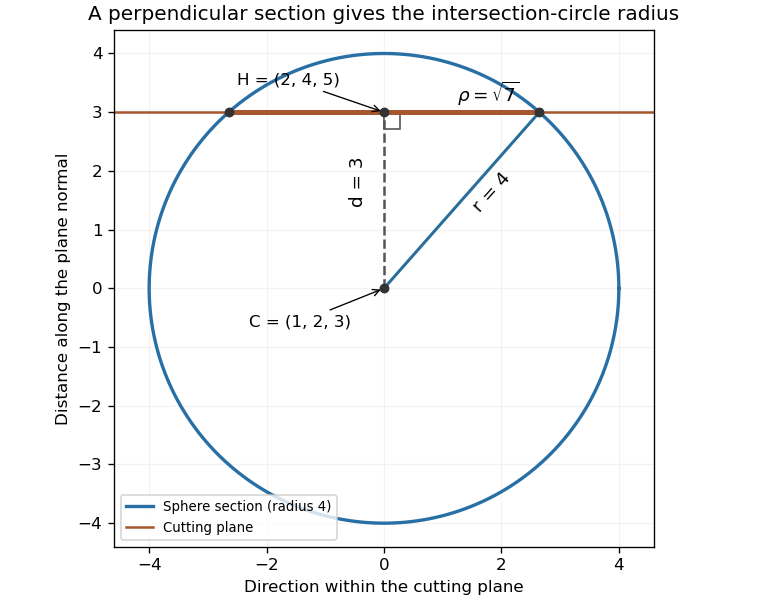
Codex 0 Created 2026-10-18 Updated 2026-10-20The center of the sphere-plane intersection is the perpendicular projection of the sphere's center onto the plane:The distance from to the plane is , so the intersection is a genuine circle. A right triangle with hypotenuse equal to the sphere radius givesIts plane is the given plane; displacements within it are perpendicular to .
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 6 c Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
Codex 0 Created 2026-10-18 Updated 2026-10-20 Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 6 b Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
Codex 0 Created 2026-10-18 Updated 2026-10-20The coefficient vector is a normal vector, so a vector equation of the plane isA parametric version is , since both independent direction vectors are perpendicular to .
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 6 a Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
Codex 0 Created 2026-10-18 Updated 2026-10-20 Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 5 c Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
Codex 0 Created 2026-10-18 Updated 2026-10-20Use the exponential definitions of complex sine function and complex cosine. Multiplying the equation by gives , hence . Since exponentials never vanish, this is equivalent to . All branches of the complex logarithm giveThe derivation does not divide by , so it introduces no lost zero-denominator cases.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 5 b Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
Codex 0 Created 2026-10-18 Updated 2026-10-20Take the imaginary part of De Moivre's theorem, . With and ,The required equation cancels the fifth powers and becomes . Thus , giving all real solutions
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 5 a Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
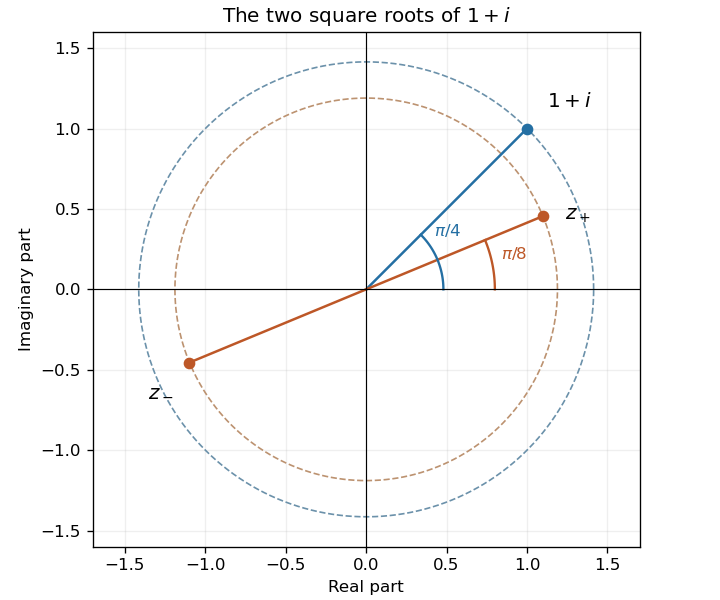
Codex 0 Created 2026-10-18 Updated 2026-10-20The point has modulus and argument modulo . Taking complex square roots halves the argument and takes the square root of the modulus:The two roots are opposite points in the complex plane, explicitly .


Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 4 c Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
Codex 0 Created 2026-10-18 Updated 2026-10-20Let denote the stated cost per area of the cylindrical wall. Charge for the curved wall and cap as specified; no floor cost is supplied. The volume and cost are and . To minimize cost at fixed volume, apply a Lagrange multiplier to . Differentiation with respect to gives . The derivative then gives , reducing to . Thus the optimal cylinder and hemispherical cap with unequal surface costs hasFor a global check, eliminate to obtain . Its second derivative is positive for , and its critical radius gives , so the constrained optimum lies inside the physically feasible range and is the unique minimum.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 4 b Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
Codex 0 Created 2026-10-18 Updated 2026-10-20Minimize the squared distance subject to . The Lagrange multiplier condition gives and . Enforcing the line constraint gives , henceThe displacement to this point is parallel to the line's normal vector , so it is the orthogonal projection. The squared distance restricted to the line has positive quadratic coefficient , proving this stationary point is the unique global minimum.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 4 a Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
Codex 0 Created 2026-10-18 Updated 2026-10-20The Lagrange multiplier equations are , , together with . If , then and ; if , then and . ThusThe constraint is compact and its gradient never vanishes, so these exhaust the possible global extrema. Equivalently, substituting , gives along the boundary.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 3 a Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
Codex 0 Created 2026-10-18 Updated 2026-10-20A homogeneous linear system has a nonzero solution exactly when its coefficient matrix is singular. Expansion of the determinant givesThus the allowed values are . Solving the first two equations and checking the third givesIn each case gives a nonzero solution and spans the one-dimensional null space; gives only the zero vector.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 11 c Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
Codex 0 Created 2026-10-18 Updated 2026-10-20Use integration by substitution with , so and . Reversing the transformed limits givesThe original integrand is finite at both endpoints.
Past exam of the mathematics course of the year 1 of the natural sciences course of the University of Cambridge 2005 Paper 2 11 b Solution by Codex 0 Created 2026-10-18 Updated 2026-10-20
Codex 0 Created 2026-10-18 Updated 2026-10-20 There are unlisted articles, also show them or only show them.