
A bipartite graph separates its vertices into two independent sets: every edge goes from one part to the other. Here is a finite simple graph and an undirected graph, with no self-loops and no repeated edges. The two parts satisfyThus neither part contains an edge. The parts need not have equal sizes, and some pairs across them may have no edge; requiring every cross pair gives a complete bipartite graph. The independent set and cross-edge definitions are equivalent.[ref]
The Basics (author-hosted chapter preview). Section 1.1, printed p. 3, independent vertices; Section 1.6, printed p. 17, bipartite and complete multipartite graphs
For example, the six-vertex cycle graph with edges has parts and . Drawing the same graph as a hexagon or in two columns changes neither its edges nor its bipartite property. An extra isolated vertex can go in either part.
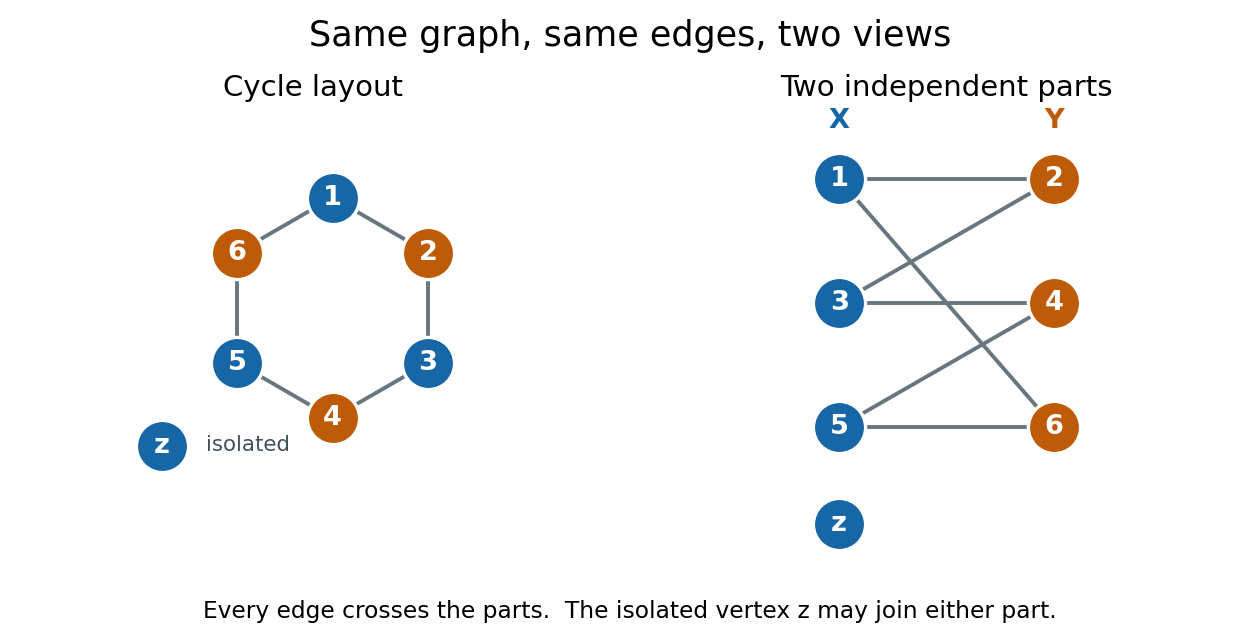
We allow either part to be empty. Consequently a graph with no edges is bipartite, even when ; choose , . Here "two colours" means two colours are available, with no requirement to use both. This convention explicitly includes the empty case, whereas definitions requiring two nonempty classes need an exception. For several connected components of a graph, choose the two parts separately in each graph component and take their unions. In a nonempty connected graph that is bipartite, fixing one vertex's colour forces all others along graph paths, so its two-colour assignment is unique up to swapping the colours. Each graph component, including an isolated vertex, can be swapped independently.
The two-colourability criterion for bipartite graphs identifies these parts with the colour classes of a proper vertex colouring: assign colour to and colour to , so adjacent vertices have different colours. More surprisingly, the odd-cycle characterization of bipartite graphs turns a global requirement into one precise obstruction:This statement is for the finite undirected graph and simple graph model above; a graph cycle has distinct vertices except for the repeated starting vertex. Along a graph cycle in a bipartite graph, colours alternate, so returning to the starting colour takes an even number of edges. Therefore any odd cycle, whether or not other edges join its vertices, prevents a bipartite split.[ref]
The Basics (author-hosted chapter preview). Section 1.6, Proposition 1.6.1 and proof, printed pp. 17–18
Breadth-first search supplies the converse constructively. Start an uncoloured vertex with colour , and use a FIFO queue to explore its graph component. When an edge first discovers , give the opposite colour to , record as its parent in a rooted tree, and enqueue . If both endpoints of any scanned edge already have the same colour, stop with a conflict. Restart from an uncoloured vertex until every graph component has been examined. If no conflict occurs, all edges cross the two colour classes, which are the required independent sets.[ref]
A conflict also explains the failure. In the rooted tree produced by breadth-first search, let be the graph distance from . The colour of is its distance's integer parity. An edge in an undirected graph satisfies , so equal colours force . Follow the two parent chains upward to their lowest common ancestor , discard the shared graph path from to , and join the remaining two graph paths with the conflict edge . The result is a genuine graph cycle withedges, an odd integer. The two branches have no shared vertices except , so this is more than a closed walk. This odd cycle is a certificate that anyone can check directly, using only its listed vertices and edges.
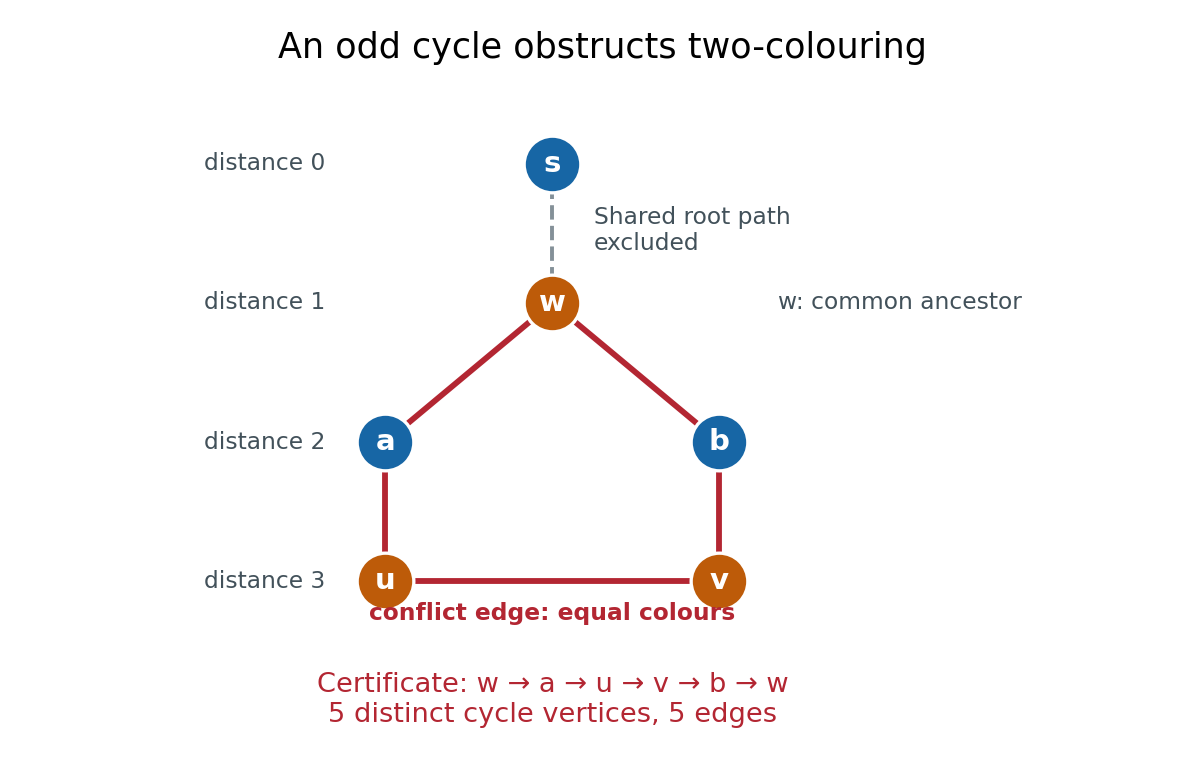
In the example, breadth-first search from gives , , and . The conflict edge closes the odd cycle , with five edges. The common edge is excluded. Thus the same procedure returns either two independent sets covering , or an explicit odd cycle. With adjacency lists and constant-time FIFO queue operations, its time complexity is in Big O notation, with additional storage.[ref]
The two parts often have a practical meaning: workers and jobs, with an edge exactly when a worker can perform a job. A matching in a graph chooses compatible worker–job pairs with no reused endpoint; merely being bipartite does not guarantee enough compatible pairs. Hall's marriage theorem characterizes when every worker can be matched, and the assignment problem adds costs to seek an optimal assignment. These connections make the bipartite structure useful after recognition, as the starting point for selecting edges under constraints.
The crossing number of a graph is the minimum number of edge-crossing pairs among its plane drawings. For a fixed drawing, deleting at most one edge per crossing pair leaves a planar graph.
A planar graph admits at least one graph drawing in which edges meet only at common endpoints. This is a property of the abstract graph, not a requirement on every graph drawing. A plane graph specifies one such drawing.[ref]
Planar Graphs; Bipartite Matching by Albert R. Meyer (6.042J lecture 5f). Planar Graphs; Bipartite Matching, slides lec 5f.3 and 5f.12
For example, the complete graph joins every pair of four vertices, giving six edges. Put its vertices at the corners of a square and its diagonals cross. Instead put at the corners of a triangle and inside it: the same six edges now meet only at their endpoints. The first graph drawing obscures planarity; the second proves it. In particular, its crossing number is zero.
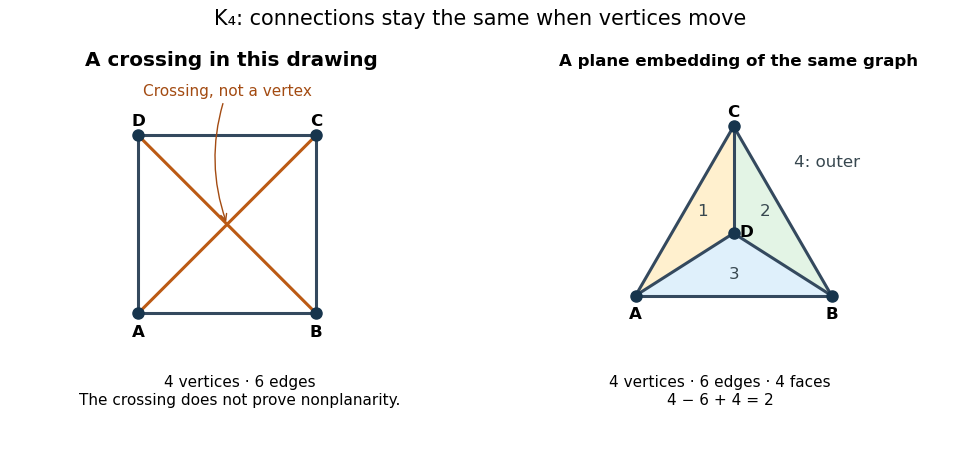
The distinction matters whenever connections must fit on one surface without intersecting. A failed graph drawing may only need rearrangement, whereas nonplanarity by edge counts proves that every rearrangement fails.
The line graph has one vertex for each edge of , with adjacency when two original edges share an endpoint.
An Eulerian graph has an Euler circuit: a closed trail traversing every edge exactly once. Here the graph is a finite undirected graph, possibly a multigraph with self-loops. Parallel edges retain distinct identities, and each self-loop contributes two to its vertex degree. Repeated vertices are allowed. This models inspecting every road segment once, even when a junction must be revisited.
For a nonempty set of edges, the Euler circuit criterion requires a connected graph only on the edge support of a graph: isolated vertices impose no travel requirement. A single vertex with a self-loop and two vertices joined by two parallel edges are both Eulerian graphs. Neither requires three vertices. With no edges and at least one vertex, we allow the zero-length trail at that vertex as an Euler circuit; the graph with no vertices has no such walk.
The motivating Seven Bridges of Königsberg problem asks for an Eulerian trail, which need not return to its starting vertex. In Leonhard Euler's Solutio problematis ad geometriam situs pertinentis by Leonhard Euler, §2 poses the bridge-crossing question and §§4–6 encode land regions by letters. The river's shape drops out: only the connections matter. The paper was written in 1735 and published in 1741, according to the Euler Archive; the journal volume carries the nominal year 1736.[ref]
A flow network is a directed graph with distinct source and sink vertices and a nonnegative flow network edge capacity on each directed edge . In the finite setting here, every flow network edge capacity is a finite real number. A feasible flow assigns a nonnegative amount to each original directed edge, satisfies the capacity constraints, and obeys flow conservation at every other vertex:These are nonnegative arc amounts. The antisymmetric convention in flow instead records net amounts , taking a missing arc amount as zero. The two conventions express the same flow conservation; keeping them distinct makes backward residual network edges easier to interpret.
Think of vertices as routers, directed edges as communication links, flow network edge capacities as available bandwidth, and flow as a steady transmission rate. An intermediate router can distribute incoming traffic among outgoing links, but flow conservation prevents it from creating traffic. The maximum flow problem asks how much total traffic can pass from to , allowing several graph paths to share the work. The same flow network language models transportation and abstract resource allocation.[ref]
https://ocw.mit.edu/courses/6-854j-advanced-algorithms-fall-2008/4064d889e5033a9915327a777d12b592_notes_flow.pdf. Goemans, Network flows, introduction and maximum flow formulation
Our running flow network has vertices and exactly five directed edges, with flow network edge capacitiesThe cross edge lets traffic entering use spare capacity on . With this edge removed, the two separate graph paths can carry only ; including it will let the maximum flow reach . Thus a link's usefulness depends on the rest of the flow network, rather than just its own flow network edge capacity.
A complete graph is a simple graph in which every two distinct vertices are joined by an edge. The finite complete graph on vertices is denoted . Here the edges are undirected, and self-loops are excluded. The usual pictures below use : is a single vertex, a single edge, and a triangle in a graph.[ref]
Graph Theory by Reinhard Diestel. §1.1, printed p. 3 of the third electronic edition (2005): pairwise adjacency, complete graphs and triangle notation
Completeness describes all the possible pairs, rather than a drawing style. Different layouts can represent the same graph through a graph isomorphism. Crossing lines away from the drawn vertices do not add new vertices or edges.
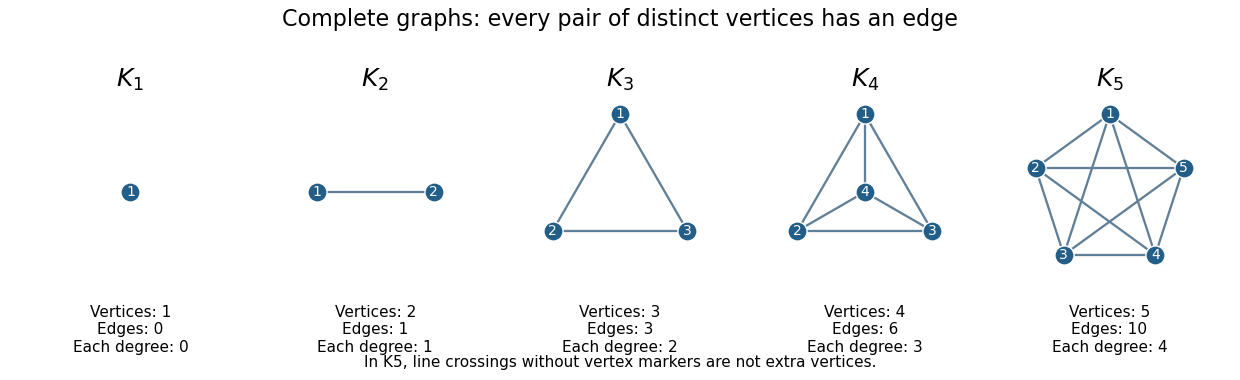
Complete graphs with one through five vertices
. Each original drawing joins every pair of distinct vertices exactly once. The complete graphs have respectively edges. Intersections of drawn lines in the panel are not additional vertices. Details.There are unordered pairs of distinct vertices, so this is the edge count of a complete graph. Each vertex has vertex degree . The degree-sum formula gives the same count: . These formulas make a complete graph the upper extreme for edge counts among simple graphs of a fixed size.
This is useful when modelling pairwise relationships. If every pair of objects needs its own direct connection, ten vertices require edges, while twenty require . Adding one more vertex to introduces further edges. This counts a specified direct-link model; it does not require every communication system to implement every relationship with a separate physical connection.
A proper vertex coloring of must give every vertex a different color, so its chromatic number is . For , its independence number is : two distinct vertices already have an edge between them. Thus complete graphs provide immediate test cases for graph coloring and independent sets.
An edge joins two vertices of a graph; in a simple graph it is an unordered pair of distinct vertices.
An edge of a graph joins endpoints in a graph. For a simple graph it is an unordered pair of distinct vertices of a graph; for a directed graph its endpoints are ordered.
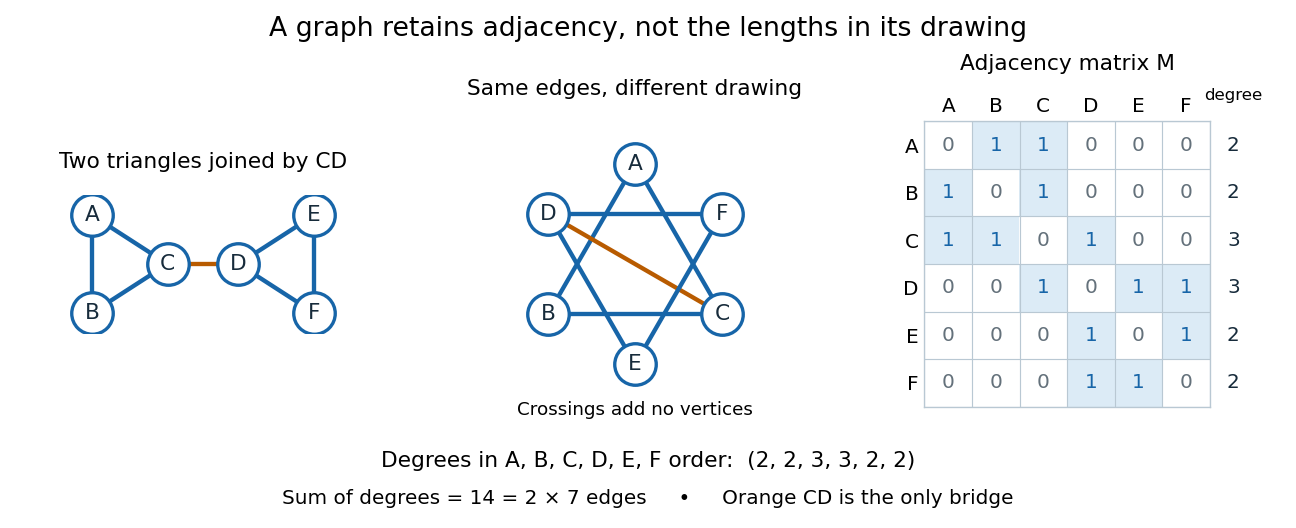


A graph describes objects, called vertices, and pairwise connections, called edges. Its vertex set tells us what the objects are; records their connections. The basic abstraction retains graph adjacency while discarding positions, angles and Euclidean distances: moving the dots in a drawing changes none of the edges. A crossing of two drawn lines is not an extra vertex unless explicitly designated as one. Even the labels can change: a graph isomorphism is a relabelling that preserves graph adjacency in both directions.[ref]
This makes graphs useful when the question concerns possible connections rather than physical shape. For example, model locations by vertices and direct links by edges; a graph path answers whether one location can reach another. Alternatively, let vertices be activities and edges represent conflicts: a graph coloring then assigns compatible time slots. These are mathematical models, so one must decide which pairwise relationship an edge means before applying graph theory.[ref]
Our running simple graph haswhere abbreviates the unordered pair . It consists of two triangles in a graph, and , joined by . The two drawings above have identical graph adjacency, even though their apparent lengths differ. What counts is that and are adjacent, whereas and are not.
Route questions require precise vocabulary. A walk is a sequence of consecutive adjacent vertices, permitting repetitions; its length counts traversed edges. A trail is a walk that repeats no edge; a graph path repeats no vertex. For a multigraph, the walk must also specify which parallel edge each step uses. For instance, is a length-five walk but not a trail, since it uses twice. The length-three graph path is a shortest route: crossing between the two triangles in a graph requires , with at least one edge before it and one after it. Thus in graph distance, regardless of the drawing.[ref]
https://ocw.mit.edu/courses/6-1200j-mathematics-for-computer-science-spring-2024/mit6_1200j_s24_lec13.pdf. MIT, Connectivity and Trees, Section 1
An Eulerian trail uses every edge exactly once, allowing repeated vertices; a Hamiltonian path visits every vertex exactly once, without needing every edge. Here is an Eulerian trail of length seven, whereas is a Hamiltonian path of length five. The first repeats ; the second omits . Calling an Eulerian trail an "Eulerian path" must not be taken to impose our graph path convention.[ref]
https://ocw.mit.edu/courses/6-1200j-mathematics-for-computer-science-spring-2024/mit6_1200j_s24_lec13.pdf. MIT, Connectivity and Trees, Section 3
The classic historical example is Euler's Königsberg bridge problem: represent the four land regions by vertices and the seven bridges by distinct edges, giving a multigraph. Their degrees of vertices are . In a trail using every edge, arrivals and departures pair at every internal vertex, so at most the two endpoints can have odd vertex degree. Four odd degrees of vertices therefore rule out such a route. This early foundational example of graph theory needs neither bridge lengths nor a geographical map. Euler's paper is conventionally associated with 1736, the volume's nominal year; the Euler Archive records its writing in 1735 and publication in 1741.[ref][ref]
https://la.wikisource.org/wiki/Solutio_problematis_ad_geometriam_situs_pertinentis. Euler, original Latin text and edition details
The binomial random graph has vertex set and includes each of the possible edges independently with probability .
The grand canonical partition function is
An interval map has a horseshoe when there are an open interval and disjoint open intervals such thatIterating inverse branches produces full two-symbol itinerary dynamics.
Ice sheet dynamics describes the gravity-driven deformation and basal motion of large terrestrial ice masses together with their mass balance.
There are unlisted articles, also show them or only show them.