For a finite, time-homogeneous Discrete-time Markov chain with row-stochastic transition matrix , a state is absorbing exactly when . Nonnegativity and the row sum then force for : once entered, is never left. Equivalently, is a closed communicating class. A larger closed communicating class may keep moving internally; closure means confinement to a set, whereas absorption at a state means remaining at one point.
An absorbing state is useful for recording a terminal outcome: after a toy routine finishes, keep its outcome in the state space so that the same transition matrix still describes subsequent steps. Calling a finite Markov chain absorbing usually also requires that some absorbing state be accessible from every state. Merely containing an absorbing state is insufficient: another closed communicating class could prevent absorption. See Grinstead and Snell, Introduction to Probability, section 11.2 for this convention.
Consider a constructed routine with unfinished modes and terminal outcomes . All the following transition probabilities are chosen for illustration, not estimated from observations. In state order , takeThe communicating class is open, while and are closed communicating classes consisting of absorbing states. Both terminal outcomes are accessible from both unfinished modes, sometimes by an indirect path.
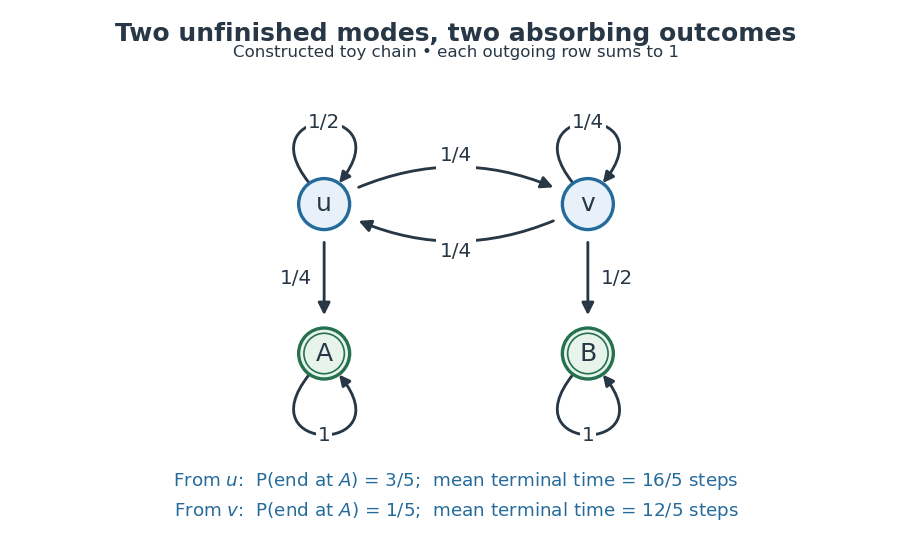
A constructed four-state routine: arrows give transition probabilities, and the two absorbing outcomes have different eventual probabilities and waiting times.
Details. 
Let be the terminal hitting time. Write for the absorption probability and for the expected hitting time, with the subscript denoting the starting state. First-step analysis givesHere , , and . Solving these two pairs of linear equations yieldsStarting at therefore ends at with probability and takes steps on average to reach either terminal state. The terminal hitting time counts the transition into the outcome, but no later self-transitions. Outcome and duration answer different questions: from , outcome is less likely, yet termination is faster on average.
The matrix power gives the probability distribution after two steps from asThus , and the probability of having already reached is , still below its eventual absorption probability . From either unfinished mode, each next step has terminal probability at least . Consequently , proving termination almost surely and finite expected hitting time directly. The Fundamental matrix of a finite absorbing Markov chain packages both calculations and counts visits to unfinished modes.
For a finite Markov chain in which an absorbing state is accessible from every state, order the nonabsorbing states first and writeHere is the identity matrix and is the matrix inverse of . With the first hitting time of the absorbing set,Thus gives the expected occupation count before absorption, including the initial visit; is the absorption probability of state ; and is the expected hitting time of the absorbing set. The vector has every entry one. See Grinstead and Snell, section 11.2, theorems 11.4-11.6.
For the toy routine in absorbing state, direct matrix multiplication givesThe first row of says that starting at gives visits to and to before termination. Their sum is the mean duration . The identities , , and independently verify the inverse, outcome, and duration calculations. The absorbing set must be reachable from every state for these finite formulas: applying them to all nonabsorbing states in the closed-cycle example would leave a persistent cycle in and make singular.
Articles by others on the same topic
There are currently no matching articles.