A damped pendulum is a simple pendulum whose mechanical energy is removed by a resisting torque. Here the model is undriven, with a fixed pivot, a point mass at distance , uniform gravitational acceleration , and resisting torque with constant . The angle is measured from the downward vertical in radians. An ideal viscous rotary dashpot realizes this torque law; tangential linear drag on the bob gives the same equation with . The moment of inertia is , soHere is physical time, is the undamped small-amplitude angular frequency, and has units of inverse time. In the normalized equation , dots mean differentiation with respect to , not . The parameter is dimensionless. This separates the chosen damping law from the small-angle approximation: retaining allows finite angles even when the resisting torque is linear in angular velocity.
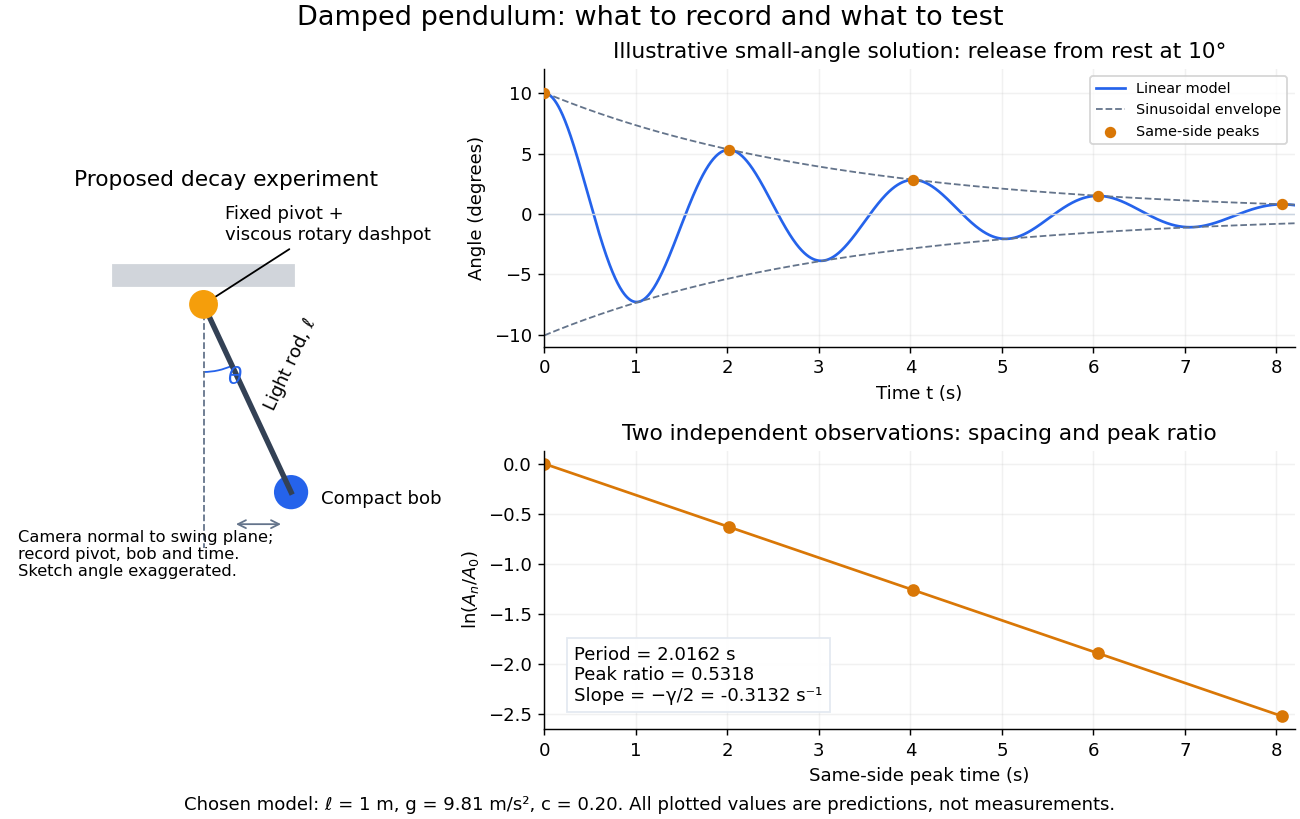
Proposed viscous-damper experiment and illustrative small-angle decay: angle versus time and successive peak ratios, not measured data
. Details. 
To motivate the model, release a pendulum without a push and record how its swing shrinks. A published example by Gintautas and Hubler uses a rotary sensor built from a computer mouse to measure the frequency and damping coefficient of a physical pendulum. [ref]
https://arxiv.org/abs/0901.4319. Gintautas and Hubler, A simple, low-cost, data-logging pendulum built from a computer mouse, 2009
The following is a proposed experiment with a chosen viscous rotary dashpot; the plotted observations are predictions, not a reproduction of their measurements.Mount a compact bob on a light rigid rod with a fixed pivot, couple the pivot to an adjustable viscous rotary dashpot, and measure from the pivot to the bob's centre. First record decay with the dashpot disconnected, then repeat with it connected at several settings; this establishes how much decay is already due to other losses. Keep the bob, rod, camera, and release angle unchanged between these trials. The simple model requires rod and damper-rotor moments of inertia to be negligible compared with . Otherwise measure the total moment of inertia and the distance to the assembly's centre of mass: the physical pendulum equation becomes , where is the total moving mass. A damper that also exerts an elastic restoring torque would require another term.
Place a camera perpendicular to the swing plane, include the pivot and bob centre in every frame, and determine their coordinates relative to the resting vertical. For horizontal and downward separations , use ; record the frame timestamps rather than assuming a frame rate. Release from rest at about , record through several complete swings, and repeat the release. For every same-side turning point, tabulate its time and angular amplitude . Measure the oscillation period from differences ; comparing several periods exposes drift. Interpolating around each observed extremum reduces frame discretization error. Check that late peaks still exceed the angular resolution; taking the natural logarithm of tiny, uncertain peaks amplifies their relative errors.
In the small-angle approximation, the damped pendulum becomes a damped harmonic oscillator. For and release from rest at , its exact linear-model solution isThe decaying sinusoidal envelope has coefficient ; because release is from rest, its successive same-side extrema occur at and have . Thus the envelope and the sequence of actual peak heights are different descriptions of the same trace. The linear damping regimes and this solution are derived in Richard Fitzpatrick, Damped Oscillatory Motion, equations 82–93.
The experiment tests two predictions independently: nearly equal same-side peak spacing and a straight line when plotting against . Its predicted slope is , givingUse several peaks and repeated trials rather than a single ratio, and compare the frequency identity with independently measured and . For the illustrative choices , , , and , the linear model gives , , and . The first two positive peaks after release are therefore approximately and . The undamped small-amplitude oscillation period is about : substantial loss per swing need not imply a large change in period.
Repeat at a larger release angle to distinguish two limitations. The relative error in replacing by is about for small angles: about at , but about at when compared with . Finite-amplitude swing spacing can therefore change as the swing shrinks even if is constant. Separately, friction at the pivot or quadratic drag can invalidate the assumed linear resisting torque; exponential peak decay should be checked, not imposed on all recorded motion. Peters discusses why real pendulum damping can require nonlinear terms. [ref]
https://arxiv.org/abs/physics/0306081. Randall D. Peters, Nonlinear Damping of the 'Linear' Pendulum, 2003
Repeatability, residual pivot motion, changes in damper temperature, and finite camera resolution are useful checks on this proposed measurement.The normalized equilibrium points are . Even multiples of are attracting: their linearization has eigenvalues , giving a stable focus for , repeated negative eigenvalues at , and a stable node for . These are the underdamped, critically damped, and overdamped small-displacement regimes. Odd multiples of have eigenvalues of opposite signs and are saddle equilibria. The energy dissipation of a damped pendulum explains why trajectories in the phase portrait spiral inward near a stable focus instead of closing into the recurring orbit of an undamped simple pendulum.
For the normalized damped pendulum, the sum of kinetic energy and gravitational potential energy, divided by , isThe chain rule and the full nonlinear equation give this identity exactly, without a small-angle approximation. Here as in damped pendulum. In physical units the mechanical energy and the power of the resisting torque areThe pendulum's lost mechanical energy is transferred to the damper and surroundings; it does not violate conservation of energy. In an ideal viscous dashpot this loss is frictional heating. The exact cumulative balance is particularly useful for checking a numerical solution:
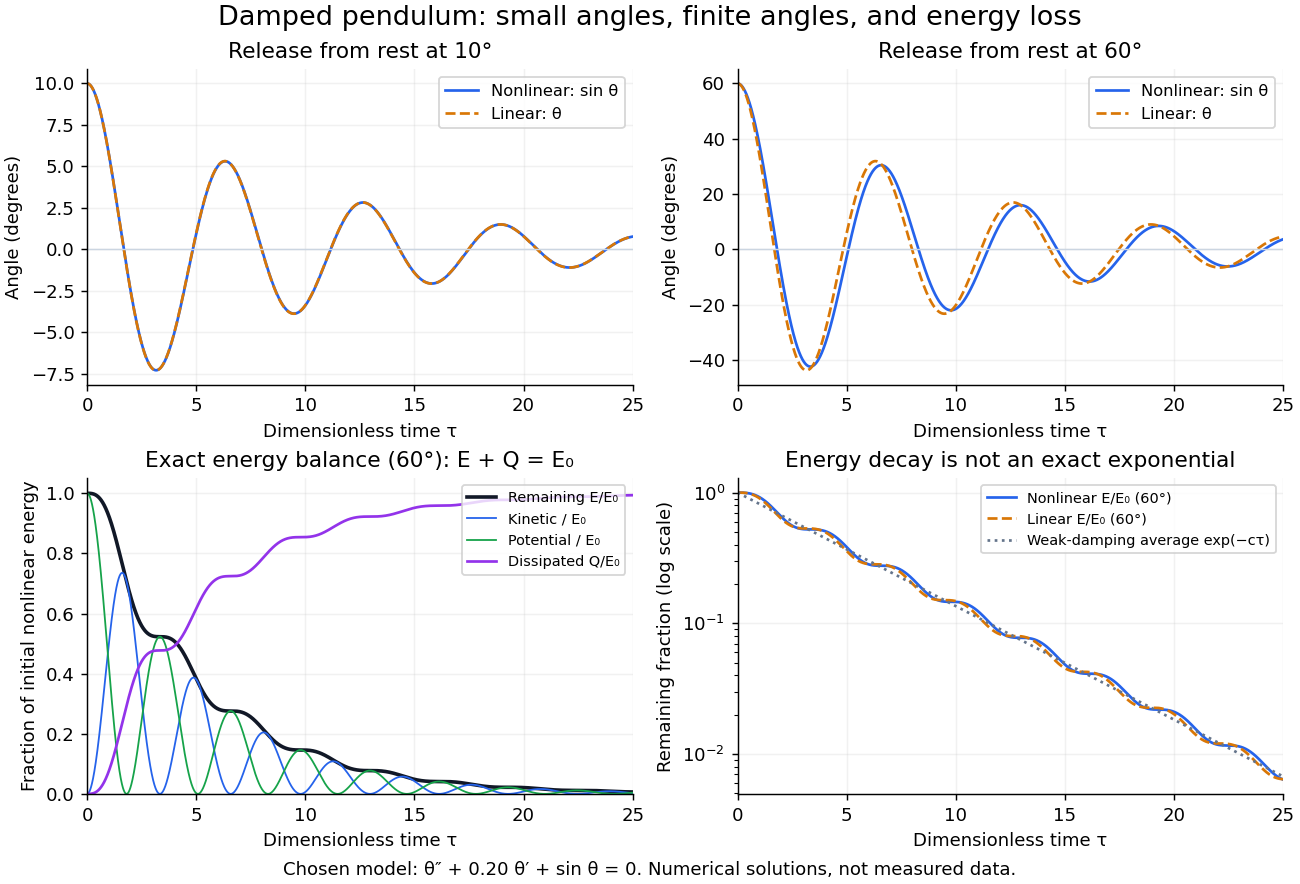
Illustrative nonlinear and linear damped pendulum solutions at 10 and 60 degrees, with exact mechanical energy transfer and loss; no measured data
. Details. 
The figure uses and release from rest. Over , the largest angular discrepancy between the nonlinear solution and the damped harmonic oscillator solution is approximately () for a release, but () for a release. Their nonlinear initial energies are and , respectively. At the remaining fractions are approximately and . These are illustrative calculations from specified initial conditions, not observations. The generator uses a Runge-Kutta method and integrates alongside the motion; halving its step and independently integrating checks the result.
For and , the first three nonlinear same-side swing intervals after a release are approximately , , and . They approach the linear-model oscillation period as the amplitude shrinks. After a release the corresponding intervals are already about , , and . This makes the experiment's period drift a quantitative test of the small-angle approximation, rather than an automatic reason to change the damping coefficient.
At a turning point, and even though the swing is losing mechanical energy over the cycle. Its potential energy there is , so measured turning angles give successive energies without estimating angular velocity. In the proposed decay experiment, multiply these values by to obtain energies in joules, then subtract adjacent same-side energies to estimate the loss over each full swing. Only for small amplitudes is . In the linear underdamped model, same-side peak energies consequently satisfy , the square of the angular amplitude ratio. For the illustrative parameters above this energy ratio is approximately . Between turning points, kinetic energy and potential energy continue to exchange while their sum decreases; the energy slope vanishes briefly at each extremum and is negative whenever the bob moves.
It is therefore inaccurate to replace the exact identity by . Even for the linear model, has . For weak damping and small angles, cycle averaging gives , so the averaged energy approximately follows while angular amplitude follows . This exponential decay is an approximation to the energy trace; the same-side peak ratio is exact within the linear model. The figure distinguishes the actual energy curves from this averaging approximation.
The energy identity also gives a global conclusion without solving the nonlinear equation. If were constant on a positive-length interval, then would vanish throughout it; the equation would force , making the entire trajectory an equilibrium. Every nonstationary trajectory therefore loses mechanical energy over every positive-length interval, even though its instantaneous derivative can vanish at a turning point. A nonconstant periodic motion would have to return to its initial mechanical energy, so it is impossible for this undriven damped pendulum. Oscillations near a stable focus are successive, shrinking swings, not a repeating cycle. Moreover, if , the angle cannot reach an upright equilibrium, whose potential energy is ; such motion stays within its original potential well. This is the usefulness of the energy description: one scalar balance controls both the observed decay and which nonlinear motions remain accessible.
Articles by others on the same topic
There are currently no matching articles.