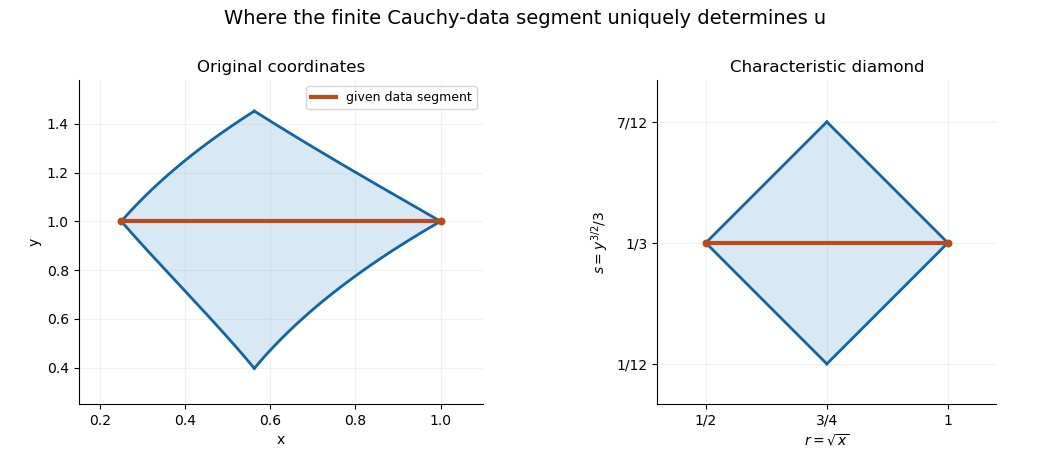
For r=x, s=y3/2/3 and data on y=1, 1/4≤x≤1, the transformed segment is s0=1/3, a=1/2, b=1. The known characteristic arguments lie in [5/6,4/3] and [1/6,2/3]. The corresponding original region has curved boundaries despite being arectangle in characteristic coordinates and adiamond in (r,s) coordinates.
For Noncharacteristic Cauchy data parameterized by t≥0, the method of characteristics produces asurface Φ(s,t)=(x,y,z). The part uniquely fixed asa classical graph through the data must retain both the allowed footpoint range and a nonsingular branch of the projected map. On a branch where inversion gives (s(x,y),t(x,y)), require t(x,y)≥0, together with the branch condition and a nonzero Jacobian determinant. The strict inequality t>0 describes its open interior; the endpoint characteristic t=0 supplies a boundary trace. A fold caustic can supply another boundary.
An algebraic formula obtained by eliminating s,t can extend beyond this domain of dependence. Its values there need not be selected by the original data, because their characteristic footpoints can lie on the unprescribed half of the datacurve. Tracking the parameter range is therefore part of the uniqueness argument, separately from selecting a real square-root branch.
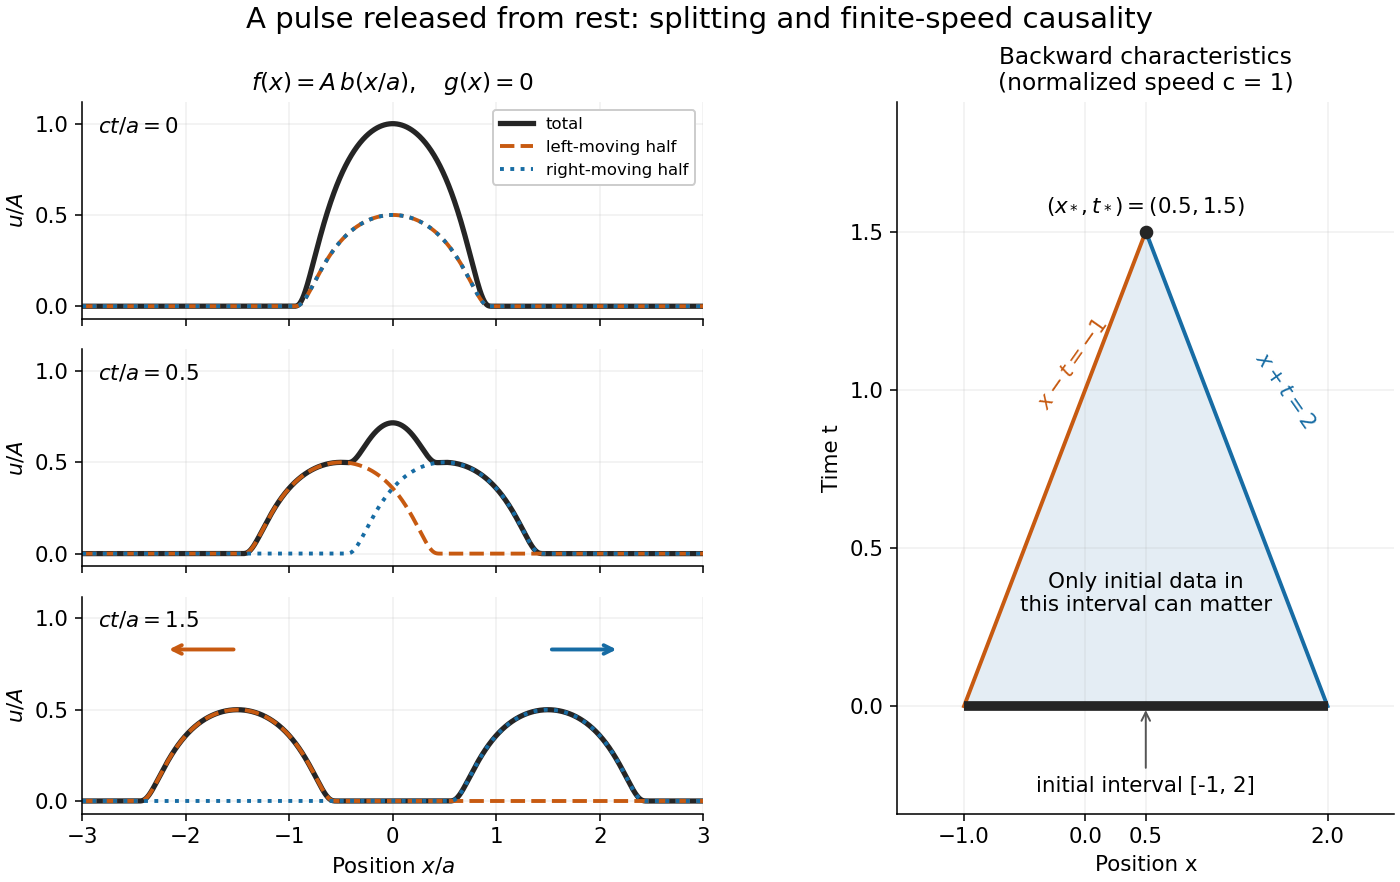
At t=0 the two copies coincide, recovering peak A. At t=a/(2c), u(0,t)=Ae−1/3≃0.716531A. At t=3a/(2c) the pulses are separated, centred at x=±3a/2, each of width 2a and peak A/2. Zero initial velocityforces equal left and right contributions; a purely right-moving initial profile instead requires g=−cf′. Thus “released from rest” and “launched to the right” describe different Cauchy data.
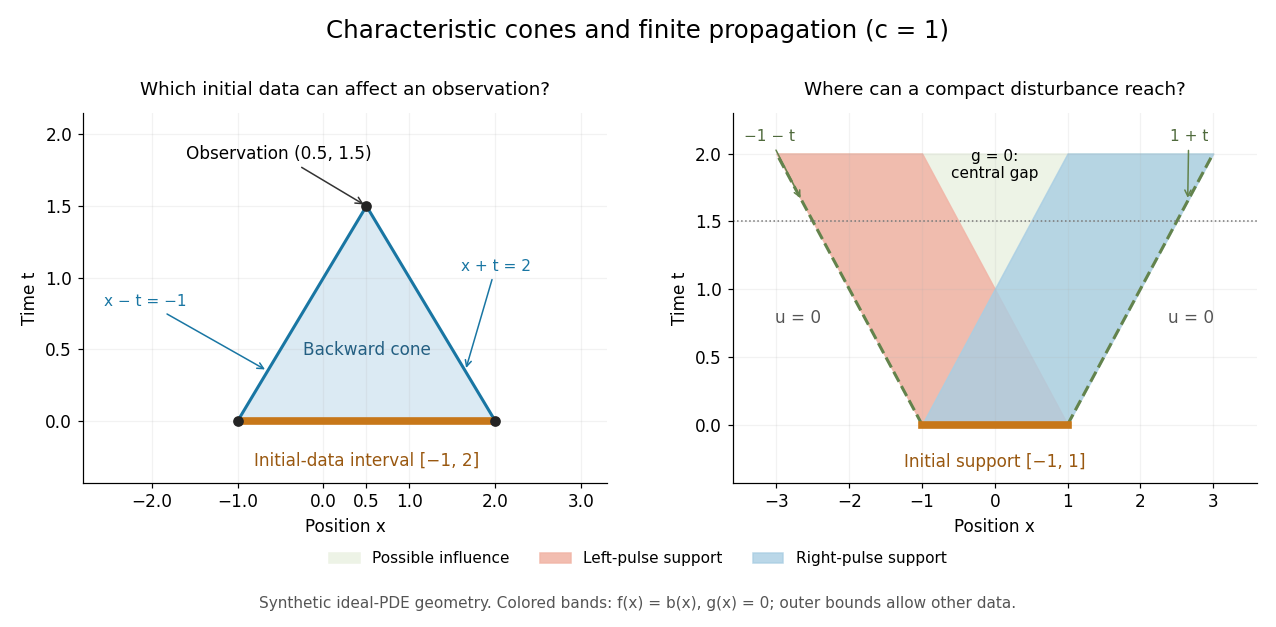
The domain of dependence of (x∗,t∗), for t∗≥0, is contained in [x∗−ct∗,x∗+ct∗] on the initial line. More precisely, displacement contributes only through the two endpoints, while initial velocity contributes throughout the interval. With c=1, x∗=0.5 and t∗=1.5, that interval is [−1,2]. Changing either initial datum outside it cannot change u(0.5,1.5). If both initial data vanish outside [−a,a], the solution vanishes outside [−a−ct,a+ct]: this is finite propagation speed. The expanding interval bounds possible influence; it need not be filled by nonzero displacement, as the separated bumps demonstrate.
Historically, d'Alembert studied the vibrating-string problem in “Recherches sur la courbe que forme une corde tendue mise en vibration”, in the Berlin Academy'svolume for the year 1747, pages 214–219. The memoir introduces the differential equation and integrates it through two arbitrary one-variable functions. The original geometric problem makes the formula's enduring appeal clear: arbitrary initial shapes can be handled without first decomposing them into normal modes. [ref]
For a brief derivation, use characteristic coordinatesξ=x−ct and η=x+ct. The chain rule gives utt−c2uxx=−4c2uξη, so u=F(ξ)+G(η). The initial conditions yield F+G=f and −cF′+cG′=g. Integrating these relations gives the displayed formula; the arbitrary integration constants cancel in their sum.
For utt=uxx−u with u(x,0)=0 and ut(x,0)=e−∣x∣, the solution outside ∣x∣≤t is exactly te−∣x∣. On the positive half-line, te−x satisfies both the equation and initial data; the finite propagation speed limits dependence at x>t to positive initial points. Uniqueness on this domain of dependence proves the formula there, and reflection gives the negative half-line. The exterior tail is nonzero because the initial velocity is not compactly supported.
Integration outside an expanding interval shows that zero initial energy there remains zero. Thus initial support in [−a,a] cannot influence x>a before t=(x−a)/c. The positive energy density includes the restoring term ω02u2/2: this adds oscillation behind the front without extending its domain of dependence. A particular disturbance may fail to excite the leading boundary, so the maximal speed is not a promise of a detectable response for every source.
The water-tank measurement in phase velocity records free surfaceelevation with calibrated resistance probes and usesa ruler and stopwatch for an independent check. The inspected protocol calls the front or back of agroupa timing feature. That visible edge establishes an envelope transit estimate, not the first nonzero disturbance in the sense of front velocity.[ref]
A proposed additional control would repeat the transit fit at several detection thresholds and train durations, using matched probe calibration and the same sampling rate. Dependence on the threshold diagnoses wave envelope reshaping or limited sensitivity; records should be compared before reflections return. Such atest could expose limitations of a group velocity estimate, but would not establish an exact causal front or validate the stipulated Klein-Gordon equation for water waves.
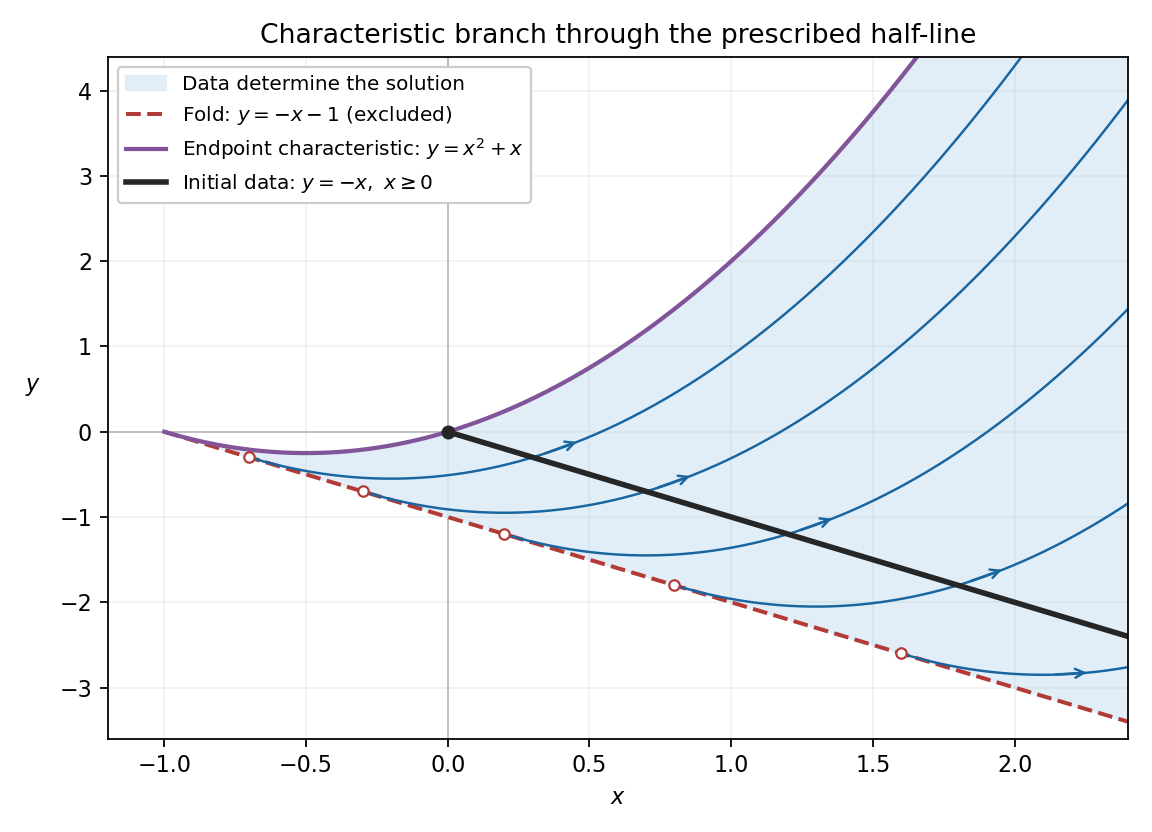
The square root must be positive, and t≥0 requires x+1≥1+x+y>0. Squaring is now legitimate and gives y≤x2+x. Thus the full characteristic-covered set on this branch is
Each point of D has exactly one backward characteristic meeting the interior t>0 of the prescribed data, so the Picard-Lindelöf theorem fixes its value. The upper boundary is the characteristic issuing from the endpoint t=0 and is fixed by the endpoint datum, consistently with the continuous trace from D. The lower boundary is excluded: s=−1 there, the Jacobian determinant vanishes, and the explicit solution derivatives diverge as W↓0.
Points of the half-plane W>0 outside this set have t<0 on the branch through the data. Their characteristic footpoints would lie on the unprescribed continuation of the initial line, so these values are not determined by the given half-line alone. For example, extend the initial value to negative tas 1+εh(t), where h is a smooth function supported on the negative half-line. Such extensions agree with all the prescribed data and, where noncharacteristic, produce different local extensions by the method of characteristics. The displayed formula supplies one possible extension there, but the data do not select it uniquely. This is why retaining the restriction on the initial half-line is essential. Continuing the parameterized surface past s=−1 instead produces the other sheet of the fold; it does not give a differentiable graph continuation through the caustic.
The coefficient matrix of (uy,vy)T is A=(vu−3uv). Its distinct eigenvalues are λ±=v±1/u for every u>0, so the system is strictly hyperbolic. Define D±=∂x+(v±1/u)∂y. Then
the derivative terms cancel, as do the sources u−u. Hence R=v−1/u is constant on the plus-family characteristics.
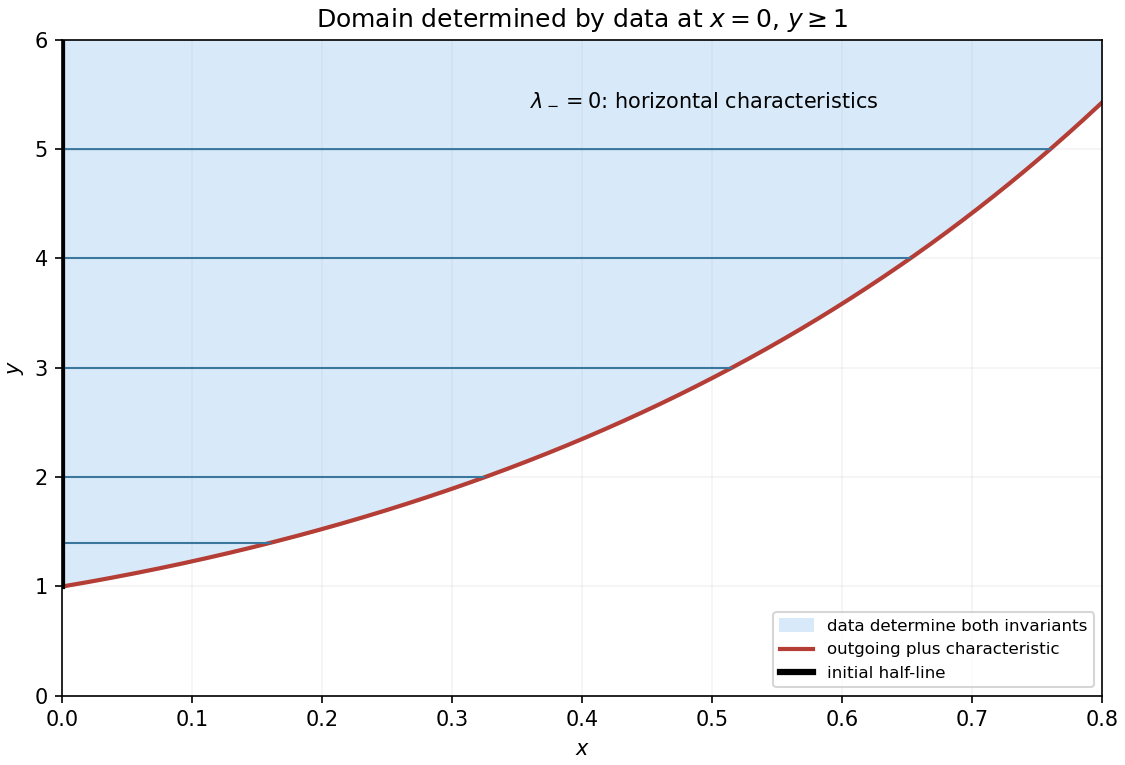
The data give R=0, so throughout their domain of dependencev=1/u. The minus-family speed is then v−1/u=0: the other characteristics are the horizontal lines y=a. Substitution into the second PDE, or its minus-characteristic compatibility relation, gives vx=1/v. Integrate at fixed y using v(0,y)=y and retain the positive branch:
Indeed ux=−u3, uy=−yu3, vy=yu, so vuy+uvy=0; similarly u−3uy+vvy=−y+y=0.
For x≥0 the lower edge of the region determined solely by the given data is the plus characteristic from (0,1). Write it y=b(x), where the exact boundary characterization is
The determined region is x≥0,y≥b(x), with strict inequality for its interior. Both backward characteristic families there reach the supplied initial half-line. Below this boundary a backward plus characteristic would require initial data below y=1, which were not supplied; extending the displayed formulas there gives a possible continuation but is not forced by the data. An elementary expression for b is unnecessary: its initial-value ODE defines it uniquely and the requested other family already has the explicit form y=a. The sketch integrates only this boundary for illustration.
Here J− is the causal past. Events in B cannot send a causal signal to the chosen infinity. This is a global definition: identifying the horizon requires the full future development, so a local measurement need not reveal whether an event lies on it. Smooth portions of an event horizon are null hypersurfaces generated by null geodesics. Generators may join at past caustics or crease sets, so the horizon need not be smooth everywhere. A past event horizon is defined by the time-reversed escape criterion; in the maximally extended Schwarzschild solution it bounds awhite-hole region.
An observer-based definition replaces infinity by a future-inextendible worldline γ. Its future observer event horizon is the boundary of events that can signal to γ, conventionally ∂I−(γ). A past observer horizon similarly bounds events reachable from its past worldline. Such horizons depend on the observer and need not imply a black hole.
At r=2M this metric is regular and the normal dr is null. Future outgoing radial rays satisfy dr/dv=f/2; inside the horizon their areal radius decreases even on the outgoing family. The stationary Killing vector field∂v generates the horizon with κ=f′(2M)/2=1/(4M) when normalized at infinity. The Kretschmann scalar is 48M2/r6, finite at the horizon and divergent at r=0. Thus the event horizon is not the curvature singularity. The photon sphere at r=3M, which supports circular null orbits, is also not the horizon.
Quasi-local horizon notions use null expansions. For a closed spacelike two-surface, choose future outgoing and ingoing null normals ℓ,n, with ℓ⋅n=1 in signature (+−−−). Each expansion is the logarithmic rate of its positive area element along the corresponding null normal. A future trapped surface has θℓ<0 and θn<0: both future light fronts initially shrink. A marginally outer trapped surface has θℓ=0; for the future black-hole type also require θn<0. On a chosen spacelike slice, the outer boundary of the future trapped region is an apparent horizon, ordinarily an outermost marginally outer trapped surface when regularity permits this characterization. It depends on the slice, and a slicing need not display an apparent horizon even when the global spacetime contains an event horizon.
The round spheres inside 2M are future trapped, while r=2M is marginal. On standard horizon-penetrating slices its sections give the apparent horizon, coinciding with the stationary event and Killing horizon. This coincidence in a symmetric stationary example does not identify the notions in a general spacetime.
in units c=1. A possible nonaffinity term vanishes here because it is proportional to the zero expansion. Write a horizon evolutionvectoras V=ℓ−Cn. Preserving θℓ=0 gives C=(Lℓθℓ)/(Lnθℓ)≥0. Hence V2=−2C≤0: the future outer horizon is spacelike or null. Its area expansion is θV=−Cθn≥0. These conclusions use the outer condition and the energy condition, not merely marginality.
Beyond it, causal influences can arrive without meeting the specified initial surface; data on that surface no longer determine the solution there. This is distinct from the inability to send signals to infinity. The inner horizon of the exact charged black hole supplies an example, and the definition necessarily specifies which initial surface is being used.
Finally, the Hubble radius must not automatically be called an event horizon. For a flat expanding cosmology, the two future radial null expansions of asphere of proper radius R are θ±=2(H±1/R). At R=H−1 the ingoing expansion vanishes, while outside it both expansions are positive: this is the cosmological marginal, past-trapped type rather than a future black-holetrapped surface. A dust universe with a∝t2/3 has such a Hubble sphere but no future event horizon. Global causal boundaries, slice-dependent trapped-surface boundaries, symmetry horizons and initial-data boundaries must therefore be distinguished, even when several coincide in a special example.
Thus such a local unselected operation changes no remote expectation in any state, proving an algebraic no-signalling result without assuming atensor-product decomposition of the local algebras. The allowed measurement operations must actually be local; calling an arbitrary ideal projector a measurement is not enough.
with the regions and algebra identifications understood in the specified local net. Definitions applying primitive causality to all bounded open regions can be stronger than atime-slice property stated only for suitable causally convex Cauchy neighbourhoods; these formulations should not be conflated without extra hypotheses.
Use the original PDF's spatial Ricci component Rχχ=aa¨+2a˙2+2; the converted TeX's 2a˙a¨ is a transcription defect. Continue with c=1 and signature (−,+,+,+). Tracing the vacuum Einstein field equations with a cosmological constant gives R=4Λ, and hence Rab=Λgab. The time component therefore gives a¨=(Λ/3)a. Substituting this into the spatial component gives
The left side is strictly positive, so Λ>0 is necessary for a real positive closed scale factor. Define ℓ=3/Λ. The accelerationequation has solution a=Aet/ℓ+Be−t/ℓ, and the first integral fixes 4AB=ℓ2. Taking the positive scale-factor branch and shifting the origin to the minimum gives
One can identify it explicitly: in five-dimensional Minkowski space, set X0=ℓsinhτ and XI=ℓcoshτnI, where ∑I=14(nI)2=1. These coordinates satisfy −(X0)2+∑I(XI)2=ℓ2, and their induced metric is the one above. Thus the solution is global de Sitter spacetime, with spherical spatial topology and both contracting and expanding parts.
The time entering the printed compactification formula is this rescaled time. Write
The angular-coordinate degeneracies at the poles are the usual regular spherical ones.
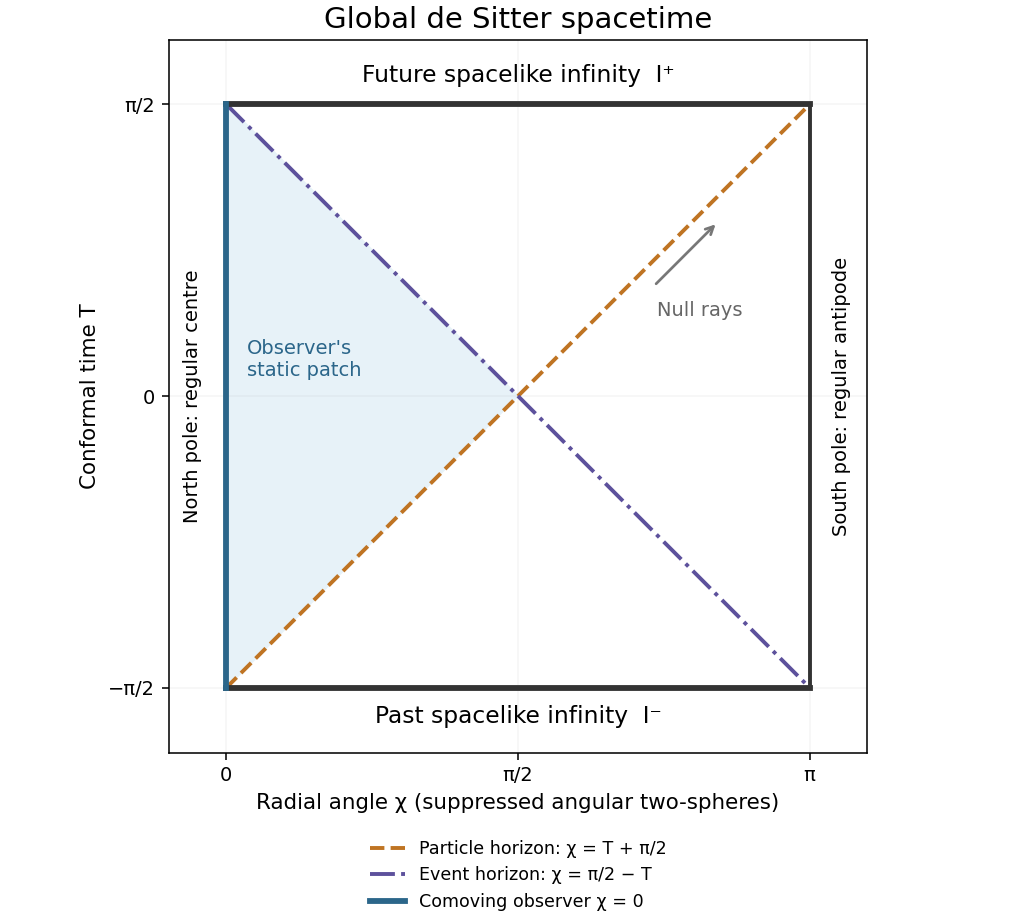
Radial null lines satisfy dχ=±dT, so the Penrose diagram is the square displayed below. Every interior point represents an angular two-sphere. Its top and bottom are the spacelike conformal infinities I+ and I− at T=π/2 and T=−π/2; they are excluded from the physical spacetime and are not curvature singularities. The vertical sides χ=0 and χ=π represent the regular north and south poles of the three-sphere, not spatial edges of the universe.
A particle horizon at an observer's current time bounds the comoving sources whose light could have reached that observer over the available past conformal interval. Here the cosmological past extends to t=−∞, but its conformal duration is finite. For acomoving observer at χ=0,
Since 0<χp<π at every finite time, aparticle horizon exists. The corresponding null boundary in the diagram is χ=T+π/2, emerging from the observer's past endpoint at I−. The antipodal point never has enough time to send asignal received at a finite proper time.
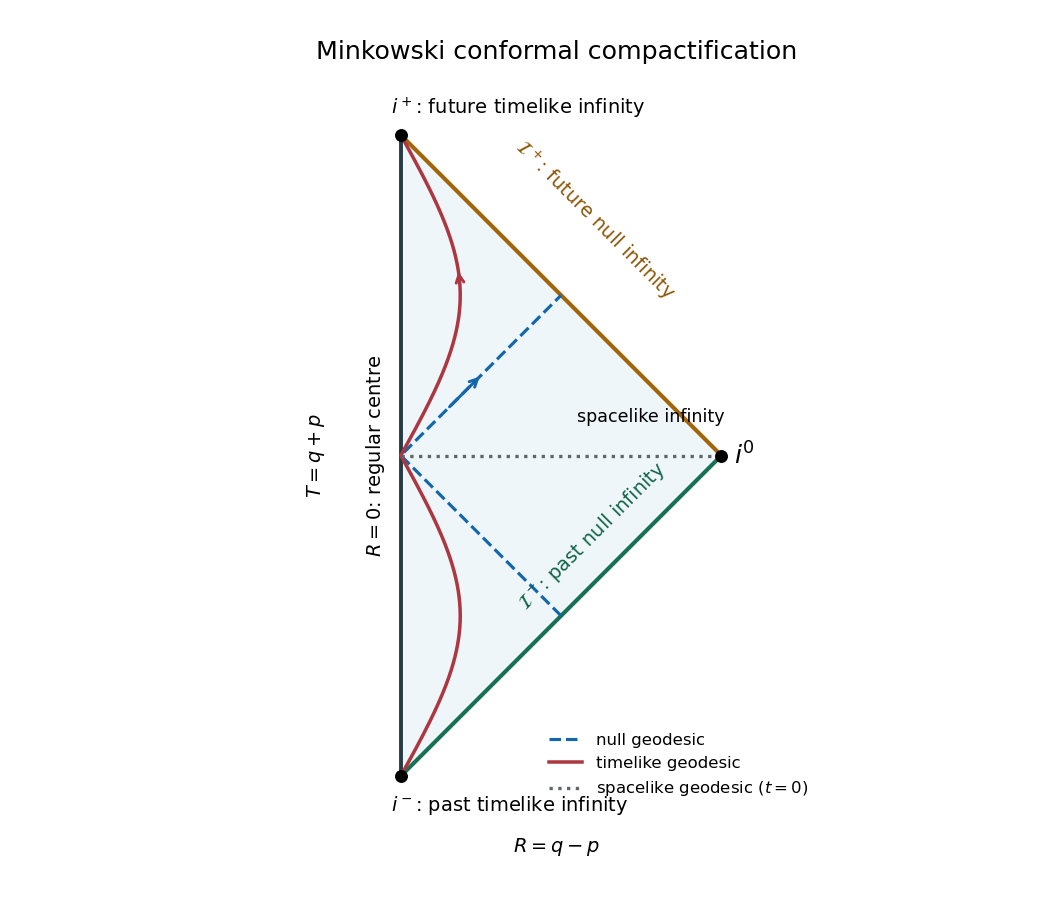
The polar angles have the usual coordinate degeneracies at their poles and at r=0. In the extended Einstein static universe one may let T∈R and 0≤R≤π, but these are not the ranges of the original physical patch. In its interior Ω>0. The line R=0 is the regular centre r=0, not a component of infinity.
There is also no black-hole event horizon, because every event can send a future-directed null ray to future null infinity. Nevertheless accelerated timelike observers can have both future and past observer event horizons. For an entire observer worldline γ, define them by Hγ+=∂I−(γ) and Hγ−=∂I+(γ), using its complete future and past respectively. An inertial observer'schronological past and future of the whole worldline are both all of Minkowski spacetime. By contrast, for the uniformly accelerated worldline in a Cartesian spatial direction,
For t>R, the solution therefore vanishes behind the inward edge ∣x∣=t−Ras well as outside ∣x∣=t+R. The absence of an interior tail is the additional content of the Strong Huygens principle.
Here n is the outward unit normal, ∂n the normal derivative, and ∇tan the component of the gradienttangent to the boundary. Since E(0)=0 and e≥0, we have E(s)=0. Hence both ϕt and ∇ϕ vanish inside the backward light cone. Integrating ϕt(s,x∗)=0 from the zero initial displacement gives ϕ(s,x∗)=0; continuity then gives ϕ(T,x∗)=0.
Applying the same energy estimate to the difference of two solutions proves the domain of dependence assertion. If dist(x∗,K)>T, the initial ball misses K, and the preceding argument proves the stated support bound. No disturbance propagates faster than one.