The wave equation is a second-order linear partial differential equation describing waves with finite propagation speed. In one spatial dimension its homogeneous, constant-coefficient form isHere is position, is time, is the disturbance, and subscripts denote partial derivatives. For a wave equation on a string, is transverse displacement; in linear acoustics, it can be a pressure perturbation. In several spatial dimensions, becomes the Laplacian . The same mathematical structure connects vibrating strings and acoustic waves, although their physical assumptions and wave speeds differ. [ref]
For the whole-line Cauchy problem, prescribe both displacement and velocity . A classical solution has continuous partial derivatives through order two; and suffice for D'Alembert's formula to produce one. A finite string additionally needs boundary conditions. These statements concern the unforced model with constant ; damping, spatially varying coefficients and nonlinear terms change the solution formula.
A travelling wave carries its entire profile to the right at wave speed ; travels left. Their sum is again a solution by the superposition principle. A standing wave instead has a fixed mode shape whose size and sign oscillate: in , each node of a standing wave stays stationary. The distinction is especially clear in the pulse and string diagrams below. For this ideal model, the dispersion relation is : each propagation branch is nondispersive, so a localized profile translates without spreading. This makes the equation a useful reference against which to understand wave dispersion and damping.
The appealing combination is local interaction with global predictability: neighbouring displacements determine acceleration through , yet D'Alembert's formula explicitly identifies exactly which initial locations can influence a later observation. Finite propagation speed turns that observation into a domain of dependence, rather than requiring knowledge of the entire initial string.
For with real , differentiation gives . This conserved Wronskian measures directed wave flux. In a one-dimensional ordinary plasma wave, the mean Poynting flux is in Gaussian units. It proves for a lossless two-channel scattering problem.
A string element has extra length . At fixed tension T, work done supplies elastic energy density . Transverse velocity supplies kinetic-energy density . For a single travelling profile with , the two densities agree pointwise. Their sum obeys a local energy balance with flux . Standing waves generally exchange kinetic and elastic energy instead of maintaining equality at every instant.
A physical sheet under uniform isotropic tension per unit length T and with mass per unit area has small transverse displacement satisfying , where . Fixed edges impose zero displacement. This mechanical membrane model neglects bending stiffness, large slopes and dissipation.
For a rectangle of sides a and b with fixed edges, separation of variables gives with positive integers p and q. Its angular frequency is . Zero integers produce the trivial displacement, not a lower mode. The p−1 and q−1 interior nodal lines divide alternating-sign lobes.
For a rectangular membrane mode with peak antinode displacement A, the integrals of each squared sine factor are half the corresponding side length. Integrating local kinetic energy density gives . The total energy is , and potential energy has the complementary cosine-squared factor. Its time-averaged kinetic energy is . At equal peak displacement, frequency and density, such mean energies are proportional to area.
A string of length with fixed endpoints, initially displaced into a triangular tent of height at its midpoint and released from rest, has a Fourier sine series with the coefficients in the title. Integrating the two linear halves gives , and symmetry cancels the even modes. Each coefficient evolves as under the wave equation. The displacement vanishes everywhere at , reverses sign at , and returns after . A straight configuration at an intermediate instant does not mean the string is at rest: its kinetic energy is then nonzero. The initial slope corner gives a finite-energy weak solution whose corner lines propagate and reflect at the ends.
A fixed circular elastic membrane of radius has radial normal modes satisfying the displayed Sturm-Liouville problem, with weight , and regularity at the origin. The regular solutions are Bessel functions of the first kind . Integration by parts gives the positive Rayleigh quotient . Distinct modes are orthogonal in the weighted inner product .
For a fixed circular elastic membrane, the Rayleigh-Ritz variational principle applied to , , gives . The numerator of its Rayleigh quotient is , and the denominator is . Minimization gives , , and the displayed upper bound for the ordinary frequency . Every has finite radial Dirichlet energy, which is the required variational admissibility condition.
A wave equation with a linear damping term and positive wave speed separates into spatial normal modes and damped harmonic oscillators. For a spatial eigenvalue , the time factor obeys . Its characteristic roots are . Thus underdamping requires , critical damping gives a repeated root and the second solution , and overdamping gives two real exponential rates. Negative amplifies rather than damps the motion.
For operator , define and . Retarded support, continuity at zero time and the derivative jump fix the displayed normalization. Imaginary produces a damped sine; zero gives . The spatially uniform mode tends to rather than decaying to zero.
At small wavenumber compared with , the slow decay rate of the damped wave operator is and the other root decays on time . Long-time, long-wavelength motion therefore approaches heat diffusion with the displayed diffusivity. The original hyperbolic equation nevertheless has finite signal speed , unlike the parabolic diffusion approximation.
For real constants , the substitution turns the displayed equation into the wave equation . If and , then and . For , D'Alembert's formula consequently givesThe extra term is necessary even when the original initial velocity is zero. For , take the limit to obtain . The formula gives classical solutions for suitably smooth data and weak solutions for less regular data. Positive damps the transformed wave, whereas negative amplifies it.
For with zero endpoint displacement, a Fourier sine series gives . With the Fourier transform convention, the causal inverse of this oscillator uses the displayed denominator. Its inverse transform is , giving when the past integral exists. The plain denominator requires a pole prescription: its Cauchy principal value gives the time-symmetric kernel instead. Homogeneous sine and cosine modes are additional freedom unless temporal data or causality are specified.
A strip of membrane with fixed edges supports transverse normal modes proportional to , . Separation of the two-dimensional wave equation gives the displayed dispersion relation. Confinement produces longitudinal wave dispersion even when the membrane's underlying wave speed is independent of frequency.
A fixed-edge membrane strip has dispersion , n≥1. Differentiating gives , whereas . Their product is . In this lossless scalar mode the integrated energy flux divided by energy density agrees with group speed. At cutoff the longitudinal group speed vanishes while formal phase speed diverges; an infinite phase speed therefore indicates no superfast energy transport.
For a plate under uniform tension per length , with surface mass density and flexural rigidity , the small-displacement equation is . If the edge conditions admit a transverse sine mode of wavenumber , its longitudinal dispersion relation isBending raises mode cutoff frequencies of a membrane waveguide and changes large- behaviour from to . A genuinely clamped plate also fixes the edge slope, so its transverse mode shapes need not remain simple sine functions. The qualitative increase in restoring force survives that change of boundary conditions.
The cutoff frequency of a membrane waveguide is the lowest frequency at which a specified transverse normal mode can propagate longitudinally. For fixed edges separated by , and . Below cutoff the longitudinal wavenumber is imaginary and a bounded excitation is an evanescent wave. Above it, and .
For a membrane waveguide branch , the exact cutoff has zero longitudinal wavevector and zero group velocity. It is not a traveling channel carrying finite longitudinal energy flux. Modes strictly below cutoff are evanescent; amplitudes of the permitted above-cutoff modes depend on the transverse excitation profile.
For the wave equation on , impose homogeneous Neumann boundary conditions , where . Separation of variables gives and . Integration by parts gives , so every nontrivial spatial eigenfunction has .
For , is constant and . For , the boundary conditions select and . The superposition principle gives the displayed expansion when the initial data have sufficient regularity. The constant zero mode must be retained: homogeneous Neumann boundary conditions do not force the spatial average of the displacement to vanish.
With zero initial velocity, all vanish, including . Initial displacement then evolves as , a standing wave above a constant offset.
For a spherically symmetric function, reduces the radial wave equation to . A time-harmonic separated solution has radial numerator , with . Finiteness at the origin excludes , and the prescribed finite origin value fixes . This is a standing combination of incoming and outgoing waves. A purely outgoing point-source wave instead has a singularity and must be specified by its source strength, not by a finite value at the origin.
This is the causal three-dimensional fundamental solution of . It concentrates on the outgoing sound cone and gives the retarded convolution of acoustic sources.
For with a homogeneous Dirichlet boundary condition, let be the first Dirichlet Laplacian eigenvalue. On a bounded one-dimensional interval, finite-energy displacement remains bounded for all time and all initial data exactly when . The conserved energy controls the gradient and, by the Poincaré inequality and one-dimensional integration, the maximum norm. At equality a mode can grow linearly; above it a mode can grow exponentially. Bounded oscillations need not have a long-time limit.
The vector field method commutes a wave equation with spacetime symmetry generators, estimates the resulting commuted wave energies, and converts weighted L2 norms to pointwise decay using a Klainerman-Sobolev inequality. The commutation vector fields for the wave equation include translations, rotations, Lorentz boost vector fields and the scaling vector field. It is useful for almost global existence for wave equations and for small-data global existence under the classical null condition for wave equations.
A commuted wave energy controls derivatives of a solution after applying the commutation vector fields for the wave equation. A convenient equivalent norm is . The wave energy estimate controls its growth through commuted sources, while the Klainerman-Sobolev inequality gives pointwise decay for low-order derivatives.
In three spatial dimensions, with the eleven translations, spatial rotations, boosts and scaling commutation vector fields for the wave equation, a sufficiently decaying smooth function satisfies . This weighted Sobolev inequality converts control of commuted wave energy into decay. It holds independently of any wave equation satisfied by .
A first-order vector field is a commutation field for the flat wave equation when is zero or a controlled multiple of . Translations, spatial rotations and Lorentz boost vector fields commute with ; the scaling vector field satisfies . Repeated commutation preserves the differential order of a semilinear wave equation.
The vector field generates simultaneous spacetime dilation. For the flat d'Alembert operator, . Consequently it commutes with the homogeneous wave equation at the level of its solution set, although its operator commutator is nonzero.
For Minkowski spacetime with unit light speed, generates a Lorentz boost. It commutes with the d'Alembert operator and controls derivatives transverse to time slices in the vector field method for wave equations.
The vector field is an infinitesimal spatial rotation. It commutes with the flat d'Alembert operator and supplies angular derivatives in the Klainerman-Sobolev inequality.
The vector fields and generate time and space translations and commute with the flat d'Alembert operator. They form the unweighted part of the commutation vector fields for the wave equation.
For a real scalar wave equation, the kinetic and gradient energy is . A potential term is added for a semilinear wave equation , giving the conserved wave energy .
For on , initially at rest with zero displacement, apply for and keep . A geometric series in the Laplace transform givesHere is the Heaviside step function, , and only finitely many terms contribute at any finite time. The second step in each pair is a sign-reversed reflection from the fixed endpoint. The formula solves the wave equation classically away from the fronts and distributionally across them; the midpoint is a square wave of period .
For the homogeneous one-dimensional wave equation with constant , wave speed means the speed at which a travelling wave profile translates. In , a feature initially at follows , giving signed velocity ; in it follows , giving signed velocity . The characteristic lines for the one-dimensional wave equation therefore have slopes . The speed of either profile is , even though the displacement at a fixed point can change sign or pass through zero.[ref]
The same bounds the causal cone for the constant-speed wave equation. For a wave equation on a string, depends on tension and linear mass density; for small acoustic waves in stationary uniform air it is the speed of sound. This interpretation assumes the stated ideal wave equation. In media with wave dispersion, phase velocity, group velocity and the earliest signal arrival have different meanings: a measured wave crest speed need not be the speed of a wave envelope, and neither alone establishes a causal cone for the constant-speed wave equation.
The experiment in A time of flight method to measure the speed of sound using a stereo sound card by Carlos C. Carvalho and others makes wave speed visible as a delay. Two powered microphones feed separate channels of one stereo line input. A clap beyond one end of their common axis reaches the nearer microphone first. The displayed signals show two separated onsets when enlarged; count their sample separation to obtain and infer speed of sound from the measured microphone spacing . The reported sampling rate is . Repeating at different spacings gives a distance-versus-delay plot whose slope estimates speed of sound; dependence on distance helps identify acoustic travel rather than a fixed electronic delay. These are the paper's apparatus and observed readout, not measurements made for this article.[ref]
A controlled implementation also needs timing calibration for acoustic speed measurements. Put the microphones side by side to estimate the channel-delay offset , swap channels to check its sign, and check the acquisition clock against an independent timing reference. Measure spacings between consistent points on the microphones, keep the source outside their span and on their axis, and fit by linear regression rather than forcing a zero intercept. Repeat pulses and compare the same onset criterion before reflections arrive. These are proposed calibration and control checks, not additional procedures claimed for the paper.
One sample corresponds to for the reported sampling rate, so a delay of only a few samples has large relative measurement error. Background measurement noise, different microphone responses and threshold choice can move the apparent onset; reflections can supply a later competing pulse. Record temperature, keep air motion small, and compare several spacings. The result estimates speed of sound under those conditions; it cannot prove an exactly zero precursor below the instrument's sensitivity or establish finite propagation speed for every real medium. Both new diagrams in these sections show explicitly synthetic ideal wave equation solutions.[ref]
Timing calibration for acoustic speed measurements separates travel delay from the offset between acquisition channels and checks the clock defining the sampling rate. A constant offset changes the intercept of a delay-versus-distance linear regression; a clock-scale error changes the inferred speed of sound itself.
A microphone is an acoustic transducer that converts an acoustic wave into an electrical signal. In an acoustic time-of-flight speed measurement, its response affects which recorded feature is identified as arrival.
The sampling rate is the number of recorded samples per unit time. A sample-index difference represents a delay when the acquisition clock is correctly calibrated.
Slowness is the reciprocal of phase velocity, measured in time per distance. A plane wave with wavevector and angular frequency has vector slowness . Its direction is the wavefront normal, which need not be the group velocity direction in an anisotropic medium.
In three spatial dimensions, the solution with initial position and velocity iswhere is the spherical mean.
Extend lower-dimensional data independently of an extra coordinate and apply the higher-dimensional wave equation solution. Projecting a three-dimensional sphere to the planar disk yields the kernel for the two-dimensional solution with zero initial displacement. This method of descent for the wave equation explains why three-dimensional wave propagation can depend on a sphere while two-dimensional propagation depends on its interior.
The strong Huygens principle says that the three-dimensional wave solution at depends only on initial data on the sphere . A compactly supported disturbance therefore leaves no tail in the interior of its light cone.
For the unforced, constant- one-dimensional wave equation, finite propagation speed says that changing Cauchy data outside cannot change the solution at , where and . This interval is the initial-data domain of dependence. Its endpoints are found by following the two characteristic lines for the one-dimensional wave equation backwards from the observation. D'Alembert's formula makes the dependence sharper: initial displacement is sampled at the endpoints, while initial velocity is integrated over the entire interval.[ref]
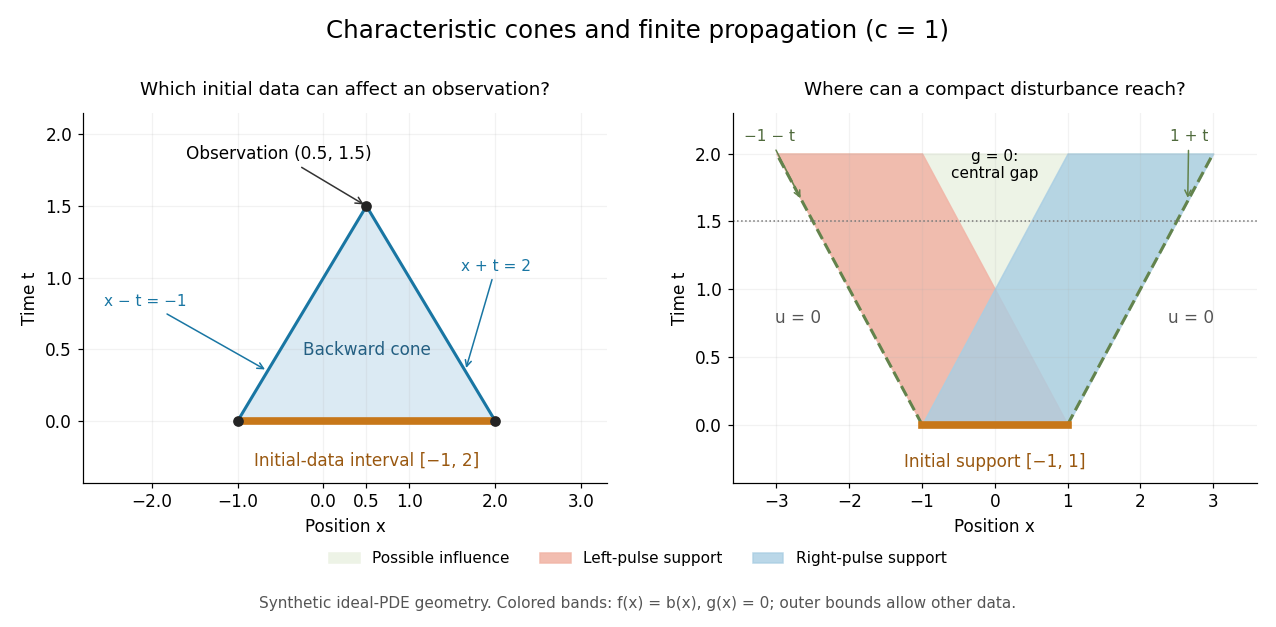
For the synthetic choice , has initial-data domain of dependence . A change confined near is irrelevant to that observation, however large it is. If both Cauchy data vanish outside , their compact support can influence only at . Thus an observer at sees exactly zero displacement for . There is no nonzero precursor beyond this causal cone for the constant-speed wave equation in the ideal model. This is an exact statement about the partial differential equation, stronger than an experimental failure to detect a small signal.
Support widening for the wave equation is a bound on possible influence, not a claim that every point inside the expanding interval moves. A bump function released with zero initial velocity splits into two separated travelling waves; the middle can become empty. An initial kick can instead leave an interior tail, as in the D'Alembert formula with initial velocity. Consequently finite propagation speed does not imply the Strong Huygens principle. A finite string needs boundary conditions, and the whole-line formula applies locally only until its backward causal cone for the constant-speed wave equation encounters an endpoint.
For , the backward causal cone at isIts boundaries are characteristic lines for the one-dimensional wave equation; its base on is the initial-data domain of dependence. The forward cone from is , . Here the cone is set by the model's wave speed, which may be acoustic or a string wave speed; it does not assert propagation at the speed of light.
For whole-line Cauchy data with support contained in , the displayed inclusion holds at . A short check uses D'Alembert's formula: if , both sampled endpoints and the whole interval of integration lie to the right of , so all contributions vanish; the argument for is identical. The inclusion can be strict, and a nonzero response at the first permitted arrival is not guaranteed.
The weak Huygens principle is the domain-of-dependence statement that initial data outside a backward light cone cannot influence its tip. It permits an interior tail and is weaker than the Strong Huygens principle. For with , integrating the local energy over shrinking balls proves this statement: the boundary contribution is .
For the homogeneous speed-one wave equation, integrate its wave energy density over . The moving boundary contributes , while the usual flux contributes . Their sum is . Zero Cauchy data in the initial ball therefore force zero solution in its backward light cone.
For Cauchy data prescribed on over , put . The maximal region determined solely by those data isIn the travel-time coordinate for a one-dimensional variable-speed wave equation this is the ordinary characteristic diamond , as follows from finite propagation speed.
A radiation field is the rescaled limit of a wave along null infinity. For a three-dimensional wave, the outgoing field is the limit of with fixed, while the incoming field fixes .
On the whole line, the homogeneous one-dimensional wave equation with constant wave speed isHere is displacement in the string interpretation; is initial displacement and is initial velocity. Its two directions of travel giveThis is D'Alembert's formula, including both Cauchy data. The countertravelling decomposition of the one-dimensional wave equation identifies as the right-moving travelling wave and as the left-moving travelling wave. Their sum is permitted by the superposition principle. For and , it is a classical solution. More generally, travelling waves with profiles and that are locally integrable functions solve the equation as distributions, with derivatives interpreted distributionally.[ref]
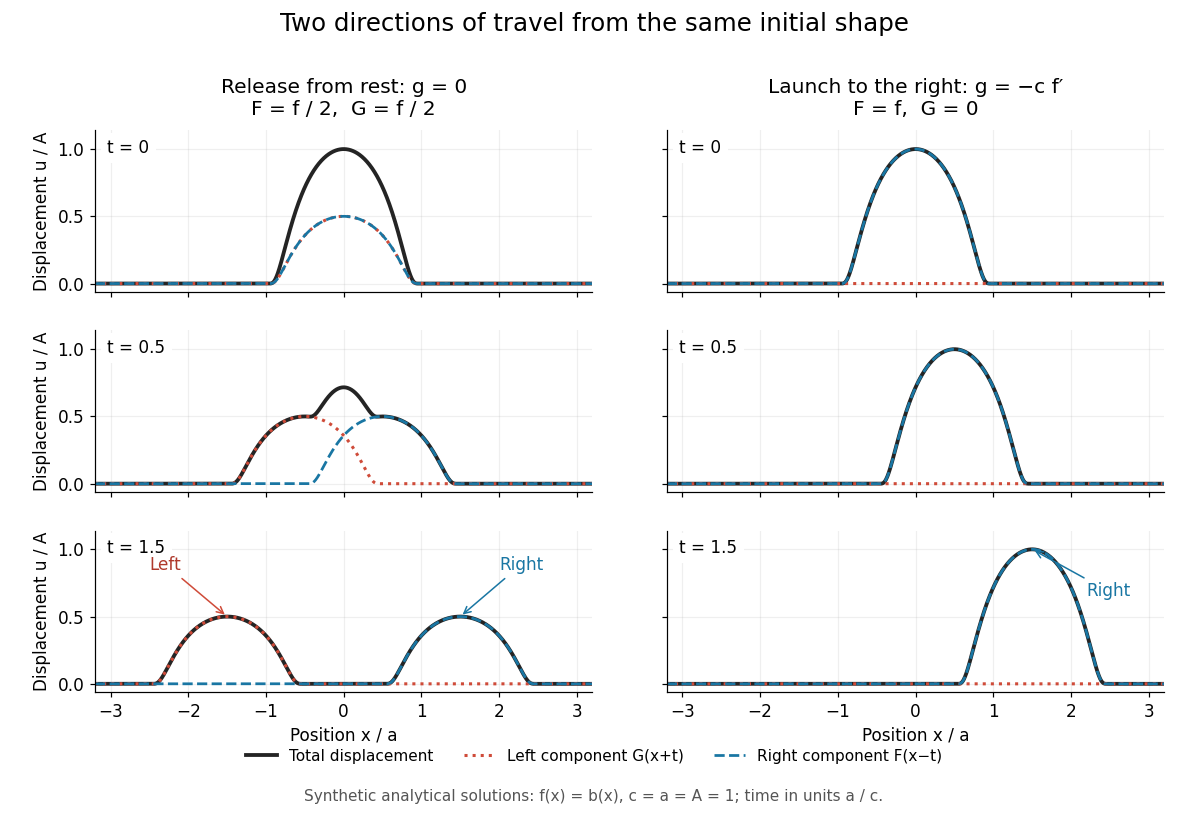
Synthetic pulse solutions: release from rest splits a profile, while matched initial velocity launches it rightward
. Details. The synthetic diagram uses the smooth bump function defined in D'Alembert's formula, with and . Releasing this displacement from rest, , gives . Each emerging travelling wave has half the original peak. Launching the identical initial displacement solely to the right instead requires and gives , . At , the released profiles have peaks at , while the launched profile has peak at . These are calculated model values. A purely left-moving launch requires . The initial velocity therefore selects the balance of directions; the initial shape alone does not.
For , zero response before the impulse gives the displayed retarded fundamental solution. Its initial displacement is zero and its initial velocity is . The response fills the interior of the forward causal cone for the constant-speed wave equation, rather than living only on its boundary. Changing the overall sign of the differential operator changes the Green function's sign. Equivalently, the spatial Fourier transform is , whose inverse is a rectangular profile. Values assigned exactly on the wave fronts do not change the associated distribution.
These characteristic curves are straight when wave speed is constant. A right-moving component is constant on , and a left-moving component on . The full superposition generally is not constant on either family, because the other component can vary along it. Their backwards intersections with the initial line select the endpoints used in D'Alembert's formula.
Let be any antiderivative of the initial velocity, . One choice of profiles isOpposite additive constants in and cancel, so the displacement is independent of the chosen antiderivative. Even for compact support of , these separate profiles can approach nonzero constants; cancellation in their sum is essential to support widening for the wave equation.
For a short derivation, the characteristic coordinates , give by the chain rule. Thus , and the Cauchy data imply and , giving the profiles above.
The d'Alembert operator is the Lorentzian wave operator in flat spacetime, or on scalar fields in curved spacetime.
A semilinear wave equation has the formso its highest-order part is linear while the forcing may depend nonlinearly on the solution and its lower derivatives.
A wave map is a harmonic map with Lorentzian domain: a critical point of the action obtained by contracting the pullback target metric with the domain Lorentzian metric. For target sphere in Euclidean space and , its extrinsic equation is , subject to . The derivative contractions are null forms for wave equations. Wave map Cauchy data must include a tangent initial velocity.
Smooth compatible data sufficiently small in high weighted Sobolev norms relative to a constant map produce global smooth wave maps in three and four spatial dimensions. In four dimensions, derivative decay is time-integrable and closes commuted wave energy estimates. In three dimensions the weaker decay requires the cancellation of null forms for wave equations, exploited by the vector field method for wave equations. These classical localized-data statements do not assert global regularity from small supercritical energy alone.
For smooth localized compatible wave map Cauchy data and compact Riemannian target, one-dimensional wave maps stay smooth globally. In null coordinates, the equation is . Compatibility of the target metric with the covariant derivative makes independent of and independent of . These transported derivative bounds and higher energy estimates prevent finite-time breakdown.
A time-independent wave map is a harmonic map of its spatial domain into the target. For target , its equation is . In two dimensions inverse stereographic projection gives a smooth nonconstant example of finite wave map energy .
The conserved energy of a wave map from Minkowski spacetime to a Riemannian target is , with norms measured in the target metric. Contraction of the wave map equation with the velocity and integration by parts gives conservation.
Under , the conserved wave map energy scales as . Energy is subcritical for , critical for , and supercritical for . The critical derivative index of the homogeneous Sobolev space is . Small energy alone is not an appropriate general small-data regularity hypothesis in supercritical dimensions.
Initial position for a wave map takes values in the target, and initial velocity belongs to its tangent space at . For this means and . Localized data agree with a constant map and zero velocity outside a compact set; the map itself need not be a compactly supported ambient function.
A quadratic derivative expression is a null form when its symbol vanishes on parallel null covectors. The Lorentz contraction is the basic example. Its cancellation suppresses interactions of derivatives pointing along the same light ray. It is the algebraic structure behind the classical null condition for wave equations.
For a quadratic derivative source , the classical null condition is whenever . It removes the leading interaction of parallel lightlike derivatives. In three dimensions this structure gives global smooth solutions for sufficiently small, localized data through the vector field method for wave equations. This PDE condition is distinct from the null condition asserting that a single vector is lightlike.
The focusing power wave equation is . Its conserved energy has the negative potential term and is not positive definite. Localized ordinary differential equation blowup for a wave equation produces smooth compactly supported data with finite maximal lifespan for suitable focusing powers.
A spatially constant blowup profile for a wave equation solves an ordinary differential equation. Choose smooth compactly supported initial data which agree with the profile on a ball larger than its blowup time times the wave speed. Finite propagation speed preserves agreement in an interior light cone, forcing finite-time breakdown of the localized solution. For , the profile is one example.
For a smooth semilinear wave equation whose nonlinearity is a smooth function of the solution and its first derivatives, local Sobolev space theory gives a continuation criterion: a finite maximal existence time requires divergence of a sufficiently high solution norm. A bounded base norm , with , allows restarting local existence. Higher regularity persists by differentiated energy estimates. Precise norms can be weakened for particular nonlinearities.
Almost global existence means a lifespan which grows exponentially in the inverse size of small initial data, typically for derivative-quadratic semilinear wave equations in three dimensions. Commuted wave energy and the Klainerman-Sobolev inequality lead to a logarithmic accumulation in a bootstrap argument. This implies existence up to every fixed inverse power when the data are small enough depending on .
For in three spatial dimensions, conserved positive wave energy controls . The Sobolev inequality gives . Differentiated wave energy estimates and the Gronwall inequality then give , where bounds the corresponding initial Sobolev norms.
Multiplying a defocusing wave equation by and integrating by parts gives a weighted spacetime identity. For a radial solution and radial weight, its coercive terms are
For a finite-energy defocusing power-wave solution in three dimensions,Hardy's inequality bounds the Morawetz action by the conserved energy.
For a radial function in three dimensions, setting removes the radial first derivative because . The defocusing power equation becomeson the half-line.
In three dimensions set for a radial function satisfying . If the source has support in and , the Duhamel principle bounds its contribution to by for . Its backward characteristic interval meets the source in a set of length at most one, and . Division by gives for compactly supported initial data.
Suppose the inhomogeneous linear wave equation has an energy estimate in a Banach solution space , and its nonlinearity obeystogether with the corresponding locally Lipschitz estimate. For a sufficiently large closed ball and sufficiently small , the map that solves the linear equation with source is a contraction. The contraction mapping theorem then gives a local weak solution.
An elastic wave propagates a disturbance through an elastic solid. Small displacements in linear elasticity satisfy a vector wave equation governed by mass density and the two Lamé parameters.
In an isotropic half-space with zero displacement at , an incident longitudinal wave directed along reflects into both longitudinal and shear waves. Let and . Horizontal phase matching gives for a reflected shear wavevector proportional to and polarization . The two zero-displacement equations at the boundary give the displayed coefficients. Since in a stable isotropic solid, both reflected branches are propagating for every genuine incident angle , with no critical-angle obstruction for this incident-wave type. Changing to a stress-free boundary changes the amplitude equations and coefficients.
For an isotropic elastic layer between two identical elastic half-spaces, an antiplane displacement has in the layer and exterior decay rate . Hence a trapped mode has phase speed between the layer and cladding shear speeds. Continuity of displacement and shear traction gives the first displayed equation for even modes and the second for odd modes .
In a rigid-cladding limit with nonzero decay rate, the interfaces become displacement nodes. Even transverse wavenumbers are , , and odd ones are , . The minimum even-mode dispersion branch is . When the cladding speed is finite, exterior decay remains a separate requirement; satisfying this lower cutoff alone is insufficient.
At a material interface, incident P or SV energy can scatter into both P and SV modes, subject to conserved horizontal slowness and traction/displacement conditions. SH is decoupled in a planar isotropic model; some conversions vanish at symmetry directions such as normal incidence.
A critically refracted wave associated with a faster lower layer that travels along an interface and radiates back into the slower upper layer. Its travel-time branch has the lower-layer horizontal slowness and a positive intercept time.
For a P ray incident from a layer of speed onto a faster layer , the transmitted ray is tangential when . Angles are measured from the interface normal.
In a two-layer P wave model, the head-wave branch overtakes the direct upper-layer arrival at . It differs from the smaller minimum offset needed for the critical-ray construction.
For small torsional displacement , the transmitted torque is . A slice of length receives net torque and has axial moment of inertia . Its angular equation therefore gives the displayed wave equation, with wave speed . The same geometric factor cancels from inertia and stiffness, making this ideal torsional speed independent of rod radius. This long-wave circular-rod model neglects additional elastic modes and dissipation.
The local elastic strain energy and rotational kinetic energy per length are and . Multiplying the torsional wave equation in a circular shaft by and integrating the product derivative gives . Thus the energy flux is torque times angular speed, with the sign set by the positive direction. The inequality follows from a square. A one-way travelling wave has ; a steadily rotating twisted shaft need not. Stored energy divided by transit time is not a separate bound for each energy component in a general superposition.
For a slender homogeneous circular shaft in small-amplitude linear elasticity, torque is and axial angular inertia per length is . Their common geometric factor cancels in the angular equation of motion, leaving the displayed wave equation. Here is the polar second moment of area, rather than the mass moment of inertia itself.
In a right-going simple wave, the state emitted at boundary time travels along . The mapping from emission time to position first becomes singular when , giving the displayed shock time and position . A smooth increase of traction produces steepening only if it increases the propagation speed. This describes the first gradient singularity; continuation as a shock wave needs admissible jump conditions.
For homogeneous stable linear elasticity, the three positive eigenvalues of the acoustic tensor give three phase velocities for each wavefront normal. Plotting the corresponding three vectors gives the three sheets of the elastic slowness surface. Sheets can meet at degeneracies. The elastic-wave energy flux is normal to each regular sheet: differentiating its eigenvalue equation along a sheet tangent gives .
Fix horizontal slowness and define , and . Under strong ellipticity in elasticity, is positive definite, so the vertical-slowness determinant has degree six with real coefficients. Real roots are intersections of a vertical line with the elastic slowness surface; complex-conjugate pairs give evanescent waves.
The unit-time elastic wave surface is the locus of group velocities on the three branches of a homogeneous elastic wave. At time , its scaled sheets describe the propagating wavefronts from an impulsive point source when that source excites the corresponding modes. Homogeneity of the dispersion relation gives , so each regular sheet is the envelope of planes . It is generally different from the radial reciprocal of the elastic slowness surface.
In a symmetry-plane cross-section, write , , and . The elastic wave surface is . Its derivative vanishes when , exactly an inflection point of the regular slowness surface. At a simple zero the second and third derivatives of are linearly independent, giving an ordinary cusp. Smooth nonconvex slowness surface sheets can therefore generate cusped wavefronts.
For a real branch polarization and complex displacement amplitude , the cycle averages are and . Differentiating the acoustic tensor eigenvalue equation with respect to gives their ratio as the group velocity. This identifies the energy flux direction with the normal to the elastic slowness surface in a lossless nondispersive elastic medium.
For a mode with positive downwards, the reduced traction is . Its mean vertical acoustic energy flux is the displayed expression. Propagating modes are downgoing for positive flux and upgoing for negative flux; phase-slowness sign need not agree in anisotropy. Depth-decaying evanescent modes have . At grazing or repeated roots use limiting radiation modes.
Select the three downgoing or depth-decaying elastic modes for a solid below a plane free surface. For each mode use its reduced traction column . Zero total boundary traction gives for an incident mode of reduced traction . Invertibility gives the displayed amplitudes. A singular matrix instead permits an outgoing homogeneous surface mode, so a radiation-limit or solvability analysis is necessary.
The causal Green function for isotropic linear elasticity is tensor-valued: column is the displacement caused by a point impulsive body force in direction . Its radiative terms are longitudinal P waves at and transverse S waves at , proportional to . A term supported between the arrivals carries the intermediate/near-field response. Convolution in time and space constructs the displacement for a general source.
In a homogeneous isotropic solid, the far-field P wave is the radial projection of the force and the S wave is its transverse projection. For a unit force axis , the magnitudes are and . The approximation requires distance large compared with both reduced wavelengths; angular nodes can still be controlled by a smaller near-field contribution.
Choose a surface normal from its minus to its plus side and jumps , . The equivalent force density is and the dipole density is . This follows by applying the elastic wave operator to a piecewise smooth displacement field: its distributional source is . Integration by parts against the elastodynamic Green tensor gives the displayed signs. At a material interface the dipole term is interpreted through the continuous reciprocal Green traction, rather than an undefined product of a discontinuous stiffness with a surface delta.
Integrating the equivalent dipole body force against the elastodynamic Green tensor by parts gives the displayed time convolution. For a fixed seismic moment tensor shape , its terms are . Derivatives of the angular projectors and the retarded near-field integral additionally produce and coefficients, yielding the final static field after the source stops.
A localized zero-resultant seismic moment tensor represents the leading force-dipole part of an elastic wave source through the displayed equivalent body force. For a prescribed displacement jump across a surface with normal , its moment density is , where is the elastic stiffness tensor. Spatial integration gives the point-source moment when the source is small compared with the wavelengths.
Articles were limited to the first 100 out of 366 total.
Articles by others on the same topic




As mentioned at: math.stackexchange.com/questions/579453/real-world-application-of-fourier-series/3729366#3729366 from solving partial differential equations with the Fourier series citing courses.maths.ox.ac.uk/node/view_material/1720, analogously to the heat equation, the wave linear equation can be be solved nicely with separation of variables.