Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Linear system of differential equations
Matrix trace Created 2026-09-24 Updated 2026-10-14
For an -by- square matrix over a field, its matrix trace is the sum of its diagonal entries:For example, has trace . Adding corresponding diagonal entries immediately proves linearity:Thus matrix trace is a linear functional on the vector space of -by- matrices.[ref]
Linear Algebra Done Right by Sheldon Axler (4th edition). Axler, Linear Algebra Done Right, fourth edition, §8D, definition 8.47 and result 8.56
The surprising point is that the sum is intrinsic to a linear operator, even though individual diagonal entries depend on the basis. The cyclic property of the trace gives, for any invertible matrix ,Hence matrix similarity preserves trace. For the example above, choose the change-of-basis matrix . ThenThe diagonal entries have changed but their sum has not. This makes trace useful for extracting a feature of the underlying linear operator without finding a preferred basis.
Over the complex numbers, or over the real numbers after allowing complex eigenvalues, the trace equals their sum with algebraic multiplicity:No diagonalizable matrix hypothesis is needed.[ref]
Linear Algebra Done Right by Sheldon Axler (4th edition). Axler, Linear Algebra Done Right, fourth edition, §8D, results 8.50–8.52
To see why, use triangularization over an algebraically closed field: an upper triangular matrix similar to has the eigenvalues on its diagonal, counted with algebraic multiplicity, because its characteristic polynomial is . Similarity preserves trace, so summing that diagonal proves the formula.For instance,There is only one independent eigenvector, since , so is not a diagonalizable matrix. Nevertheless its repeated eigenvalue contributes twice. For our earlier , the characteristic polynomial is , its eigenvalues are and , and their sum is . An inexpensive diagonal sum therefore gives spectral information before solving the characteristic polynomial.
The trace of a real matrix does not give that linear map's volume factor: that factor is the absolute value of its determinant. For example, has trace and area factor , but has trace and volume factor . Their occasional numerical agreement in two dimensions is a coincidence. The connection between trace and local volume change gives a geometric interpretation near the identity matrix, and describes the volume rate of a flow map generated by a linear system of differential equations.
Past exam of the mathematical methods I course of the University of Oxford 2013 12 a Solution 2026-10-25
The second equation gives . Differentiating it gives . Substitution into the first equation cancels the terms and the constant forcing, leaving . HenceThis has two independent constants, as expected for the first-order linear system of differential equations. At zero, the conditions give and . Thus the required particular solution isChecking directly, , while . This also verifies the signs introduced during elimination.
Past exam of the mathematical methods I course of the University of Oxford 2018 9 b Solution 2026-10-25
The linear system of differential equations has matrixThe columns of are eigenvectors of . The change of basis therefore gives , , with independent first-order linear differential equationsThe initial velocity gives , . Transforming back, , yields the real velocity vector componentsThese also cover . Complex coordinates have decoupled a real rotation without making the physical velocity complex.
Past exam of the mathematics course of the University of Cambridge 2001 ia Paper 2 7B Solution Created 2026-09-24 Updated 2026-10-14
Write , where has . One eigenpair isBecause is real, conjugating gives . The eigenvector matrix has determinant , so the eigenvectors form a basis. Reality of then forces conjugate coefficients, giving .
Set . The forcing has the same basis decomposition,Equating the coefficient of in the linear system of differential equations yieldsFor , an integrating factor gives . The zero initial vector means , soTaking the real vector combination givesExact secular resonance occurs at : the forcing frequency matches the undamped homogeneous mode. For positive , damping prevents secular growth, and the late-time periodic amplitude is proportional to . Thus there is a resonant small-damping limit, but no unbounded resonant response at fixed .
Past exam of the mathematics course of the University of Cambridge 2006 ia Paper 2 5B Solution Created 2026-09-24 Updated 2026-10-14
First solve the closed linear system of differential equations for . Its coefficient matrix is , with characteristic polynomial . Corresponding eigenvectors are and . The homogeneous solution is thereforeUse separate exponential particular solutions for the two forcing frequencies. Solving and gives and . HenceThe third equation then gives . Integrating,The three arbitrary constants span the general solution: two arise from the first-order subsystem and one from integrating .
Past exam of the mathematics course of the University of Cambridge 2012 ia Paper 2 7A Solution Created 2026-09-24 Updated 2026-10-07
Write the linear system of differential equations asA homogeneous power solves this Cauchy-Euler differential system precisely when . The eigenvalues are and , with eigenvectors and . The homogeneous solution is therefore .
For a particular solution, put . Then , which gives . At , the two initial conditions become and , so . ThusThe two powers correspond to the two eigenvalues; the lower-degree particular term accounts for the constant forcing. Substitution gives both original right sides and the zero initial data.
Past exam of the mathematics course of the University of Cambridge 2020 ia Paper 1 8A Solution Created 2026-09-24 Updated 2026-09-29
The first and third equations form a constant-coefficient linear system of differential equationsThe eigenvectors and have eigenvalues and . Applying the initial data givesThe remaining equation becomesAn integrating factor, or the usual exponential and trigonometric particular solutions, givesThese values satisfy all three initial conditions.
The linearized vortensity amplitude isSince the exact vortensity obeys and the time-dependent cancels the background shear in the phase, linearization gives
On the zero-vortensity branch,Substitution in the two momentum equations yields the linear system of differential equationswithwhere is the result from part (ii).
Trace and local volume change Created 2026-10-14 Updated 2026-10-20
For any fixed real -by- matrix , as the real parameter tends to zero,The big O notation means the remainder is bounded in absolute value by for some constant near zero. The determinant stays positive for sufficiently small , so its oriented volume factor is also its ordinary volume factor. Thus the trace is the first-order fractional volume change, measured from the identity matrix.
A proof follows directly from multilinearity of the determinant. Each column of is . The constant term chooses all the standard basis columns and equals one. A term containing exactly one factor replaces just column by ; expanding that vector in the standard basis leaves only its component, , because every other choice repeats a column. Summing gives . Terms with two or more replacements have order or higher. This also proves the derivative of the determinant at the identity matrix.
This coefficient has a direct visual meaning. At the point , the linear map has component along direction . In a small step , these are the first-order changes of the square's or box's sides in their own directions. Summing them gives its fractional area or volume change; the off-diagonal entries initially change shape rather than contributing to this first-order total.
For the constant-coefficient linear system of differential equations , the exact linear flow is , using the matrix exponential. Its volume factor isThis is the matrix exponential determinant identity. One can derive it without diagonalization: set , whose matrix inverse is , and use in Jacobi's formula to get . The scalar differential equation with initial value one gives the displayed exponential function. Thus positive trace causes volume expansion, negative trace causes contraction, and zero trace preserves volume, even when individual directions behave differently.
In two dimensions, compare four generators at :The first and third diagonal matrices expand or contract both directions. The second expands horizontally and contracts vertically by reciprocal factors, making a rectangle of unchanged area. For the last nilpotent matrix, , so its matrix exponential is exactly ; it sends to , a shear mapping. Zero trace allows substantial shape change and does not mean the flow map is stationary.
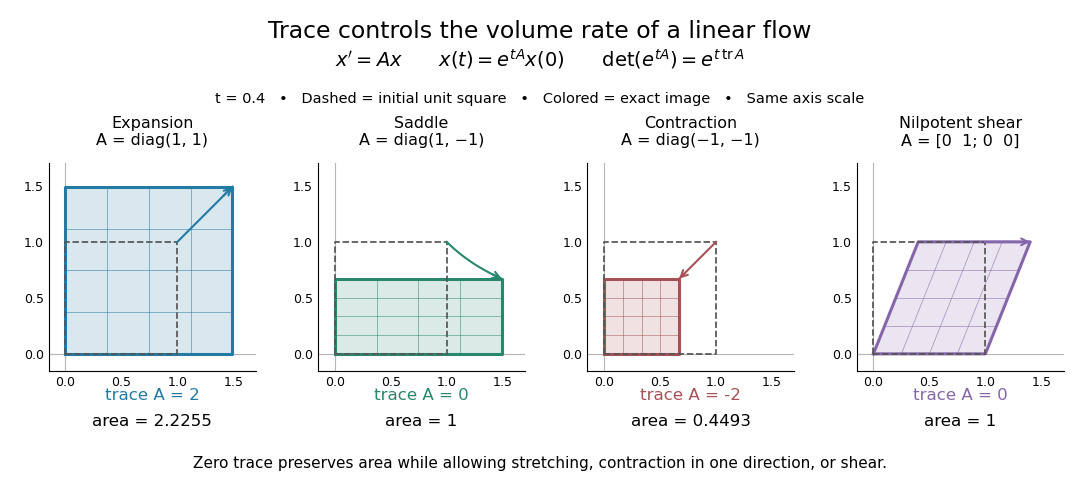
Four examples of a linear system of differential equations: trace controls area change while a saddle and a shear mapping preserve area
. Details. 
The first-order statement and the exact flow map should be distinguished. For , , whereas for all real . Zero trace eliminates the first-order change in the approximate step, and it preserves volume exactly in the matrix exponential flow. The examples use an abstract parameter and coordinate vectors; no physical units are assumed.