The classification of compact surfaces says that every compact connected surface without boundary is homeomorphic either to the sphere with handles, with Euler characteristic , or to a connected sum of real projective planes, with Euler characteristic . The first family is orientable and the second is nonorientable; the displayed invariants uniquely determine the type. With boundary one additionally removes a uniquely determined number of open disks.
Number the vertices of the fourteen-gon in boundary order. The printed edge identifications implyThus there is one vertex, seven edges and one face in the quotient. ConsequentlyThe two occurrences of have the same sign, as do those of , so the orientation on the polygon cannot extend consistently across those paired edges. Thus the surface is nonorientable, and classification identifies it as a connected sum of seven projective planes. The inverse on the first occurrence of and the positive second occurrence have been retained in the vertex calculation.
A Riemann surface is a connected Hausdorff second-countable space equipped with complex coordinate charts whose changes of coordinate are holomorphic with holomorphic inverses. Such charts give it the structure of a one-dimensional complex manifold.
A holomorphic change of coordinate has nonzero derivative. In real coordinates its derivative matrix has determinant by the Cauchy-Riemann equations. Thus every overlap preserves the standard orientation of the complex plane. These chart orientations fit together, proving every Riemann surface is orientable.
For a regular parametrization choose the unit normal . The first fundamental form is the squared length induced on tangent vectors:The second fundamental form records their normal bending:The Gaussian curvature isRegularity ensures .
Expanding the characteristic determinant givesThe product and sum of its two roots therefore giveReversing the normal changes both principal curvatures and the mean curvature in sign, while leaving their product unchanged.
For the ruled surface, , so . AlsoThusThe denominator is positive at every regular point, proving that zero Gaussian curvature is equivalent to the vanishing of the stated scalar triple product. In particular the Gaussian curvature of a regular ruled surface is always nonpositive.
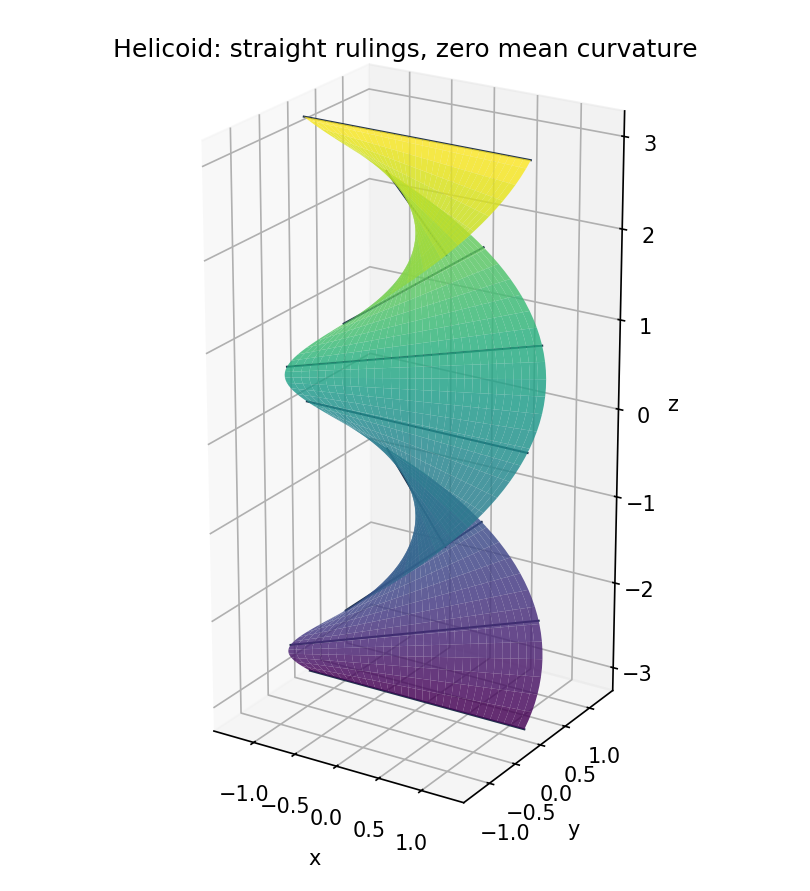
For the helicoid,Hence , , . Since and , both and vanish. The mean-curvature formula therefore givesFor comparison, , so ; zero mean curvature does not mean zero Gaussian curvature.

For the unit-speed curve, the normal curvature is , and the geodesic curvature is . Differentiating twice and taking the normal component kills the terms in , givingAn affinely parametrized geodesic has zero tangential acceleration, or equivalently its covariant derivative of velocity is zero. For unit speed, , and form an orthonormal frame. Therefore , so zero tangential acceleration is exactly .
Since , differentiation givesThe corresponding calculation with givesThus the two requested equations hold exactly when is perpendicular to both tangent basis vectors, which is precisely the geodesic condition.
On expanding the left sides, the coefficient matrix of is the positive-definite metric matrix. It is invertible, so the equations form a smooth second-order ordinary differential equation in local coordinates. The local existence and uniqueness theorem gives a unique solution for each initial point and coordinate velocity. For an arbitrary initial tangent vector this is an affine parameter of constant speed ; it is arclength when . For the solution is the constant curve. This specifies how the arbitrary-velocity statement relates to the preceding unit-speed convention.
Let be reflection in the plane. Choose a point of the regular intersection curve and a unit tangent vector to it. Both the point and are fixed by . The unique local geodesic with these initial data is carried by the surface isometry to another geodesic with the same initial data. Uniqueness therefore gives . Its image lies in the fixed-point set of the reflection, namely the plane, hence locally in the intersection curve. Thus the intersection curve is a geodesic, when parametrized by arclength.
For a positively oriented curvilinear polygon bounding a disk in one coordinate patch, with exterior turning angles , the Gauss-Bonnet theorem statesFor a closed compact surface the global formula isTriangulate the surface with each triangle contained in a coordinate patch. For each face, writing its exterior angles as minus its interior angles gives . On summing, the two contributions on each internal edge cancel, and all angles at each vertex sum to . Thus . Since , this equals , as required. For a nonorientable surface apply the orientable version to its orientation double cover: both the curvature integral and Euler characteristic double. With boundary, the same summation retains the boundary geodesic-curvature integral and the exterior angles at boundary corners, giving the corresponding global boundary formula with right side .
For the sphere, choose the inward normal so that the second fundamental form is . Both principal curvatures are , giving ; the outward choice reverses both signs and gives the same product.
The octant has area , so its curvature integral is . Its sides are great-circle geodesics, hence have zero geodesic curvature. Each interior angle is , so each exterior angle is also . Thereforeverifying the polygon formula directly.
If two distinct geodesic arcs enclosed a disk, regard its boundary as a curvilinear two-sided polygon, with interior angles . These are positive; zero angle would make the arcs tangent and local geodesic uniqueness would make them coincide. The geodesic-curvature terms vanish, so Gauss-Bonnet givesThis contradicts . Thus no such disk-bounding geodesic bigon exists. The disk hypothesis matters because it fixes the Euler characteristic on the right side.
Articles by others on the same topic
There are currently no matching articles.