For an embedded submanifold of a Riemannian manifold, the vector-valued second fundamental form isHere is the ambient Levi-Civita connection and the superscript denotes projection onto the normal bundle. For a hypersurface in Euclidean space with unit normal , the scalar form is . In a surface parametrization its coefficients are , , and .
At every point its second fundamental form is a scalar multiple of its induced metric. Equivalently its shape operator is scalar, so all principal normal curvatures agree. For a three-dimensional hypersurface, and . The sign of its intrinsic scalar in a vacuum Lorentzian ambient space then follows from the Gauss equation for a nonnull hypersurface.
For a timelike unit normal with squared norm epsilon and vanishing ambient Ricci tensor, contraction of the Gauss equation for a nonnull hypersurface gives the displayed formula. In signature the timelike normal has epsilon plus one, so the scalar of the induced negative-definite metric is nonnegative. In signature the positive-definite spatial metric instead has scalar . Replacing the induced metric by its negative reverses the scalar, so the inequality must not be transferred between these conventions without adjustment.
// Target: general-relativity.bigb
Differentiate the orthogonality of the unit normal to the two independent coordinate tangent vectors. If the second fundamental form vanishes, each derivative of the normal is orthogonal to both tangent vectors; differentiating its unit length also makes it orthogonal to the normal. Thus both normal derivatives vanish. On a connected parameter domain the normal is constant, and differentiating the position's scalar product with that constant normal proves the surface lies in a plane.
Rotate an ellipse with positive semiaxes about an axis a distance from its centre. For the parametrized surface , put and . An outward unit normal is . Direct differentiation gives the first fundamental form and second fundamental form, with the convention :Reversing the unit normal reverses , but the Gaussian curvature is unchanged.
For major radius and minor radius , let . With the inward normal determined by the usual ordered parametrization, the first fundamental form and second fundamental form areReversing the normal reverses . The Gaussian curvature of a ring torus is independent of this orientation.
For a ring torus of radii , the Gaussian curvature isIt is positive on the outer side, negative on the inner side and zero on the top and bottom circles. The sign contrast expresses two principal curvatures of the same sign outside and opposite signs inside.
The Gauss–Codazzi equations relate the intrinsic curvature and connection of an embedded submanifold to its second fundamental form and the ambient curvature. The Gauss equation controls tangential curvature; the Codazzi equation controls the covariant derivative of the second fundamental form. The Gauss formula is the tangential-normal splitting used to derive these relations.
For a hypersurface with unit normal vector , put , , and for tangent vectors. The induced metric is nondegenerate precisely when the normal is non-null. With and , the Gauss formula is . Substituting twice into the ambient Riemann curvature tensor and projecting tangentially gives the displayed Gauss equation. Its normal projection gives , the curved-ambient Codazzi equation. A null hypersurface needs additional geometric data because its induced metric is degenerate.
For a submanifold with induced Levi-Civita connection and second fundamental form , the ambient derivative decomposes asFor a parametrized surface this reads .
For a Euclidean embedded submanifold,It expresses intrinsic curvature in terms of the second fundamental form.
For an embedded submanifold of a Riemannian manifold, use . The Gauss formula and tangential derivative of a normal field giveSubtract the expression with interchanged and the bracket derivative, whose normal part pairs to zero. This proves the displayed curvature identity. For flat Euclidean ambient space, its ambient curvature term vanishes and one obtains the ordinary Gauss equation. Declaring the four-slot convention avoids sign ambiguities when permuting arguments.
Let the unit normal satisfy , let , and set . The normal component of an ambient derivative of tangent fields is . Substitute that decomposition into the curvature commutator and project tangentially to obtain the displayed equation. Its scalar contraction is . Both metric signature and curvature-slot convention must be specified when assigning a sign.
Here , the negative of the convention in the ordinary Gauss equation in a curved ambient manifold. Insert the Gauss formula and Weingarten formula into this definition and project tangentially to obtain the displayed identity. Positive sectional curvature uses with this convention. Thus a Euclidean surface still has Gaussian curvature ; reversing the operator sign without changing the slot order would give the wrong sign.
A surface locally swept out by ambient geodesics has in its unit ruling direction . For a perpendicular unit tangent , the Gauss equation in a curved ambient manifold therefore gives the displayed identity. Its Gaussian curvature is at most the ambient sectional curvature in its tangent plane, with equality precisely when . An independent variation argument applies the Jacobi field equation to the length of a perpendicular connecting field; its ambient derivative has the extra normal component . The Euclidean surface is ruled by straight lines and has Gaussian curvature .
An -dimensional Riemannian manifold is locally maximally symmetric if its local Killing vector fields attain the dimension bound for Killing vector fields . This is equivalent to constant sectional curvature. Positive, zero and negative sectional curvature give local spherical geometry, Euclidean geometry and hyperbolic geometry, respectively. Global identifications can reduce the number of globally defined isometries without changing this local property. The spatial slices of an FLRW metric have this property.
A space with nonzero constant sectional curvature has curvature radius of a constant-curvature space . Scaling a metric tensor by divides its sectional curvature by . In an FLRW metric whose spatial normalization is , the spatial curvature of an FLRW universe is , so its scale factor equals . For there is no finite intrinsic curvature length.
Ricci curvature is the trace of the Riemann curvature tensor in its first and third arguments. For a unit tangent vector and an orthonormal basis ,
For a complete connected -dimensional Riemannian manifold with nonnegative Ricci curvature, the displayed ratio is nonincreasing, tends to one at zero, and is at most one. In particular . In geodesic polar coordinates, the radial Jacobi field determinant is at most the Euclidean density until the cut time. The trace of the radial Riccati equation for distance spheres, with Cauchy-Schwarz inequality, proves this comparison. Equality for every radius forces the Euclidean polar metric and absence of a cut locus.
For a complete connected -dimensional Riemannian manifold with , , put andHere is the area of the unit -sphere, and is the Riemannian volume of a radius- ball in the round curvature- sphere. The Bishop-Gromov inequality asserts that is nonincreasing for , tends to one at zero, and is at most one. In geodesic polar coordinates, the radial volume density before the cut time is at most . The bound uses trace Ricci curvature; with normalized Ricci curvature it reads .
Under the hypotheses of Bishop volume comparison with a positive-curvature model, the Bonnet-Myers theorem gives diameter at most . If total Riemannian volume equals , every comparison ball ratio is one. In a small normal ball the pointwise radial density bound therefore becomes equality. Writing , the traced radial Riccati equation for distance spheres and Cauchy-Schwarz inequality force the radial operator to equal . The angular metric is consequently , so the metric is locally round. The classification of complete positive constant-curvature manifolds gives a quotient , whose volume is . Equality forces trivial.
Assume the trace Ricci curvature satisfies , with . If points have Riemannian distance , the balls and are disjoint. Bishop volume comparison with a positive-curvature model bounds their volumes below by and . Since , both inequalities must be equalities. Taking gives , and spherical rigidity of maximal total volume yields the round sphere.
The Bishop-Gromov inequality forces every volume ratio to equal one if the asymptotic ratio is one. Equality in the radial Jacobian comparison forces the radial operator of each distance sphere to be (it is the negative of the outward shape operator in the convention ), by the traced radial Riccati equation for distance spheres and equality in Cauchy-Schwarz inequality. Any finite cut time would remove a positive cone of radial volume at a later radius, contradicting equality. Thus the Riemannian exponential map is global and one-to-one, and the polar metric is , the Euclidean metric.
For a Riemannian manifold of dimension , the normalized directional Ricci curvature averages, rather than sums, the sectional curvatures through a unit vector. Thus the Bonnet-Myers theorem gives from . With trace Ricci curvature the corresponding hypothesis is . The distinction changes positive constants but not the signs of Ricci curvature.
At a point of a Riemannian manifold, Ricci curvature is isotropic when is independent of nonzero tangent direction. Polarization makes this equivalent to the displayed tensor identity. In dimension three, sectional curvatures from Ricci curvature in dimension three gives every sectional curvature at that point the value . In higher dimensions isotropic Ricci curvature does not determine every two-plane curvature.
An Einstein manifold has Ricci curvature equal to a constant multiple of its metric. In the Riemannian setting, the round unit sphere has . This condition is weaker than constant sectional curvature in higher dimensions. The definition can also be applied to pseudo-Riemannian metrics, but positivity is assumed in the completeness theorems discussed here.
A Riemannian or pseudo-Riemannian metric is Einstein when its Ricci tensor is a constant scalar multiple of the metric. Constant-sectional-curvature metrics satisfy this condition with . The Killing-form metric on a real semisimple Lie group is another example, with for in the curvature convention .
The product Riemannian metric of two round unit spheres has Ricci curvature equal to its metric, since the factor Ricci tensors equal their metrics and the product connection splits. Its directional Ricci curvatures are all one. A two-plane tangent to a single sphere has sectional curvature one, while a mixed plane has sectional curvature zero. This four-dimensional Einstein manifold therefore need not have constant sectional curvature.
For an orthonormal triple and distinct , tracing sectional curvature gives . Solving the three equations gives the displayed formula. Equivalently . This pointwise assertion does not require the triple to diagonalize the Ricci curvature.
Scalar curvature is the complete trace of the Riemann curvature tensor:An -manifold of constant sectional curvature has .
The product Riemannian metric of the round unit two-sphere and a circle has Ricci curvature equal to on the sphere directions and zero on the circle direction. Its scalar curvature is constantly two, but no single scalar multiple of the whole metric equals that Ricci tensor. In two dimensions the identity does make constant scalar curvature equivalent to an Einstein metric.
A Ricci-flat Riemannian manifold has identically zero Ricci tensor. Every flat Riemannian manifold is Ricci-flat, while the converse can fail in dimension at least four.
For a connected Riemannian manifold of dimension , assume geodesic completeness and for a constant . The Riemannian distance then has diameter at most ; the manifold is compact and its fundamental group is finite. The dimension restriction excludes the vacuous one-dimensional Ricci bound.
The graph in Euclidean three-space has the displayed induced Riemannian metric and positive Gaussian curvature. It is smooth at its vertex; the polar-coordinate singularity is only a coordinate artifact. The metric dominates the Euclidean plane metric, so upward stability of Riemannian completeness proves completeness. It has infinite diameter. In dimension two Ricci curvature equals Gaussian curvature times the metric, so this is a counterexample to compactness under merely pointwise positive Ricci curvature. Its curvature tends to zero at infinity.
If a connected complete Riemannian manifold has with , its universal cover with the lifted metric is complete and satisfies the same bound. The Bonnet-Myers theorem makes that cover compact. A covering fiber is closed and discrete and hence finite; the number of its elements equals the order of the fundamental group. Applying the diameter theorem only to the base would not prove this conclusion: the positive lower bound must also be used on the cover.
This metric pulls back the round spherical metric by . It has unit Gaussian curvature and Ricci curvature equal to its metric, yet the meridian reaches a missing boundary in finite time. Every curve between and has length at least , so its diameter is infinite. It shows that the positive Ricci bound alone does not replace geodesic completeness in the Bonnet-Myers theorem.
This is a Riemannian splitting theorem whose hypotheses include a globally minimizing geodesic line.
A complete connected Riemannian manifold with nonnegative Ricci curvature that contains a line splits isometrically as .
If a connected closed manifold has a noncontractible universal cover, then has no complete metric making it a Ricci-flat Riemannian manifold. The product has two ends and hence contains a line in a Riemannian manifold for any complete metric. The Cheeger-Gromoll splitting theorem would split it isometrically as . Its three-dimensional factor is Ricci-flat and therefore flat by three-dimensional curvature from the Ricci tensor. The complete simply connected cover of the product would be Euclidean four-space. But that cover is , which retracts onto , contradicting noncontractibility.
A Riemannian manifold is flat when every sectional curvature is zero. A complete simply connected flat -manifold is isometric to Euclidean space .
On a compact flat Riemannian manifold, the integrated Bochner identity for Killing vector fields makes every Killing vector field parallel. Parallel vector fields are exactly the fixed vectors of the linear holonomy. Thus the six orientable closed flat three-manifold types have identity-component isometry dimensions three for the torus, one for each cyclic nontrivial holonomy, and zero for the Hantzsche-Wendt manifold.
For a compact flat Riemannian manifold , the translations in form a normal full-rank Euclidean lattice of finite index. The quotient is its finite linear holonomy. Affine conjugacy of the torsion-free crystallographic groups classifies these manifolds up to affine diffeomorphism. An abelian must consist entirely of translations: commuting with every lattice translation forces each linear part to fix a spanning set of .
These are precisely the faithful linear holonomy groups of closed orientable Euclidean three-manifolds. Cyclic cases arise from planar lattice rotations combined with axial screw translations. The noncyclic case is generated by two perpendicular half-turn screws. The list refers to the maximal translation lattice, not to arbitrary finite quotients of a fundamental group.
The closed orientable flat Riemannian manifold with holonomy can be presented by Euclidean screws and . Their squares and the square of their product generate the unit translation lattice. Each nonidentity holonomy coset has a half-integer displacement along its fixed axis, so acts freely. The holonomy has no common fixed vector, giving first Betti number zero and a finite isometry group for every flat metric.
The mapping torus of an order-six rotation of a hexagonal flat torus is a closed orientable flat Riemannian manifold with holonomy . The screw rotation has angle and axial displacement . Its first Betti number is one.
The mapping torus of an order-three rotation of a hexagonal flat torus is a closed orientable flat Riemannian manifold with holonomy . A screw rotation through with axial displacement , together with the planar lattice, describes its deck group. Its first Betti number is one.
This closed flat Riemannian manifold is the mapping torus of on a two-dimensional flat torus. Equivalently, take planar lattice translations and the screw in Euclidean three-space. Its square is a unit axial translation, its holonomy is , and its first Betti number is one.
The Euclidean transformations , and generate a torsion-free cocompact group with , and equal to unit translation along . Every nontranslation has nonzero axial displacement modulo integers, hence no fixed point. Its maximal translation subgroup is and its holonomy is .
A flat torus is with its quotient Euclidean metric, where is a full-rank Euclidean lattice. Its volume is the lattice covolume. The dual lattice indexes its complete Fourier series of Laplacian eigenfunctions.
Let be full-rank Euclidean lattices, and choose smaller than every nonzero vector length in either. The shortest vectors of are exactly the new coordinate vectors and their negatives. Any isometry between the associated flat tori lifts to an affine Euclidean isometry, whose orthogonal part maps the lattices. It must preserve the span of the shortest vectors, hence also its orthogonal complement, and therefore maps to . Consequently a nonisometric pair remains nonisometric after adding sufficiently short equal circle factors. The spectrum of a flat torus shows that adding the same factors preserves isospectral manifolds.
With the nonnegative Laplace-Beltrami operator, a frequency in the dual lattice gives the eigenfunction and eigenvalue . Its multiplicity is the number of dual vectors with that norm. Fourier series prove completeness. In dimension two the shortest vector, shortest independent vector and covolume determine a reduced Gram matrix, proving spectral rigidity.
The vector-length multiset of a rank-two Euclidean lattice determines it up to an orthogonal map. Let be the shortest nonzero length. Removing two copies of each positive integer multiple of removes one primitive lattice line; the shortest remaining length is the shortest independent-vector length. Those two vectors form a lattice basis: otherwise a nonzero point in the centred basis parallelogram would be an independent lattice vector of length less than . Lattice-point density determines the covolume . The basis Gram matrix then has diagonal entries and absolute off-diagonal entry . This proves two-dimensional spectral rigidity for a flat torus through its dual lattice.
On a complete connected Riemannian manifold of nonpositive sectional curvature, the exponential map at every point is a covering map. If the manifold is simply connected, each exponential map is a diffeomorphism from a tangent space onto the manifold.
With outward normal , the unit sphere has . The Gauss equation therefore gives sectional curvature one on every tangent two-plane.
For a Euclidean embedded submanifold, the covariant derivative of the second fundamental form satisfies
For the ambient Levi-Civita connection, a normal field , and tangent fields , differentiate using metric compatibility. The tangential part of is orthogonal to , giving the displayed identity. It controls how an ambient derivative of a normal vector can develop a tangential component, and is the vector-valued version of the shape operator relation.
For a nondegenerate induced metric tensor, a totally geodesic submanifold has vanishing second fundamental form; equivalently, every ambient geodesic initially tangent to it remains in it. This extends the notion of a totally geodesic hypersurface to arbitrary codimension.
A smooth nondegenerate component of the fixed-point set of an isometry is a totally geodesic submanifold. If a geodesic starts tangent to the fixed component, its image under the isometry has identical position and tangent. Uniqueness of the geodesic equation makes the two geodesics coincide throughout their common domain, so the original geodesic stays in the fixed set.
The normal curvature of an oriented surface in a unit tangent direction isIt equals the normal component of the acceleration of any unit-speed surface curve tangent to .
If a unit tangent makes angle with the first principal direction, the normal curvature is . This follows by diagonalizing the second fundamental form relative to the first fundamental form. When the Gaussian curvature is nonnegative, .
For directions spaced in the same rotational sense, Euler formula for normal curvature gives . The sum of the equally spaced complex exponentials is zero when , proving the formula. Consecutive unsigned angles alone do not imply this arrangement: they permit directions to double back.
The second fundamental form of an embedded submanifold of a Riemannian manifold is symmetric. Its ambient Levi-Civita connection is a torsion-free connection, soThe Lie bracket of vector fields tangent to the submanifold is tangent and therefore has zero normal component. This proof applies to a curved ambient manifold as well as Euclidean space.
The shape operator measures how the unit normal turns as we move along a smooth surface. A plane has a constant unit normal, whereas the outward unit normal of a sphere turns in every direction in the tangent plane. Keeping the direction of this change, rather than just its magnitude, lets one recover the principal curvatures and their principal directions.
Choose an orientation of a surface , with Gauss map . The shape operator at is the linear mapHere is the differential of the Gauss map. Its output belongs to , identified with because both are the vector plane perpendicular to . The minus sign is our convention throughout this branch. [ref]
https://ghomi.math.gatech.edu/Classes/Math497C/LectureNotes9.pdf. Ghomi, Lecture Notes 9, §2.2: Gauss map and shape operator
The shape operator packages the second fundamental form as an operator using the inner product supplied by the first fundamental form:The symmetry of the second fundamental form makes the shape operator a self-adjoint operator for this inner product. Thus an orthonormal basis of principal directions diagonalizes it. In a coordinate basis of a parametric surface, writeThe matrix need not be a symmetric matrix in this coordinate basis: its self-adjointness means . Using the eigenvalues of alone gives the principal curvatures only when is the identity matrix. [ref]
For a worked example, parametrize the lateral surface of an outward-oriented circular cylinder of radius using circumferential arc length and axial coordinate :The coordinate tangent vectors are an orthonormal basis. Since and , the shape operator satisfiesChanging to angular coordinate gives and ; still has eigenvalues . This is why the first fundamental form must participate in the calculation.
For a sphere of radius centered at the origin, the outward unit normal is . Hence , so both principal curvatures are . For a plane, and the shape operator vanishes. Reversing the unit normal negates the shape operator and both principal curvatures; the Gaussian curvature remains unchanged while the mean curvature changes sign, as in orientation reversal of surface curvature.
For a normal vector , this identity defines the corresponding shape operator using the vector-valued second fundamental form. It is self-adjoint because of the symmetry of the second fundamental form. Differentiating shows that . In higher codimension there is a different operator for each normal direction.
The Weingarten formula decomposes the ambient derivative of a normal field into a tangential shape operator term and the normal connection. The minus sign corresponds to . For the outward unit normal of a unit sphere, with this convention.
At a point of a smooth surface, a normal section of a surface can bend by different amounts depending on its tangent vector. The principal curvatures are the largest and smallest signed normal curvatures among unit tangent vectors. Equivalently they are the two eigenvalues of the shape operator, with an orthonormal basis of corresponding principal directions. Here the labels follow the selected directions, without requiring . [ref]
https://ghomi.math.gatech.edu/Classes/Math497C/LectureNotes10.pdf. Ghomi, Lecture Notes 10, §2.3.3: normal curvature and principal curvatures
For a unit tangent vector making angle with , Euler formula for normal curvature givesThe normal curvature is a weighted average of the principal curvatures; the extremes occur in the principal directions. If the principal curvatures coincide, every direction in the tangent plane is a principal direction: this is an umbilical point. The Gaussian curvature and mean curvature summarize the pair by
For an outward-oriented sphere of radius , both principal curvatures are , so the normal curvature is in every direction. For an outward-oriented circular cylinder, choose around the circumference and along the axis. The principal curvatures are , giving ; halfway between the principal directions, .
At the origin of the upward-oriented hyperbolic paraboloid , the principal directions are the coordinate axes and the principal curvatures are in the chosen length unit. Thus , with zero normal curvature at . Zero normal curvature in these directions coexists with Gaussian curvature : the shape operator is not zero. The mean curvature is zero at this point; this does not say that the whole hyperbolic paraboloid is a minimal surface.
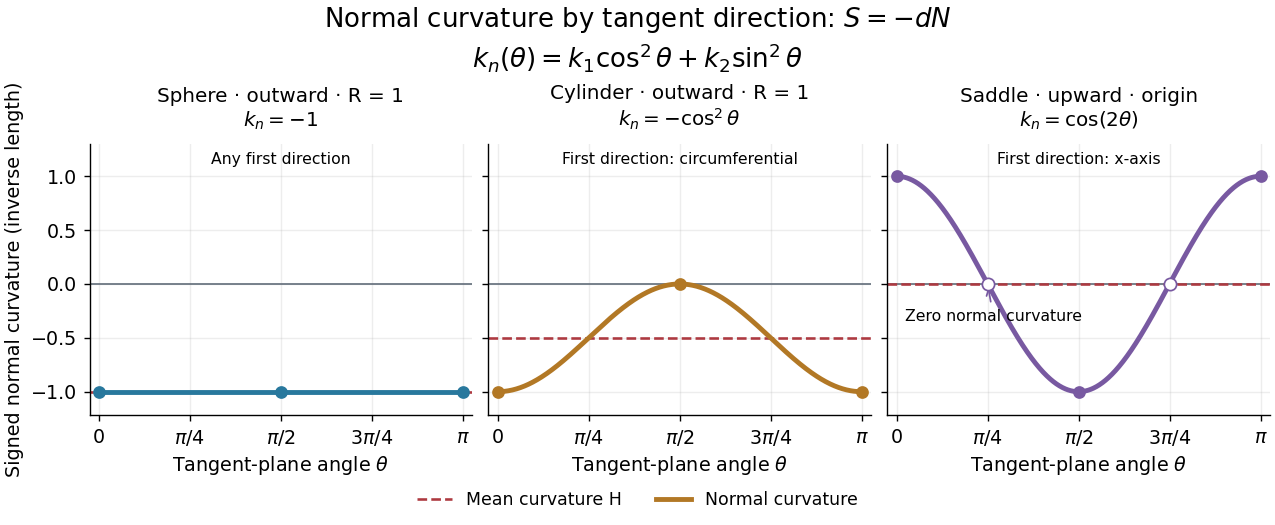
Each graph uses angle in the tangent plane, measured from the indicated first principal direction. The sphere and circular cylinder have ; the saddle graph refers only to the origin. Reversing the unit normal reflects each normal curvature graph through zero, negates both principal curvatures and the mean curvature, and preserves their product, the Gaussian curvature.
A principal direction is an eigenvector of the shape operator. The normal curvature in a unit principal direction is the corresponding principal curvature.
An umbilical point of a surface is a point where the two principal curvatures are equal, equivalently where the shape operator is a scalar multiple of the identity.
For a proper Euclidean motion of Euclidean three-space , transport the unit normal by . The corresponding shape operators are orthogonally conjugate:Their determinant and trace, hence Gaussian curvature and mean curvature, are unchanged.
Rolling a sheet into a circular cylinder bends it without changing its internal lengths and angles. Fitting that same sheet smoothly onto a sphere requires distortion of its first fundamental form. Gaussian curvature distinguishes these situations: it measures the intrinsic curvature of a smooth surface, even though its simplest definition uses how the surface bends in Euclidean space.
The Gaussian curvature at a point is the determinant of the shape operator, or the product of the two principal curvatures:Here is the first fundamental form and is the second fundamental form, with . Regularity makes . Reversing the unit normal negates and both principal curvatures, leaving Gaussian curvature unchanged. [ref]
https://ghomi.math.gatech.edu/Classes/Math497C/LectureNotes9.pdf. Ghomi, Lecture Notes 9, §2.2: determinant formula and independence of normal choice
The sign describes bending at the point: positive Gaussian curvature means the principal curvatures have the same nonzero sign, as at an elliptic point; negative Gaussian curvature means opposite signs, as on a saddle; zero Gaussian curvature means at least one principal curvature vanishes. Zero Gaussian curvature at a single point does not imply that a neighborhood is a plane. [ref]
https://ghomi.math.gatech.edu/Classes/Math497C/LectureNotes10.pdf. Ghomi, Lecture Notes 10, §2.3.1: the sign of Gaussian curvature
Four worked models make the signs concrete:
- On a plane, the unit normal is constant, so the shape operator is zero and .
- On a sphere of radius , the outward unit normal gives . Thus , , and .
- On the lateral surface of a circular cylinder of radius , the outward unit normal gives and . Hence but : there is extrinsic curvature despite intrinsic flatness. The shape operator calculation above gives , , , so the determinant formula gives the same result.
- For the upward-oriented saddle with , the gradient vanishes at the origin. The fundamental forms of a graph surface therefore giveThe shape operator has eigenvalues , giving and . Away from the origin, Gaussian curvature of a graph surface gives ; the label applies only at the marked point.
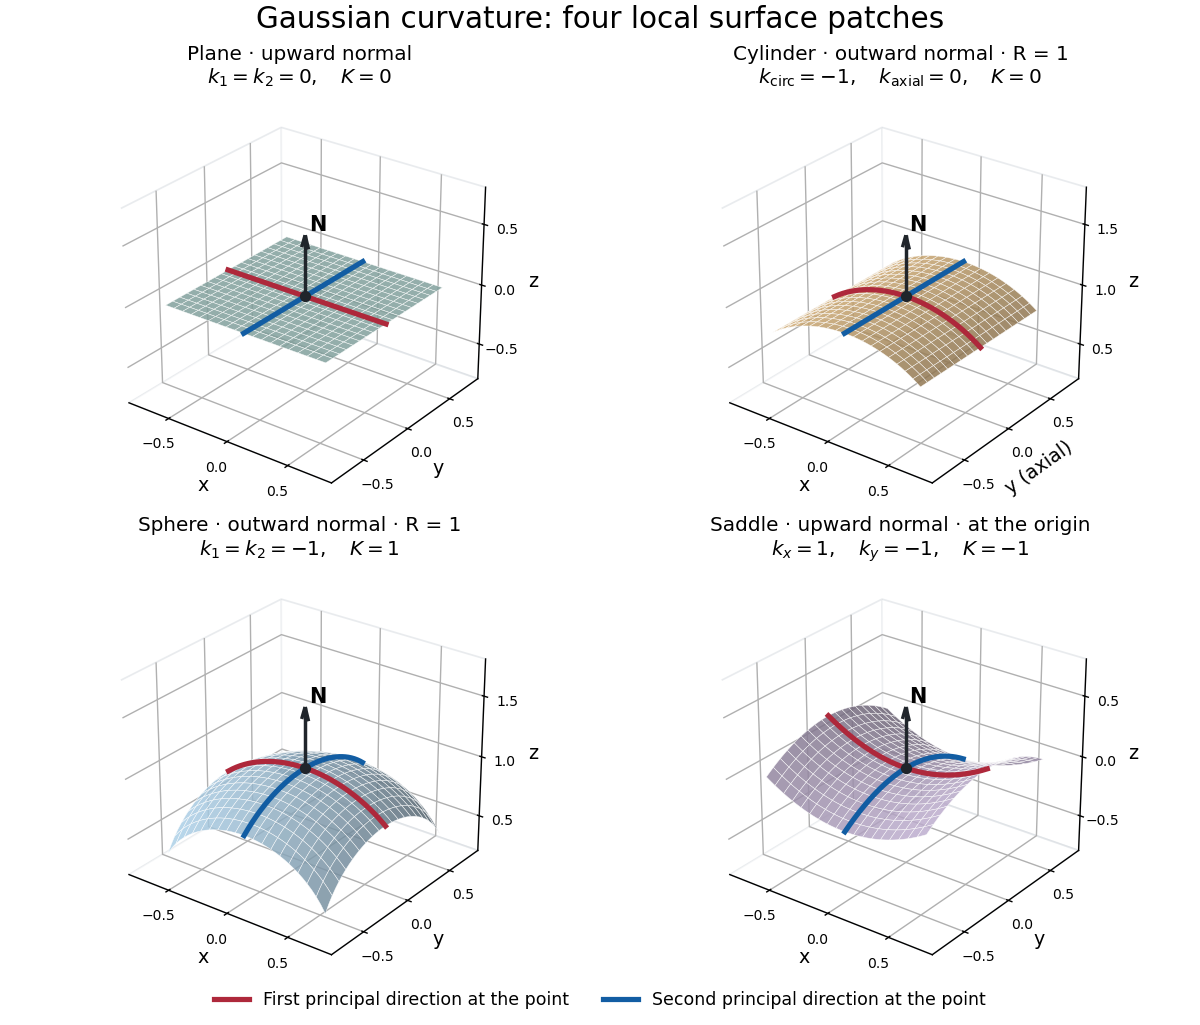
Plane, outward cylinder, outward sphere, and upward saddle compared by their principal curvatures and Gaussian curvature
. Details. The patches use a common length unit, with for the sphere and circular cylinder. The marked red and blue curves have principal directions at the black point; the arrow is the chosen unit normal. For physical lengths, principal curvature and mean curvature have units of inverse length, while Gaussian curvature has units of inverse squared length. Rescaling a surface by divides its principal curvatures by and its Gaussian curvature by . Writing the saddle as restores an explicit length scale: .
The Theorema Egregium says that Gaussian curvature depends only on the first fundamental form and its first two coordinate derivatives. A local isometry therefore preserves Gaussian curvature, even if the shape operator and the principal curvatures change. [ref]
https://ghomi.math.gatech.edu/Classes/Math497C/LectureNotes11.pdf. Ghomi, Lecture Notes 11, §2.5: Theorema Egregium
Here is the outline, rather than a full proof. The Gauss formula splits second derivatives of a parametric surface into tangential Christoffel symbols and the second fundamental form. The Christoffel symbols are determined by the first fundamental form and its first derivatives. Commuting the next partial derivatives gives the Gauss equation, which identifies with the intrinsic sectional curvature computed from the Riemann curvature tensor. Thus the apparently extrinsic product is determined by the Riemannian metric. [ref]
https://ghomi.math.gatech.edu/Classes/Math497C/LectureNotes12.pdf. Ghomi, Lecture Notes 12, §§2.6–2.7: Gauss formula and metric-based curvature
One can see the distinction directly by rolling a plane strip with coordinates into the circular cylinder . Both have , so the map is a local isometry, and is one-to-one on an open strip of width less than . Extending over all real numbers wraps around periodically; it does not give a global isometry between the entire plane and the entire circular cylinder. A nonempty open patch of a sphere cannot be flattened by a local isometry into a plane, because its Gaussian curvature cannot become zero. The obstruction concerns preservation of the first fundamental form, rather than a particular drawing or choice of seam.
For positive twice differentiable , the only nonzero Christoffel symbols are and . In the convention , substitution gives . Dividing by gives the Gaussian curvature . Thus gives the flat metric in polar coordinates away from its axis, gives unit positive curvature, and gives unit negative curvature.
A supporting sphere for an embedded surface at is a sphere tangent at such that the surface lies locally on one side of the sphere. Comparing second fundamental forms at the tangency controls the surface's normal curvature.
If a compact regular surface lies in a closed Euclidean ball of radius , maximize distance from the ball's centre. At a maximizing point, comparison of the second fundamental form with the tangent supporting sphere makes both principal curvatures have magnitude at least and the same sign. The Gaussian curvature there is therefore at least .
An elliptic point of a surface is a point at which the Gaussian curvature is positive, equivalently where the two principal curvatures have the same nonzero sign.
Every regular cone parametrized by has zero Gaussian curvature away from its vertex. Its unit normal is independent of , whileis tangent, so two coefficients of the second fundamental form vanish and .
Mean curvature measures the average signed bending of a smooth surface. Unlike Gaussian curvature, it adds the two principal curvatures rather than multiplying them. A circular cylinder therefore has nonzero mean curvature despite zero Gaussian curvature, whereas a catenoid has zero mean curvature despite negative Gaussian curvature. The cancellation on a catenoid explains how a curved minimal surface can be stationary for surface area.
Choose a unit normal and the shape operator , as in the second fundamental form convention . For a smooth surface in Euclidean space of dimension three, define the signed scalar mean curvature byHere are the coefficients of the first fundamental form, and those of the second fundamental form. The factor makes an average; the scalar trace convention instead calls the mean curvature. Authors who use reverse both signs. A formula involving mean curvature is therefore incomplete unless its shape operator, unit normal, and averaging convention are specified.
In orientation reversal of surface curvature, both principal curvatures and change sign, while Gaussian curvature and the mean curvature vector do not. The units of mean curvature are inverse length, compared with inverse squared length for Gaussian curvature. The distinction matters in soap film pressure balance: pressure couples to the sum of the signed principal curvatures.
For an -dimensional embedded submanifold, let denote its vector-valued second fundamental form and an orthonormal basis of its tangent space. This branch uses the trace mean curvature vectorAn alternative averaged mean curvature vector is ; on a smooth surface in three-dimensional Euclidean space, these are and , respectively. Reversing reverses , so their product is independent of the chosen orientation of a surface. With the trace convention, the first variation of area formula has no additional factor . For an outward-oriented sphere of radius , : it points toward the centre even though the scalar's sign depends on conventions.
For a sphere of radius , its outward unit normal is . Applying the shape operator gives , so the two principal curvatures coincide:For the lateral surface of a circular cylinder with outward unit normal, moving around a circle turns at rate , while moving along the axis leaves constant. Thus the circumferential and axial principal curvatures giveHere is Gaussian curvature. The circular cylinder bends in only one principal direction, so its mean curvature is half that of the equally sized sphere. These formulas concern the smooth lateral surface, excluding any edges where end caps meet it.
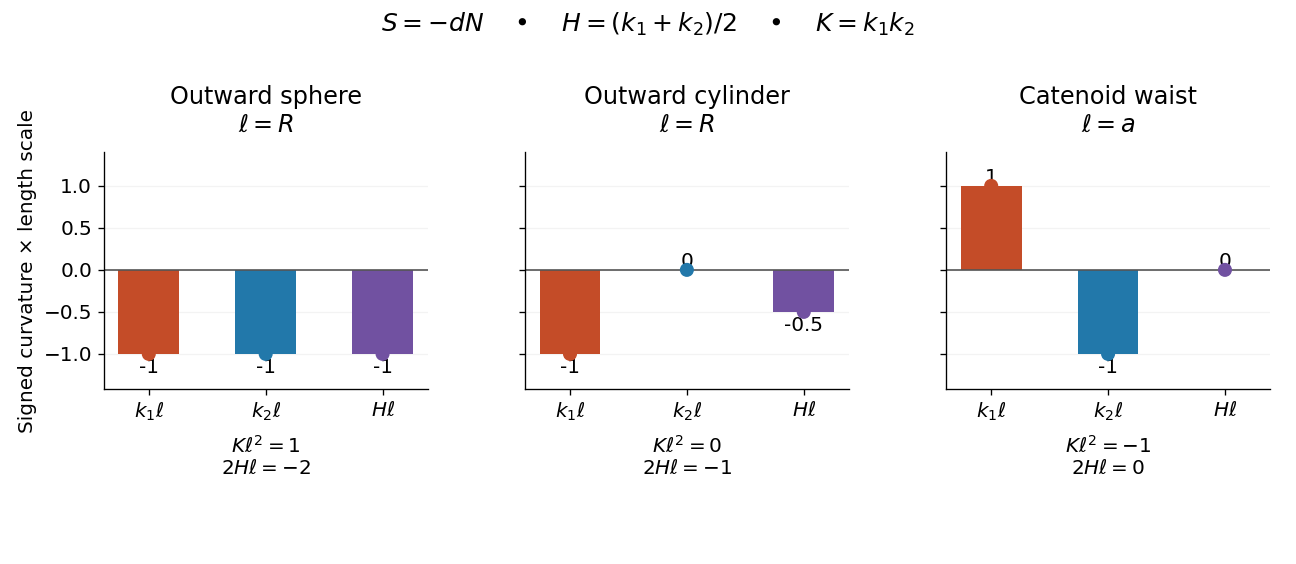
Signed principal curvatures and their mean on an outward sphere, outward cylinder, and catenoid waist
. Details. The common length scale is , equal to the radius for the sphere and circular cylinder, and to the waist radius for the catenoid. The mean curvature marker is halfway between the two principal curvature markers. Gaussian curvature has a different unit and is listed separately beneath each panel.
Scale the catenoid by its waist radius and choose a unit normal with outward radial component:The hyperbolic cosine controls the profile . Direct differentiation yields the first fundamental form and second fundamental formThe coordinate tangent vectors are orthogonal, so the meridional and circumferential principal curvatures areThe opposite principal curvatures cancel at every point, not just at the waist. This is precisely why the catenoid is a minimal surface, while its nonzero second fundamental form and negative Gaussian curvature show that it is not a plane.
A minimal surface has vanishing mean curvature vector. For a smooth surface in three-dimensional Euclidean space, this means , equivalently . Thus Gaussian curvature is , but neither principal curvature needs to vanish. A plane and a catenoid both satisfy the condition, with very different Gaussian curvatures.
By the first variation of area formula, a minimal surface is a stationary point of surface area for every smooth variation that fixes its boundary, or has compact support in its interior. The word “minimal” specifies this differential equation; it does not guarantee a global minimum of surface area, or even a local minimum. A stable minimal surface imposes a further condition on the second variation.
Let a boundaryless minimal surface be closed in , and let its distance to a plane tend to infinity along every sequence escaping bounded sets. If it has no planar point, it must meet the plane. Otherwise absolute signed height has a positive attained minimum by properness. Its Hessian there is semidefinite and equals the second fundamental form up to sign because the plane is tangent. Minimality makes its trace zero, so the entire form vanishes, contradicting the absence of planar points. This argument uses curvature and attained extrema, rather than an unproved contact comparison for Gaussian curvature.
An outer area-minimizing surface is a closed surface in a Riemannian initial-data slice whose area is no greater than that of any enclosing competitor. This is a variational property, not a consequence of containment alone. It is important when choosing the horizon-area quantity in the Riemannian Penrose inequality and when examining an apparent-horizon area comparison.
The isothermal coordinates give the immersion . Its coordinate functions are harmonic and its metric is , so it is a complete immersed minimal surface with self-intersections.
With and , a variation with velocity satisfiesThus a boundaryless submanifold is stationary for every compactly supported variation exactly when it is minimal.
For the squared distance , a minimal -submanifold satisfies . On a compact boundaryless manifold, attains a maximum where the Laplacian is nonpositive, a contradiction for .
A stable minimal surface has nonnegative second variation of surface area for every admissible normal variation fixing the boundary. For a two-sided minimal surface in three-dimensional Euclidean space, the quadratic form isHere is the gradient for the induced Riemannian metric. The gradient term penalizes rapid changes in the displacement; the principal curvature term can make the second variation negative. A plane has only the nonnegative gradient term. Nonnegativity alone, especially with zero modes, does not prove a strict local minimum or a global minimum.
For a finite catenoid between fixed rings, the answer depends on the ring separation, waist radius, and allowed variations. The axisymmetric second variation of a catenoid tests a specified restricted class. Comparing with two disconnected disks tests a different class of competitors, including a change in topology. Consequently, a stationary catenoid can have greater surface area than two disks without immediately collapsing under every small perturbation.
For an ideal soap film with equal constant surface tension on both faces, the effective tension is . Choose a unit normal from the minus side to the plus side, and . Translating the Young–Laplace equation to givesA single interface uses . An outward-oriented spherical soap bubble has , giving . The positive-convex curvature sum in the Young–Laplace equation article is . [ref]
An open film with the same resting gas on both sides has zero pressure jump. Neglecting film weight, soap film pressure balance gives : a minimal surface. A pressurized bubble instead has nonzero mean curvature. These statements assume equilibrium, constant surface tension, and negligible normal viscous stress. Surfactant gradients or motion require the fuller normal stress balance. [ref]
The variational outline is short. With fixed boundary, a normal displacement gives by the first variation of area formula. For a closed interface oriented outward, , so stationarity of gives . This is a first variation calculation; testing for a stable minimal surface needs the second variation, and deciding a global minimum needs a comparison of competitors.
Two equal circular rings of radius in parallel planes at provide a boundary for an open film. In the ideal axisymmetric model, a stationary connected film has the catenoid profileThe catenoid existence threshold for equal rings explains why this equation can have two solutions, one solution, or none. The cancellation of principal curvatures holds for both solutions whenever they exist; the mean curvature equation alone does not select a stable minimal surface.
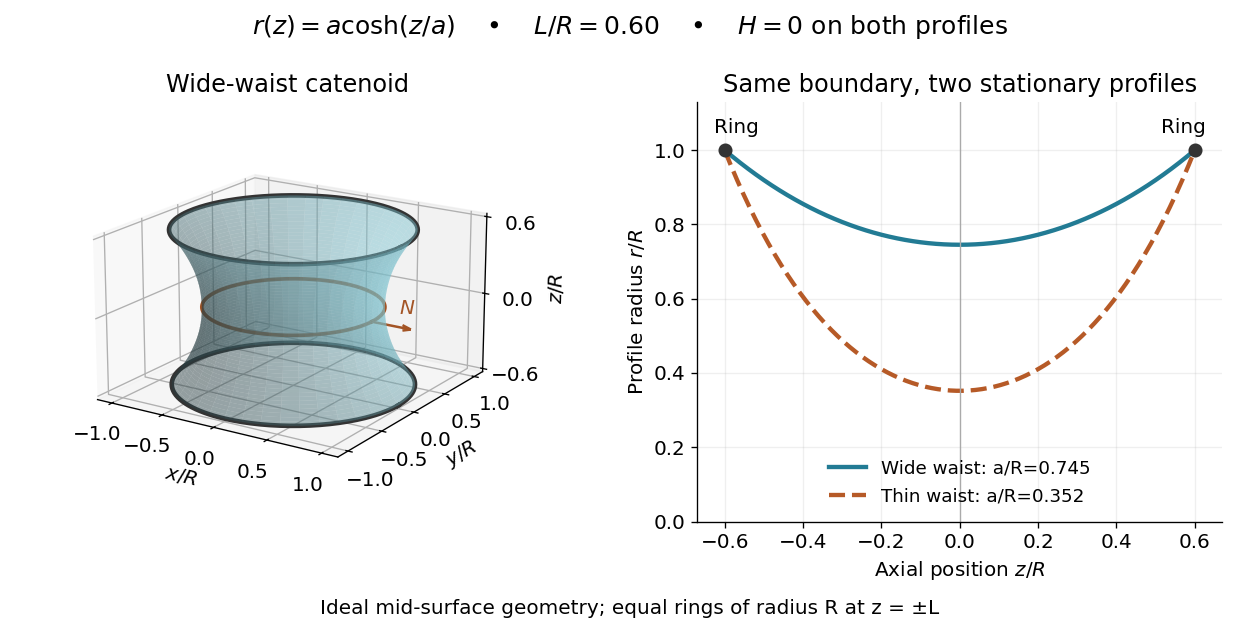
This ideal geometry uses and . The two profiles have different waist radii , although both have . For either profile the surface area follows by integration:At this illustrated separation both profiles have greater surface area than the two disconnected disks, whose total is . This comparison disproves a claim of global area minimization in a class allowing disconnected competitors; it does not determine the sign of the second variation for small variations of a connected film.
A reported experiment used coaxial wire rings of radius , drawn from a surfactant solution and slowly separated until collapse. The solution contained tetradecyltrimethylammonium bromide in deionized water, with glycerol added to vary viscosity. Fluorescein enabled fluorescence imaging under cyan LED arrays; a Phantom V641 camera recorded 4,000 or 5,600 frames per second. Extracted contours gave neck radius, attachment angle, and inferred surface area. They showed neck narrowing and eventual breakup, rather than indefinite persistence of a stationary catenoid. Comparing solutions across viscosities helped distinguish liquid dissipation from the surrounding air's inertia, but the ring displacement beyond the last stable state was not precisely controlled. These are collapse observations, not direct measurements of equilibrium . [ref]
Geometry of catenoidal soap film collapse induced by boundary deformation by Raymond E. Goldstein and others. Geometry of Catenoidal Soap Film Collapse Induced by Boundary Deformation, §II, manuscript pp. 3–4, Figs. 1–3: apparatus, contour readouts, viscosity comparison, and displacement limitation
A proposed classroom measurement would instead hold two equal rings coaxial on a translation stage, leave both sides open to the same gas, and photograph the settled silhouette beside a scale. Fit and inspect fit residuals before inferring cancellation of the principal curvatures. Repeat at several separations and with the camera rotated about the axis to test rotational symmetry. Keep solution composition, ring wetting, and elapsed drainage time comparable, and shield the film from drafts. Film weight, drainage, evaporation, surfactant gradients, and rupture can invalidate the ideal soap film pressure balance. A silhouette fit alone neither measures the pressure jump nor tests all possible perturbations of a stable minimal surface.
Replacing the chosen unit normal by replaces the shape operator by . On a surface, Gaussian curvature is unchanged, while mean curvature changes sign.
Suppose two graph surfaces and are tangent at the origin, are oriented upward, and nearby. Then has a local minimum, so its Hessian matrix is positive semidefinite. At the common horizontal tangent plane,
The same contact does not order Gaussian curvature, because determinant is not monotone under addition of a positive-semidefinite matrix when the original Hessian is indefinite or negative definite. For example,satisfy and are tangent at zero, but .
After a rigid motion, write the plane as and the surface locally as . Along the curve of tangency, and . Differentiating shows that the Hessian annihilates the nonzero tangent , so its determinant and therefore the Gaussian curvature vanish.
The graph of is minimal exactly whenEquivalently, it is the Euler--Lagrange equationfor the area functional .
This functional measures the surface area of the graph of a function. On a bounded domain it is finite for . Its directional derivative is , by the dominated convergence theorem, since the pointwise difference quotients are bounded by . The resulting dual-valued operator is monotone: the scalar integrand is convex and its gradient is . It is not a nonlinear coercive operator on the full space, since it vanishes on constant functions whose norms can tend to infinity.
Every entire classical minimal graph over is affine for . The dimension restriction is essential. This theorem applies to the minimal surface equation for a graph, without assuming a global bound on its gradient.
// Target: analysis.bigb
The flux of the minimal surface equation for a graph has a positive definite symmetric matrix derivative. Its eigenvalues are in the direction of and orthogonally; at every eigenvalue is one. On it satisfiesThus an averaged linearization of a nonlinear divergence-form equation is uniformly elliptic where the relevant gradients are bounded. Pointwise positivity alone does not supply a uniform bound on an unbounded gradient range.
For a solution of the minimal surface equation for a graph on the closure of a bounded domain,Write with . Its differentiated operator , where , satisfiesThe weak maximum principle for elliptic operators gives the result. Interior Schauder estimates justify differentiating a solution initially assumed only .
If a smooth minimal surface equation for a graph solution on is homogeneous of degree one, with , then its graph extends to a plane through zero. Its gradient is homogeneous of degree zero, so attains a global maximum on the unit sphere. The strong maximum principle for elliptic operators makes it constant. The differentiated equation in the gradient maximum principle for a minimal graph then forces , and degree-one homogeneity removes the affine constant. This argument applies to cones that are graphs of smooth functions away from their vertex; it is not a claim that every minimal surface cone is flat.
Articles by others on the same topic



The second fundamental form is a mathematical object used in differential geometry that provides a way to describe how a surface bends in a higher-dimensional space. Specifically, it is associated with a surface \( S \) embedded in a higher-dimensional Euclidean space, such as \(\mathbb{R}^3\).