Mean curvature measures the average signed bending of a smooth surface. Unlike Gaussian curvature, it adds the two principal curvatures rather than multiplying them. A circular cylinder therefore has nonzero mean curvature despite zero Gaussian curvature, whereas a catenoid has zero mean curvature despite negative Gaussian curvature. The cancellation on a catenoid explains how a curved minimal surface can be stationary for surface area.
Choose a unit normal and the shape operator , as in the second fundamental form convention . For a smooth surface in Euclidean space of dimension three, define the signed scalar mean curvature byHere are the coefficients of the first fundamental form, and those of the second fundamental form. The factor makes an average; the scalar trace convention instead calls the mean curvature. Authors who use reverse both signs. A formula involving mean curvature is therefore incomplete unless its shape operator, unit normal, and averaging convention are specified.
In orientation reversal of surface curvature, both principal curvatures and change sign, while Gaussian curvature and the mean curvature vector do not. The units of mean curvature are inverse length, compared with inverse squared length for Gaussian curvature. The distinction matters in soap film pressure balance: pressure couples to the sum of the signed principal curvatures.
For an -dimensional embedded submanifold, let denote its vector-valued second fundamental form and an orthonormal basis of its tangent space. This branch uses the trace mean curvature vectorAn alternative averaged mean curvature vector is ; on a smooth surface in three-dimensional Euclidean space, these are and , respectively. Reversing reverses , so their product is independent of the chosen orientation of a surface. With the trace convention, the first variation of area formula has no additional factor . For an outward-oriented sphere of radius , : it points toward the centre even though the scalar's sign depends on conventions.
For a sphere of radius , its outward unit normal is . Applying the shape operator gives , so the two principal curvatures coincide:For the lateral surface of a circular cylinder with outward unit normal, moving around a circle turns at rate , while moving along the axis leaves constant. Thus the circumferential and axial principal curvatures giveHere is Gaussian curvature. The circular cylinder bends in only one principal direction, so its mean curvature is half that of the equally sized sphere. These formulas concern the smooth lateral surface, excluding any edges where end caps meet it.
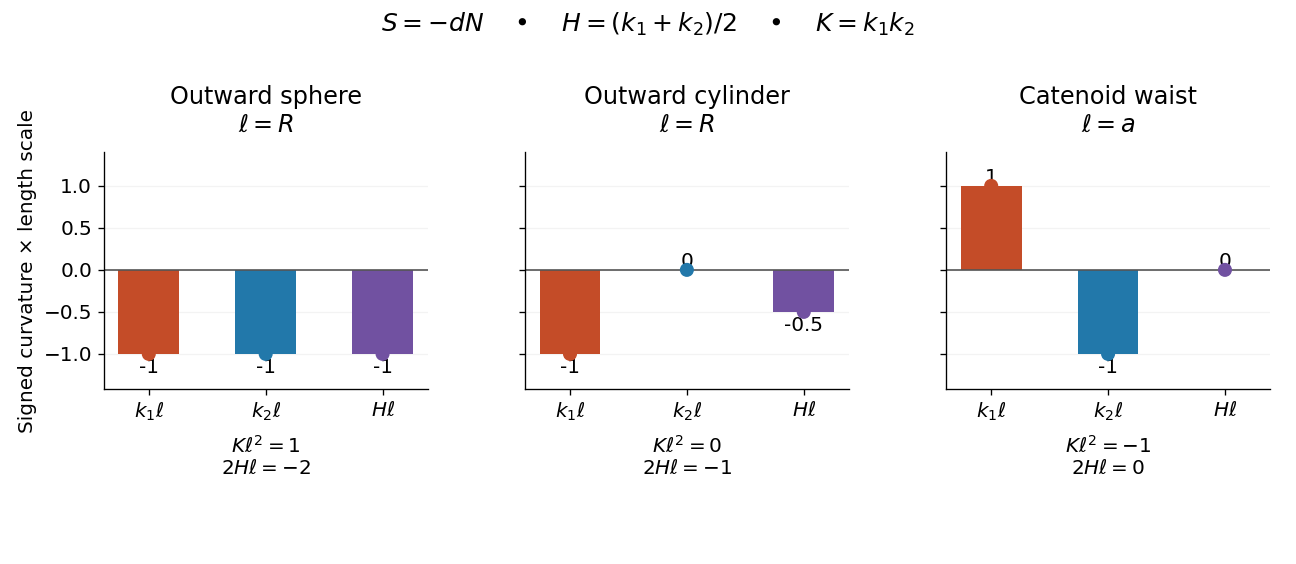
Signed principal curvatures and their mean on an outward sphere, outward cylinder, and catenoid waist
. Details. The common length scale is , equal to the radius for the sphere and circular cylinder, and to the waist radius for the catenoid. The mean curvature marker is halfway between the two principal curvature markers. Gaussian curvature has a different unit and is listed separately beneath each panel.
Scale the catenoid by its waist radius and choose a unit normal with outward radial component:The hyperbolic cosine controls the profile . Direct differentiation yields the first fundamental form and second fundamental formThe coordinate tangent vectors are orthogonal, so the meridional and circumferential principal curvatures areThe opposite principal curvatures cancel at every point, not just at the waist. This is precisely why the catenoid is a minimal surface, while its nonzero second fundamental form and negative Gaussian curvature show that it is not a plane.
A minimal surface has vanishing mean curvature vector. For a smooth surface in three-dimensional Euclidean space, this means , equivalently . Thus Gaussian curvature is , but neither principal curvature needs to vanish. A plane and a catenoid both satisfy the condition, with very different Gaussian curvatures.
By the first variation of area formula, a minimal surface is a stationary point of surface area for every smooth variation that fixes its boundary, or has compact support in its interior. The word “minimal” specifies this differential equation; it does not guarantee a global minimum of surface area, or even a local minimum. A stable minimal surface imposes a further condition on the second variation.
Let a boundaryless minimal surface be closed in , and let its distance to a plane tend to infinity along every sequence escaping bounded sets. If it has no planar point, it must meet the plane. Otherwise absolute signed height has a positive attained minimum by properness. Its Hessian there is semidefinite and equals the second fundamental form up to sign because the plane is tangent. Minimality makes its trace zero, so the entire form vanishes, contradicting the absence of planar points. This argument uses curvature and attained extrema, rather than an unproved contact comparison for Gaussian curvature.
An outer area-minimizing surface is a closed surface in a Riemannian initial-data slice whose area is no greater than that of any enclosing competitor. This is a variational property, not a consequence of containment alone. It is important when choosing the horizon-area quantity in the Riemannian Penrose inequality and when examining an apparent-horizon area comparison.
The isothermal coordinates give the immersion . Its coordinate functions are harmonic and its metric is , so it is a complete immersed minimal surface with self-intersections.
With and , a variation with velocity satisfiesThus a boundaryless submanifold is stationary for every compactly supported variation exactly when it is minimal.
For the squared distance , a minimal -submanifold satisfies . On a compact boundaryless manifold, attains a maximum where the Laplacian is nonpositive, a contradiction for .
A stable minimal surface has nonnegative second variation of surface area for every admissible normal variation fixing the boundary. For a two-sided minimal surface in three-dimensional Euclidean space, the quadratic form isHere is the gradient for the induced Riemannian metric. The gradient term penalizes rapid changes in the displacement; the principal curvature term can make the second variation negative. A plane has only the nonnegative gradient term. Nonnegativity alone, especially with zero modes, does not prove a strict local minimum or a global minimum.
For a finite catenoid between fixed rings, the answer depends on the ring separation, waist radius, and allowed variations. The axisymmetric second variation of a catenoid tests a specified restricted class. Comparing with two disconnected disks tests a different class of competitors, including a change in topology. Consequently, a stationary catenoid can have greater surface area than two disks without immediately collapsing under every small perturbation.
For an ideal soap film with equal constant surface tension on both faces, the effective tension is . Choose a unit normal from the minus side to the plus side, and . Translating the Young–Laplace equation to givesA single interface uses . An outward-oriented spherical soap bubble has , giving . The positive-convex curvature sum in the Young–Laplace equation article is . [ref]
An open film with the same resting gas on both sides has zero pressure jump. Neglecting film weight, soap film pressure balance gives : a minimal surface. A pressurized bubble instead has nonzero mean curvature. These statements assume equilibrium, constant surface tension, and negligible normal viscous stress. Surfactant gradients or motion require the fuller normal stress balance. [ref]
The variational outline is short. With fixed boundary, a normal displacement gives by the first variation of area formula. For a closed interface oriented outward, , so stationarity of gives . This is a first variation calculation; testing for a stable minimal surface needs the second variation, and deciding a global minimum needs a comparison of competitors.
Two equal circular rings of radius in parallel planes at provide a boundary for an open film. In the ideal axisymmetric model, a stationary connected film has the catenoid profileThe catenoid existence threshold for equal rings explains why this equation can have two solutions, one solution, or none. The cancellation of principal curvatures holds for both solutions whenever they exist; the mean curvature equation alone does not select a stable minimal surface.
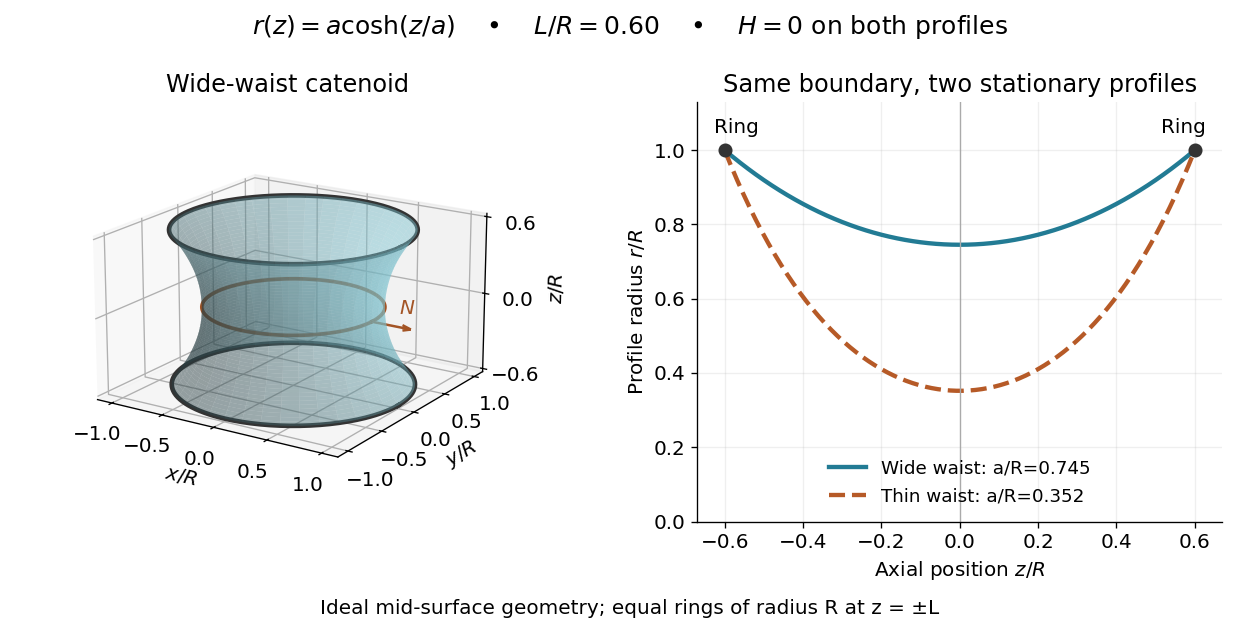
This ideal geometry uses and . The two profiles have different waist radii , although both have . For either profile the surface area follows by integration:At this illustrated separation both profiles have greater surface area than the two disconnected disks, whose total is . This comparison disproves a claim of global area minimization in a class allowing disconnected competitors; it does not determine the sign of the second variation for small variations of a connected film.
A reported experiment used coaxial wire rings of radius , drawn from a surfactant solution and slowly separated until collapse. The solution contained tetradecyltrimethylammonium bromide in deionized water, with glycerol added to vary viscosity. Fluorescein enabled fluorescence imaging under cyan LED arrays; a Phantom V641 camera recorded 4,000 or 5,600 frames per second. Extracted contours gave neck radius, attachment angle, and inferred surface area. They showed neck narrowing and eventual breakup, rather than indefinite persistence of a stationary catenoid. Comparing solutions across viscosities helped distinguish liquid dissipation from the surrounding air's inertia, but the ring displacement beyond the last stable state was not precisely controlled. These are collapse observations, not direct measurements of equilibrium . [ref]
Geometry of catenoidal soap film collapse induced by boundary deformation by Raymond E. Goldstein and others. Geometry of Catenoidal Soap Film Collapse Induced by Boundary Deformation, §II, manuscript pp. 3–4, Figs. 1–3: apparatus, contour readouts, viscosity comparison, and displacement limitation
A proposed classroom measurement would instead hold two equal rings coaxial on a translation stage, leave both sides open to the same gas, and photograph the settled silhouette beside a scale. Fit and inspect fit residuals before inferring cancellation of the principal curvatures. Repeat at several separations and with the camera rotated about the axis to test rotational symmetry. Keep solution composition, ring wetting, and elapsed drainage time comparable, and shield the film from drafts. Film weight, drainage, evaporation, surfactant gradients, and rupture can invalidate the ideal soap film pressure balance. A silhouette fit alone neither measures the pressure jump nor tests all possible perturbations of a stable minimal surface.
Replacing the chosen unit normal by replaces the shape operator by . On a surface, Gaussian curvature is unchanged, while mean curvature changes sign.
Articles by others on the same topic



Mean curvature is a geometric concept that arises in differential geometry, particularly in the study of surfaces. It measures the average curvature of a surface at a given point and is an important characteristic in the study of minimal surfaces and the geometry of manifolds. For a surface defined in three-dimensional space, the mean curvature \( H \) at a point is given by the average of the principal curvatures \( k_1 \) and \( k_2 \) at that point.