A matrix over a field is in row echelon form when all zero rows follow the nonzero rows, each nonzero row's first nonzero entry lies strictly to the right of the preceding row's first nonzero entry, and all entries below each such leading entry vanish. These leading entries are its pivot elements. They need not be one, and entries above them need not vanish.[ref]
Row Reduction. Interactive Linear Algebra by Dan Margalit and others; §1.2.2, Echelon Forms: three echelon conditions and definition of a pivot
The staircase turns a linear system into a sequence of simpler equations. For example,is in row echelon form, with pivot columns 1 and 2. Its second equation determines once is chosen; its first then determines by back substitution. It is not in reduced row echelon form, because the second pivot column contains a nonzero entry above its pivot element. Neither being square nor having a nonzero entry in every row is required.
Elementary row operations bring every matrix to row echelon form: choose a nonzero entry in the leftmost available nonzero column, interchange rows, clear entries below it, and repeat on the remaining rows and later columns. Skip columns with no remaining nonzero entry. Clearing above each pivot element and scaling it to one completes reduced row echelon form.[ref]
Row Reduction. Interactive Linear Algebra by Dan Margalit and others; §1.2.3, The Row Reduction Algorithm, forward steps and Last Step
The nonzero rows of an row echelon form are linearly independent: in a vanishing linear combination, inspecting the first pivot column forces the first coefficient to be zero, then the next forces the second, and so on. They give a basis of the original row space. The number of pivot elements is both the row rank and the column rank. To recover a basis of the original column space, select the corresponding original pivot columns; the reduced column vectors generally belong to a different column space.
Here the arithmetic is exact in the specified field. For floating-point arithmetic, deciding whether a computed entry counts as zero requires a numerical criterion; see Tiny-pivot roundoff in Gaussian elimination and condition number. An exact row echelon form classification alone does not settle numerical stability.
Two matrices of the same size over the same field are row-equivalent matrices if a sequence of elementary row operations transforms one into the other.[ref]
Row Reduction. Interactive Linear Algebra by Dan Margalit and others; §1.2.1, definition of row equivalence
Every operation is reversible, so they have the same row space and the same column linear relations. Writing the entire sequence as multiplication by an invertible matrix gives andThus the kernel is preserved. For a nonzero right-hand side, perform every operation on the whole augmented matrix : changing the coefficients while keeping fixed generally changes the solutions. The column space instead transforms to , which need not equal .Work over the rational numbers, allowing unknowns in the real numbers when interpreting the geometry. Consider four equations in three unknowns:The third row of is the sum of its first two rows, and the fourth is their difference, second minus first. The same relations must hold on the right: consistency requires and . The latter condition already holds. Gaussian elimination makes this compatibility test explicit while exposing the remaining freedom.
Apply the elementary row operations in this order, using each row's current value:then and . The resulting augmented matrix is in row echelon form for every :When , the third row has its pivot element in the augmented column. It says , so the linear system has no solution. When , that entire row vanishes and only two pivot elements remain. More equations than unknowns therefore do not force a unique solution: some equations may repeat information.
The final operation reduces the coefficient block toThe product of all six elementary matrices isDirect matrix multiplication verifies both displayed transformations. Its determinant is one, so this transformation is reversible. In particular, the third row of extracts the discrepancy between the third equation and the sum of the first two.
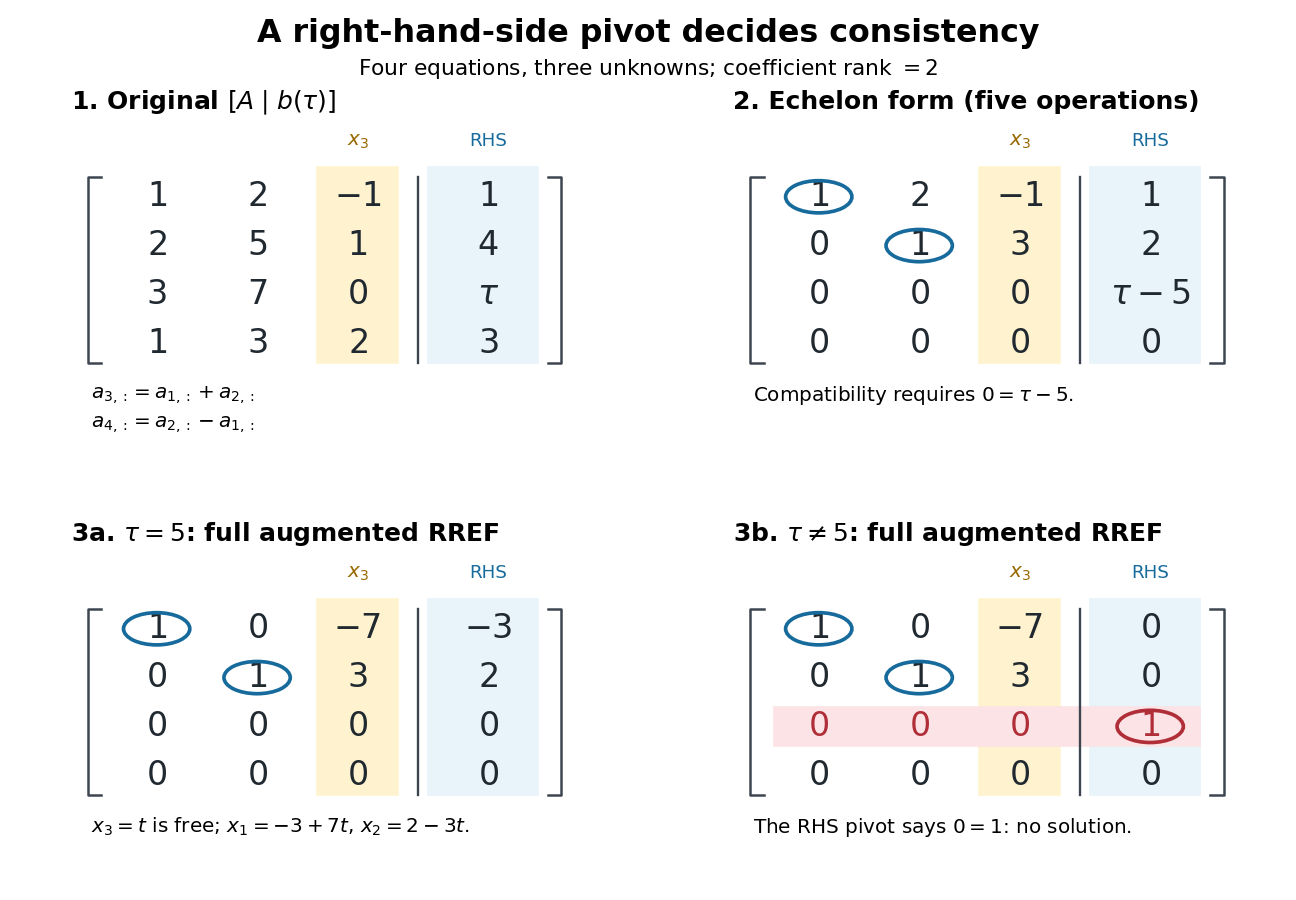
Row echelon form exposes compatibility; a right-hand-side pivot element distinguishes inconsistency from a free variable in a linear system
. Details. For , is the reduced row echelon form of the full augmented matrix. For , only its coefficient block is reduced: scale the third row by and clear the entries above its augmented pivot element. The full reduced row echelon form is thenThe last column is part of the matrix when testing the echelon conditions. Calling fully reduced before clearing that column would miss this distinction.
A row echelon form is in reduced row echelon form when every pivot element is one and is the only nonzero entry in its column.[ref]
Row Reduction. Interactive Linear Algebra by Dan Margalit and others; §1.2.2, reduced echelon conditions 4 and 5
This extra reduction displays each pivot unknown directly in terms of the free variables in a linear system. The zero matrix also satisfies the definition: it has no pivot elements.Every matrix has exactly one reduced row echelon form under elementary row operations, with its size and column order held fixed.[ref]
Row Reduction. Interactive Linear Algebra by Dan Margalit and others; §1.2.3, theorem preceding the Row Reduction Algorithm
Ordinary row echelon form is not unique: multiplying a nonzero row by two over the rational numbers keeps the staircase but changes the matrix. The reduced conditions remove that freedom.For a fixed number of columns, each row space has a unique reduced matrix after zero rows are removed; at a fixed full size, the number of appended zero rows is also determined. Thus reduced row echelon form represents a vector subspace independently of the starting basis. This is the uniqueness used by Gaussian binomial coefficients to count vector subspaces over a finite field.
The fixed column order matters. Elementary column operations can change the row space, the kernel and the resulting reduced row echelon form. For instance, swapping the columns of over the rational numbers gives , whose reduced row echelon form is instead of . When solving a linear system, a column interchange also requires tracking the corresponding interchange of unknowns.
For row reduction with a parameterized right-hand side at , the nonzero reduced equations areColumn 3 has no pivot element, so is a free variable in a linear system. Taking gives every solution:There is no further restriction on . Independent substitution into the original linear system givesConversely, the two reduced equations force exactly these coordinate formulas, so no solutions have been omitted. The same computation with zero right-hand side gives the kernel . Its dimension is one. The rank-nullity theorem appears here as : two pivot columns and one freely chosen coordinate account for the three unknowns.[ref]
The Rank Theorem. Interactive Linear Algebra by Dan Margalit and others; §2.9, Rank Theorem and preceding pivot-column/free-variable count
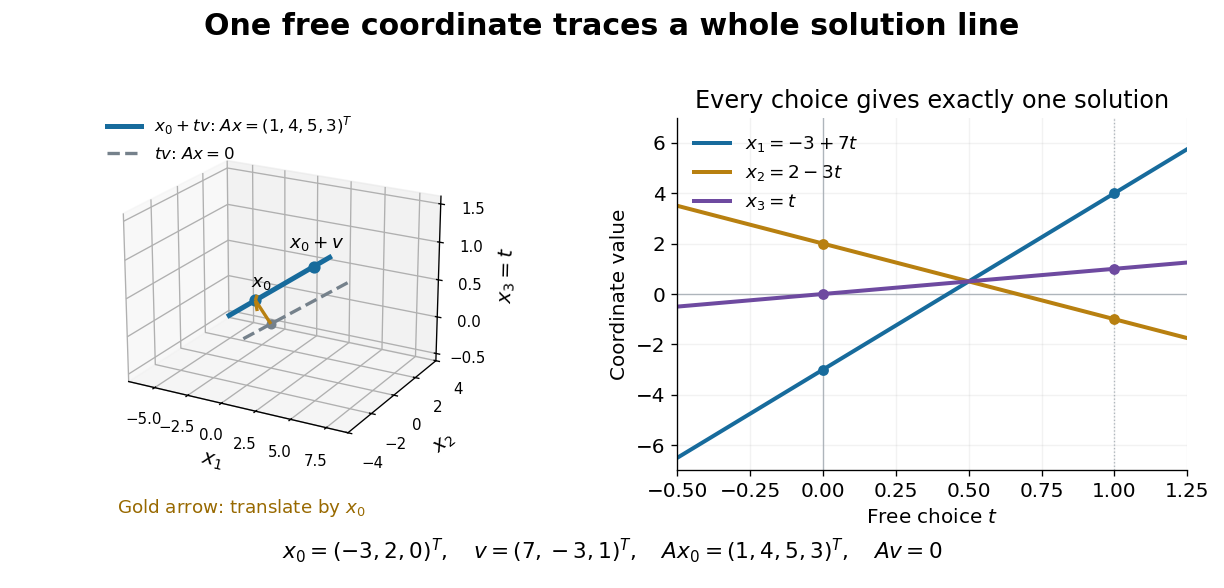
One free variable in a linear system traces an affine solution space of a linear equation parallel to its kernel
. Details. In general a consistent linear system has solution set . Subtracting from proves this description in both directions. The particular solution places the affine subspace, and the kernel supplies its directions.[ref]
Solution Sets. Interactive Linear Algebra by Dan Margalit and others; §2.4.2, Key Observation and its proof: translate homogeneous solutions by any particular solution
Over the real numbers this example is an entire line; over the rational numbers the same formula uses rational . A free variable in a linear system over a finite field instead has only finitely many choices.The pivot columns identify a different object: the original column space. Here they selectwhich form its basis, while . The corresponding reduced columns are and ; their linear span is a different plane. For example, every original output satisfies , but does not. Since is an invertible matrix, column linear relations survive even though the output vectors move. This is why choosing original columns at the reduced pivot positions works.
Here is a short proof that uses only the row space. For a vector subspace , let be the dimension of its projection map onto the first coordinates, with . In any reduced row echelon form with row space , counts the pivot columns among those first columns: later-pivot rows project to zero, while earlier-pivot rows remain linearly independent. Thus the positions where determine all pivot positions from alone.
If those positions are , the map sending to is an isomorphism : the reduced nonzero rows map to the standard basis. Its th row is therefore the unique vector of with pivot-coordinate values equal to the th standard basis vector. Any other reduced row echelon form with that row space has identical nonzero rows in identical order. At a fixed matrix size, the remaining rows must be zero. Together with existence by Gaussian elimination, this proves uniqueness.
Articles by others on the same topic



Row echelon form (REF) is a type of matrix form used in linear algebra, particularly in the context of solving systems of linear equations. A matrix is said to be in row echelon form if it satisfies the following conditions: 1. **Leading Coefficients**: In each non-zero row, the first non-zero number (from the left) is called the leading coefficient (or pivot) of that row.