Topics (374k) Articles (387k) Users (410) Discussions (242) Comments (383) Files (12k) New article
With constant buoyancy and no settling or entrainment, the box volume is proportional to . Thus for an initial lock length . A gravity-current front condition gives , so increases linearly with time. This is a late-time integral approximation; it does not reproduce the initial rarefaction or the detailed nose.
Assume independent stationary Compound Poisson process inputs, preemptive-resume priority for voice, first come first served within each class, capacity , a shared buffer of units of work, packet sizes bounded by , and voice delay gate . Write and . For flows with per-flow effective bandwidths , the continuous-time exponential workload bound givesprovided and . To prove this, couple with the unthinned infinite-buffer aggregate and voice queues driven by the same offered packets. Dropping work reduces both the total and voice workloads under this service discipline. A buffer-fit failure implies total workload greater than , and a voice-gate failure implies voice workload at least . Apply the two bounds and a union bound; Poisson arrivals see time averages converts stationary prearrival probabilities to offered-packet loss fractions. For target losses , choose and , then setThe two effective bandwidth constraints, together with strict aggregate mean-load stability, define a sufficient integer admission region. Voice loss includes the shared-buffer term, even though data packets have lower service priority.
For a regular curve with positive curvature of a space curve, the Frenet-Serret formulas give . If the unit tangent vector has constant component along a fixed vector , differentiation of gives . Hence every principal normal vector is perpendicular to that direction. Nonzero curvature is needed to define the principal normal.
If two principal moments of inertia coincide, for example , every direction in their two-dimensional eigenspace is a principal axis. The perpendicular axis is determined, but there is no privileged orthogonal pair within that plane. Rotating the pair in the plane leaves the diagonal inertia tensor unchanged. If all three principal moments of inertia coincide, and every axis through is principal. This follows from the eigenvalue multiplicity and eigenspace, rather than from a failure of diagonalization. [ref]
Equal principal moments of inertia do not prove that a body's outline has continuous rotational symmetry. For example, six equal point masses at , and have . This discrete layout has the same axial moment of inertia in every direction, although its actual mass distribution changes under most rotations. Conversely, even when all three principal moments of inertia are distinct, principal axes are unoriented lines: reversing an eigenvector's sign gives the same axis. Near repeated eigenvalues, small measurement errors can rotate fitted principal axes substantially within the nearly degenerate eigenspace, so quoted directions need an uncertainty assessment as well as quoted principal moments of inertia.
For strictly positive principal moments of inertia and a fixed rotational kinetic energy , the allowed angular velocity components form an ellipsoid:Its semiaxis lengths have units of angular speed. The longest semiaxis corresponds to the smallest principal moment of inertia: that direction permits the greatest angular speed for the same rotational kinetic energy. This is a surface in angular velocity space, not the physical outline of the body. If one principal moment of inertia vanishes in an ideal line-mass model, this constant-energy surface is unbounded in that direction and is no longer an ellipsoid.
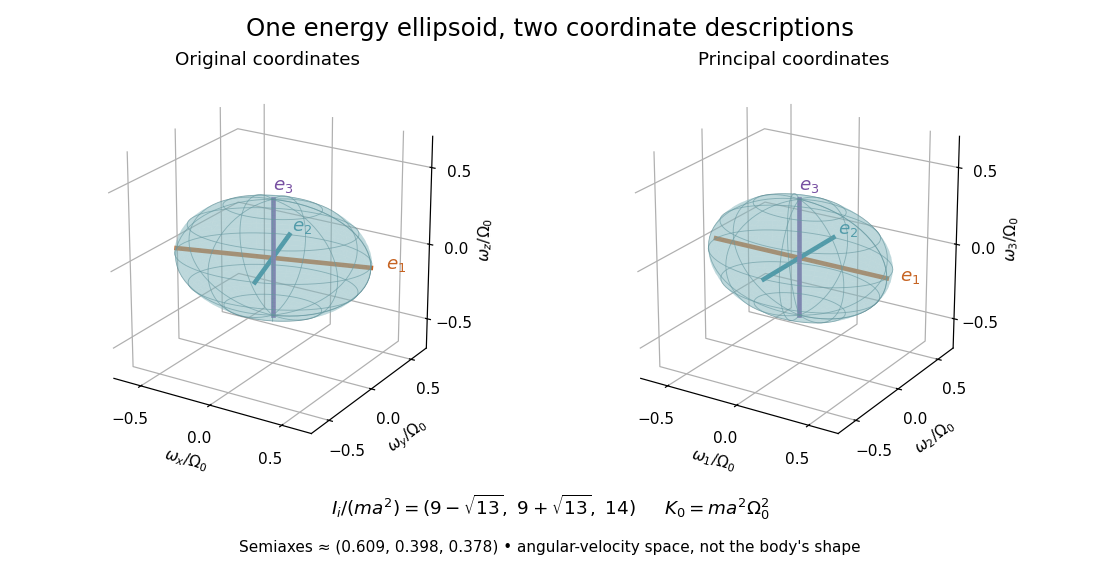
The rotational energy ellipsoid gives the geometry behind Poinsot's ellipsoid, but a constant-energy surface alone does not determine a free-rotation trajectory. A torque-free trajectory must also satisfy the conserved angular momentum constraint and the Euler equations for a torque-free rigid body.
For , the effective principal congruence subgroup is torsion-free. Its modular curve cover of has analytic ramification indices above the two elliptic orbits and the modular cusp. If is its projective index, the numbers of points above these three values are . Applying the Riemann-Hurwitz formula gives . Here for and for ; level one is the identity cover.
The population principal components are centered linear compounds along an orthonormal eigenbasis of the covariance matrix, ordered by decreasing eigenvalue. They are uncorrelated and have variances . Each successive direction maximizes variance subject to unit length and orthogonality to earlier directions. Uncorrelatedness does not imply independence unless additional distributional assumptions hold.
For positive marginal variances, standardizing each variable to variance one converts covariance-based PCA on into correlation-based PCA on . This makes the analysis insensitive to the original measurement units but changes the optimization criterion. Standardization gives small-variance variables the same marginal weight as large-variance variables; it is a modelling choice, not an automatic improvement.
A population principal component explains the displayed fraction of total variance. The first components explain . Comparing covariance and correlation analyses requires different denominators: the original variance sum for the former and the number of nonconstant standardized variables for the latter.
A principal component is the projection of centered data onto a unit eigenvector of its covariance matrix. Ordering the components by their eigenvalues orders their variances. Repeated eigenvalues allow any orthonormal basis of the corresponding eigenspace.
Two conventions occur for principal-component loadings: the unit eigenvector defining a principal component, and the scaled vector . For principal component analysis on a correlation matrix, the entries of the latter are the correlations between each standardized variable and the component scaled to variance one. Indeed, and . Thus , whereas ; reporting the convention avoids confusing component directions with correlations.
A scree plot graphs ordered covariance or correlation eigenvalues against component number. A transition from a steep decline to a flatter tail suggests a dimension, but this is a diagnostic rather than a proof of the number of latent factors. In factor analysis, it should be combined with model fit, substantive interpretation and uncertainty assessment.
Regress a response on selected principal component scores of centered predictors. If is a singular value decomposition and the first positive-singular-value components are retained, the retained score matrix is and the fitted coefficient in predictor coordinates is . The fitted centered response is : this follows by applying the least-squares normal equations to the orthogonal score columns. Truncating small singular directions limits variance amplification, but directions of large predictor variance need not be those best predicting the response; select using prediction assessment rather than explained predictor variance alone.
For and , the two evaluation forms are and , with and . Their dot product is , since every appearing exponent is between one and and the sums of those powers of vanish. Comparing dimensions proves equality with the dual code. In particular, the dual of the unweighted evaluation code has multipliers ; it need not be an unweighted evaluation code on the same ordered points.
With syndromes and distinct error-location values , form and the error locator polynomial . There is an error evaluator polynomial of degree less than the number of errors satisfying the key equation. When the number of errors is at most , the Berlekamp-Massey algorithm or extended Euclidean algorithm recovers these polynomials, normalized by .
In an orientable three-manifold, an embedded nonseparating two-sphere has a product neighborhood. Join its two boundary spheres by an arc outside that neighborhood and take a regular neighborhood of the union. This region is with an open ball removed. Its boundary sphere exhibits the displayed connected sum. Consequently a prime but nonirreducible orientable three-manifold is .
Every closed connected orientable three-manifold is a finite connected sum of prime three-manifolds, unique up to order and the insertion of three-sphere factors. The corresponding fundamental group is the free product of the summand groups. A prime orientable three-manifold is either irreducible or ; this separates aspherical infinite-group cases from the infinite cyclic case.
If all nontrivial zeta zeros satisfy with fixed , the Riemann–von Mangoldt formula gives . The truncated explicit formula for the second Chebyshev function then bounds the error by . Choosing gives the displayed bound and, for every positive , .
// Target: number-theory.bigb
Fix an irreducible polynomial f of degree d with nonzero constant term. In , the number of matrices whose minimal polynomial is a power of f is . The primary matrix centralizer formula is identical to the unipotent centralizer formula over , and summing reciprocal centralizer orders reduces to counting nilpotent matrices by the Fitting decomposition.
Primary ideals can need more generators than the maximal ideal by  Codex 0 Created 2026-10-14 Updated 2026-10-25
In the Noetherian local ring with maximal ideal , the embedding dimension is two but needs generators for every . The degree- monomials generate , and their images form a basis of , so no smaller generating list exists. These ideals are -primary: if and , then cannot be a unit; hence and . Consequently embedding dimension bounds the minimum over all maximal-primary ideals, because the maximal ideal itself is eligible, but does not bound the number of generators of each such ideal.
Pinned article: Introduction to the OurBigBook Project
Welcome to the OurBigBook Project! Our goal is to create the perfect publishing platform for STEM subjects, and get university-level students to write the best free STEM tutorials ever.
Everyone is welcome to create an account and play with the site: ourbigbook.com/go/register. We belive that students themselves can write amazing tutorials, but teachers are welcome too. You can write about anything you want, it doesn't have to be STEM or even educational. Silly test content is very welcome and you won't be penalized in any way. Just keep it legal!
Intro to OurBigBook
. Source. We have two killer features:
- topics: topics group articles by different users with the same title, e.g. here is the topic for the "Fundamental Theorem of Calculus" ourbigbook.com/go/topic/fundamental-theorem-of-calculusArticles of different users are sorted by upvote within each article page. This feature is a bit like:
- a Wikipedia where each user can have their own version of each article
- a Q&A website like Stack Overflow, where multiple people can give their views on a given topic, and the best ones are sorted by upvote. Except you don't need to wait for someone to ask first, and any topic goes, no matter how narrow or broad
This feature makes it possible for readers to find better explanations of any topic created by other writers. And it allows writers to create an explanation in a place that readers might actually find it.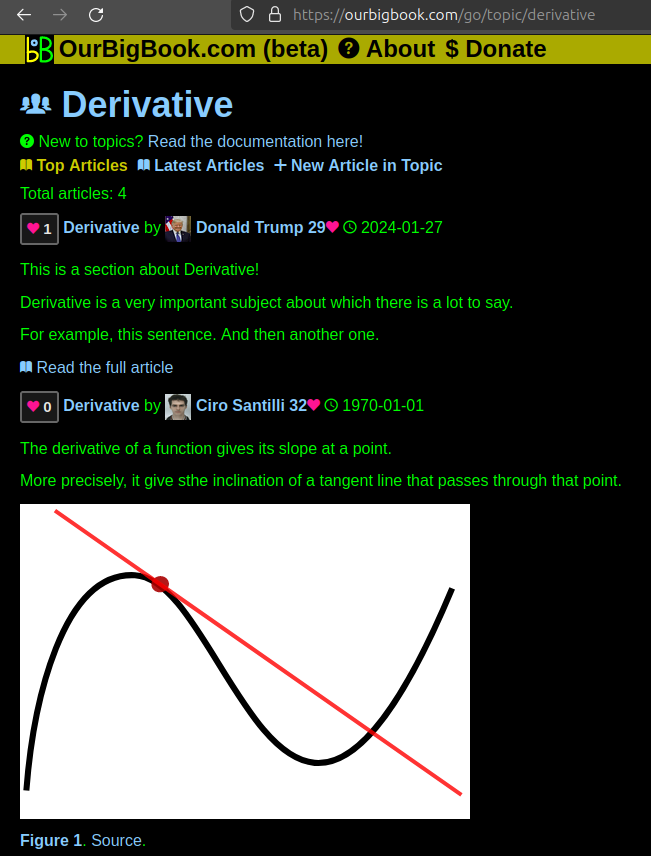
Figure 1. Screenshot of the "Derivative" topic page. View it live at: ourbigbook.com/go/topic/derivativeVideo 2. OurBigBook Web topics demo. Source. - local editing: you can store all your personal knowledge base content locally in a plaintext markup format that can be edited locally and published either:This way you can be sure that even if OurBigBook.com were to go down one day (which we have no plans to do as it is quite cheap to host!), your content will still be perfectly readable as a static site.
- to OurBigBook.com to get awesome multi-user features like topics and likes
- as HTML files to a static website, which you can host yourself for free on many external providers like GitHub Pages, and remain in full control
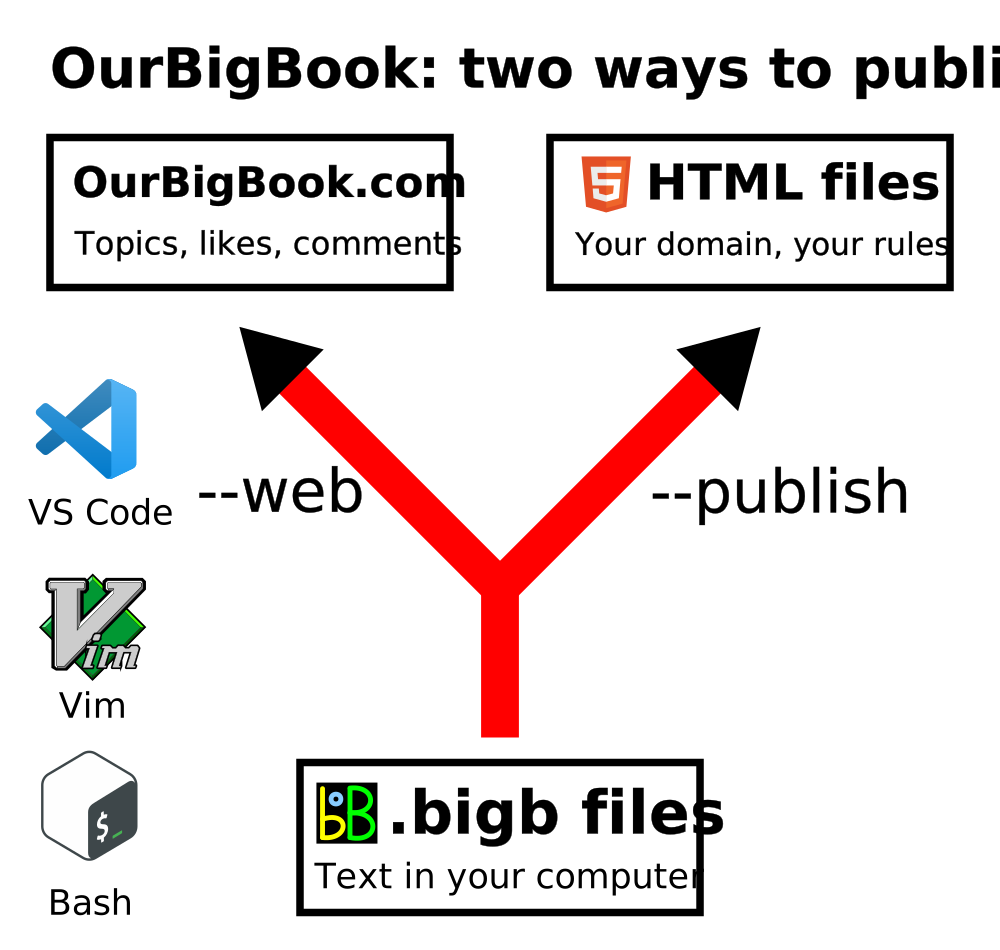
Figure 2. You can publish local OurBigBook lightweight markup files to either OurBigBook.com or as a static website.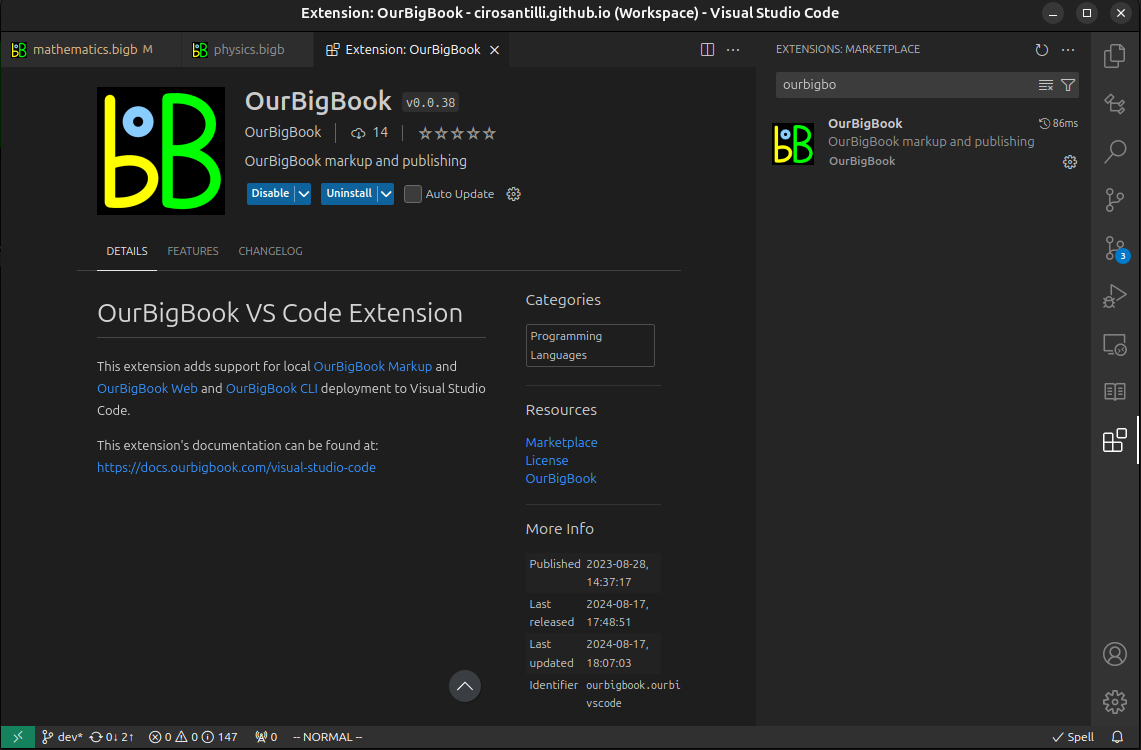
Figure 3. Visual Studio Code extension installation.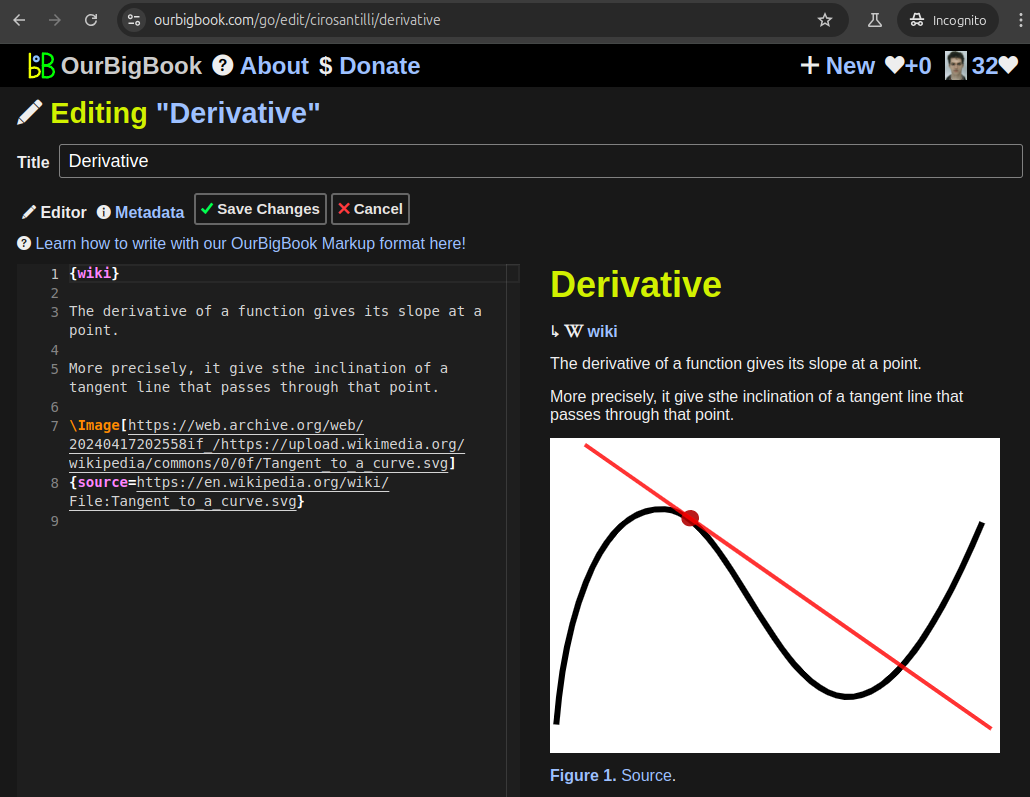
Figure 5. . You can also edit articles on the Web editor without installing anything locally. Video 3. Edit locally and publish demo. Source. This shows editing OurBigBook Markup and publishing it using the Visual Studio Code extension. 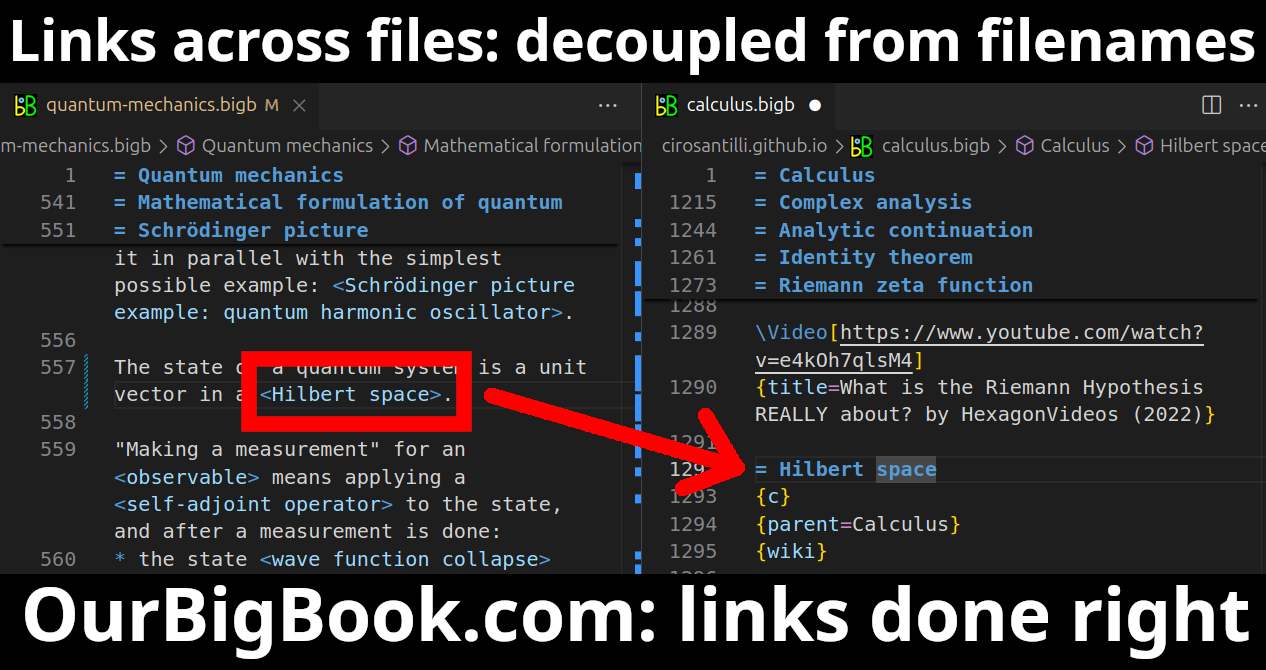
- Infinitely deep tables of contents:
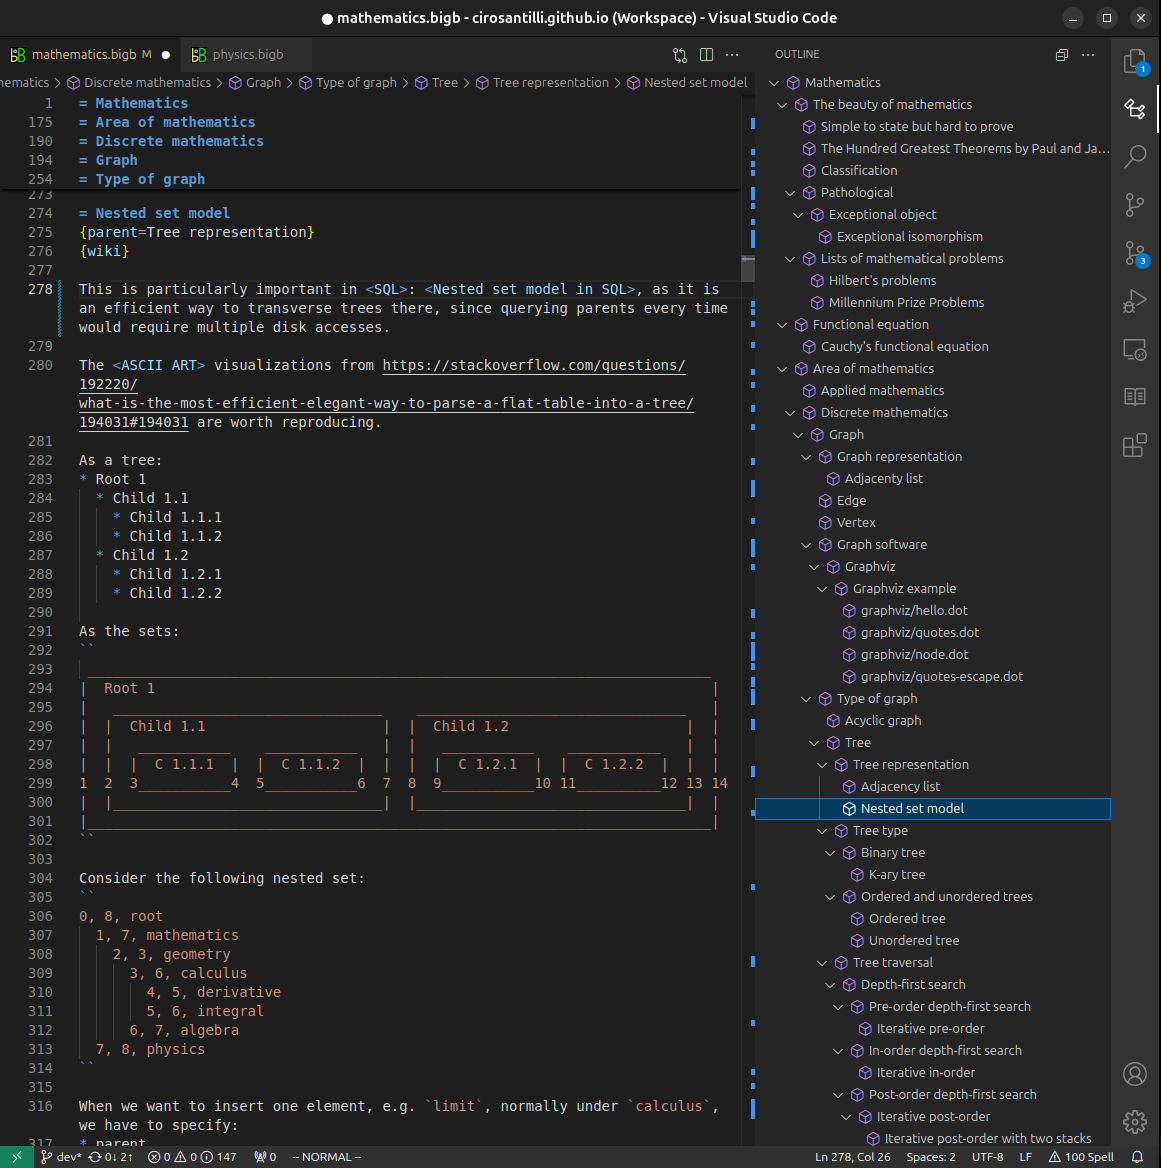
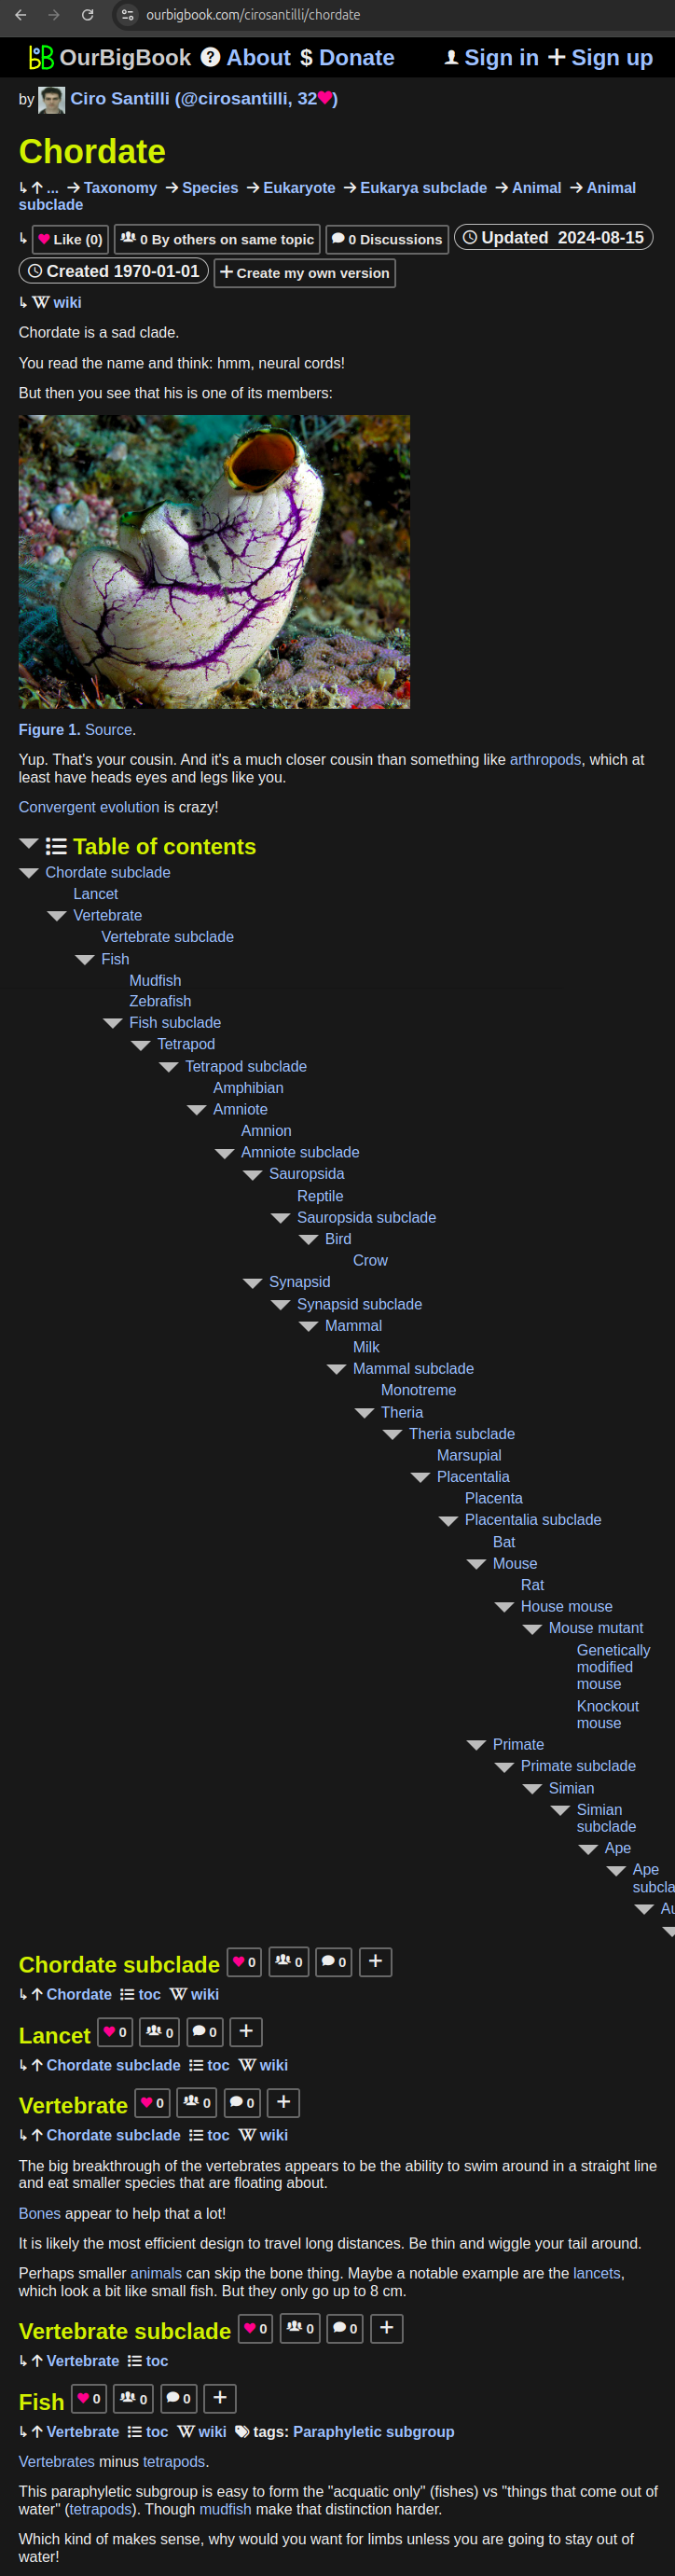

All our software is open source and hosted at: github.com/ourbigbook/ourbigbook
Further documentation can be found at: docs.ourbigbook.com
Feel free to reach our to us for any help or suggestions: docs.ourbigbook.com/#contact