
Rolling without slipping imposes that the contact point is instantaneously at rest, giving v=R omega.
With the convention in which is inclination, is precession, and is body-axis spin, an axisymmetric body's kinetic energy is
The moment of inertia about a specified axis measures how a mass distribution resists changes of angular velocity about that axis. For point masses at perpendicular distances , or a continuous distribution with mass density ,Its SI unit is . The distance is to the entire axis, not to one point on it: moving a point mass along the axis leaves its contribution unchanged. The moment of inertia depends on both the distribution and the chosen axis; it is not determined by total mass alone. About an axis fixed in an inertial frame, a rigid body with larger moment of inertia has smaller angular acceleration under the same net axial torque, and greater rotational kinetic energy at the same angular speed.[ref]
For a simple model, put four equal point masses of total mass on light rigid spokes at radius . Their moment of inertia is . Doubling quadruples the moment of inertia without changing . The illustrated placements and give and . Actual spokes and finite-sized weights contribute their own moments of inertia; the point mass model neglects them. Repositioning weights during rotation also breaks the fixed-distribution assumption, so it requires a separate work and angular momentum calculation.
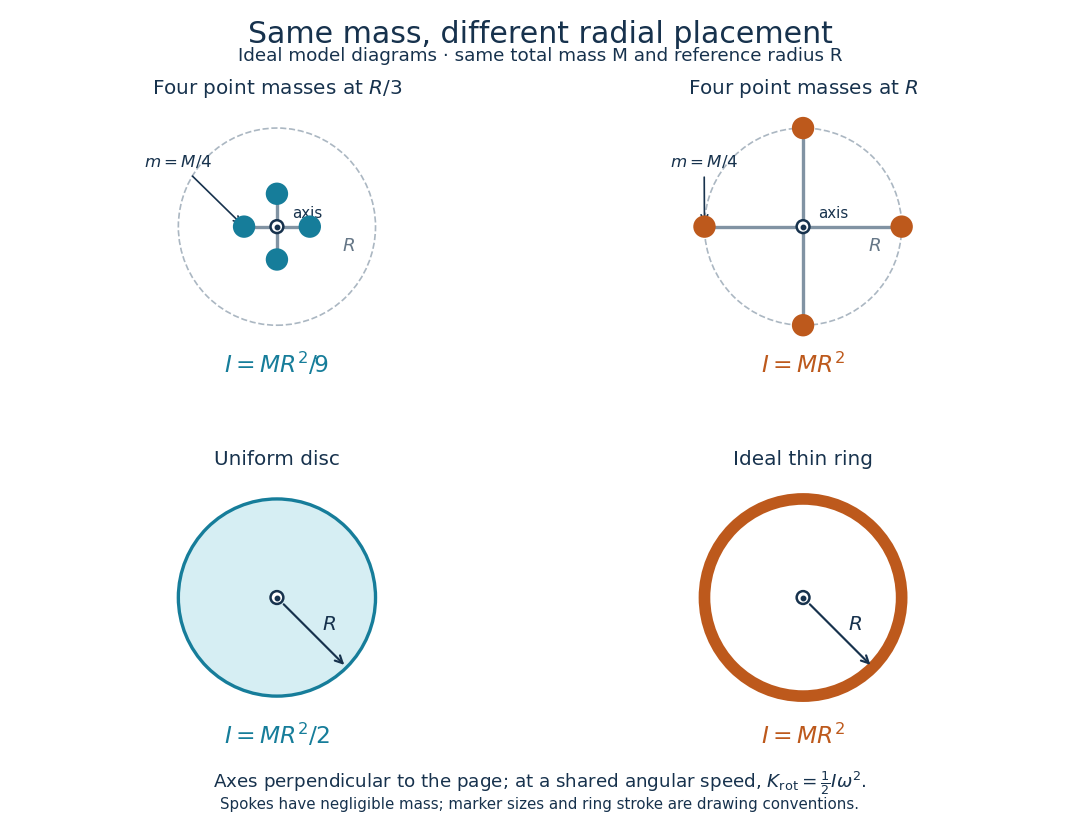
Same total mass, different radial placement and moment of inertia
. Original model diagrams, not experimental data. The upper pair has four equal point masses on negligible-mass spokes, at and from a perpendicular central axis. The lower pair compares a uniform disc with an ideal thin ring of the same mass and outer radius . The displayed moments of inertia determine rotational kinetic energy at a shared angular speed. The visible thickness of the ring and size of the point markers are only drawing conventions. Details.The moment of inertia of a uniform disc follows by dividing it into concentric annuli: and . For an ideal thin ring every mass element is at , so . A ring of finite radial thickness instead uses the moment of inertia of a uniform annulus, , with inner radius . A moment of inertia is thus a compact summary of radial placement rather than a complete description of shape. For several joined pieces, their moments of inertia add only when each is calculated about the same axis.[ref]
A physical pendulum makes the moment of inertia measurable through timing. Martín Monteiro, Cecilia Stari, Cecilia Cabeza and Arturo C. Martí used a metal bar with suspension holes apart and an attached smartphone. They report bar length , bar mass and phone mass . Changing the suspension hole changes the pivot axis. Their readouts were phone gyroscope angular velocity records, analyzed by autocorrelation or a fit to a sinusoid, and an independent photogate; the logged records for the sinusoid fits lasted . They observed agreement between the three timing methods and the geometry-based model, including a minimum of oscillation period as the suspension point varied. These are reported apparatus details and observations, not measurements made for this article.[ref]
To infer a moment of inertia from such a measurement, determine the total mass including every attached part, locate the assembly's centre of mass , and measure its distance below the horizontal pivot . Record successive crossings in the same direction, or the elapsed time for complete oscillations, giving oscillation period . The physical pendulum model with a fixed pivot, a uniform gravitational field, negligible friction and the small-angle approximation givesThe crossing times, masses and geometric distances are the measured inputs; is an inference conditional on this model, while an integral over the assumed shape supplies an independent model prediction. The parallel axis theorem converts the inferred pivot moment of inertia to one about a parallel axis through . The controls and interpretation of that comparison are described there. An axial measurement determines one scalar moment of inertia, not the complete inertia tensor needed for general rotation.
A principal body frame is an orthonormal basis fixed in the body and aligned with the principal axes of its inertia tensor. In this frame the inertia tensor is diagonal with principal moments .
Angular velocity is the vector whose direction gives the instantaneous rotation axis and whose magnitude gives the angular speed.
A symmetric top is a rigid body with two equal principal moments of inertia, conventionally . Its third principal axis is its symmetry axis.
The Weyl tensor is the completely trace-free part of the Riemann curvature tensor. In four dimensions,
For a family of affinely parametrized geodesics with tangent and connecting field , the Jacobi equation in the convention used here isIt describes the relative acceleration produced by spacetime curvature.
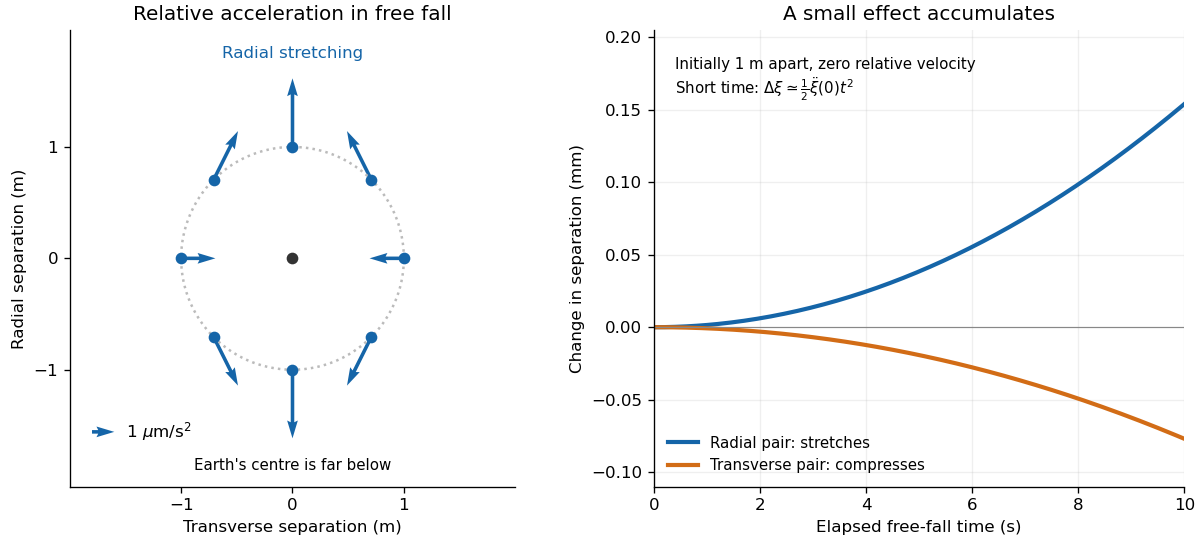
Here describes an infinitesimal separation and the covariant derivatives compare it in a frame transported along the reference geodesic. The Riemann curvature tensor thus becomes something measured with neighboring trajectories. The Newtonian version follows by differentiating gravitational acceleration with respect to position. In the exterior of a spherical mass, let be radial separation and separation in either transverse direction. Newton's law of universal gravitation givesThe upper particle falls less strongly than the lower one, stretching their radial separation; side-by-side particles accelerate toward converging radial directions, compressing their transverse separation. See Oregon State's derivation of tidal acceleration.
For a spherical Earth model with , and , a one-metre radial separation gives ; a one-metre transverse separation gives . Initially comoving particles therefore change separation after one second by approximately : micrometres radially or micrometres transversely. This short-time calculation holds the reference radius fixed to leading order. Its beauty is that common falling motion drops out, leaving a measurable stretching pattern that reveals curvature.


For a rank-two covariant tensor, the derivative commutator contributes one curvature action on each index:
Suppose a contour follows the real axis, closes in the upper half-plane, and avoids each simple real pole by a small semicircle above it. Each indentation is clockwise and tends toIf the large arc vanishes and there are no enclosed poles away from the real axis, the Cauchy principal value is therefore
An indecomposable representation is nonzero and cannot be expressed as a direct sum of two nonzero invariant subspaces. It is an indecomposable module over the associated group algebra or representing algebra.
There are unlisted articles, also show them or only show them.