An autonomous planar system is an ordinary differential equationwhose vector field does not depend explicitly on time.
The nullclines meet at the origin and . At the origin, the Jacobian matrix has trace three, determinant and discriminant , giving an unstable node. At , its determinant is , giving a saddle equilibrium. The horizontal component is positive below the parabolic nullcline and negative above it; the vertical component is positive above the straight nullcline and negative below it. These signs determine the directional regions of the phase portrait.
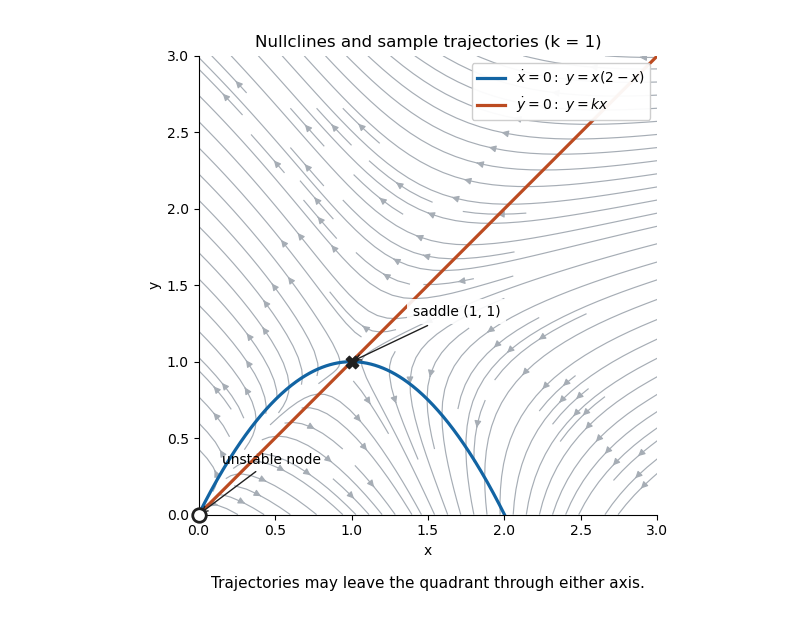

The quadrant is not positively invariant: nonzero points on either axis have an outward-pointing component. Restricting a drawing to that quadrant does not keep its trajectories there. For , only the saddle at the origin remains in the quadrant, and an exponential Dulac multiplier for a quadratic planar system excludes nonconstant periodic orbits there.
The phase plane is the two-dimensional state space of an autonomous planar system. Its oriented trajectories, equilibria, nullclines, and invariant sets display the system's qualitative dynamics.
An equilibrium point of a dynamical system is a state satisfying for an autonomous differential equation . Starting exactly there gives the constant solution . A mechanical equilibrium requires all state derivatives to vanish: a mass momentarily passing through the zero-force position with nonzero velocity is not at an equilibrium point in its full phase plane.
Existence and stability are separate questions. For , the points are all equilibria. The linear derivatives are negative at and positive at zero, giving locally attracting outer states and a repelling middle state. This simple example connects algebraic roots with multistability and distinct basins of attraction. Small perturbations reveal stability; the exact unperturbed equilibrium solution alone does not.
A homogeneous equilibrium in a spatial evolution equation is a steady state independent of position. Its stability against homogeneous perturbations need not imply stability against spatially varying modes.
A hyperbolic equilibrium point is a source when all its eigenvalues have positive real parts. It is a sink equilibrium for the reversed flow. Every sufficiently close nonstationary trajectory leaves its neighborhood in forward time. This is distinct from an external forcing source.
A hyperbolic equilibrium point is a sink when all its eigenvalues have negative real parts. Nearby trajectories converge exponentially to it. In a planar system this includes both stable nodes and stable foci. The condition is stronger than neutral stability: a centre equilibrium is not a sink.
A three-dimensional hyperbolic equilibrium point is a saddle-focus when its eigenvalues include a nonreal pair and a real eigenvalue with the opposite sign of real part. In the displayed orientation it has a one-dimensional unstable manifold and a two-dimensional spiralling stable manifold; reversing time interchanges the stable and unstable dimensions. The ratio controls local transverse contraction in a Shilnikov return map.
For a hyperbolic equilibrium of a smooth planar system, the eigenvalues of the Jacobian matrix determine local stability. If its determinant and trace are positive, both eigenvalues have positive real part and the equilibrium is a repeller.
A planar equilibrium point whose Jacobian matrix has nonreal conjugate eigenvalues with positive real part. Its nearby linearized trajectories rotate while their amplitude grows exponentially; the smooth nonlinear system has the same local qualitative behavior when the equilibrium is hyperbolic.
A node equilibrium with a repeated nonzero real eigenvalue. If the planar Jacobian matrix has a one-dimensional eigenspace, its linearized solutions contain a term and the node is also called improper. A negative repeated eigenvalue still gives asymptotic stability; a repeated value does not by itself indicate a bifurcation.
A node is a planar hyperbolic equilibrium whose two linearized eigenvalues are real and have the same sign. Negative eigenvalues give a stable node; positive eigenvalues give an unstable node. Nearby motion approaches or recedes without the repeated rotation characteristic of a focus.
For , with , solutions are and . Each coordinate decays, while unequal decay rates usually make a trajectory align with the slower direction as it nears the origin. Reversing both signs gives outward motion. Repeated eigenvalues require attention to the number of independent eigenvectors and can add polynomial factors to the exponential response. The node classification describes local behavior near an equilibrium; it does not determine the geometry of remote orbits.
A planar node whose Jacobian matrix has a repeated nonzero real eigenvalue and only one independent eigenvector is an improper node. In suitable real coordinates its linearization of a dynamical system has the displayed form, with solutionsIt is a stable node for and an unstable node for . The factor makes generic trajectories tangent to the unique eigendirection as they approach the equilibrium in the attracting time direction. For a nonlinear autonomous system with this hyperbolic equilibrium, the sign of still determines local stability; the local phase portrait has the same topological type as its linearization.
A focus is a planar equilibrium whose linearization has nonreal complex-conjugate eigenvalues with nonzero real part. The imaginary part produces local rotation, while the real part determines growth or decay of its envelope. A stable focus has negative real part; a focus with positive real part repels nearby trajectories.
The linear system , with and has radius and angular advance . It therefore spirals inward, combining two measurable scales: rotation period and decay time . A damped mechanical oscillator can exhibit this geometry in its position-velocity plane. Eigenvalues with zero real part require a separate nonlinear analysis and are excluded from this hyperbolic focus definition.
A saddle equilibrium in a smooth planar flow has one attracting and one repelling linearized direction. Its Jacobian determinant is negative, so its two eigenvalues are real and have opposite signs. This produces stable and unstable invariant directions rather than uniform attraction or uniform repulsion.
For , with , the axis approaches the origin in forward time and the axis moves away. A generic nearby initial state has a nonzero component and eventually leaves, even if its distance initially decreases. In a nonlinear system, the corresponding stable manifold and unstable manifold curve away from their tangent eigendirections. Such manifolds can form a separatrix between different kinds of motion, making a saddle important for global outcome selection as well as local instability.
A center equilibrium of a planar dynamical system is surrounded by closed nonstationary trajectories. Nearby initial states remain nearby, giving Lyapunov stability, but they do not converge to the equilibrium. The motion is consequently not asymptotically stable.
An undamped harmonic oscillator gives , , with conserved curves . Each nonzero small energy selects a periodic ellipse around the origin. This physical energy storage explains why there is continued oscillation rather than inward spiralling. Purely imaginary linearized eigenvalues alone do not prove a nonlinear center: nonlinear terms can slowly increase or decrease the amplitude. The surrounding closed-orbit property concerns the full dynamics, not just the first-order linear approximation.
Let be a continuously differentiable planar vector field with an isolated equilibrium point , and let the twice continuously differentiable first integral satisfy and . If the Hessian matrix is positive or negative definite, then is a centre equilibrium.
For a positive-definite matrix, sufficiently short rays from have strictly increasing with radial derivative bounded below by a positive constant times distance. Every sufficiently small positive level difference therefore meets each ray exactly once, and the implicit function theorem makes these intersections a simple closed curve. These regular level sets shrink to ; use in the negative-definite case. The vector field is tangent and nonzero on each such compact curve. Its speed is bounded away from zero, so a traversal takes finite time and each curve is a periodic orbit. An arbitrary strict local extremum without these regularity and nondegeneracy conditions does not by itself supply this argument.
A planar equilibrium is a stable node when its two Jacobian eigenvalues are real and negative. Every nearby trajectory approaches it, tangent asymptotically to an eigendirection.
A planar equilibrium is an unstable node when its two Jacobian eigenvalues are real and positive. Every nearby nonstationary trajectory moves away from it in forward time.
A planar equilibrium is a stable spiral when its Jacobian has a complex-conjugate pair of eigenvalues with negative real part. Nearby nonstationary trajectories spiral toward it.
Articles by others on the same topic
There are currently no matching articles.