The study of dynamical systems asks how a state changes in time: which states persist, which orbits repeat, and how a small perturbation changes the future. A dynamical system combines a state space with an evolution rule. For a seasonal population, the state might be its abundance and one step one generation; for a harmonic oscillator, a state vector includes both position and velocity. Choosing a sufficient state is essential: position alone does not determine where an oscillator moves next.
The two basic descriptions are a discrete dynamical system, , and an ordinary differential equation, . Repeated iteration of a map gives ; an autonomous differential equation with unique solutions gives a flow map . In either case, evolving for two successive durations agrees with evolving for their sum. The logistic map provides a particularly simple discrete dynamical system; the Lorenz system supplies a continuous-time example with a very different geometry.
Deterministic evolution says that the exact rule and exact initial condition specify one future. Predicting that future from measurements is a separate question. An instrument supplies a range of possible initial conditions, and a computation adds small errors. Near an asymptotically stable fixed point, nearby orbits converge and the long-term state can become easier to predict. With sensitive dependence on initial conditions, arbitrarily close starting states can eventually lead to a visible disagreement, even though each follows the same rule.
Much of the usefulness of dynamical systems comes from describing outcomes without writing every solution explicitly. Fixed points identify possible resting states; periodic orbits identify repeating behaviour; stability theory asks whether those behaviours survive small disturbances. A bifurcation diagram shows how changing a bifurcation parameter changes the possible outcomes. This is useful in population dynamics, where a stable abundance and an alternating abundance have different consequences, and in thermal convection, where a steady flow and a changing flow transport heat differently.
The beauty of the subject is that a small formula can organize a large variety of behaviour. The logistic map moves from an attracting fixed point to attracting periodic orbits and then to parameter values supporting sensitive motion. Its period-doubling cascade has a recognizable structure across many unimodal maps. Nevertheless, Devaney chaos, Glendinning chaos, and a positive Lyapunov exponent express different properties; a claim of chaos should specify its definition, its state space, and the parameter values under consideration.
Chaos describes sustained irregular behaviour in a deterministic dynamical system, with precise definitions emphasizing different features. Deterministic evolution fixes the future from an exact initial condition; sensitive dependence on initial conditions concerns what happens when that condition is changed by a small amount. These are compatible properties.
For a continuous map on an invariant set, Devaney chaos requires topological transitivity, dense periodic points and sensitive dependence on initial conditions. The invariant set and its topology are part of the claim. Other conventions use properties of an invariant probability measure or numerical Lyapunov exponents; those conventions are not universally equivalent.
A positive largest Lyapunov exponent indicates exponential separation along a trajectory, but alone does not prove every topological definition of chaos. For example, the map has the fixed point , with derivative two and Lyapunov exponent . The orbit stays at one forever. On the singleton invariant set there are no distinct nearby states to separate, and the restricted system is not sensitive. Expansion transverse to a chosen invariant set must not be confused with complicated motion within it.
Numerical evidence should therefore specify the map or vector field, the bifurcation parameter, the relevant invariant set and the property actually measured. A visually irregular phase portrait can motivate a claim, while a proof must establish the chosen definition.
The softening Rayleigh-Duffing oscillator obeysThe restoring force weakens as displacement grows, while the cubic velocity term dissipates energy. Writing gives the planar autonomous differential equation , .
The three equilibrium points are and . At the origin, the characteristic polynomial is , so the eigenvalues cross the imaginary axis at . At either outer equilibrium the Jacobian matrix has determinant , making it a saddle point for every real .
The mechanical energyhas the exact time derivative . For the linear damping removes energy; for it injects energy at small velocities, while cubic damping removes it at larger velocities. Near the origin, averaging over the leading harmonic oscillator motion , givesHere the cubic restoring term changes the leading phase evolution but contributes zero average energy input. The negative cubic amplitude coefficient gives a supercritical Hopf bifurcation as crosses zero, with small stable cycles satisfying for .
This local calculation does not locate the later global changes in the softening Rayleigh-Duffing phase portrait. In particular, a heteroclinic cycle and a saddle-node bifurcation of periodic orbits are different events. The quartic potential is unbounded below, so the energy formula also does not establish that every initial state has bounded motion.
With , a stable cycle grows from the origin. At , symmetric saddle connections form a repelling heteroclinic cycle, while the stable inner cycle persists. Just above it an unstable outer cycle coexists with the stable one; they merge at in a saddle-node bifurcation of periodic orbits. These approximate values follow from the half-return equations , with at the fold, and saddle-manifold shooting at the connection. A coarse parameter scan can miss the narrow coexistence interval. The saddle eigenvalue ratio is below one at the connection, proving that the loop is repelling and preventing identification of the stable cycle's disappearance with that connection.
The Kuramoto model couples phase oscillators through their phase differences:Here is the natural frequency and measures attractive coupling. Equal coupling between every pair gives the exact collective form in terms of the Kuramoto order parameter.[ref]
For example, with two phase oscillators, put . Subtracting their equations gives . A stable fixed phase difference exists when , on the branch with . Thus synchronization of oscillators can give equal observed frequencies even when their uncoupled natural frequencies differ. Equality is the marginal locking threshold, rather than a hyperbolic stable state.
For a large population, the Kuramoto self-consistency equation tests stationary collective states. The finite two-oscillator threshold and the continuum threshold concern different frequency populations and should not be substituted for each other.
For phases , the Kuramoto order parameter is their complex centroid on the unit circle:The triangle inequality gives . Equality requires all phase vectors to point in the same direction. When , is the complex argument of ; it is undefined at .
Zero does not specify a unique phase distribution. For example, the four phases give , while give . The first has two clusters and the second is evenly spread. A first complex moment cannot recover every detail of a distribution.
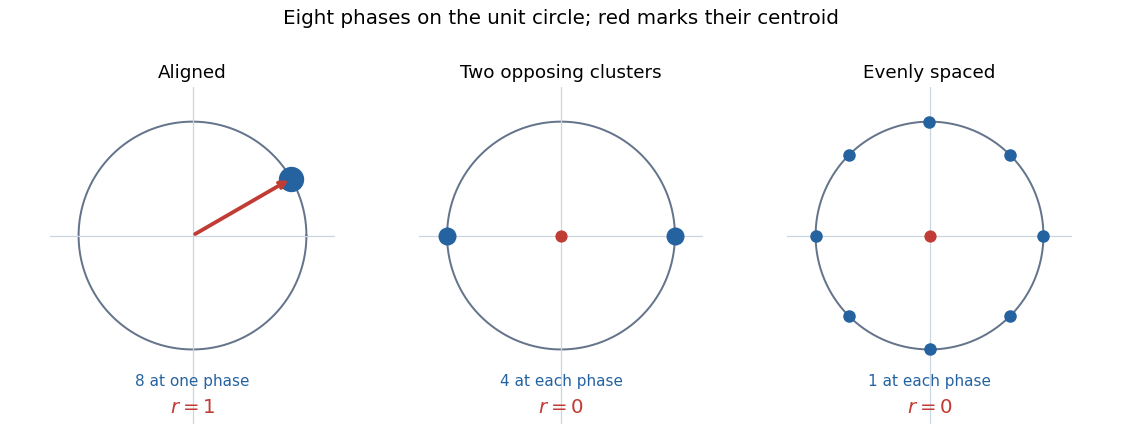
The Kuramoto order parameter distinguishes complete phase alignment but gives zero for both opposing clusters and evenly spaced phases
. Details. Multiplying by and taking the imaginary part givesThis identity rewrites all pairwise terms of the Kuramoto model using two collective real variables. It remains valid at when expressed as , without assigning a nonexistent complex argument to zero.
Consider the continuum Kuramoto model with an even probability density function . Seek a stationary Kuramoto order parameter in a frame with . For , phase locking gives on the stable branch, so locked phase oscillators contributeDrifting phase oscillators have stationary angular density proportional to . Their real contribution integrates to zero as a periodic logarithmic derivative; their imaginary contributions cancel between and .[ref]
Substitution and division by yieldThe incoherent state of the Kuramoto model must be retained separately before division. If is continuous with , any nonzero stationary branch reaching at a finite coupling must satisfyIndeed, the integral tends to . This limiting stationary calculation alone does not establish the branch's stability, its global existence, or the first instability of a multimodal frequency population.
The incoherent state of the Kuramoto model has a uniform conditional phase density, , in the continuum population description. Its Kuramoto order parameter vanishes because : individual phases cancel even though the oscillators keep moving.
The mean-field coupling then vanishes, so a uniform density remains uniform while each frequency class rotates. This state must be retained separately when deriving a self-consistency equation by dividing by a nonzero order parameter. A finite random sample generally has a small nonzero empirical order parameter; this fluctuation is not a contradiction of the continuum definition.[ref]
From Kuramoto to Crawford: exploring the onset of synchronization in populations of coupled oscillators by Steven H. Strogatz. Sections 3–5, continuum density and incoherence
The Rössler system is the three-variable autonomous differential equationIts only nonlinear term is the quadratic product . The planar rotation in the first two variables interacts with the third variable through that term, allowing behaviour much richer than a linear harmonic oscillator. Otto Rössler introduced the model as a simple setting for continuous-time chaos.[ref]
An equation for continuous chaos by Otto Rössler. 1976 paper, abstract: one quadratic nonlinearity and a folded return map
Its equilibrium points can be calculated without integrating an orbit. The first two equations give and ; the third then reduces to . When , the real equilibria therefore correspond toprovided . A repeated quadratic root gives one equilibrium; a negative discriminant gives none. The case is obtained directly from the linear equation , without dividing by .
The Jacobian matrix at a general state iswith divergence . These formulas test local stability and local volume contraction. Their signs alone do not establish the global folding and return required for a Rössler attractor.
A Rössler attractor is a chaotic attracting invariant set occurring in a Rössler system at suitable parameter values. The model was designed to combine continuous-time motion with a folded Poincaré map.[ref]
The distinction between local and global information is essential. An unstable spiral can stretch nearby trajectories apart during one part of an excursion. To sustain bounded irregular motion, the trajectories must also return through the global phase portrait. A local Jacobian matrix describes the stretching near a point; it does not determine where trajectories go after leaving that neighborhood.
Numerically, a useful diagnostic is to record consecutive intersections with a transverse section and plot the resulting Poincaré map. A folded shape suggests how stretching and return interact, but a finite point cloud does not itself prove an invariant set, an attracting neighborhood or a rigorous definition of chaos. The parameter values, section and discarded transient should accompany such a computation.
An attractor is an invariant set approached by nearby trajectories of a dynamical system. A useful precise convention is a compact invariant set that is Lyapunov stable and attracts some open neighborhood: starting sufficiently close keeps the trajectory close for all future times, and the distance to the set tends to zero. Definitions differ over the stability, uniformity and minimality conditions, so those conditions should be stated when they affect an argument.
For the discrete dynamical system on , the fixed point zero is an attractor. If , then ; if is small, every later value is at least as small. Its basin of attraction is exactly . The other fixed point, one, is invariant but repelling: its derivative is two, and arbitrarily close starting values can move away.
An attracting limit cycle is an attractor consisting of a whole repeating orbit. A trajectory can approach that set while continuing to move around it, so attraction to a set does not mean convergence to one stationary point. A strange attractor can have more complicated geometry; attracting nearby trajectories alone does not imply chaos.
Attraction in a dynamical system means convergence of nearby forward trajectories toward a specified invariant state or set. Attraction and Lyapunov stability are separate properties; together they give the usual local asymptotic stability of an equilibrium.
A strange attractor, in the geometric convention, is an attractor whose structure is irregular or fractal rather than a smooth point, cycle or torus. The geometry concerns the set of possible long-term states. Chaos concerns evolution on that set. Some authors include chaos in the meaning of strange, so the convention must be stated.
The separation matters because the same plot cannot answer every question. A box-counting dimension calculation asks how many boxes are needed to cover a set as their size decreases. A Lyapunov exponent calculation follows the growth of a perturbation along a trajectory. These measure different features, and neither number can be substituted for the other.
Strange nonchaotic attractors provide the explicit warning: geometrically complicated attraction can occur without a positive Lyapunov exponent. The original construction used systems driven by two incommensurate frequencies.[ref]
Strange attractors that are not chaotic by Celso Grebogi and others. 1984 paper, abstract: geometric strangeness is distinguished from exponential orbit divergence
Thus fractal-looking geometry alone is insufficient evidence for a chosen definition of chaos.A strange nonchaotic attractor combines geometrically irregular attraction with no positive Lyapunov exponent for the dynamics under consideration. Systems driven at two incommensurate frequencies supplied the original examples.[ref]
Strange attractors that are not chaotic by Celso Grebogi and others. Abstract and opening definitions, Physica D 13 (1984), pages 261–268
One useful framework is a skew productThe base is an irrational rotation of the circle. An attracting invariant graph of a skew product obeys ; the geometric question concerns how irregular that graph is. For a differentiable one-dimensional fiber map, the fiber Lyapunov exponent along it is, when the limit exists,A negative value describes average contraction of perturbations within the fiber. The base rotation has a neutral exponent, so a negative fiber exponent does not mean that every exponent of the full forced system is negative. Under appropriate boundedness and integrability assumptions for this triangular derivative system, the full largest exponent is zero rather than positive.
These equations specify a framework, not a claim that every choice of produces a strange attractor. For instance, with has the smooth attracting graph . A negative fiber exponent alone therefore establishes neither geometric strangeness nor a discontinuous graph.
An equation specifying how a system changes with time, such as an ordinary differential equation for position and velocity or the Schrödinger equation for a wave function. Its solution depends on its specified initial conditions.
A modeling approach using stocks, flows and feedback to investigate coupled systems over time. Computer simulations can explore delayed responses and the consequences of different model assumptions.
A system dynamicist studies feedback and time evolution using system dynamics models. Stocks describe accumulated quantities and flows describe their rates of change, while feedback links the rates to the current system state.
For a simple stock with inflow and proportional outflow , the model is . Its equilibrium and adjustment timescale follow from the equation. A useful model also states the evidence and assumptions behind the chosen feedback relationships.
Physicist and coauthor of The Limits to Growth by Donella H. Meadows and others.
Biophysicist and coauthor of The Limits to Growth by Donella H. Meadows and others.
Let be a smooth diffeomorphism and a compact invariant set. It is uniformly hyperbolic if its tangent spaces have a continuous splitting preserved by the derivative, with constants and such thatThe same constants must work for every . Thus the stable directions contract forward and the unstable directions contract backward, uniformly over the set. A sign observed in a finite-time numerical Lyapunov exponent calculation does not establish these uniform estimates.
For the cat map on a two-dimensional torus, the constant matrix has eigenvalues . Its two eigenvectors give fixed stable and unstable directions; the smaller eigenvalue is the reciprocal of the larger. With the flat Euclidean metric, and give the required estimates everywhere. The whole torus is therefore hyperbolic.
A Smale horseshoe supplies a different example: its hyperbolic invariant set contains infinitely many saddle periodic orbits, yet need not attract a neighborhood. Hyperbolicity describes stretching and contraction, while being an attractor concerns nearby trajectories. For a nonsingular flow map, the analogous splitting also has the neutral direction along the vector field; it should not be omitted by copying the map definition unchanged.
A Smale horseshoe is a compact hyperbolic invariant set of a smooth map with expanding and contracting directions and at least two strips that stretch across a common rectangle. Iterating the strips and their inverse images produces a Cantor-set product on which the dynamics are conjugate to a full shift. It supplies infinitely many saddle periodic orbits and chaotic itineraries; hyperbolicity alone does not make it an attracting invariant set. The geometric construction explains why phase-dependent reinjection near a Shilnikov bifurcation can create chaos even when the associated symmetric amplitude equations have no such mechanism.
For a linear group action of on a state space, an equivariant dynamical system has a vector field satisfyingThus applying a symmetry before computing a velocity gives the same result as applying it to the computed velocity. An equivariant vector field need not be invariant as a vector: its value transforms along with the point where it is evaluated.
If the ordinary differential equation has unique solutions, its flow map obeys whenever both sides exist. Indeed, has derivative and starts at , so Picard-Lindelöf theorem identifies it with .
Consequently, every subgroup's fixed-point subspace of a group action is invariant under the flow map. If for all in the subgroup, then . This reduces some symmetry-preserving motions to a smaller state space. It also constrains normal forms: the wavevector selection rule for equivariant monomials and the cubic equivariants of the full cube symmetry group are concrete coefficient tests.
Let a translation symmetry with displacement act on nonzero complex Fourier modes byEach phase changes by . Therefore a real linear combination of locally unwrapped phases, , is unchanged exactly when . This is a kernel of a linear map calculation for the matrix whose columns are the wavevectors.
A globally defined expression on angular phases requires more care: is independent of the representatives chosen modulo precisely when every is an integer. The globally defined translation-invariant characters therefore satisfy both and . An arbitrary real vector in the matrix's kernel of a linear map gives a local unwrapped invariant, but need not give a single-valued function of the angular phases.
For example, take four planar wavevectors , , and . The two independent angular combinations are and , each interpreted modulo . Translations can set the first two phases to zero; the other two then equal these combinations.
More generally, when four planar wavevectors span a common reciprocal lattice of rank two, their translation action has a closed two-dimensional torus as its image and the quotient of the four-phase torus is two-dimensional. Real rank two alone guarantees only two local independent combinations; without a commensurability condition, the translation image can be dense in a larger torus. At zero amplitude, a phase is undefined, so smooth centre manifold equations should first use real parts and imaginary parts of the complex amplitudes.
Consider complex Fourier modes transforming under a translation symmetry as . A monomialtransforms by multiplication with . It can occur in the equation for of an equivariant dynamical system only ifThis follows because must transform with the same wavevector as . The condition enforces translation equivariance; other symmetries can impose additional restrictions on the polynomial coefficients.
Writing , a monomial with total polynomial degree and a prescribed integer vector exists exactly when and is an even integer. To prove this, write and with nonnegative integers . Then . Conversely, any nonnegative even surplus can be distributed among the .
For one nonzero wavevector, a cubic term in its own equation must have and , giving . With several Fourier modes, a relation instead permits the quadratic term in the third equation. The wavevectors decide whether this resonant interaction is possible before any polynomial coefficient is calculated.
For the natural action of all signed coordinate permutations on , a cubic equivariant dynamical system has componentsReflecting alone reverses component , so that component must be an odd function of . Reflecting any other coordinate leaves component fixed, so it must be an even function of each other coordinate. Consequently the only cubic monomials are and . Permuting the other coordinates makes their coefficients equal; permuting all coordinates gives the same pair in every component. The same parity test excludes every quadratic term.
A branch with exactly nonzero coordinates of common magnitude satisfiesThus its nonzero states require , provided the denominator is nonzero. The three cases describe coordinate-axis, face-diagonal and body-diagonal states. If the denominator vanishes, the cubic truncation cannot determine that branch's amplitude; higher-order terms must be retained. Existence of a branch does not by itself determine its stability.
At a nondegenerate equivariant Hopf bifurcation, each complex axial isotropy subgroup of the spatial group combined with temporal phase gives a branch of periodic solutions with that spatiotemporal symmetry. Assumptions include an isolated semisimple imaginary critical pair of the required representation type, transverse parameter crossing, and a nonzero cubic coefficient on the fixed-point plane. The statement guarantees existence and symmetry type, not stability or which parameter side contains every branch.
A primary periodic branch whose phase advance is compensated by a spatial rotation. For the natural plane representation, the spatial pattern rotates rather than remaining on a fixed reflection axis. Opposite chiralities are exchanged by reflection.
// Target: dynamical-systems.bigb
A primary periodic branch retaining a spatial reflection at every time. In the natural plane representation, each real-copy component oscillates along a fixed reflection axis. The fourfold dihedral case has distinct axial and diagonal standing-wave types.
// Target: dynamical-systems.bigb
In Hopf coordinates where the rotation acts as , reflection swaps components, and temporal phase multiplies both equally, cubic equivariance permits precisely the three displayed monomials in the first component. Swapping indices gives the second equation, with the same complex coefficients. The rotating, axial standing, and diagonal standing branches are , , and . Their squared component amplitudes are , , and , respectively, when positive.
// Target: dynamical-systems.bigb
Spatially complex coordinates on two real copies need not both have the same temporal phase weight. If their time-circle action is , conjugating the second coordinate gives a common Hopf phase. The linear terms then have the same imaginary frequency in coordinates but opposite imaginary frequencies in the original coordinates. Failing to make this conjugation produces amplitude equations inconsistent with the specified symmetries.
// Target: dynamical-systems.bigb
A spatial group element combined with a time shift may preserve a periodic orbit even if the spatial element alone does not fix it at each instant. The temporal circle acts complex linearly on Hopf amplitudes. Complex axial isotropy subgroups identify the primary branches guaranteed by the equivariant Hopf theorem.
// Target: dynamical-systems.bigb
For the action , and common phase multiplication, the fifth-order normal form has first component and second component obtained by swapping indices. Here all coefficients may be complex. Its three primary symmetry types are a one-component rotating wave and the two standing-wave lines and , together with their group conjugates. The two standing amplitudes split at fifth order through .
If only reflection and common temporal phase remain, the linear complex matrix is . The symmetric and antisymmetric modes have eigenvalues and , generically separating their Hopf thresholds. One-component rotating-wave axes are no longer invariant. Their hyperbolic finite-amplitude periodic solutions can persist as mixed-mode solutions, often through secondary symmetry-breaking bifurcations, while the double primary onset splits into two simple Hopf onsets. Coefficients determine the detailed secondary diagram and stability.
For an absolutely irreducible real symmetry representation, an equivariant steady-state bifurcation with a simple transverse crossing of the scalar linear eigenvalue generically has an equilibrium branch for each axial isotropy type. Restricting the vector field to its one-dimensional fixed-point subspace reduces the existence problem to a scalar bifurcation equation. The lemma guarantees these branches; it does not exclude branches with smaller isotropy or higher-dimensional fixed-point subspaces.
The normalizer of an axial isotropy subgroup preserves its one-dimensional fixed-point subspace of a group action. If its quotient by the isotropy contains an element acting as minus one, the reduced scalar vector field is odd, forcing a pitchfork bifurcation rather than a generic quadratic branch. For odd dihedral groups the reflection normalizer has no such quotient; an even-degree anisotropic term can distinguish the two half-axes at higher order.
// Target: algebra.bigb
For the natural plane action of the dihedral group, rotations constrain monomial weights and reflection makes coefficients real. The reflection axes support the bifurcating equilibria. For , the quadratic anisotropic term gives three transcritical-like branches that are saddles in the full plane. For , cubic isotropic and anisotropic terms determine two reflection-isotropy classes. For , the cubic isotropic term sets the leading radial amplitude while quartic anisotropy separates stable and saddle angular classes.
// Target: dynamical-systems.bigb
Independent sign changes and interchange of two coordinates in the natural dihedral group action force the displayed cubic normal form. Apart from the origin, its nondegenerate small equilibria lie on coordinate axes or on the diagonals. An axial branch has squared amplitude and eigenvalues . A diagonal branch has component squared amplitude and eigenvalues . Subtracting the two nonzero equilibrium equations gives , excluding other cubic branches when .
For the four wavevectors and their negatives, use invariant phases , . Add to the cubic normal form of a dynamical system the two quintic terms and in the first equation, together with their square-symmetry partners; are real. For equal positive magnitudes, steadiness forces unless . Equality of radial equations further gives . Consequently the generic phase types are and . When , the mixed type , equivalent by square symmetry to , also exists. When both quintic coefficients vanish, every phase pair is allowed. Amplitude existence must still be checked from the remaining scalar equation.
A scalar mode that changes sign under a quarter-turn and is fixed by diagonal reflections couples quadratically through . In the saturated three-mode equivariant dynamical system, a diagonal state , has and . The symmetric perturbation decays at rate ; the remaining stability matrix is the displayed block. With , its linear stability interval is , provided . The endpoints are a symmetry-breaking pitchfork bifurcation and a Hopf bifurcation, respectively, away from degeneracies.
A relative equilibrium is a solution moving only through a continuous group action: its shape is stationary after the symmetry motion is removed. If a one-parameter subgroup is written , the solution has the form . Its image lies on a single group orbit, and quotienting by the symmetry turns it into an ordinary equilibrium point.
For example, the ordinary differential equationis equivariant under . At , writing gives and . Thus is stationary in the quotient, while rotates in the original state space. When this is a periodic orbit; when each point on the circle is an ordinary equilibrium point.
A relative equilibrium need not be periodic. A steadily translating pattern on an infinite line has a fixed profile in its moving frame but never returns to the same laboratory position. The rotating point-vortex relative equilibrium is the corresponding idea for rigidly rotating vortex configurations.
For identical point vortices on the plane, use , , and . The generator of simultaneous counterclockwise rotations is , and is its moment map with the convention . In coordinates rotating with angular velocity , the Hamiltonian vector field is . Hence a collision-free configuration rigidly rotating at that velocity is exactly a critical point of the augmented Hamiltonian function . For , scaling all positions shows ; a rotating relative equilibrium therefore obeys . For this implies positive in the stated circulation convention. Reversing the contraction convention requires consistent changes to the Hamiltonian and rotation signs.
For a smooth autonomous differential equation and a hyperbolic equilibrium point , the unstable manifold consists of points whose backward trajectories approach :where the backward solution must exist for all negative time. The local unstable manifold additionally requires that the backward trajectory remain in a chosen small neighborhood. The global unstable manifold is obtained by following this local set forward as far as the flow map exists.
Its tangent space at is the real sum of the generalized eigenspaces of the Jacobian matrix with eigenvalues of positive real part. Generalized eigenspaces are needed when the matrix is not diagonalizable. Nonreal eigenvalues occur in conjugate pairs, together contributing a real invariant plane. The stable manifold uses negative real parts and convergence in forward time.
A nonlinear example shows why the tangent space alone is insufficient. For , , the curve is invariant because its time derivative is . On this curve and approach zero backward, so it is the unstable manifold. It is tangent to the -axis at the origin, but it is not that axis. In fact obeys , so every point off the curve fails to approach zero backward.
A local transverse section to a flow is mapped back to itself by the next intersection of an orbit. Fixed points represent periodic orbits, and the derivative of this return map determines their transverse stability.
For , , use the section modulo and . Exact resonance produces the secular term , giving the displayed return translation. Nonzero forcing makes every section orbit unbounded. At zero forcing the map is the identity. The assumption is essential: at zero frequency no transverse phase section exists and the motion is constant-acceleration or free-particle motion.
For , , use entry and exit . If , , integration gives . A smooth global return has . If , its derivative vanishes as , and a small yields an attracting fixed point. If , the passage is . For small parameters the resulting global return is strongly contracting, with an attracting fixed point near on either side of zero.
If a planar equilibrium with purely imaginary linear eigenvalues has radial return map , then gives nonlinear attraction and gives repulsion. Vanishing linear decay therefore does not imply a centre.
The Routh-Hurwitz criterion tests whether all roots of a real polynomial have negative real part, by sign conditions on determinants formed from its coefficients. Applied to a characteristic polynomial, it gives an algebraic test for strict linear asymptotic stability.
Consider the real family with fixed . The Routh-Hurwitz criterion reduces its nontrivial determinant to . Strict decay for every finite is equivalent to the displayed inequalities: the constant and slope must be nonnegative, with at least one positive, and coefficient positivity requires . The stricter chain is sufficient but excludes valid equality cases. Neither equality case guarantees a uniform decay margin as tends to zero or infinity. At there is no asymptotic attraction.
A real Jacobian matrix has both eigenvalues in the open left half-plane exactly when its trace is negative and its determinant is positive. At zero trace the test no longer determines nonlinear stability.
A heteroclinic orbit is a trajectory tending to one invariant equilibrium or orbit in backward time and a different one in forward time. Coupled convection amplitudes can have such trajectories describing replacement of one convection roll orientation by another.
A heteroclinic cycle is a closed chain of invariant states joined by heteroclinic orbits. For three equilibrium points , the connections can run . The cycle consists of those connections and their limiting equilibria; it is not a single periodic orbit completing a circuit in finite time.
Nearby trajectories can spend long intervals close to one equilibrium before switching to the next. In convection-amplitude models this can describe successive convection roll switching. Whether trajectories remain near the chain depends on both local expansion and contraction rates and on the global connections. An invasion growth rate at one roll state alone does not establish an attracting cycle.
Invariant coordinate planes or other symmetries can preserve connections that an unrestricted perturbation would break. Consequently existence, robustness and attraction are separate questions.
Phase locking maintains a fixed relation between the phases of oscillations, or between an oscillation and periodic forcing. For a one-to-one locked pair, is constant; more general locking can fix an integer combination . Locking concerns the relative phases, so the individual oscillations can continue indefinitely.
For two equally coupled phase oscillators in the Kuramoto model, the difference satisfies . A stable locked value has and when . The uncoupled frequencies need not coincide: coupling shifts both observed frequencies to the same value. Outside the locking range the difference keeps winding.
Spatial forcing can likewise pin the phase of a pattern. For the real-coefficient conjugately forced amplitude equationputting with gives and . The phase-stable values are for and for . A physical nonzero branch also needs a positive squared amplitude when ; radial stability is a separate check. At the phase is neutral and this pinning disappears.
Topological dynamics studies continuous maps and their orbits on topological spaces. For a compact metric space and a continuous map , the pair is a compact Hausdorff topological dynamical system.
Two continuous maps are topologically conjugate if a homeomorphism between their state spaces satisfies the displayed intertwining identity. It is conjugate maps with a topology-preserving conjugating map. On compact metric spaces, pulling back a compatible metric through preserves every Bowen metric, and hence topological entropy.
A continuous map on a nonempty topological space is point-transitive if it has a dense forward orbit. This is one convention for topological transitivity, but on spaces with isolated points it must be distinguished from the open-set intersection definition. On a nonempty compact metric space, the positive-time open-set intersection property implies point transitivity: for each member of a countable basis of a topology, is open and dense, and the Baire category theorem supplies a point in their intersection. Conversely, a surjective point-transitive continuous map has every tail of its dense orbit dense, since and continuity sends its orbit closure into the closure of that tail. The map , on is point-transitive but fails the open-set intersection property.
An orbit is a dense orbit in a topological space if its closure is all of . For a forward map orbit, this means that every nonempty open subset contains some iterate . A dense orbit visits every region distinguishable by the topology; it need not pass through every point.
An irrational rotation of the circle has dense orbits, whereas a rational rotation has finite periodic orbits. Density is a topological property and does not specify frequencies of visits. Equidistribution and ergodicity make stronger statements involving a specified measure, so neither should be inferred merely from one dense trajectory.
A subset is syndetic if it has bounded gaps: some positive integer makes every block meet . The quantifier applies at every integer location, including negative ones. A corresponding one-sided definition uses and nonnegative starting locations.
For example, the even integers are syndetic with , while the positive perfect squares are not: the gap between and is and grows without bound. In a one-sided syndetic set, partitioning the first integers into blocks of length gives at least elements, so its lower asymptotic density is at least .
Positive lower density alone does not ensure bounded gaps. Remove from each block for . The removed blocks have unbounded lengths, but at most removed points lie below . The remaining set has asymptotic density one and is not syndetic. Thus a condition on every interval is stronger than a condition on the long-run proportion.
A recurrent point of a discrete dynamical system returns arbitrarily close to its starting state at arbitrarily late positive times. In a metric space, this means that there is a strictly increasing sequence withEquivalently, every neighborhood of contains for arbitrarily large . A finite early return near the point does not suffice.
Every periodic point is recurrent: if , take . An irrational rotation of the circle gives recurrent points that are not periodic. For with irrational , the pigeonhole principle applied to modulo one supplies an integer with distance from to an integer at most . These approximating must be unbounded, since no fixed positive multiple of an irrational number is an integer. An increasing subsequence therefore gives the required returns for every starting angle.
Recurrence concerns returning close, whereas convergence to an attracting equilibrium point need not give recurrence of any other starting state. The map has zero as a recurrent point, but a nonzero converges to zero rather than back to itself.
Every continuous self-map of a nonempty compact metric space has a recurrent point. Choose a minimal subsystem. The forward orbit of every point in it is dense, and the same is true of every tail of that orbit; consequently each neighborhood is revisited at arbitrarily large times. A nonempty subsystem is all that is guaranteed: the identity map on a singleton has no larger subsystem.
In a compact metric space with a continuous map , points are proximal ifThis property is independent of the compatible metric. If is injective and , arbitrarily small proximal distances must occur at arbitrarily large times, since each finite collection of distances is strictly positive. Proximal points need not be equal or have dense orbits.
If distinct points of a dynamical system on a compact metric space satisfy in one compatible metric, no compatible metric can make an isometry. On a compact space, all compatible metrics give the same asymptotic-pair property by uniform continuity, whereas an isometry preserves the strictly positive distance between distinct points. In a full shift, a constant sequence and a sequence differing at just one coordinate converge to each other under forward shifts, proving this obstruction directly in the product topology.
For a compact metric space with a continuous map , suppose is a minimal point and are proximal. Every neighborhood of admits arbitrarily large with . First shrink to an open neighborhood, then choose an open with and . Minimality and compactness give a finite cover of the orbit closure of by , . Uniform continuity of these finitely many iterates turns a sufficiently close proximal encounter into a common visit to after at most more steps. If the proximal encounters occur only at bounded times, a zero distance at some time makes the two future orbits coincide, and minimality then gives arbitrarily late common visits. Thus injectivity is not needed for this general lemma.
A nonempty topological dynamical system on a compact Hausdorff space is minimal if it has no proper nonempty closed forward-invariant subset. Equivalently, every forward orbit is dense in , because an orbit closure is closed and forward invariant. Minimality implies .
A point is minimal when its forward orbit closure is a minimal dynamical system. This does not require the point to be a fixed point. In a finite-alphabet full shift, minimal points are exactly the uniformly recurrent sequences.
A minimal subsystem is a nonempty closed forward-invariant subset on which the restricted dynamical system is a minimal dynamical system. Every continuous map on a nonempty compact Hausdorff space has one: intersections of chains of nonempty closed invariant sets remain nonempty by compactness, so the Zorn lemma gives a minimal member.
The forward orbit closure of under a continuous map is the closure of its forward orbit. It is a closed forward-invariant set. If is invertible, one may instead consider the two-sided orbit closure using ; the convention should be specified. For a minimal point of an invertible compact system the two closures agree.
Symbolic dynamics studies dynamical systems whose points are sequences of symbols from an alphabet and whose evolution is a shift. A finite alphabet with the discrete topology gives its sequence space a product topology.
A subshift of finite type is a closed subset of a finite-alphabet full shift defined by finitely many forbidden finite words, with the restricted left shift. After replacing symbols by sufficiently long blocks, its constraints can be described by a zero-one symbolic transition matrix. In this presentation, membership means that every consecutive pair follows an allowed transition. The resulting sequence space is a compact metric space and the restricted left shift is a homeomorphism.
A fixed point of the th iteration of a map of a subshift of finite type is determined uniquely by its length- block with a permitted closing transition. Summing the counts of length- closed walks over their starting symbols gives the displayed trace. This counts points whose least period divides . If counts points of least period exactly , then , and Möbius inversion gives . The number of distinct least-period- periodic orbits is .
The adjacency matrix of a directed graph whose vertices are symbols and whose directed edges are the permitted consecutive pairs. Its entries indicate permission. In comparison, the transition matrix of a Markov chain records transition probabilities.
A finite word over an alphabet is locally admissible for a zero-one symbolic transition matrix if every consecutive pair is permitted. Its length counts symbols, so length corresponds to transitions. The number with endpoints is by matrix multiplication. Local admissibility does not always imply occurrence in a two-sided subshift of finite type: the matrix permits the word but admits no two-sided sequence. If every row and column has a nonzero entry, every locally admissible word extends in both directions.
A two-sided sequence over a finite alphabet is uniformly recurrent if every finite word over an alphabet occurring in it occurs with bounded gaps. More precisely, for each such word some ensures that every length- interval contains a complete occurrence. This is equivalent to being a minimal point of the full shift: a finite cover of the orbit closure by preimages of a word's cylinder set bounds its return gaps; conversely, bounded gaps pass to all points of the orbit closure and make every forward orbit dense there. The property concerns finite words, not infinite integer intervals.
The two-sided full shift on a finite alphabet consists of all functions , with the product topology and the left shift. It is a compact metric space. A compatible metric isAgreement on increasingly large finite coordinate sets is equivalent to convergence in this topology. The metric above is compatible but is not invariant under the left shift.
On a two-sided full shift, the left shift is the homeomorphismIts inverse sends to . On a one-sided sequence space, the same forward shift is generally not invertible.
A dynamical system combines a state space with a rule for evolution in time. A discrete rule sends a complete state to , while a continuous model can specify . The state must include enough information for the chosen rule: a harmonic oscillator needs both position and velocity, because equal positions with opposite velocities have different immediate futures.
The same model can be studied through several questions. An equilibrium point stays fixed, a periodic orbit repeats, and a basin of attraction describes which initial states approach a selected long-term behavior. Changing a parameter can cause a bifurcation. These qualitative properties can be useful even when no explicit formula for every trajectory is available. Deterministic evolution also requires well-defined forward solutions; merely writing a differential equation does not establish existence or uniqueness of its initial value problem.
A dynamical observable is a function or that assigns a measurable quantity to each state of a dynamical system. If the dynamics is , the observed sequence from state is . The state space may be high dimensional even when this record is scalar.
For a harmonic oscillator with state , position is one dynamical observable; energy is another. Position generally oscillates, while energy is constant along an ideal conservative trajectory. Composition describes evolution of the measured quantity instead of evolution of states. Its time average, , is the object compared with a space integral in ergodic theory.
For a map and a given dynamical observable , the additive cohomological equation asks for a function satisfyingWhen such exists, is a difference accumulated between consecutive states. Summing along a trajectory makes the intermediate terms cancel:Thus bounded forces these sums to remain bounded, and any periodic orbit of period must have sum zero. These are necessary conditions, not a universal existence theorem.
For the circle rotation , try and . Then when the denominator is nonzero. If it vanishes, this mode is an obstruction; if it is very small, the coefficient is large. This explains how a simple equation leads to delicate regularity questions in dynamical systems.
A time average measures an dynamical observable along a single trajectory of a dynamical system. For a flow , define . If the limit as exists, it is the long-time average at initial state . For a discrete map , the corresponding expression is .
If , the average tends to zero although the observable never settles to a constant. The Birkhoff ergodic theorem supplies almost-everywhere existence for integrable observables under a probability-preserving map. Equality with a spatial average requires the appropriate ergodicity assumption; existence alone does not imply it.
An additive cocycle over a dynamical system records a quantity accumulated along a flow. It satisfies and : accumulation over two intervals equals accumulation over the first interval plus accumulation over the second interval from the evolved state.
For an dynamical observable , the integral is an example, as splitting the integral at proves the identity. A coboundary has the special form . Matrix-valued multiplicative versions replace addition by an ordered product; the order matters when the matrices do not commute.
Synchronization of oscillators occurs when interacting or driven oscillators acquire a sustained relation between their phases or frequencies. Equal amplitudes are not required. In one simple phase model, a relative phase obeys , where is the uncoupled frequency mismatch and the coupling strength.
When , a fixed relative phase exists; the branch with is stable because the linearized restoring coefficient is . The Kuramoto model extends this competition between mismatch and coupling to a population of phase oscillators.[ref]
From Kuramoto to Crawford: exploring the onset of synchronization in populations of coupled oscillators by Steven H. Strogatz. Sections 2–3, phase reduction and collective synchronization
A state variable is a coordinate used to describe the instantaneous condition of a dynamical system sufficiently completely to determine its future evolution under a specified model and input. For a simple pendulum, its angle and angular velocity form a state; angle alone generally does not, because the same position can be traversed in either direction.
A second-order ordinary differential equation becomes a first-order system by setting : and . The choice of state variables therefore reflects the memory required by the model, and differs from merely listing measured outputs.
Repulsion in a dynamical system describes nearby trajectories moving away from an invariant state or set in forward time. For a scalar discrete dynamical system, a fixed-point multiplier with modulus greater than one gives local repulsion.
A forward-invariant set is a subset of a state space that contains every future state of each trajectory starting in it. For a discrete dynamical system with update map , the condition isMathematical induction then gives for every nonnegative integer . For a flow map, the analogous condition is for every forward time for which the solution exists.
Forward invariance does not require equality or backward invariance. For , the interval is forward invariant because , but the inverse image of one is two, outside . By contrast, the singleton is invariant in both directions.
This is useful before an exact solution is available. A forward-invariant positive interval prevents a population model from generating negative states and supplies an upper bound for all later iterates. The positive invariant interval for a cubic biological population map derives such a region by direct inequalities. Being bounded in a forward-invariant set does not alone imply convergence to one equilibrium point.
An invariant interval for a scalar map is an interval whose points remain in that interval under every forward iterate. Here invariance means forward invariance and does not assert surjectivity onto the interval.
For the discrete dynamical system withevery positive starting value satisfying has positive later iterates. The useful invariant interval is .
First, for every ,because the quadratic has positive leading coefficient and discriminant . Thus a positive first image lies below .
Second, on the cubic product can be negative only for . On that interval its magnitude is at most , so throughout . Together the bounds give . Mathematical induction then keeps all later values in that positive bounded interval.
The hypothesis on the first image is necessary: a positive starting population outside the invariant region need not have a positive image. The interval argument supplies positivity and boundedness; it does not by itself classify the eventual orbit.
A semiconjugacy from to is an intertwining map :In a topological factor-map convention, is also continuous and onto. Authors using the term for an arbitrary intertwining map should state that weaker convention. If is a homeomorphism, the relation is a topological conjugacy.
The identity transports every forward orbit. Induction gives , so iterating in the larger space and then projecting agrees with projecting first and then iterating. The map can merge different states, so the projected dynamics need not retain all information about the original orbit.
For example, let on the circle, on , and . ThenThus the doubling map maps onto the parameter-four logistic map by a continuous semiconjugacy. Since , it is not one-to-one and does not give a topological conjugacy by this map.
The forward orbit of a state is the collection of states reached as time advances. For a discrete dynamical system ,For a flow map , the analogous set is over the times for which the solution exists. The initial state is included; its future accumulation points instead form the omega-limit set.
For example, with gives . Zero is approached but is not one of those iterates, so the forward orbit differs from its closure. Forward evolution also need not determine a unique past: sends both and to . The distinction matters when discussing attraction or invariance for a map that cannot be inverted.
The box-ball system is a discrete cellular automaton with a row of boxes, each either empty or holding one ball. Consider finitely many balls and unlimited empty boxes to the right. During one update, process the original balls from left to right and move each exactly once to the nearest currently empty box on its right. The ordering and the instruction to move each ball only once are part of the evolution rule.
An isolated block of three balls in boxes moves to in one update. More generally, an isolated block of balls moves boxes per step, preserving its shape. Interacting patterns have a soliton interpretation: localized structures re-emerge with conserved identities, and the system has further conserved quantities.[ref]
A Soliton Cellular Automaton by Daisuke Takahashi and Junkichi Satsuma. Publisher abstract: solitary-wave interactions preserve identities; infinitely many conserved quantities
This gives a particularly concrete setting in which a simple integer update rule produces organized wave-like motion.Evolution is deterministic when a specified initial condition and evolution rule select a unique future orbit. For a discrete dynamical system, applying the same map to the same state gives the same next state. For an ordinary differential equation, uniqueness of the initial value problem is required; merely writing a differential equation does not guarantee it.
Determinism permits both asymptotic stability and sensitive dependence on initial conditions. It does not by itself imply reliable prediction from approximate measurements, and sensitivity does not introduce a random choice into the evolution rule.
The Lorenz system is the three-variable autonomous differential equationIt arose as a low-dimensional model of thermal convection. Edward Norton Lorenz used its numerical solutions in 1963 to study nonperiodic motion and sensitivity to the initial condition, with consequences for long-range weather forecasting.[ref]
Deterministic Nonperiodic Flow by Edward Norton Lorenz. Journal of the Atmospheric Sciences 20 (1963), pages 130–141: convection model, numerical nonperiodic solutions and forecasting implications
The equilibrium points follow directly from the equations. For and , the first gives and the third gives . The second then becomes . Thus the origin always exists, while for there are two additional equilibriawith matching signs in the first two coordinates. The symmetry exchanges them.
The Equilibrium bifurcations of the Lorenz system determine how their stability changes. The separate instantaneous Lorenz error growth at a zero-y crossing calculation concerns a perturbation at one instant; it should not be confused with the long-term Lyapunov exponent.
For positive , the origin of the Lorenz system loses stability at and two equilibria emerge stably. Center-manifold projection gives , proving a supercritical pitchfork. The nonzero-branch characteristic polynomial is . If these equilibria remain stable for all . Otherwise their transverse Hopf crossing occurs at the displayed parameter, with frequency squared . Its cubic Hopf coefficient is positive, so this Hopf is subcritical, producing an unstable small periodic orbit on the stable-equilibrium side. A zero eigenvalue detects the pitchfork, while the Hopf condition uses the Routh-Hurwitz equality; neither alone determines nonlinear criticality without the corresponding normal-form calculation.
Consider the Lorenz system with and , at a state where . An infinitesimal error evolves by , where is the Jacobian matrix. Its squared Euclidean norm satisfiesAt that crossing, the skew couplings involving cancel, leavingThe planar block has negative trace and determinant . It has a positive eigenvalue exactly whenThus some error direction initially grows for either or . The vertical direction initially contracts.
For , , and , the eigenvalues of are . The most rapidly growing unit direction is , with instantaneous logarithmic norm growth . The factor of two distinguishes squared-norm growth from norm growth.
This is a local criterion at the specified state. Later rotation of the perturbation direction can change its growth, so it does not prove a positive asymptotic Lyapunov exponent.
The Feigenbaum period-doubling map is the universal, even, quadratic-critical fixed map associated with repeated period-doubling bifurcations. One normalization isComposing twice and rescaling therefore reproduces the same graph. This self-similarity is the mechanism behind a common spatial scaling in otherwise different one-dimensional maps with a quadratic maximum.[ref]
Quantitative Universality for a Class of Nonlinear Transformations by Mitchell Feigenbaum. 1978: universal spatial scaling and the period-doubling functional equation
The quadratic maximum means and . Twice applying the chain rule at zero givesThe term involving vanishes, and cancellation is legitimate because the maximum is nondegenerate. Thus the endpoint derivative is determined by the spatial scaling.
Writing makes the successive central intervals shrink by the factor . Their iterates generate the Feigenbaum attractor; nonuniform interval lengths are encoded by the Feigenbaum geometric potential. The constant here describes spatial scaling, rather than the spacing of successive bifurcation parameter values.
The Feigenbaum geometric potential is a bounded negative symbolic potential encoding the lengths of nested intervals of the Feigenbaum attractor. In an appropriate binary coding,and changing only the distant tail of an address changes by an exponentially small amount. For odd interval labels, a sum along reversed address prefixes satisfieswith a bound independent of the depth and address. Even-label intervals have lengths comparable to neighboring odd-label intervals. These uniform estimates connect geometric lengths with thermodynamic formalism.[ref]
Feigenbaum universality and the thermodynamic formalism by E. B. Vul and others. Thermodynamic description of the period-doubling geometry
[ref]Multifractality of the Feigenbaum attractor and fractional derivatives by Uriel Frisch and others. Section 2.1, equations (8)–(14): bounded potential, decaying variations and interval-length comparisons
The bounded logarithmic error is important. For fixed real , exponentiation givesAfter summing and taking , the error is at most , which vanishes. Thus geometric partition sums and symbolic partition sums give the same limiting topological pressure. The almost-additive partition-function limit supplies existence under the bounded-distortion hypotheses; bounded negative potentials give a strictly decreasing pressure.
This potential measures geometric contraction across partition levels. It is not an unbounded derivative potential evaluated at the critical point, where , and partition depth is distinct from elapsed orbit time.
Odd-address intervals lie in the first image of the central restrictive interval, away from the critical point. The derivative of the Feigenbaum map is bounded above and away from zero there, so the next even interval has comparable length by the mean value theorem. For the wraparound image, makes its length a fixed fraction of the central interval. Thus the odd and full partition length-power sums differ only by constant factors for each fixed real exponent, and have the same exponential growth rate.
For the normalized Feigenbaum map, put and defineThe Feigenbaum attractor is the nested intersection . Each level interval has two children, and the largest interval length tends to zero. Consequently every compatible infinite binary address selects one point of this Cantor set.[ref]
At level , the intervals are visited cyclically: the label changes from to modulo . Expressing in binary therefore turns iteration on into the dyadic adding machine. One adds one with carries, rather than discarding the first symbol as in a full shift. For example, addresses written with the least significant digit first begin .
There are geometric pieces at depth , but those pieces are visited in a cycle. Counting them does not make the time evolution a two-symbol full shift. The Feigenbaum geometric potential uses this depth to study spatial contraction and Hausdorff dimension.
The dyadic adding machine is addition by one on the space of infinite binary digit sequences, interpreted with the least significant digit first. Carries propagate toward later digits: . The all-ones sequence maps to the all-zeros sequence.
Equivalently, it is the compatible collection of cyclic maps for all , or translation by one on the 2-adic integers. Every orbit visits every finite binary cylinder and is therefore dense. At the Feigenbaum attractor, this describes the order of visits to nested intervals; it is not the digit-discarding evolution of a full shift.
Articles were limited to the first 100 out of 549 total.
Articles by others on the same topic


Dynamical systems is a branch of mathematics that studies the behavior of systems that evolve over time according to specific rules. These systems can be described by differential equations or difference equations, which dictate how the state of the system changes in response to its current state. ### Key Concepts: 1. **State Space**: The set of all possible states of a system. Each point in this space corresponds to a unique state of the system.