For differentiable maps and , the multivariable chain rule multiplies their Jacobian matrices:The outer matrix multiplies the inner matrix, producing an matrix. This order records that the inner linear map acts first. Componentwise, the matrix multiplication sums the contributions of all intermediate coordinates. Existence of separate partial derivatives alone is not the required differentiability hypothesis.
For twice continuously differentiable coordinate functions and an outer scalar function , apply the multivariable chain rule twice along an original coordinate . The first three terms differentiate the outer function, while the last two differentiate the coordinate coefficients. They cannot be omitted for a nonlinear coordinate map. In matrix notation this is the Hessian matrix formula for . The extra terms vanish for an affine map.
If is differentiable at the point of a differentiable parametric curve, the multivariable chain rule givesThe gradient supplies the local spatial rates; the velocity vector supplies the direction and rate of movement. Their dot product is the change in the sampled scalar field per unit parameter. If the parameter is time, this is a rate per unit time; a directional derivative per unit distance instead uses a unit vector.
Take and the unit circle path . Along the path,At , the gradient is , the velocity vector is , and their dot product is . The sampled value is and increases at rate one, even though one coordinate is decreasing. This is why a moving observation must combine every coordinate's contribution.
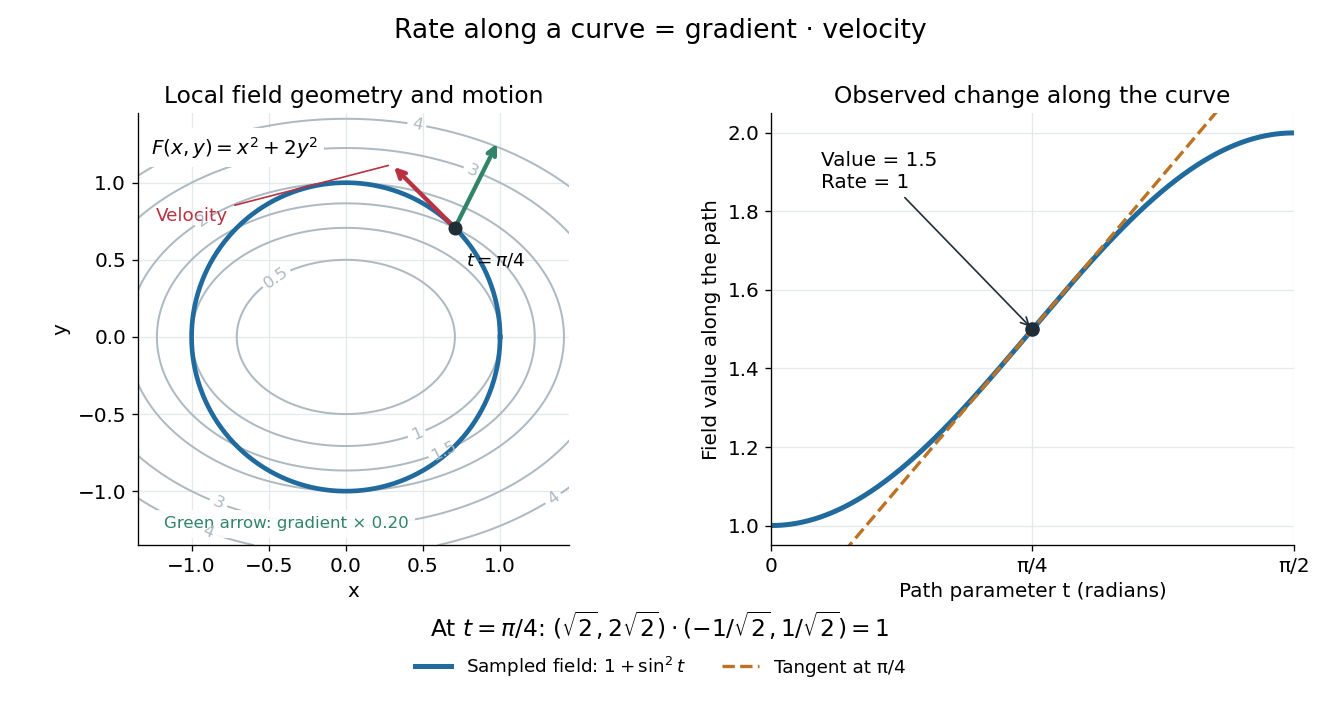
For a level curve, is constant, so the derivative along a curve is zero and its velocity vector is orthogonal to the gradient. Along other paths, the same formula combines a field's geometry with the observer's motion. [ref].
For a continuously differentiable vector field and a twice continuously differentiable parametric curve , the product rule and multivariable chain rule givewhere is the Jacobian matrix. Indeed, first differentiate the dot product to obtain , and then substitute .
The first term describes variation in the sampled vector field; the second records the changing velocity vector of the parametric curve. In three dimensions one may take for a sufficiently smooth vector field . The formula then involves first and second spatial partial derivatives of and the velocity and acceleration of the parametric curve. Omitting the second term would be valid only when its dot product vanishes, for example for a straight path with constant velocity.

