Functions whose differentials are linearly independent at the point in question. For this means the derivative has rank , so is a submersion there. The condition is open. It is distinct from global algebraic independence of functions.
If a differentiable map takes values in a level set of a differentiable scalar function , the chain rule gives . At a regular point, the image of the derivative lies in the kernel of the nonzero covector : the tangent space of the level set. For a map into the unit circle this forces rank at most one.
For a positive integer , the negative matrix power is differentiable on the open general linear group. The Neumann series gives locally around any invertible matrix. Applying the product rule to the factors of this inverse gives the displayed Fréchet derivative. Each summand chooses one inverse factor to differentiate while keeping the others in order.
The factor order matters. Only when and commute does the sum simplify to . This is a useful example of why scalar differentiation rules for powers cannot be transferred to matrices without accounting for noncommutativity.
For on , continuity of on gives a bounded Fréchet derivative in the displayed form. Fixing and restricting to a bounded neighborhood confines all intermediate pairs to a compact range up to null sets. Uniform continuity of the partial derivatives bounds the integrated first-order remainder by , where . This is little-oh of the Sobolev norm. The result needs no continuous derivative representative for ; essential boundedness suffices.
Suppose and . If , then . The boundedness of is also preserved, and the same argument in reverse proves equivalence of differentiability. The derivative is the same linear map, not a norm-dependent replacement.
A map on a subset of a normed vector space is Hadamard differentiable at if its directional difference quotients converge to a continuous linear map uniformly along all convergent sequences of directions: , , and in the domain imply . Tangential differentiability restricts the limit directions to a specified subspace. This is the regularity used by the functional delta method.
For a Hadamard differentiable functional with continuous linear derivative , define . For every compact and positive , some positive make whenever and . If this failed, choose , directions within of and remainders at least . Compactness gives a convergent subsequence of nearby points of , hence convergent directions. The derivative definition and continuity of give remainder tending to zero, a contradiction. With a tight weak limit, the Portmanteau theorem makes random directions lie near a suitable compact set with arbitrarily large probability. Thus this lemma proves the functional delta method without assuming separability of the entire normed space or uniform differentiability on its whole unit ball.
On bounded continuously differentiable functions with uniformly bounded total variation of a function, the map is Hadamard differentiable in the supremum norm with derivative . Use weak convergence of bounded-variation integrators for the first term and integration by parts for the remaining terms. No derivatives of the limiting continuous directions are required.
A map is Fréchet differentiable at if it admits a bounded linear first-order approximation: for a continuous linear map .
A differentiable map on a connected open subset of Euclidean space whose derivative vanishes everywhere is constant. The mean value inequality makes it constant on every ball in the domain, hence locally constant; connectedness then makes the value global.
The inverse function theorem answers a practical question: can nearby outputs be used to recover nearby inputs uniquely and smoothly? Its useful surprise is that a nonlinear function can be tested using its linear derivative. If the first-order changes preserve all input directions, then, on a sufficiently small region, the nonlinear map can also be reversed. This is the basis for treating a nonlinear map as a coordinate transformation.
Precisely, let be continuously differentiable on an open subset of Euclidean space, let , and put . If is an invertible linear map, there are open neighbourhoods of and of such that is a bijection with a continuously differentiable inverse function . Thus this restriction is a diffeomorphism. In coordinates the test is , using the Jacobian determinant. The derivative of a local inverse map is obtained by inverting the Jacobian matrix, at the corresponding input. [ref]
For a one-dimensional example, has . Near , the inverse function is , and the inverse function rule gives . But has no inverse function on the whole real line, since and give the same output. The theorem supplies a local restriction, not global injectivity. At zero, the derivative test fails; the nonnegative branch still has a square root inverse, but that inverse has no finite derivative at zero. [ref]
https://www.jirka.org/ra/html/sec_ift.html. Jiří Lebl, Basic Analysis: the one-dimensional theorem and the square-root example
Here is a two-dimensional example with an invertible derivative everywhere and infinitely repeated outputs:The exponential function turns into a positive radius, while is the angle in polar coordinates. Restricting, for example, to and produces the reversible patch pictured below. On its image, with Cartesian coordinates and , the inverse function isThe arctangent selects the angle near zero. Without an angle restriction, for every integer , so there is no single global inverse function. This map is a local diffeomorphism but is not injective.
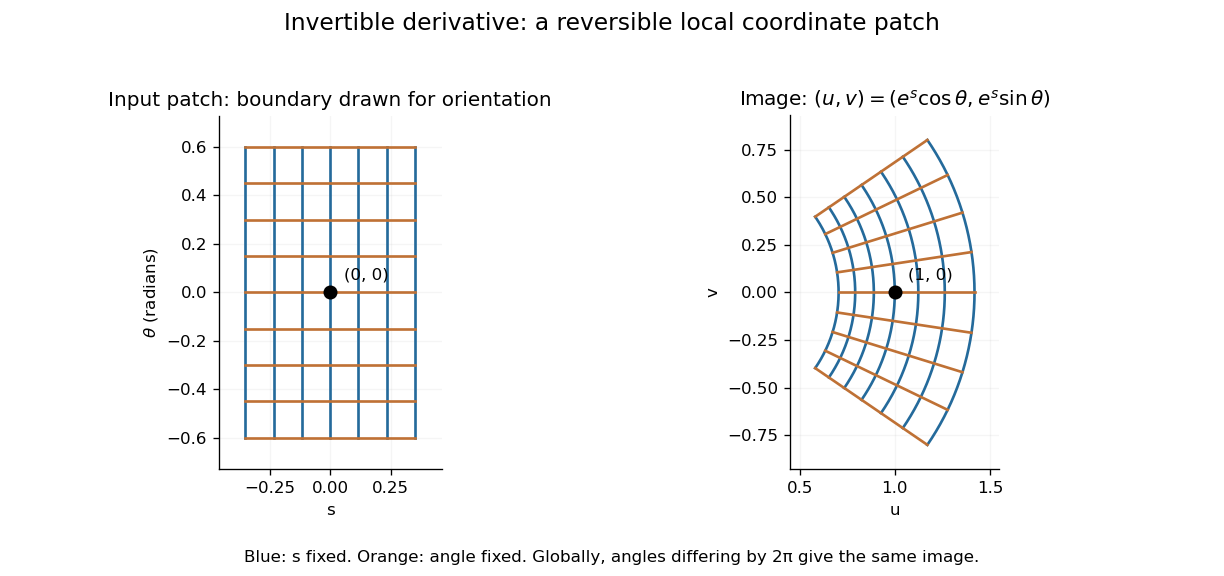
A small rectangular coordinate patch maps reversibly to a curved sector, despite global angle repetition
. Details. 
The short proof idea is to correct a guessed input using the inverse linear response. With , solving is equivalent to finding a fixed point ofAt , the derivative vanishes. Continuity makes a contraction mapping on a sufficiently small closed ball, which it maps into itself when is sufficiently close to . The contraction mapping theorem then gives existence and uniqueness there. Establishing the smooth dependence on completes the inverse theorem. This explains why the nonlinearity can be tolerated: its correction has a small local slope.[ref]
8.5 Inverse and implicit function theorems. §8.5: the contraction argument
For the continuously differentiable inverse function supplied by the inverse function theorem, the chain rule applied to givesHere is the identity matrix. The matrix inverse is taken at the recovered input , not at the output . In one dimension this is the inverse function rule .
The formula also describes sensitivity. For a small output perturbation , differentiability gives . A large operator norm of permits large amplification in some directions. In the square root example, grows without bound as positive approaches zero. Existence of a local inverse function therefore does not imply that recovery is insensitive to measurement error.
This map is a diffeomorphism from onto . Writing , the inverse problem becomes with . The left side decreases strictly from to zero, proving existence and uniqueness exactly on . Its Jacobian determinant is , so the inverse function theorem supplies a differentiable inverse. Along , applying the inverse Jacobian to gives . Establishing the actual image matters before using a global inverse, even when a local inverse already exists at the point of interest.
Let a three-times continuously differentiable real function have . The inverse function theorem gives a local inverse . Writing , and , its derivatives areIndeed by the chain rule. Apply this operator successively to , and . Every forward derivative on the right is evaluated at the inverse image .
The constant rank theorem separates the directions a smooth map preserves from the directions it forgets. If a smooth map from an open subset of to has derivative of constant rank on a neighbourhood of a point, there are local coordinate transformations in source and target in which it becomesIt keeps coordinates, discards the other , and inserts zeros. This is stronger than simplifying the Jacobian matrix at one point: it straightens the actual nonlinear map on a neighbourhood. [ref]
For a worked example, takeThe two columns agree, and the first row is nonzero, so the rank is exactly one everywhere. The image of a function is the parabola . Every line is a fiber mapping to the same point .
Choose input coordinates , , and output coordinates , . Both coordinate transformations are diffeomorphisms: their inverses are , and , . In these coordinates,The curved image has become a straight line, and the unused coordinate is explicit.
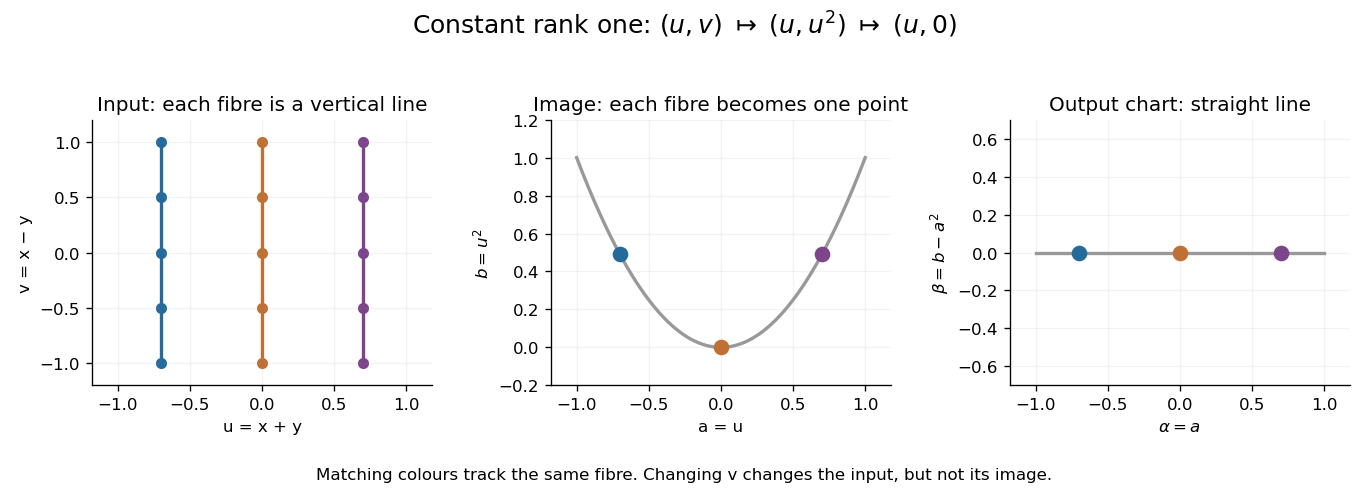
A rank-one map collapses input fibres to a parabola, which a change of output coordinates straightens
. Details. 
Constant rank on a neighbourhood is essential. The map has rank one when and two when , so the constant rank theorem does not supply one rank-one form across that line. By contrast, the full-rank square case of the theorem forgets no coordinates and recovers the inverse function theorem. The usefulness is that curved fibers and images can often be studied through this simpler local form.
For a smooth map on the plane with zero Jacobian determinant and , set . The determinant identity gives . Along a curve solving , both and have zero derivative. Local existence and uniqueness for this smooth differential equation through every nearby point produce a local foliation by curves of constant .
A local diffeomorphism is a differentiable map that restricts near every point to a diffeomorphism onto an open subset of its target. The local inverse functions need not combine into a single global inverse function: different parts of the domain of a function can map onto the same output region.
For continuously differentiable maps between open subsets of , being a local diffeomorphism is equivalent to having an invertible derivative at every point. The inverse function theorem proves one direction. For the other, the chain rule for each local inverse function gives two inverse linear maps. The periodic angle example under the inverse function theorem has this property everywhere, even though it has infinitely many inputs for every point of the punctured plane. The noninjective map with constant Jacobian determinant gives another useful distinction: even a constant nonzero Jacobian determinant need not give global injectivity.
Every local diffeomorphism is an open map. To see this, take an open subset of the source and intersect it with the neighbourhoods where the map is a diffeomorphism. Each local image is open, and their union is the full image. Thus nearby outputs remain available locally, despite the possible global ambiguity.
The displayed smooth map from to the punctured plane has Jacobian determinant one: in polar coordinates its radius is and its angle is , so the determinant is . Nevertheless for every integer . Thus a local volume-preserving map need not be injective or have bounded weighted inverse multiplicity. Compactly supported data distributed over many inverse branches disprove a determinant-only dispersion with a nonlinear velocity map estimate.
An open map sends every open subset of its source to an open subset of its target. This is an image property; continuity instead concerns preimages of open sets. A local diffeomorphism has both properties, but openness alone does not promise unique recovery of an input. In the periodic coordinate map under the inverse function theorem, open patches give open output regions while multiple angle values still give the same output.
An equation can define a function without giving an explicit formula for it. The implicit function theorem tells us when the constraint determines uniquely from nearby , and makes the resulting function continuously differentiable. It is useful when solving an equation explicitly is cumbersome or impossible: the partial derivatives already reveal whether local recovery is possible.
Let be a continuously differentiable map from an open subset of to . Suppose and the partial derivative is an invertible linear map. There are open neighbourhoods of and of and a unique continuously differentiable function such that, for ,Thus the nearby level set is a graph of a function. The derivative of this graph isThe matrix inverse acts on the left; the order matters in several dimensions.
For example, take the unit circle, written as the level set . At , , so the local upper branch is . Implicit differentiation givesThis tangent line slope is available directly from the constraint. The negative square root branch is elsewhere on the same circle; it does not destroy uniqueness near the selected upper point.
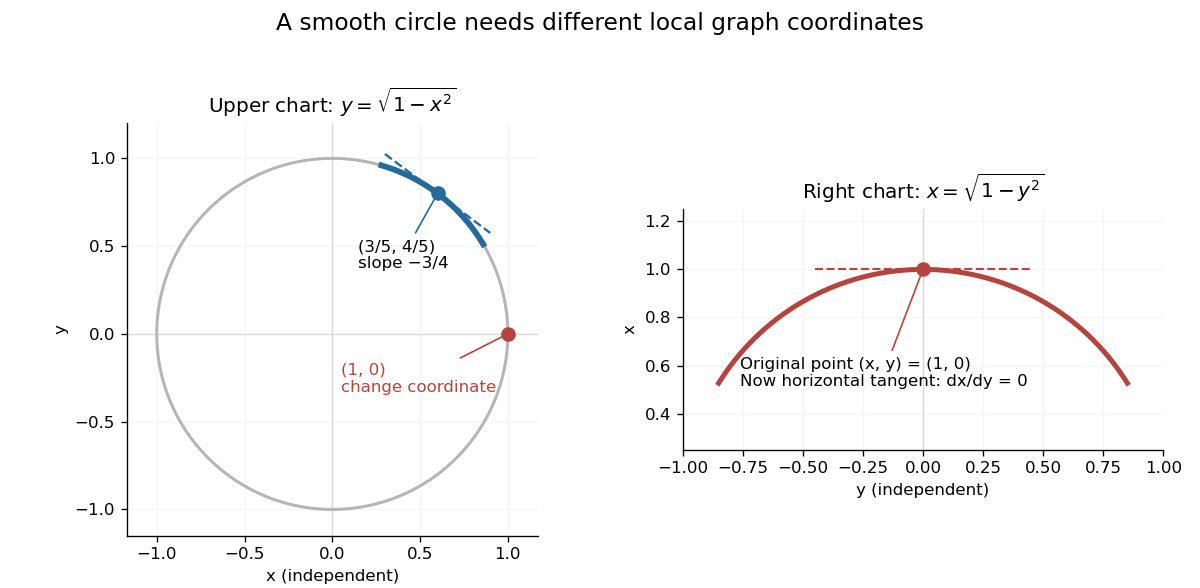
The same circle uses y as a function of x near its upper arc and x as a function of y near its rightmost point
. Details. 
At , however, and the circle cannot be represented locally as one function : just to the left of there are two nearby values of . The circle is still smooth there. Since , use the other coordinate instead: , with . A failed coordinate choice is different from a geometric singularity.
The derivative condition is sufficient, not necessary for every possible implicit graph. For , the entire zero set is the smooth graph , even though vanishes there. In this case the defining equation itself has a degenerate derivative; the theorem's test gives no conclusion.
The connection to the inverse function theorem is particularly elegant. Augment the constraint to the map , whose Jacobian matrix isIts determinant is . When this is nonzero, locally invert and set its second output to zero. The recovered second input is . In this way an implicit constraint becomes an ordinary inverse function problem. [ref]
https://www.math.utoronto.ca/courses/mat237y1/20199/notes/Chapter3/S3.3.html. University of Toronto MAT237: the implicit theorem as a corollary of the inverse theorem
For two constraints , the implicit function theorem gives differentiable functions when the Jacobian determinant is nonzero. At its zeros this particular projection can fail even when a geometric curve remains. A nonzero tangent vector with zero component gives a vertical tangent in that projection. Singular constraint representations require further care: a determinant of zero alone does not prove an infinite derivative or even a regular intersection.
If a holomorphic function satisfies and , then near its zero set is the graph of a unique holomorphic function. The analogous statement with uses as the local coordinate.
Implicit differentiation differentiates an identity along a differentiable branch and uses the chain rule to solve for its derivative:The partial derivatives treat as independent coordinates before evaluating on the branch. The implicit function theorem justifies the branch's local existence and regularity under its hypotheses; differentiating alone does not establish either. For the unit circle at , this calculation yields the tangent line .
On a regular level set , holding fixed gives . If is continuously differentiable and both and are nonzero, the implicit function theorem gives and . Multiplication proves the identity. The same held-fixed variable is essential, and a zero denominator invalidates the corresponding quotient rather than creating an infinite factor that may be cancelled formally.
On a level set , implicit differentiation gives the three ratios , and . Their product is wherever all the required coordinate representations are differentiable with nonzero denominators. At coordinate singularities the quotient product need not be defined.
Articles by others on the same topic
There are currently no matching articles.