Use the standard ordered basis for both maps. The reflection in a hyperplane interchanges the second and third coordinates, so its matrix isOrient the rotation axis along and use the right-hand convention. The rotation matrix for angle sends to , to , and to . For example, the Rodrigues rotation formula givesMultiplying the rotation matrix by the dilation factor givesDirect multiplication gives , and . Hence . If the opposite axis orientation is chosen, also has cube . Independently of coordinates, two applications of the reflection give the identity, while three applications of the rotation-dilation give a full turn and dilation by . Every basis represents these resulting maps by and . Thus the equality even holds when the two matrices are expressed in different bases.
Let be the normal subgroups of orders . Their intersection is a subgroup of both, so Lagrange's theorem makes its order divide both and ; hence . For and , normality shows that belongs to both and . It must be the identity, so . This proves the needed instance of normal subgroups of coprime order commute.
Choose nonidentity and . Their orders are and , since these orders divide the respective prime subgroup orders. If , commutativity gives , so and . Conversely . Thus the product of commuting elements of coprime order gives an element of order .
For the counterexample, take the dihedral group of symmetries of a regular pentagon:Its ten elements are and , . Nonidentity rotations have order , and , so all reflections have order . There is no element of order .
The curve is a hyperbola with two branches, vertices and , and asymptotes . It is symmetric under reflection in either coordinate axis. The requested sketch marks both vertices:
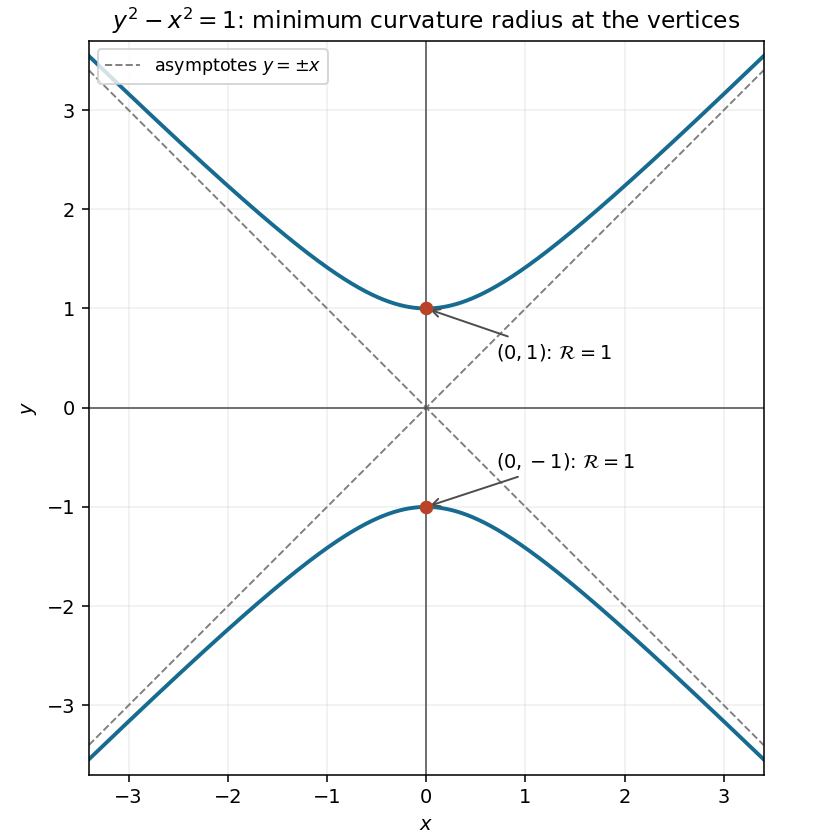

Parametrize the branches by , , for . The squared speed is , and . The reciprocal of the curvature of a plane curve is thereforeSince , with equality only at , the least radius is , attained at and .
Suppose are two sufficiently regular solutions with the same Dirichlet boundary condition, and put . Then in and on its boundary. Apply the divergence theorem to :Thus throughout , so is constant on each connected component. Its zero boundary values force every such constant to be zero. This proves uniqueness of the Dirichlet solution, without assuming its existence.
For a prescribed Neumann boundary condition, the difference instead has . The same energy argument still gives , but does not fix the constant. Consequently the solution is unique up to an additive constant on each connected component. A value at one point, or the integral mean, fixes the constant on a connected region. There is also a necessary compatibility condition: if on , the divergence theorem givesIt is required on each component if the region is disconnected. Data failing this condition admit no harmonic solution. This is the homogeneous-source instance of the Neumann Poisson problem.
Move the origin to the centroid and write the four vertex vectors as . Their sum is zero. The midpoints of the first opposite-edge pair have vectors and , so their distances from the centroid are equal. The same argument applies to the other two opposite-edge pairs.
Choose the three midpoint distances as , , . Expanding the dot products,Identifying these four norms with the vertex distances proves the tetrahedron centroid-to-midpoint sum of squares:The proof uses no orthogonality or regularity assumption on the tetrahedron.
Put and decompose it into axial and perpendicular parts, . For the nondegenerate semi-angle , the equation is equivalent toThus each plane perpendicular to at axial distance from meets the surface in a circle of radius . Both signs of are allowed, and gives the vertex. This proves that it is a double circular cone with the specified vertex and axis; is the angle each generator makes with either direction of the axis.
For the intersection calculation, define the symmetric matrix . The two equations are . Their difference givesWith and , symmetry of makes the last two terms . Hence the intersection plane of parallel congruent double cones isThe unnormalized normal vector is . Expanding its squared norm givesEquivalently, if , this is . Thus normalization is legitimate and yieldsThe assumption of a genuine cone matters: at the degenerate limits or , the surface collapses respectively to an axis or a plane and this normal need not exist.
Write the row components as . Expanding the cross product in components,equals the alternating six-term expansion of the determinant of . Therefore .
Geometrically, is the area of the parallelogram spanned by , and its direction is perpendicular to that plane. A nonzero scalar triple product means both that this area is nonzero and that has a nonzero component normal to the plane. Thus the vectors are linearly independent and form a basis of , without needing to be orthogonal. Equivalently, their parallelepiped has nonzero volume.
The entries of are , so the required duality is exactly . Since is invertible, this has the unique solutionIts determinant is , so its rows are again a basis. Put . The cross product is perpendicular to , and its dot product with is . Consequently the reciprocal basis isThese vectors have precisely the required dot products, so uniqueness identifies them with the rows of .
For the final request, an orthonormal basis of rows gives . If instead the reciprocal rows are orthonormal, then and substitution of gives , again implying . Thus in either case is an orthogonal matrix and .
The further printed claim that must be a rotation matrix is false without an orientation assumption. The matrix has orthonormal rows and is its own reciprocal basis matrix, but : it is a reflection. By the orientation of an orthonormal reciprocal basis, the corrected conclusion isA right-handed original ordered basis supplies exactly this missing condition.
If all three points are finite, define the Möbius transformationIts numerator vanishes at , its pole is at , and substitution of gives . The three points are distinct, so the numerator and denominator are not proportional and the associated matrix has nonzero determinant.
If one point is infinite, the limiting formulas areIn each case the finite values and the limit at infinity give , , , and the corresponding determinant is nonzero. Distinctness permits at most one of the points to be infinite. Hence every ordered triple of distinct points on the Riemann sphere can be normalized to .
Each element of permutes the three-point set, giving a group homomorphism . To prove injectivity, let an element fix all three points. Conjugate it by the normalizing Möbius transformation from part (i). The conjugate fixes . A Möbius transformation fixing has , and fixing infinity has . It is then ; fixing forces . Thus the conjugate, and hence the original transformation, is the identity. The kernel of a group homomorphism is trivial.
For surjectivity, let and choose any permutation . Let normalize the ordered triple and let normalize . Then sends to , lies in , and induces the chosen permutation. Thus is onto andFor the normalized set, the six Möbius transformations permuting three points are , , , , , and . Conjugating by gives the corresponding six maps for the original set.
Using the monic convention for the characteristic polynomial, expand the determinant along the last column:For the eigenvalue , the equations give and . Thus every corresponding nonzero eigenvector is a nonzero multiple of . For the eigenvalue , the first two equations give and , so every corresponding nonzero eigenvector is a nonzero multiple of . ThereforeThese eigenspaces together have dimension , so they cannot provide an eigenvector basis of . The matrix is not diagonalizable; the eigenvalue has algebraic multiplicity but geometric multiplicity .
The characteristic polynomial has only the eigenvalue . If is diagonalizable, there is an invertible matrix and a diagonal matrix with . Every diagonal entry of is an eigenvalue, hence equals . Thus and . Conversely, is already diagonal in every basis. HenceThis argument uses the existence of an eigenvector basis rather than merely the repeated root of the polynomial; repeated eigenvalues alone do not imply diagonalizability.
Orient the triangular boundary from to to and back to . This orientation corresponds to the positive normal vector . The cyclic coordinate rotation sends the three directed edges to one another and transforms the vector field by the same rotation. Since rotations preserve dot products, the three edge contributions to the line integral are equal.
For a sufficiently smooth vector field on an oriented piecewise smooth surface , with induced boundary orientation on , the Stokes theorem statesTherefore the requested surface integral, with all normal components positive, is also .
To verify it directly, parametrize the triangle by on , , . Its two tangent vectors are and , giving the vector area elementDifferentiation of the vector field gives . On the triangle , so its dot product with is . Consequentlyconfirming both the magnitude and the orientation sign.
For the printed integration formula, must mean the Jacobian determinant of the inverse coordinate map:If instead one calls the forward Jacobian, its determinant is where the derivative is invertible. This convention distinction resolves the direction of the arrow in the printed wording.
To derive the change of variables formula, a small rectangular cell of side lengths maps under the inverse transformation, to first order, to a parallelepiped with edge vectors , , . Its volume is the absolute scalar triple product of those vectors:For a one-to-one continuously differentiable coordinate map with continuously differentiable inverse, summing these local volume contributions and taking the partition limit givesThe absolute value removes an orientation reversal; injectivity ensures that each volume element is counted once.
For positive semi-axes, take , , . The solid ellipsoid becomes the unit ball and the inverse Jacobian determinant is . ThusRotational symmetry gives equal integrals of over the ball. Their sum is the integral of , so spherical coordinates give . The Cartesian second moment of a solid ellipsoid is therefore
Use suffix notation, summing repeated indices. The contraction of two Levi-Civita symbols givesAdding the directional derivative cancels the second term. Interchanging gives another pair whose sum is . The total right-hand side is thereforethe th component of the gradient of the dot product. Since this holds for each component, the dot-product gradient identity is proved:It holds for any continuously differentiable vector fields; no irrotationality assumption is used.
Take to be continuously differentiable everywhere on , as in the question. Its zero curl says . Construct a potential of a conservative vector field explicitly byAll segments lie in . Differentiating under the integral and using the symmetry of the derivatives,Hence . This radial integral potential for a curl-free field also works on a star-shaped domain after translating its centre. On an arbitrary domain, zero curl only guarantees local potentials; the everywhere-on- interpretation is important for this global assertion.
For the given field, put . The three pairs of derivatives entering its curl areThus the field is irrotational. To find its potential using , integrate to get . Comparison with gives , and comparison with gives . ThereforeDifferentiating this expression reproduces all three components with the required minus sign; the only freedom on the connected domain is the additive constant.
For a sufficiently regular vector field on a bounded region with piecewise smooth boundary , the divergence theorem stateswhere is the outward unit normal vector. Apply it to for an arbitrary constant vector . Since , it givesEquality for every constant proves the vector gradient form of the divergence theorem:
Applying the same divergence theorem directly to , with , proves the flux lawThis is the Gauss flux law for the prescribed source density, obtained directly from the divergence theorem. For the piecewise source in this problem the divergence relation is understood away from the interface, or almost everywhere; applying the theorem separately to the two sides gives the same law because the normal field is continuous across the interface and the internal boundary fluxes cancel.
For the radial field, its normal component on a sphere of radius is the constant , so its total flux is . For the enclosed source is ; for it is . Thus the origin-regular spherical Poisson flux law givesThe value at is the continuous value zero. A singular inverse-square radial addition is excluded by the source equation throughout space, including the origin: it would add a point source there.
Since , radial integration gives inside and outside. The decay condition fixes the exterior constant, giving for . Integrating inside gives , and matching at yields . Hence the potential of a uniform spherical source isBoth and its radial derivative are continuous at ; there is no surface source hidden in the matching.
For any ball centred at the origin, the gradient is odd under , so its volume integral vanishes by symmetry. On the bounding sphere, is constant and outward normals at antipodal points are opposite, so as well. Both sides of the vector gradient identity are therefore zero, for radii below, above, or equal to .
Articles by others on the same topic
There are currently no matching articles.