Use column vectors in a right-handed frame, and interpret clockwise as viewed from the positive -axis towards the origin. The rotation matrix fixes and sends towards . With , its images of the basis vectors giveThe transverse block is the planar rotation through . Viewing from the other end of the axis reverses the meaning of clockwise and replaces by ; the viewpoint is not specified in the paper.
The orthogonal reflection in exchanges the first two coordinates and leaves the third unchanged. Its fixed subspace is the plane, while its normal changes sign. ThereforeThis reflection matrix has determinant , as expected.
For column vectors, the second transformation multiplies on the left of the first. Thus the required matrix is , not . Using the rotation matrix convention in part (i),Indeed, a vector first becomes , and the orthogonal reflection then exchanges its first two entries.
Compose permutations from right to left. Tracking the images gives , , and , soTwo transpositions give sign of a permutation , proving that this element belongs to the alternating group .
Its conjugacy class consists of all double transpositions. Conjugation merely relabels the letters, so no other cycle type can occur. Conversely, choose a permutation relabelling the two pairs into any desired two pairs. If is odd, replace it by : the transposition centralizes , so this replacement is even and gives the same conjugate. Thus every double transposition is reached by conjugation inside .
The complete list of fifteen elements, grouped by their fixed letter, isThere are five choices of fixed letter and three pairings of the other four letters, confirming the conjugacy class size .
Write . The first two components have no dependence, and the third component is zero. The only possibly nonzero component of the curl isThus wherever the field is defined.
The disk spanning lies away from the excluded axis: the distance from its center to that axis is . The field is continuously differentiable on a neighborhood of that disk. The Stokes theorem therefore givesThis value is independent of the choice of orientation.
For , take the counterclockwise orientation viewed from positive . Put , . Then , so the line integral isClockwise orientation gives ; no orientation is printed for this curve. There is no contradiction with the Stokes theorem: its usual spanning disk intersects the axis where the field is undefined, so the differentiability hypothesis fails. This is a curl-free vector field with nonzero circulation around the excluded axis; local angular potentials cannot be combined into a single-valued global potential.
In polar coordinates, the curve is the logarithmic spiral , . It starts at and winds counterclockwise outwards through one and a half turns. It crosses the horizontal axis atThe following original sketch uses representative positive values; changing rescales it and changing changes its rate of expansion.
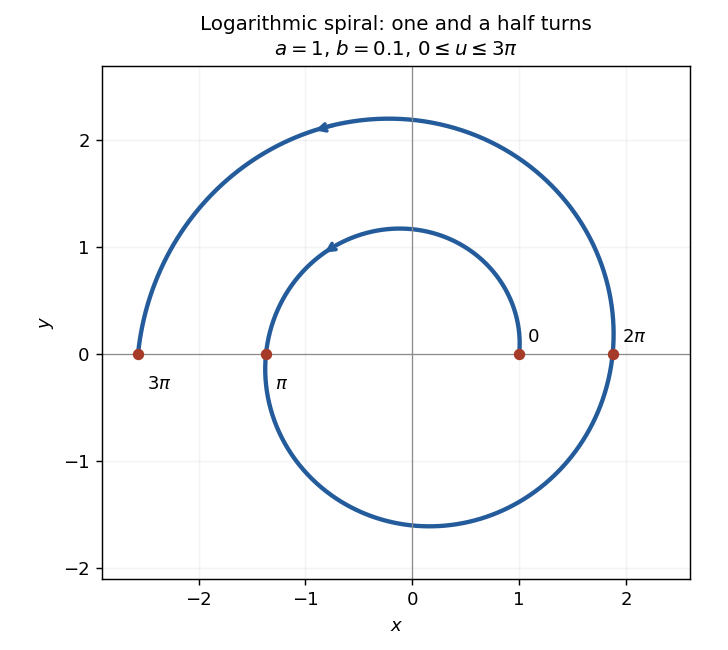
Logarithmic spiral over one and a half counterclockwise turns
. Details. Differentiate the coordinates:Hence . Integrating the arc length element gives, for ,For a negative endpoint parameter the length between and zero uses the absolute value of the final factor.
A second differentiation givesThe numerator is positive, so the absolute value in the PDF's curvature of a plane curve formula leaves it unchanged. ConsequentlyThe speed is , and therefore . Thus the requested elapsed time isThis travel time at reciprocal-curvature speed is independent of because the growing arc length per unit angle is exactly matched by the growing speed.
For a finite group action, the orbit-stabilizer theorem statesThe bijection explains the formula by identifying cosets with the group orbit.
The cube rotation group acts transitively on its six faces. A rotation fixing one face fixes its center and its outward normal, so its axis is the line joining that center to the opposite face's center. The allowed rotations are the four multiples of about this axis. Thus the stabilizer subgroup is , andThe face-pair orbits of cube rotations are the ordered equal-face pairs, opposite-face pairs, and adjacent-face pairs. These relations are preserved by every cube rotation. The first two families are transitive because the face action is transitive and the opposite face is uniquely determined. For the third, first send the first face to a prescribed face, then use its four quarter-turns to send the neighboring second face to any chosen neighbor. Thus there are exactly three orbits, of sizesTheir sizes sum to .
Place the cube with its opposite-face axes along the coordinate axes. ConsiderThe three nonidentity elements are the half-turns about those axes. Multiplying two different ones gives the third, and each squares to the identity, so this is a Klein four-group of order four.
Every cube rotation permutes the three pairs of opposite faces. The associated group homomorphism has exactly as its kernel: fixing all three face-axis pairs allows only independent sign changes of the three coordinate directions, with determinant one. Hence the kernel of the cube face-axis action is a normal subgroup, and
The finite-group Lagrange theorem states that divides for every subgroup , since the disjoint left cosets all have size . In particular, the order of an element divides the group order.
If and , the cyclic subgroup has order greater than one and dividing , so it has order . Therefore every group of prime order is cyclic.
Let now be abelian of order . If an element has order , it generates , giving . Otherwise every nonidentity element has order . Choose and , which is possible because . Commutativity makesa group homomorphism. If and , choose with . Then , a contradiction. Hence and then . The homomorphism is injective and both groups have order , so it is an isomorphism. This proves the abelian group of prime-square order classification:Here denotes the dihedral group of order twelve, as specified in the paper: the hexagon's rotation through has order six. The possible cycle types in are the identity, three-cycles and double transpositions, of orders one, three and two. It has no element of order six. A group isomorphism preserves element orders, so
By transitivity, choose with . If , thenThus . This proves the conjugation assertion directly from the transitive group action.
For the complex special linear group in dimension two, the Möbius transformation of a matrix acts by , with . It fixes infinity exactly when , so its stabilizer subgroup isWe distinguish the cases to avoid dividing by a vanishing coefficient.
If , infinity is not fixed, and the finite fixed points solveNeither root is the pole : substituting that value gives . The fixed-point set is thereforewith the two entries coinciding when the discriminant is zero. The discriminant identity uses .
If and , the fixed points are . If , and , only infinity is fixed. If , and , the determinant condition gives and every point is fixed. Both central matrices induce the identity Möbius transformation.
Every case has a fixed point, because a quadratic over the complex numbers has a root. The action is transitive: any finite is sent to infinity byand infinity already needs no change. Applying the first argument to a fixed point proves every element of is conjugate to an element of .
For each , conjugation sends a subgroup to , a subgroup of the same order and hence still proper. Identity conjugation fixes every subgroup, andThese verify the group action laws.
The stabilizer subgroup of for this conjugation action is its normalizer . Since , the orbit-stabilizer theorem gives the number of distinct conjugates asAll these conjugate subgroups contain the identity, so counting that element only once givesThe last inequality uses the properness of , so . There is therefore an element outside this union, which is not conjugate to any element of . This proves that conjugates of a proper subgroup do not cover a finite group, including the case .
A Cartesian second-rank tensor has components in every orthonormal Cartesian frame that transform according towhen vector components transform as for an orthogonal matrix . Repeated indices are summed. If in one frame, their transformed difference is , so their equality holds in every such frame, at the same physical point.
Now impose the scalar contraction hypothesis on . For every tensor , invariance in the two frames saysAt a fixed point, choose the components of to be each matrix unit in turn; each is an admissible tensor once its components in other frames are transformed. Thus every coefficient of agrees, yielding , orTherefore is necessarily a Cartesian second-rank tensor. This is the scalar contraction test for a Cartesian tensor. Testing all tensors, rather than only symmetric tensors, is essential to the proof.
Let be rotation about the third axis, so invariance means . At , its diagonal signs are ; each mixed entry changes sign and must vanish.
For the remaining planar block , the quarter-turn givesHence and . Writing the constants as givesConversely, commutes with every planar rotation, so every displayed matrix is invariant under every rotation about the axis. This is an oriented-axis invariant Cartesian tensor. Symmetry was not assumed, so the antisymmetric parameter need not vanish.
For , the inertia component is . Reflecting just one of these coordinates preserves the cylinder and its uniform density but changes the integrand's sign. Odd-integrand cancellation by reflection therefore makes every off-diagonal entry zero. Rotations about the axis also give .
Using cylindrical coordinates , , , with , the required integrals areThus the inertia tensor isThe mass is , so these entries are also , respectively.
For a one-to-one continuously differentiable change of variables with nonzero Jacobian determinant in the interior, the change of variables formula isThe absolute value is necessary even if the transformation reverses orientation.
The original region is the first-quadrant area between the hyperbola and circle, above the horizontal-axis segment. More explicitly,Its vertices are , and . Under the squared-radius difference substitution, the inverse isand the image is the triangle , with vertices .
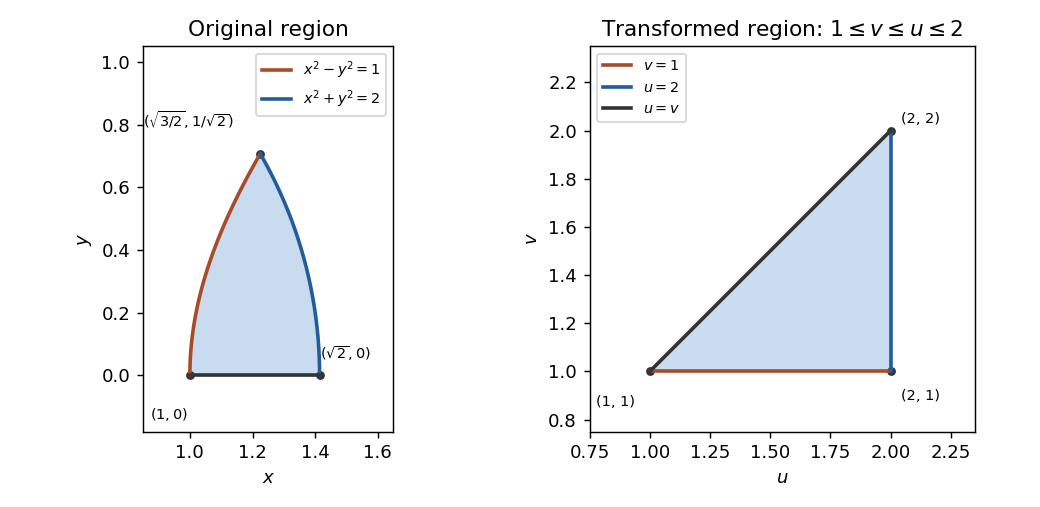


The forward Jacobian determinant isIt is nonzero in the interior; the zero on lies on a measure-zero boundary, so the integral formula applies by taking interior limits. Since and , the inverse-Jacobian factor cancels , givingIntegrating in first and then ,Therefore
For a bounded volume with piecewise smooth boundary and a continuously differentiable vector field on a neighborhood of its closure, the divergence theorem stateswhere is the outward unit normal.
The boundary here consists of a paraboloid cap over the unit disk, a cylindrical wall of height one, and the bottom disk. Their joined surface enclosesThe cap meets the wall at , and the wall meets the base at . The sketches show each boundary piece and their closed union.
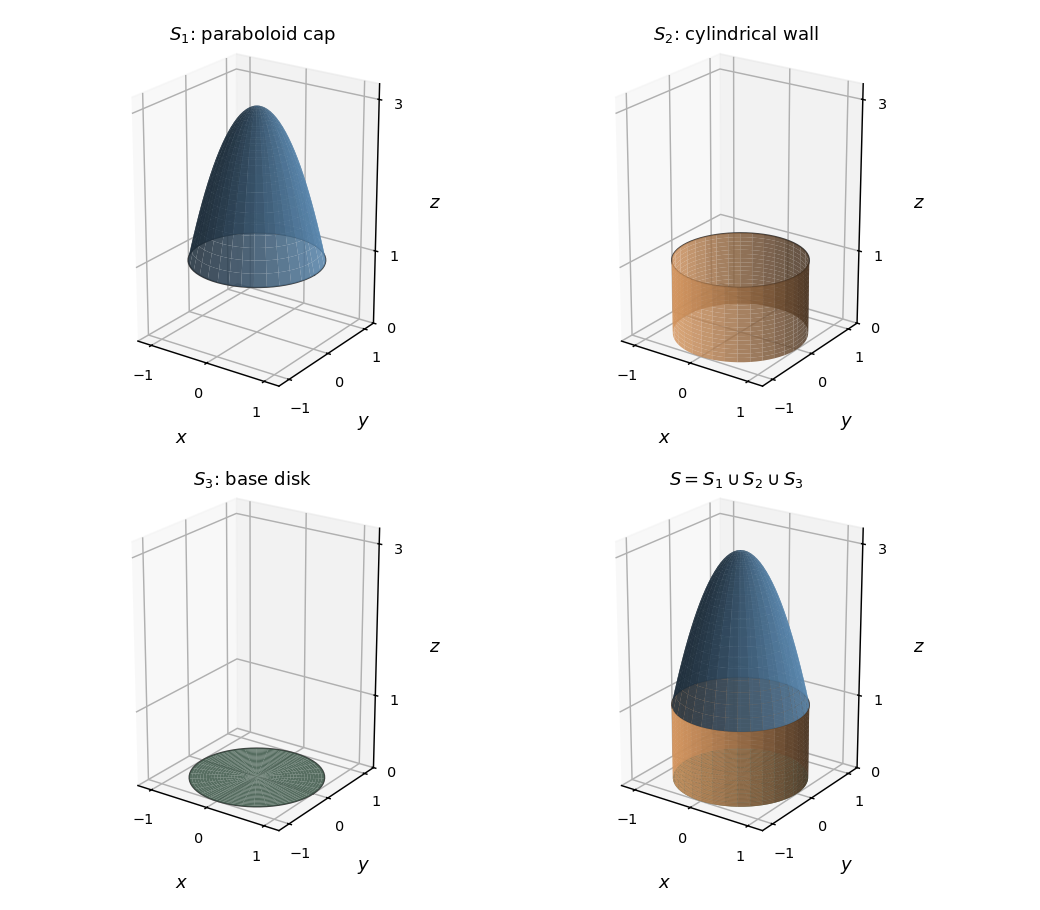
Paraboloid cap, cylindrical wall, base disk, and their closed union
. Details. 
Differentiate the field components to find the divergence:The volume is invariant under reflecting or , so odd-integrand cancellation by reflection removes both odd-power contributions. The outward flux equals the volume:The corners between the three pieces are permitted by the piecewise smooth boundary hypothesis.
For a spherically symmetric potential, the Poisson equation for Newtonian gravity becomesIntegrate from the center, excluding any additional point mass there. The boundary condition is as , soThis derives the enclosed-mass form of the spherical shell theorem from the differential equation. Outside the mass, integrating gives ; the conventional zero at infinity sets .
For the dyadic shells, multiply their constant mass density by their spherical volumes. The th shell contributesSumming the geometric series yieldsAt radius , the enclosed shells are exactly those with ; a boundary itself contributes no mass. ThusDividing by givesThese dyadic spherical shells with inverse-radius density scaling have the same field magnitude at each shell boundary, although the field varies inside an individual shell. Finally, outside the planet,with zero potential at infinity; without that convention an arbitrary additive constant remains.
Articles by others on the same topic
There are currently no matching articles.