
A hadronic form factor parametrizes a current matrix element between hadron states, separating allowed Lorentz covariant tensor structures from scalar-valued functions of Lorentz invariant combinations of momentum transfer. These functions encode composite structure and strong interaction dynamics. Equal kinematic phase space does not imply equal form factors for different weak interaction transitions.
Given a finite set of jobs with fixed half-open intervals , where , choose a subset of maximum cardinality. Each job occupies one shared resource throughout its interval. A feasible solution has pairwise disjoint intervals: for distinct selected jobs , either or . Thus a finish and the next start may coincide. Every job has value one; occupied time is not the objective function.[ref]
Lecture 1: Introduction. 6.046J Design and Analysis of Algorithms, Spring 2015; Printed p. 2, Interval Scheduling: fixed requests, one resource, compatibility with endpoint equality, maximum size
Consider these six original jobs, with arbitrary time units:Job can be followed immediately by and . Job conflicts with all three. Starting the resource earlier is therefore not automatically beneficial: one long commitment can displace several shorter requests.
The earliest-finish greedy algorithm uses a sorting algorithm to put jobs in nondecreasing finish time. Scan that order, accepting the first job and then each job whose start is at least the last accepted finish. Break finish-time ties arbitrarily; an empty input returns the empty set. For these jobs, the order and decisions areAfter , job starts before the current finish five and is rejected. Accept ; then reject because six is before seven. Finally accept . The result is , with cardinality four. Leaving idle makes room for more jobs.
By contrast, the earliest-start rule scans . It accepts , skips , accepts , and skips . Its feasible solution contains only two jobs. Here and meet at time six and are compatible; and overlap on .
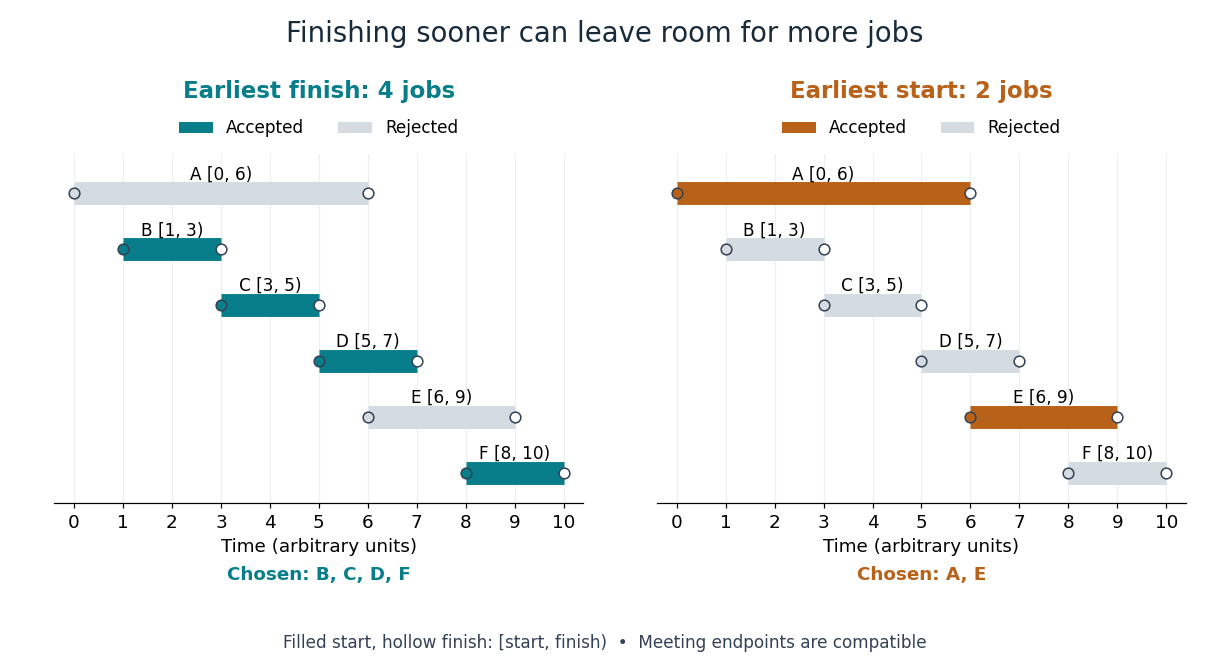
Earliest finish accepts four jobs; earliest start accepts two
. The same six original intervals appear in both panels. Colored jobs are accepted and gray jobs rejected. A filled start and hollow finish depict a half-open interval; jobs meeting at an endpoint are compatible. Details.
There is also an elementary optimality certificate for this example. The four subsets , , and form a partition of a set of the jobs. A feasible solution takes at most one job from each group: overlap, as do , and each other group is a singleton. Hence four is an upper bound, attained by . Checking all subsets gives a unique optimum of size four: .
The earliest-finish theorem states that this greedy algorithm maximizes job count for every finite instance of interval scheduling. For the exchange argument, let be the first job in an optimal feasible solution and an earliest-finishing job. Every later selected job satisfiesReplace by ; compatibility and cardinality survive. The remainder must be optimal among jobs starting at or after , or improving it would improve the whole selection. Mathematical induction on the smaller remaining instance, starting with the empty set, completes the outline.[ref]
Greedy Algorithms. Algorithms by Jeff Erickson; §4.2 Scheduling Classes, Lemma 4.3 and Theorem 4.4, printed pp. 163–164; endpoint equality is allowed by our half-open convention
Why is the algorithm fast? Once sorted, each job is examined once, using only the last accepted finish to decide compatibility. The scan takes time; comparison sorting algorithms give total time complexity for , in Big O notation, assuming constant-cost endpoint comparisons. Already sorted input needs only the scan.[ref]
Lecture 1: Introduction. 6.046J Design and Analysis of Algorithms, Spring 2015; Printed pp. 2–4, earliest-finish rule, compatibility and first-job exchange; scan cost follows by counting one comparison per subsequent request
A greedy-choice property says that some optimal feasible solution contains the locally selected choice. Together with optimal substructure in the remaining instance, it allows repeated commitments. An exchange argument often establishes this property.[ref]
Greedy Algorithms. Algorithms by Jeff Erickson; §4.3 General Pattern, printed pp. 164–165: exchange without worsening an optimum
For interval scheduling, a safe first choice need not belong to every optimal feasible solution. When several optima exist, a commitment may exclude one while retaining another. The useful loop invariant is that the accepted prefix can still be extended to an optimum. Merely keeping the accepted intervals compatible proves feasibility, which is a weaker claim.
Chapter 6 of Graph Theory by Reinhard Diestel, by Reinhard Diestel. Springer publishes the book; the author’s University of Hamburg site hosts the preview. No edition, publication year or revision date is established from this preview.
Cited passages: Chapter 6 opening, printed p. 155 (PDF p. 1): signed amounts and nonterminal conservation.; §6.2, printed p. 158 (PDF p. 4): independently specified orientation capacities, conditions F1/F2′/F3 and source/sink cut definition.; §6.2, printed p. 159 (PDF p. 5): Proposition 6.2.1, cancellation proof, total-value definition, footnote 4 on negative values, capacity upper bound and Theorem 6.2.2..
The upper part of the terrestrial atmosphere includes regions where ionization makes the response to electromagnetic waves depend strongly on mobile electrons. The ionosphere describes that electrical structure; its boundaries need not coincide with the boundaries defined by temperature in the mesosphere and thermosphere.
Geometry studies shapes, positions and spatial relationships through the structures and transformations under consideration. Euclidean geometry measures lengths and angles; projective geometry emphasizes incidence; differential geometry studies smooth spaces using tangent spaces and curvature. A circle can be stretched into an ellipse by an affine map, but generally not by a Euclidean isometry. Their curves are also homeomorphic, illustrating how topology preserves a different level of structure.
A geometric envelope is a curve tangent to the members of a smoothly varying family of curves. For a regular implicit family , candidate contact points also satisfy the partial derivative condition ; regularity is needed to turn these candidates into an actual envelope. The Mach cone is a three-dimensional analogue for expanding spheres.
There are unlisted articles, also show them or only show them.